News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesEntropy-Augmented Multi-Objective Policy Optimization in Multiagent Systems
arXiv:2608.12534v1 Announce Type: cross Abstract: Autonomous agent teams deployed in settings such as marine and extraterrestrial outposts must coordinate actio…
Towards Socially Compliant Navigation in Deep Reinforcement Learning via Proxemics-Based Reward Modeling
arXiv:2608.12917v1 Announce Type: cross Abstract: Developing effective robot navigation methods in crowded environments is essential for real-world applications…
RGB-D Video Generation for Improving Human-to-Robot Object Handover Prediction
arXiv:2608.13028v1 Announce Type: cross Abstract: Human-to-robot (H2R) object handover is a fundamental capability for human-robot collaboration, yet progress i…
DreamX-Phi 1.0: Action-Conditioned Video World Model for Robotic Manipulation
arXiv:2608.13489v1 Announce Type: cross Abstract: We present \textbf{DreamX-Phi 1.0}, an action-conditioned video world model for robotic manipulation that, giv…
SONIC: Supersizing Motion Tracking for Natural Humanoid Whole-Body Control
arXiv:2511.07820v4 Announce Type: replace Abstract: Despite the rise of billion-parameter foundation models trained across thousands of graphical processing uni…
APEX: Learning Adaptive High-Platform Traversal for Humanoid Robots
arXiv:2602.11143v3 Announce Type: replace Abstract: Humanoid locomotion has advanced rapidly with deep reinforcement learning (DRL), enabling robust feet-based …
Perception-Aware Autonomous Exploration in Feature-Limited Environments
arXiv:2603.15605v2 Announce Type: replace Abstract: Autonomous exploration in unknown environments typically relies on onboard state estimation for localisation…
SpatialVAM:Spatial-Aware Multi-View Video Diffusion as a Data-Efficient Robot Policy
arXiv:2604.03181v2 Announce Type: replace Abstract: Robotic manipulation requires understanding both the 3D spatial structure of the environment and its tempora…
JailWAM: Jailbreaking World Action Models in Robot Control
arXiv:2604.05498v2 Announce Type: replace Abstract: World Action Models (WAMs) have emerged as a promising paradigm for robotic manipulation, enabling physical …
Trajectory First: A Curriculum for Discovering Diverse Policies
arXiv:2506.01568v4 Announce Type: replace-cross Abstract: Being able to solve a task in diverse ways makes agents more robust to task variations and less prone …
Predictive Relative-Velocity Steering for Safe Robotic Manipulator Teleoperation in Dynamic Environments
arXiv:2608.13284v1 Announce Type: new Abstract: Recent advances in teleoperation have enabled robotic manipulators to perform dexterous, human-arm-like motions.…
OpenRC: An Open-Source Robotic Colonoscopy Framework for Multimodal Data Acquisition and Autonomy Research
arXiv:2604.03781v2 Announce Type: replace Abstract: Colorectal cancer screening critically depends on colonoscopy, yet existing platforms offer limited support …
AMR-Pose: An Active LED Marker-Based Relative Pose Estimation Framework With Probabilistic Switching PnP for Cooperative AUVs
arXiv:2608.12866v1 Announce Type: new Abstract: Reliable relative pose estimation between autonomous underwater vehicles (AUVs) is critical for cooperative ocea…
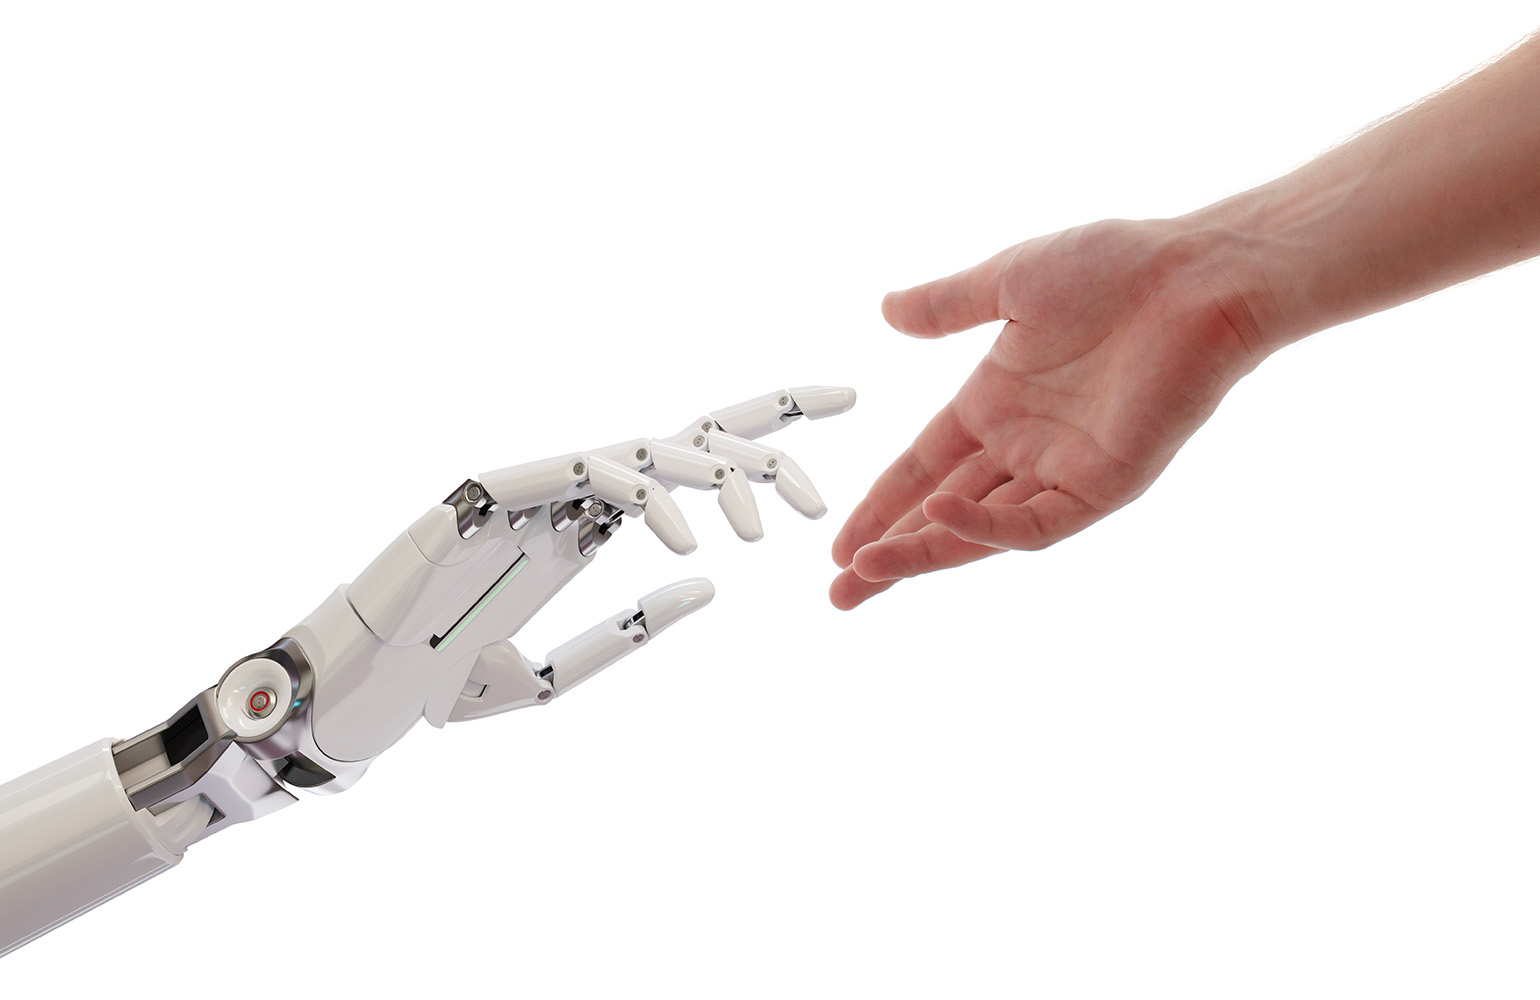
BioflexBot robot hand aims to replicate key human hand motions
Researchers created the BioflexBot, a novel robot that mimics and even exceeds core motions of the hand with a simple design. The post BioflexBot robot hand aim…
Mobile manipulators and humanoids: The future of robotics
Humanoid robotics and software startups have emerged weekly for the past year, capturing media attention and billions of dollars in investment. While some human…
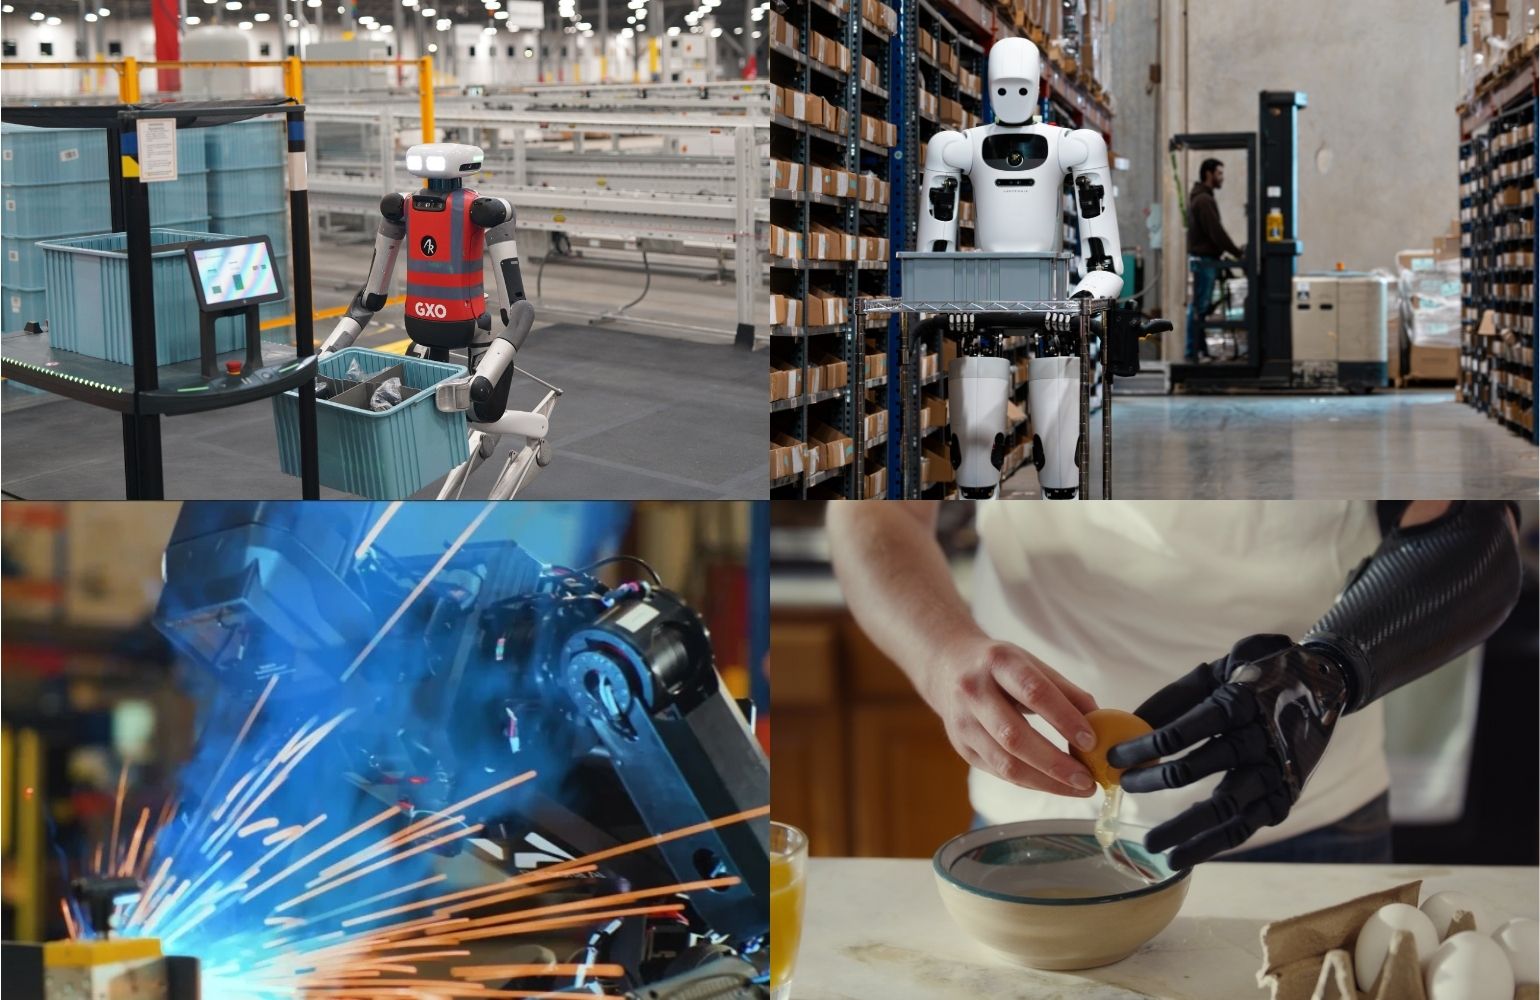
Experts to discuss the state of humanoid robots at RoboBusiness
The RoboBusiness panel will include insights on humanoid robots from Agility, Apptronik, Persona AI, and PSYONIC experts. The post Experts to discuss the state …
ARM Institute calls for defense manufacturing technology projects
The ARM Institute and the U.S. Department of War are seeking technology project submissions to help rapid U.S. production. The post ARM Institute calls for defe…
Towards Tighter Convex Relaxation of Mixed-Integer Programs: Leveraging Logic Network Flow for Task and Motion Planning
arXiv:2509.24235v2 Announce Type: replace Abstract: This paper proposes an optimization-based task and motion planning framework, named "Logic Network Flow," th…
Robotic Manipulation is Vision-to-Geometry Mapping: Vision-Geometry Backbones over Language and Video Models
arXiv:2604.12908v2 Announce Type: replace Abstract: At its core, robotic manipulation is a problem of vision-to-geometry mapping ($f(v) \rightarrow G$). Physica…
TMRL: Diffusion Timestep-Modulated Pretraining Enables Exploration for Efficient Policy Finetuning
arXiv:2605.12236v2 Announce Type: replace Abstract: Fine-tuning pre-trained robot policies with reinforcement learning (RL) often inherits the bottlenecks intro…
Top-down Traffic Scenario Generation via Joint Initial-Goal Diffusion and Trajectory Infilling
arXiv:2608.11407v1 Announce Type: new Abstract: Robust traffic simulators are crucial for developing and testing autonomous vehicles to reduce the costly, labor…
From Self-Normal-Positioning to Omni-Directional Tracking: Real-Time Surface Modeling Enabled Probe Tilt Control for Robotic Ultrasound Imaging
arXiv:2608.11409v1 Announce Type: new Abstract: Ultrasound (US) provides real-time, radiation-free imaging, but the image quality depends strongly on how the pr…
Locomotion Variability and User Experience in Smart Wheelchair Human-Robot Interaction
arXiv:2608.11417v1 Announce Type: new Abstract: Human movement is inherently variable, with variability structured according to task relevance: movements are ty…
Repurposing RGB-based Foundation Model for Depth Estimation on Thermal Images Using Hierarchical Supervision
arXiv:2608.11564v1 Announce Type: cross Abstract: Depth estimation from thermal images is highly valuable for robotic applications in adverse conditions, such a…
Towards the Harness of Embodied Agents
arXiv:2608.11246v1 Announce Type: cross Abstract: The success of coding agents has established the harness as a paradigm: what an agent achieves depends not on …
Utilizing Inpainting for Keypoint Detection for Vision-Based Control of Robotic Manipulators
arXiv:2604.13309v2 Announce Type: replace Abstract: We present a novel visual servoing framework for controlling a robotic manipulator in configuration space us…
FEWT: Frequency-Enhanced Wavelet-based Transformer for Multimodal Wheeled Bimanual Manipulation
arXiv:2509.11109v4 Announce Type: replace Abstract: Embodied intelligence bridges the physical world and information spaces, with robots demonstrating immense p…
RoboHarness: A Memory-Augmented Policy Harness for Vision-Language-Action Model Robustness via In-Context Adaptation
arXiv:2603.24060v3 Announce Type: replace Abstract: Despite the promise of Vision-Language-Action (VLA) models as generalist robotic controllers, their robustne…
A Generalized Theory of Load Distribution in Redundantly-actuated Robotic Systems
arXiv:2603.11431v2 Announce Type: replace Abstract: This paper presents a generalized theory which describes how applied loads are distributed within rigid bodi…
UniGround: Universal 3D Visual Grounding via Training-Free Scene Parsing
arXiv:2603.08131v2 Announce Type: replace Abstract: 3D Visual Grounding (3DVG) localizes objects from natural-language descriptions in 3D scenes and is fundamen…