News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 stories
General Robotics is betting on modular intelligence, not one robot brain
Rather than training one model to do everything, General Robotics composes specialized capabilities—helping robots adapt across tasks and form factors. The post…
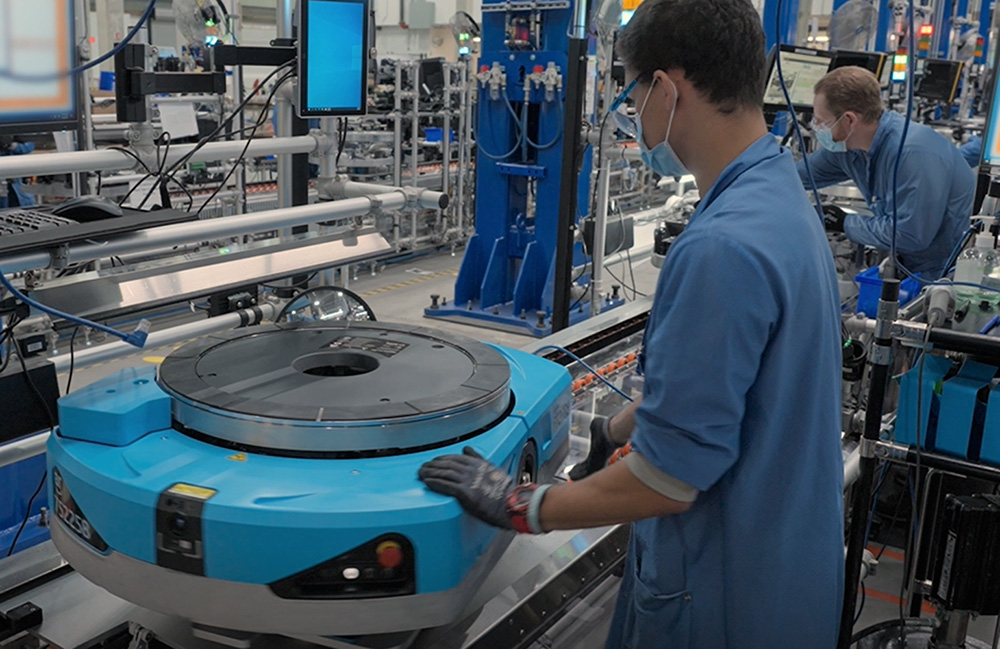
Amazon to invest $100M in new Indiana manufacturing facility
The new facility will produce products that power Amazon's fulfillment and robotics network across North America. The post Amazon to invest $100M in new Indiana…

Farmers are facing more pressure; CNH says robotics can help
Labor availability, costs, productivity, and efficiency are common concerns of farmers that technology can address, according to CNH. The post Farmers are facin…

Agility Robotics, maker of Digit humanoid, exploring wheeled robots
Agility Robotics is exploring a range of robot designs and form factors, including wheels, to address different operating environments and customer needs. The p…

Robot Talk Episode 163 – Robots helping people, with Aaron Edsinger
Claire chatted to Aaron Edsinger from Hello Robot about their Stretch robots that can help people with mobility issues live more independently. Aaron Edsinger i…

An open source approach to physical AI from Intrinsic
Deborah Lupton / Pop Chips / Licenced by CC-BY 4.0 Intrinsic (an AI robotics group at Google) announced that the company is making parts of its platform open so…
Know Your Body: A Harness for Direct and Self-Improving Robot Control with VLMs
arXiv:2609.28530v1 Announce Type: new Abstract: A general-purpose vision-language model can understand a task goal without knowing how a particular robot's moti…
OA-MPPI: Occlusion-Aware Model Predictive Path Integral Control for UAV Flight
arXiv:2609.28709v1 Announce Type: new Abstract: Autonomous UAV flight through cluttered and partially unknown environments requires reasoning not only about obs…
Temporal Learning for End-Effector Position Estimation under Aerodynamic Disturbances in Aerial Continuum Manipulation
arXiv:2609.28716v1 Announce Type: new Abstract: This paper investigates temporal neural networks for \mbox{end-effector} position \mbox{estimation} of an aerial…
TAPESIM: Efficient Simulation of Adhesive Tape Dispensing for Robotic Manipulation
arXiv:2609.28766v1 Announce Type: new Abstract: Applying adhesive tape to secure wire harnesses or seal packages requires robots to coordinate a flexible strip,…
FlyCNS: Connectome-Grounded Information Organization for Communication-Constrained Embodied Control
arXiv:2609.28816v1 Announce Type: new Abstract: Robotic bodies are inherently distributed in sensing and actuation, yet learning-based control still commonly re…
KeyGen: Unsupervised Keypoint based Object-Centric Representations for Category-Level Policy Generalization
arXiv:2609.28818v1 Announce Type: new Abstract: Generalization in robotic manipulation requires policies to perform tasks across diverse unseen object instances…
Fly, Drive, Reconfigure: A Modular Reconfigurable Aerial-Ground Platform for Field Operations
arXiv:2609.28887v1 Announce Type: new Abstract: Heterogeneous robot teams distribute complementary capabilities across specialized agents, but their physical ro…
Robots That Take Initiative: A Framework for Building and Evaluating Proactive Robots
arXiv:2609.28910v1 Announce Type: new Abstract: Effective robot assistance beyond narrow roles and repetitive tasks requires robots to be proactive - to decide …
Koopman-Accelerated Model-Based Diffusion for Real-Time Robot Control
arXiv:2609.28920v1 Announce Type: new Abstract: Conventional model-based diffusion (MBD) achieves effective trajectory optimization by leveraging noise annealin…
Echo in the Steps: Learning Perceptive Humanoid Parkour with Gated Memory
arXiv:2609.28960v1 Announce Type: new Abstract: While recent advances in perceptive locomotion have enabled humanoid robots to traverse structured terrains, agi…
Sim-to-Real Aware End-to-End Learning Environment for Micromobility
arXiv:2609.28969v1 Announce Type: new Abstract: While end-to-end autonomous driving systems show promise, their application to micromobility vehicles is hindere…
CAMP: Cooperative Arm-Hand Motion Planning in Constrained Spaces
arXiv:2609.29021v1 Announce Type: new Abstract: Coordinated arm-hand motion planning is fundamental to dexterous robotic manipulation in complex and constrained…
Design and Evaluation of LLM Chaining-Based Task Planning for General Purpose Service Robots
arXiv:2609.29043v1 Announce Type: new Abstract: General Purpose Service Robot (GPSR) tasks, as defined in the RoboCup@Home benchmark, require robots to interpre…
DA-GRD: Decision-Aware Grasp-Relevant Disambiguation for tactile recovery under perception-to-execution mismatches
arXiv:2609.29065v1 Announce Type: new Abstract: Grasping is a fundamental robotic capability that bridges perception and physical task execution. This paper stu…
A Tendon-Driven Robotic Jellyfish with Constrained Soft Actuation and Depth Control via Reinforcement Learning
arXiv:2609.29132v1 Announce Type: new Abstract: Jellyfish-inspired robots offer a compliant and efficient approach to underwater locomotion, but achieving large…
OREN-X: Octree Residual Network for Real-Time Multi-Modal Mapping
arXiv:2609.29157v1 Announce Type: new Abstract: To achieve general-purpose autonomy over long horizons, a robot needs to maintain spatial environment informatio…
Dense-Joint-Based Obstacle-Aided Locomotion with a Joint-Repositionable Snake Robot
arXiv:2609.29261v1 Announce Type: new Abstract: Obstacle-aided locomotion is a fundamental capability for snake robots to traverse complex environments. However…
EgoSpeedUp: Transferring Human Manipulation Tempo to Robot Policies
arXiv:2609.29310v1 Announce Type: new Abstract: Robot manipulation policies trained through imitation learning inherit not only the demonstrated behavior but al…
A Simple Gripper Interface for Simulator-Agnostic Cloth Manipulation
arXiv:2609.29340v1 Announce Type: new Abstract: This paper presents a grasping model for cloth manipulation specifically tailored to ease the deployment of robo…
Free-Init: Scan-Free, Motion-Free, and Correspondence-Free Initialization for Doppler LiDAR-Inertial Systems
arXiv:2609.29375v1 Announce Type: new Abstract: Robust initialization is crucial for online systems. In the letter, a high-frequency and resilient initializatio…
Decoupled Early Exits for Task-Dependent Compute Allocation in Flow-Matching VLAs
arXiv:2609.29382v1 Announce Type: new Abstract: Flow-matching Vision-Language-Action (VLA) models have emerged as a potential solution for generalist robot cont…
Robo-Harness K1: Harnessing Robot-Use Agents via Perception Augmentation
arXiv:2609.29389v1 Announce Type: new Abstract: Foundation vision-language models (VLMs) understand objects, instructions, and spatial relations, yet translatin…
RACaP: Agentic Reasoning, Acting, and Coding as Policies for Evolvable Robot Learning
arXiv:2609.29394v1 Announce Type: new Abstract: General-purpose robot agents must learn from experience, transfer to new tasks, and act efficiently. Code as Pol…
WRAP: Fixtureless Wrench-aware Multi-Robot Assembly Planning
arXiv:2609.29407v1 Announce Type: new Abstract: Assembly using robots often requires specially designed fixtures, or relies on top-down only assembly strategies…