News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesKeep the Future, Drop the Rollout: RIFT for World Action Models
arXiv:2608.11521v1 Announce Type: new Abstract: World action models (WAMs) condition robot actions on predicted futures, but iterative video rollout increases d…
IoT-Enabled Autonomous Maritime Navigation in Smart Ports: A Curriculum-Guided Shared Policy Learning Framework
arXiv:2608.11597v1 Announce Type: new Abstract: As smart port infrastructures increasingly rely on autonomous maritime devices enabled by the Internet of Things…
RoadWeaver: Large-Scale Lane-Level HD Map Generation from Scratch for Autonomous Driving Simulation
arXiv:2608.11580v1 Announce Type: new Abstract: Autonomous driving simulation requires diverse and scalable lane-level HD maps to support long-horizon evaluatio…
Policy-Induced Hand Priors in Humanoid Dual-Arm Manipulation: Diagnosing and Mitigating Initial-Pose Dependence
arXiv:2608.11769v1 Announce Type: new Abstract: Vision-language-action (VLA) policies are expected to operate robustly across variations in the robot's initial …
Synchronizing Beliefs with Second-Order Theory-of-Mind in Human-Autonomy Teams (Extended Version)
arXiv:2608.11229v1 Announce Type: cross Abstract: Comparative feedback, asking people which of two behaviors they prefer, has become a standard way to align rob…
Herding End-to-End Autonomous Driving via Neuro-Symbolic Safety Guards
arXiv:2608.11451v1 Announce Type: new Abstract: Modern end-to-end driving agents can achieve high average performance yet still violate basic traffic rules that…
G0.5: One Autoregressive Stream for Robot Reasoning and Action
arXiv:2608.11739v1 Announce Type: new Abstract: The prevailing recipe for Vision-Language-Action (VLA) models couples a pretrained VLM with a separately trained…
Adaptation of Generalist Robot Policies with Minimal Data
arXiv:2608.11363v1 Announce Type: new Abstract: A central goal in robot learning is to move beyond task-specific human data collection toward robots that improv…
HandEdit: A Unified Benchmark for Egocentric Human-to-Robot Dexterous Hand Image Editing
arXiv:2608.12122v1 Announce Type: new Abstract: Robotic manipulation with dexterous hands is a cornerstone of Embodied AI, yet its progress is stifled by the hi…
Learning Loco-Manipulation From SMPC Demonstrations With Sparse Offline-to-Online RL
arXiv:2608.12063v1 Announce Type: new Abstract: Integrating locomotion and manipulation is essential for robot autonomy, but scaling standard Reinforcement Lear…
D3D-GEN: Robot-Aware Domain-Grounded Interactive 3D World Generation for Social Robotics
arXiv:2608.11876v1 Announce Type: new Abstract: Training and validation of Embodied AI for social navigation critically depends on realistic simulation environm…
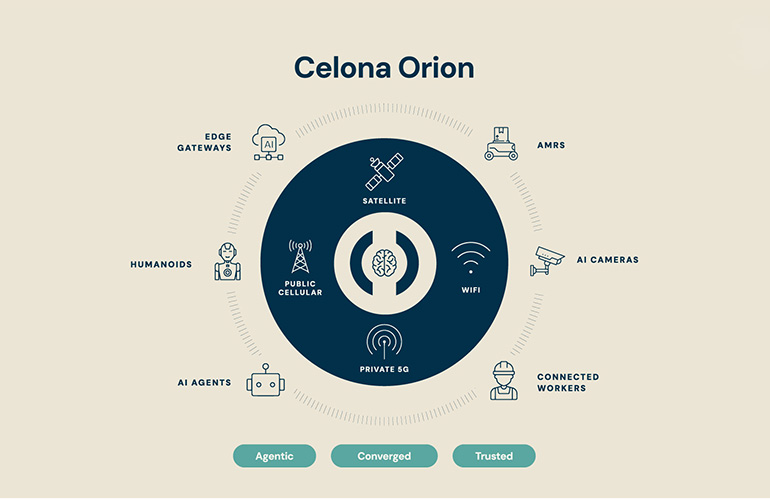
Celona launches Orion agentic wireless platform built for physical AI and robotics
Celona launched Celona Orion, a unified agentic platform merging private 5G, Wi-Fi, cellular, and satellite into one network for physical AI. The post Celona la…
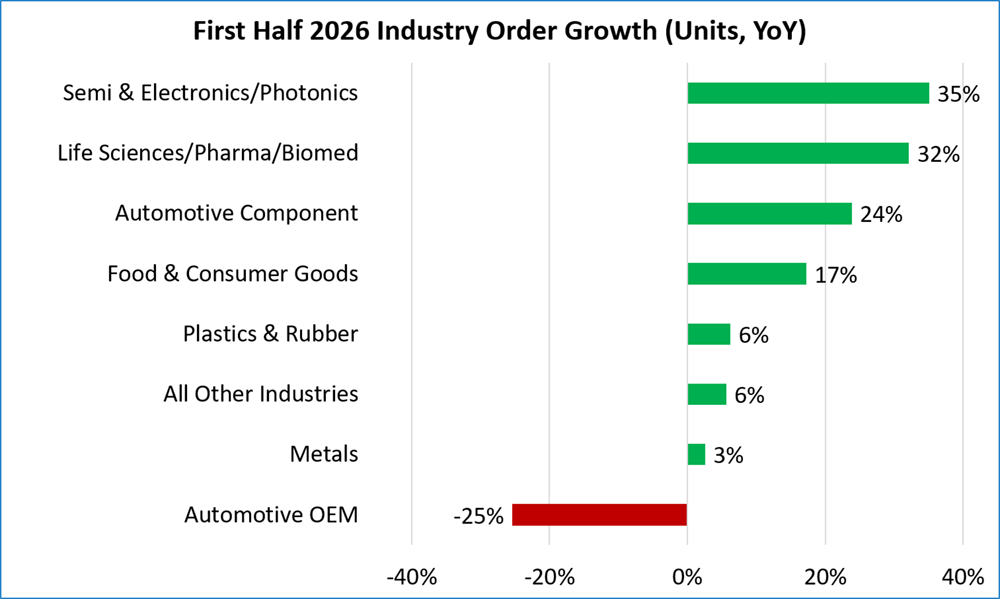
Q2 2026 robotics demand increased across industries, reports A3
A3 said that Q2 2026 robotics orders in food, electronics, and healthcare helped offset soft demand from automotive manufacturing. The post Q2 2026 robotics dem…
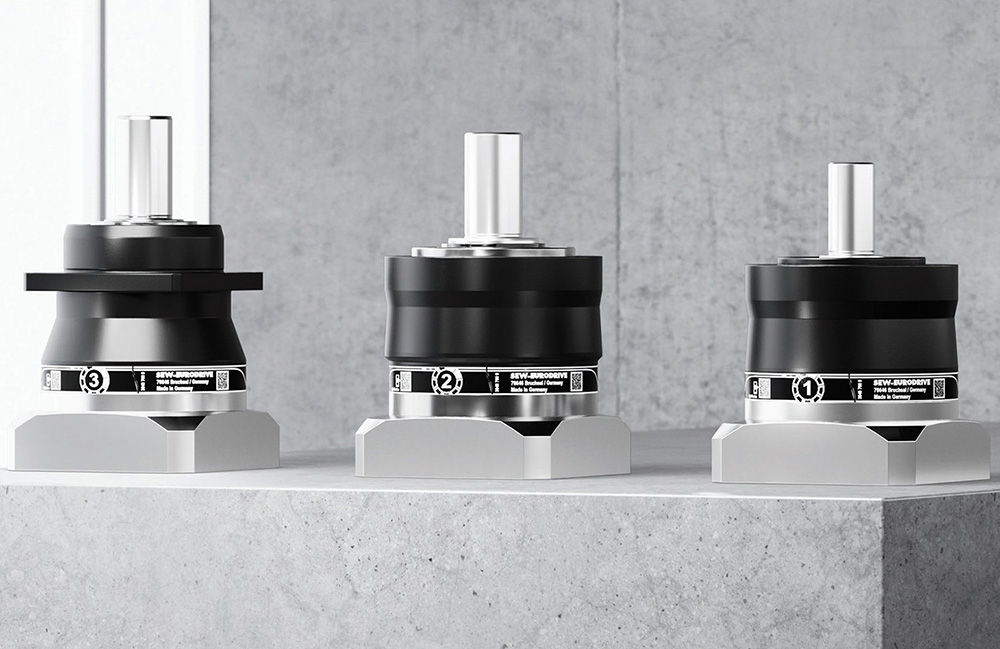
SEW-EURODRIVE adds economy series to its planetary servo gear unit portfolio
SEW-EURODRIVE's new P1.G, P2.G and P3.G gear units extend its existing PxG family below the P5.G, P6.G, and P7.G precision range. The post SEW-EURODRIVE adds ec…
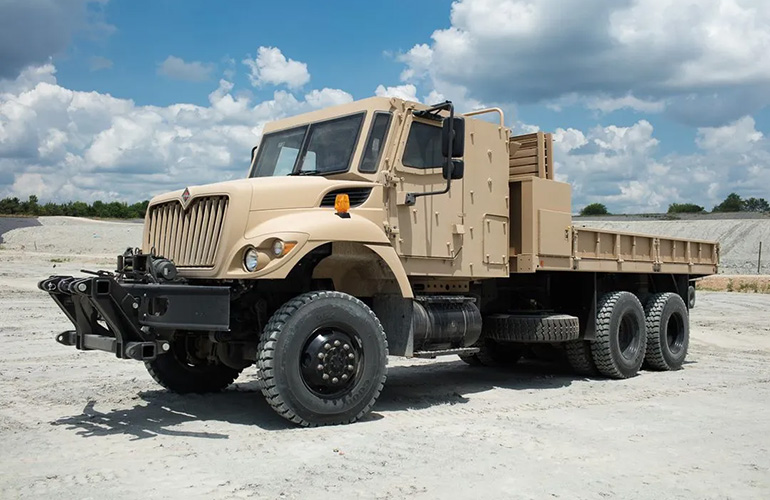
Strengthening U.S. Army sustainment: TALUS to deliver autonomous distribution
A Stratom-led team won a U.S. Army contract to develop TALUS, an autonomous logistics system for contested environments. The post Strengthening U.S. Army sustai…

DAF Trucks to integrate Einride Driver to scale autonomous electric freight
Einride is integrating its self-driving software with PACCAR unit DAF Trucks and research at TNO to advance safe autonomous trucking. The post DAF Trucks to int…
OmniVTA: Visuo-Tactile World Modeling for Contact-Rich Robotic Manipulation
arXiv:2603.19201v3 Announce Type: replace Abstract: Contact-rich manipulation tasks, such as wiping and assembly, require accurate perception of contact forces,…
Learning in ImaginationLand: Omnidirectional Policies through 3D Generative Models (OP-Gen)
arXiv:2509.06191v2 Announce Type: replace Abstract: Recent 3D generative models, which are capable of generating full object shapes from just a few images, now …
The Impact of Operational-Data Fidelity when Assessing Safety-Critical Autonomous-Vehicle Software
arXiv:2608.10025v1 Announce Type: new Abstract: For safety-critical software, data from the software's operational past (e.g. a sequence of success and failure …
Protection Levels for Vision-Based Pose Estimation
arXiv:2608.10023v1 Announce Type: new Abstract: Vision-based navigation complements Global Navigation Satellite Systems, but certification demands integrity gua…
AECNav: Active Evidence Consolidation for Efficient Zero-Shot Open-Vocabulary Object Navigation
arXiv:2608.10817v1 Announce Type: new Abstract: Zero-shot object-goal navigation (ZSON) in open-vocabulary scenarios is challenging, as it requires a robot to l…
Enabling Scalable Kinesthetic Teaching via Observer-based Hand-guiding with Active Support
arXiv:2608.10847v1 Announce Type: new Abstract: Kinesthetic teaching through robot hand-guiding provides a natural interface for collecting demonstrations in im…
Aerial Layouting: Design and Control of a Compliant and Actuated End-Effector for Precise In-flight Marking on Ceilings
arXiv:2608.10987v1 Announce Type: new Abstract: Aerial robots have demonstrated impressive feats of precise control, such as dynamic flight through openings or …
Risk-Aware Kinodynamic Motion Planning Under Uncertainty For Safe Navigation on Planetary Environments
arXiv:2608.11175v1 Announce Type: new Abstract: For autonomous space exploration, robotic agents need to perform motion planning in which environmental interact…
Surgical WAM: A World-Action Model for Data-Efficient Surgical Robot Learning
arXiv:2608.11204v1 Announce Type: new Abstract: Learning reliable surgical manipulation policies is bottlenecked by the scarcity of action-labeled demonstration…
Dual Stress: Runtime Safety Monitoring for Safety-Constrained MPC Navigation
arXiv:2608.10791v1 Announce Type: new Abstract: Runtime hazard monitors for autonomous naviga- tion are conventionally built from geometric quantities: predicte…
When Your State Estimator Has Lost The Plot: Detecting Estimator Failures Via Spectral Analysis
arXiv:2608.10623v1 Announce Type: new Abstract: Reliable onboard state estimation is essential for safe robotic operation, yet unmodeled disturbances, such as s…
Precise Top-Layer Fabric Segmentation for Fabric Destacking with Edge- and Shape-Aware Deep Networks
arXiv:2608.10648v1 Announce Type: cross Abstract: Fabric destacking requires precise segmentation of the topmost fabric layer, a task complicated by subtle fabr…
Autonomous Exploration-Based Precise Mapping for Mobile Robots through Stepwise and Consistent Motions
arXiv:2503.17005v3 Announce Type: replace Abstract: This paper presents an autonomous exploration framework. It is designed for indoor ground mobile robots that…
Diffusion-Based Impedance Learning for Contact-Rich Manipulation Tasks
arXiv:2509.19696v4 Announce Type: replace Abstract: Learning-based methods excel at robot motion generation but remain limited in contact-rich physical interact…