News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesFlatLab: A Unified Methodology Framework and Simulation-Based Benchmark for Robotic Manipulation of Flat Objects
arXiv:2608.14049v1 Announce Type: new Abstract: Robotic manipulation of flat objects is challenging due to the ungraspable configurations and strong variations …
hint$^2$: Hierarchical World Models for Inference-Time Temporal Logic Guidance
arXiv:2608.13678v1 Announce Type: new Abstract: A central goal of robot learning is to enable robots to execute rich instructions specified at runtime. Large-sc…
Knowledge-Data-Dual-Driven Reinforcement Learning for Autonomous Vehicle Control in Mixed Traffic
arXiv:2608.13878v1 Announce Type: new Abstract: In mixed traffic, decision-making for autonomous vehicles (AVs) confronts three interrelated challenges. First, …
Demonstration of Space Robot Teleoperation over a Lossy and Delayed Network using ATMOS
arXiv:2608.14031v1 Announce Type: new Abstract: We present a demonstration showcasing the Autonomy Testbed for Multi-purpose Orbiting Systems (ATMOS), a planar …
PILOT: Privileged Imitation Learning for End-to-End Motion Planning of Autonomous UAVs under Partial Observability
arXiv:2608.14082v1 Announce Type: new Abstract: Autonomous navigation in cluttered environments is hampered by partial observability and dynamic constraints. Th…
Control-Informed Constraint Adaptation in Minimum-Time Trajectory Planning for Autonomous Racing
arXiv:2608.14448v1 Announce Type: new Abstract: Autonomous racecars operate at the limits of vehicle dynamics, where small control errors translate into safety-…
Expected Free Energy-based Informative Path Planning for Robotic Mars Exploration
arXiv:2608.14466v1 Announce Type: new Abstract: An autonomous robot efficiently exploring an unknown environment, such as looking for water sources on Mars, fac…
Spatiotemporal Tube-Based Safety-Certificate for Autonomous Navigation of Articulated Vehicles
arXiv:2608.14531v1 Announce Type: new Abstract: Articulated vehicles are the workhorses of freight transportation, and their autonomous navigation is challengin…
Learning-Guided Sparsification of Dynamic Graphs in Robotic Exploration
arXiv:2604.16509v2 Announce Type: replace Abstract: Many robotic exploration algorithms rely on graph structures for frontier-based exploration and dynamic path…
How robotics is revolutionizing stroke rehabilitation
Eyal Samuel Shachar, the CEO of Bioxtreme, says the growing synergy of robotics, AI, and human-centered care will improve patient outcomes. The post How robotic…
Why robots that can’t communicate naturally won’t be adopted
Gunnar Pétur Hauksson, the co-founder and COO at Treble Technologies, says robotics developers can't overlook the importance of hearing. The post Why robots tha…

How Protolabs turns CAD files into parts in under 24 hours
Protolabs CTO Marc Kermisch explains how AI, simulation, and design for manufacturing turn CAD files into production parts faster. The post How Protolabs turns …

Neros Technologies raises $250M to deploy its defense drones by the end of 2026
Neros is developing its Archer AI and Bandit platform with the hardware and compute required for multi-asset control. The post Neros Technologies raises $250M t…
Robots on Wall Street: Non-traditional paths to public markets for robotics companies
Agility’s SPAC deal shows there is no one route to a robotics public listing, with SPAC mergers, reverse mergers, and traditional IPOs offering different advant…
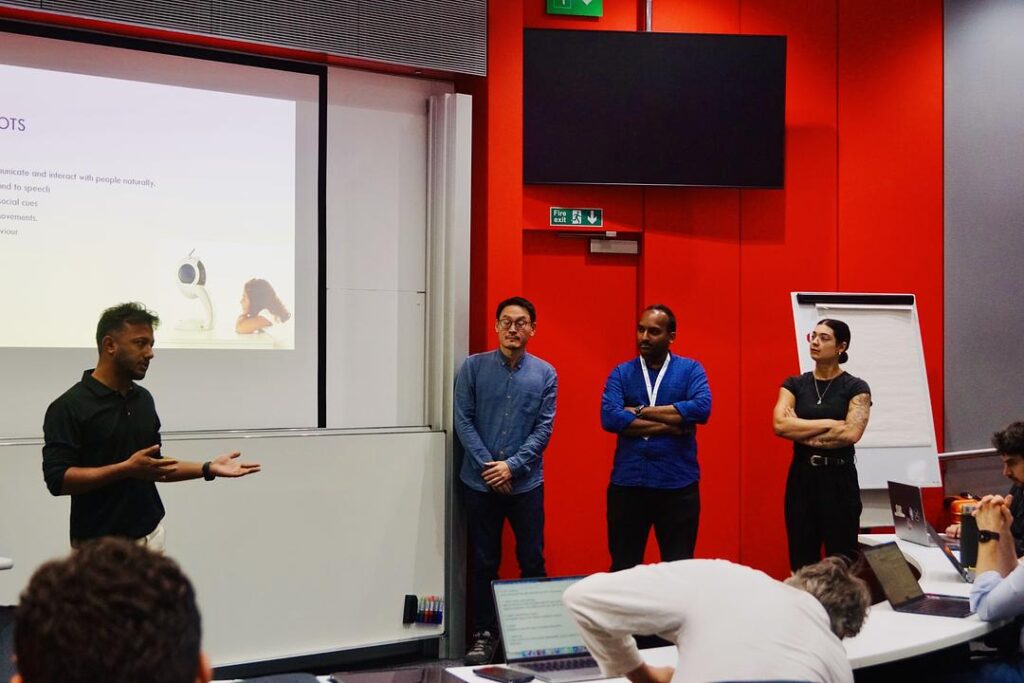
What does it take for a robot to hold a conversation with a room, not just a person?
By Umar Farooq That was one of the questions at the heart of my last week (20th-24th July) at the Imperial Robotics Summer School, hosted at Imperial College, L…
RoboSynChallenge: Mastering Real-World Dexterity via Generalizing Synthesized Manipulation Skills
arXiv:2608.12416v1 Announce Type: new Abstract: Achieving generalizable robotic manipulation remains a central challenge in embodied intelligence. Despite rapid…
Attune: A Self-Annotation Tool for Understanding Robot Operator Attention Profiles
arXiv:2608.12650v1 Announce Type: new Abstract: Deploying robot fleets in complex, real-world environments requires human operators to supervise multiple robots…
Genetic Fuzzy System-Based Multi-Robot Coordination for Planetary Missions
arXiv:2608.12755v1 Announce Type: new Abstract: This paper proposes a decentralized approach for a multi-robot system (MRS) using a genetic fuzzy system to perf…
BrainWAM: Action-Space Coordination of Semantic Priors and Predictive Dynamics for Autonomous Driving
arXiv:2608.12854v1 Announce Type: new Abstract: Autonomous driving requires planning under both semantic constraints and predictive dynamics. Existing end-to-en…
HumanoidVLN: A Physics-Grounded Simulator and Benchmark for Vision-Language Navigation Across Diverse Humanoid Embodiments
arXiv:2608.12860v1 Announce Type: new Abstract: Vision-Language Navigation (VLN) for humanoid robots poses challenges existing benchmarks fail to address: biped…
H2R-Bench: Benchmarking Human-to-Robot Manipulation Video Generation in World Models
arXiv:2608.13049v1 Announce Type: new Abstract: Large-scale manipulation data is essential for robot learning, yet collecting robot demonstrations remains expen…
S2-HWM: Sparse Event-Structured Hierarchical World Model for Long-Horizon Surgical Robot Manipulation
arXiv:2608.13103v1 Announce Type: new Abstract: Long-horizon surgical robot manipulation is challenging because task rewards are sparse, while meaningful intera…
NestDex: Nested Policy Learning with Copilot Assisted Teleoperation for Dexterous Manipulation
arXiv:2608.13362v1 Announce Type: new Abstract: Dexterous manipulation promises substantially richer robot interaction with the physical world, but learning the…
FIRE-VLA: Failure-Informed Self-Evolution for Vision-Language-Action Models in Autonomous Driving
arXiv:2608.13395v1 Announce Type: new Abstract: Reinforcement learning improves autonomous-driving vision-language-action (VLA) models by evaluating trajectorie…
Capstan-driven Continuum Surgical Robot: Design, Modeling, and Perception
arXiv:2608.13396v1 Announce Type: new Abstract: Shape and force sensing have long been critical bottlenecks in the development of compact capstan-driven continu…
Deliberate Practice: Learning Robot Skills under a Budget
arXiv:2608.13415v1 Announce Type: new Abstract: We consider the problem of autonomously learning robot skills under a limited practice budget for sequential tas…
ContactGuard: Pre-Contact Execution Monitoring with Action-Conditioned Latent World Models
arXiv:2608.13438v1 Announce Type: new Abstract: Contact-rich manipulation failures are often detected only after the robot has committed to contact. This is esp…
Mind the Context: Continual Learning of Socially Appropriate Robot Actions via Environmental-Social Disentanglement
arXiv:2608.13448v1 Announce Type: new Abstract: Social robots are expected to operate across diverse environments, where similar arrangements can imply differen…
HumanTracker: Towards Comprehensive and Human-Aligned Motion Tracking Benchmark
arXiv:2608.13555v1 Announce Type: new Abstract: Humanoid motion tracking is central to teleoperation and whole-body imitation, yet evaluation often disagrees wi…
Can Vision-Language Models Assess Proxemic Risk from Egocentric Robot Images?
arXiv:2608.12515v1 Announce Type: cross Abstract: Assessing proxemic danger from a robot's egocentric perspective is critical for safe embodied navigation in hu…