News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesFrom Continuous Design to Delay-Aware Discrete Synthesis: Guaranteed High-Bandwidth Joint Control for PMSM Drives
arXiv:2608.14937v1 Announce Type: new Abstract: The increasing dynamic demands of modern robotic joints require current controllers to achieve high bandwidth ov…
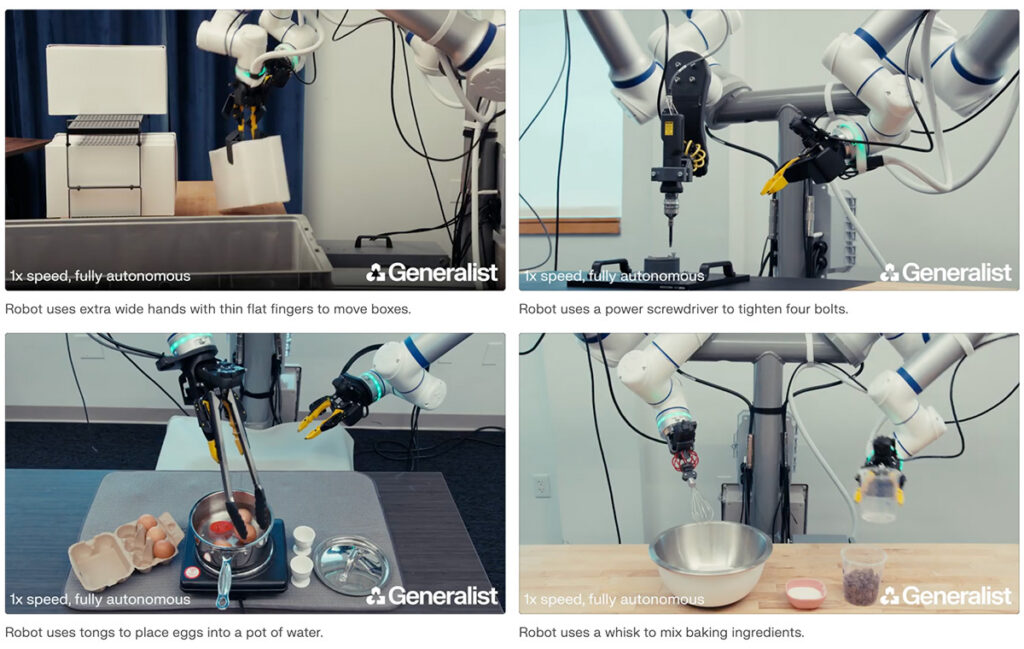
How Generalist uses human demonstration data for robot learning
Research around the Universal Manipulation Interface is enabling Generalist, Walden Robotics, and others to turn data into robot behaviors. The post How General…
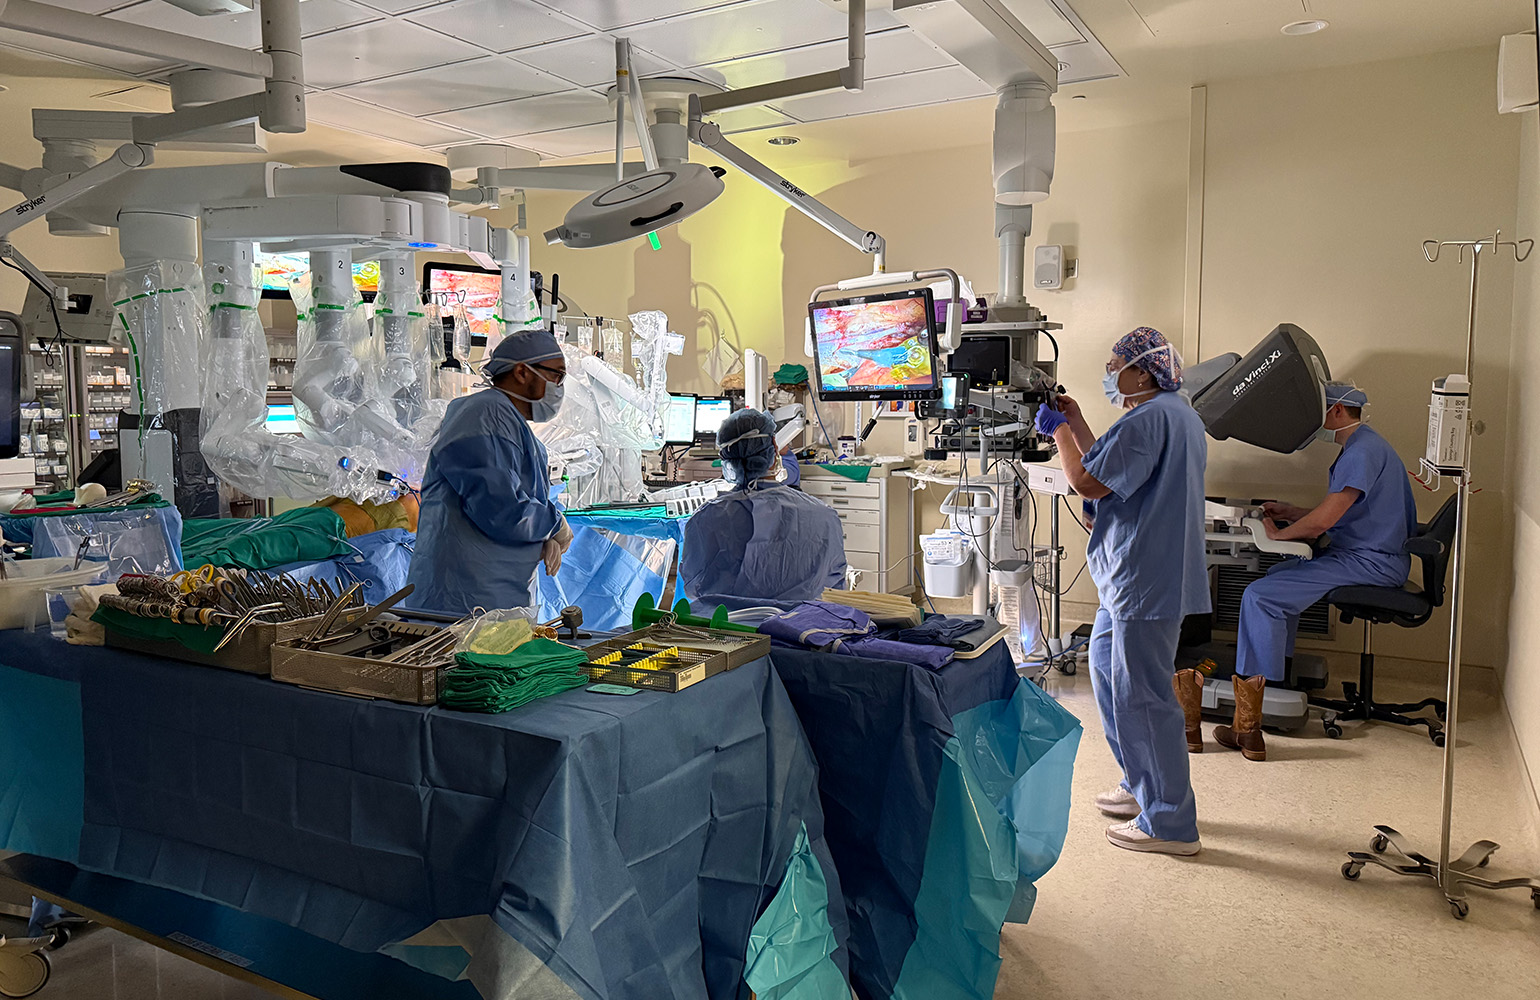
Surgeons use da Vinci surgical robot to perform common cardiac surgery
At the El Camino Health Heart and Vascular Institute, surgeons are now performing cardiac procedures with Intuitive's da Vinci robot. The post Surgeons use da V…
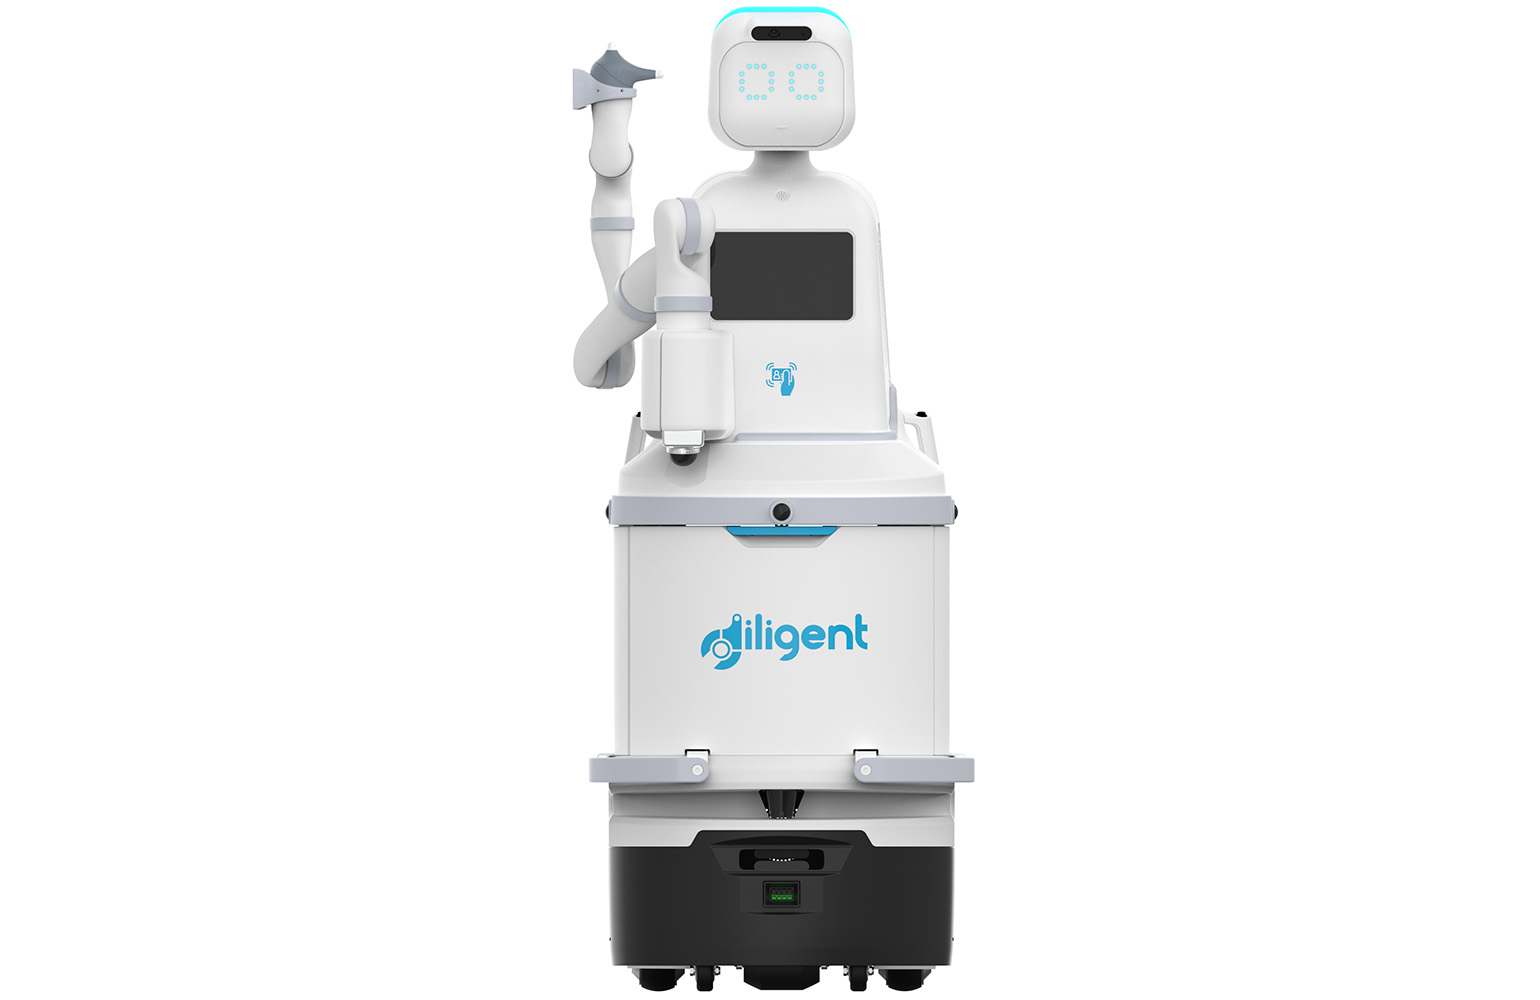
Five years of operation shape Diligent Robotics rollout of Moxi 2.0
Diligent is now rolling out Moxi 2.0 to health systems including Endeavor Health Edward Hospital and Children’s Hospital Los Angeles. The post Five years of ope…
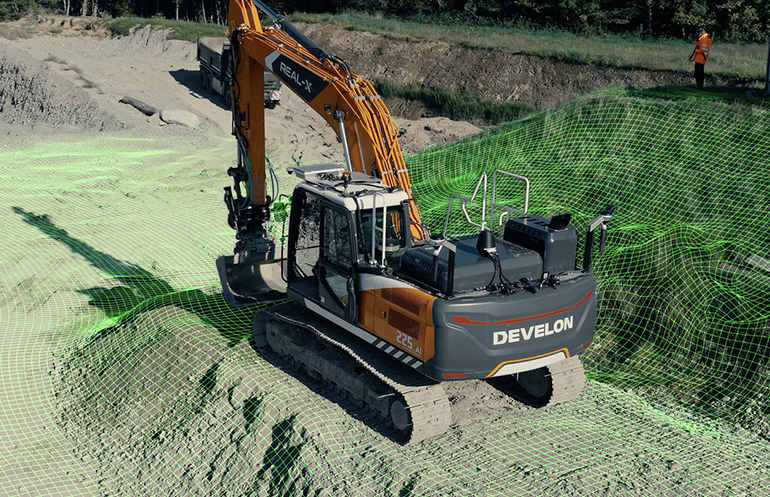
Gravis Robotics raises $200M for autonomous construction
Gravis Robotics has designed autonomy AI and hardware for a wide range of excavators and construction equipment and plans to scale globally. The post Gravis Rob…
Intermittent swimming promotes the energy efficiency of fish-like robot movements
Image credits: Xiangxiao Liu, Francois A. Longchamp, and Louis GeverBiorobotics Laboratory, EPFL Improving energy performance can effectively extend the time a …
Scientists turn DNA into a memory device that uses 100x less power
Researchers combined synthetic DNA with a semiconductor to create an ultra-low-power memory device capable of storing and processing information in the same pla…
Coverage Aware Active Evaluation for Failure Discovery with Paired Systems
arXiv:2608.13719v1 Announce Type: cross Abstract: Autonomous systems can fail in rare and heterogeneous ways, making real-world failure discovery difficult unde…
MorphIt: Flexible Spherical Approximation of Robot Morphology for Representation-driven Adaptation
arXiv:2507.14061v3 Announce Type: replace Abstract: What if a robot could rethink its own morphological representation to better meet the demands of diverse tas…
AtomBridge: Agentic VLA Inference Plugin for Long-Horizon Tasks in Scientific Experiments
arXiv:2602.09430v2 Announce Type: replace Abstract: Robotic laboratories play a critical role in autonomous scientific discovery by enabling scalable, continuou…
CoViLLM: An Adaptive Human-Robot Collaborative Assembly Framework Using Large Language Models
arXiv:2603.11461v3 Announce Type: replace Abstract: With increasing demand for mass customization, traditional manufacturing robots that rely on rule-based oper…
How to Relieve Distribution Shifts in Semantic Segmentation for Off-Road Environments
arXiv:2605.29599v2 Announce Type: replace Abstract: Semantic segmentation is crucial for autonomous navigation in off-road environments, enabling precise classi…
HierDAMap: Towards Universal Domain Adaptive BEV Mapping via Hierarchical Perspective Priors
arXiv:2503.06821v2 Announce Type: replace-cross Abstract: The exploration of Bird's-Eye View (BEV) mapping technology has driven significant innovation in visua…
Versatile Exoskeleton Control Supports Elderly Joint Energetics During Hip-Intensive Tasks
arXiv:2603.22580v2 Announce Type: replace Abstract: Age-related mobility decline is frequently accompanied by a redistribution of joint kinetics, where older ad…
Active Perception for Embodied Disambiguation
arXiv:2608.13605v1 Announce Type: cross Abstract: Natural language provides robots with a flexible task interface, but target ambiguity in embodied environments…
Ensuring Safe Physical AI in Urban Mobility via Hazard-Informed Synthesized Envelopes
arXiv:2608.14481v1 Announce Type: new Abstract: As heterogeneous robotic systems deploy across diverse urban zones, maintaining safety amid complex human-robot …
Effect of Twisted-Yarn Architecture on Pressure and Proximity Sensing Characteristics of Textile Capacitive Sensors for Robotic Skin
arXiv:2608.14406v1 Announce Type: new Abstract: Textile-integrated capacitive sensors offer flexible and conformable tactile sensing for wearable electronics an…
Reflex: Enabling Fast and Predictive Vision-Language-Action Models for Reaction-Critical Manipulation
arXiv:2608.14379v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have recently achieved promising performance in robotic manipulation. Howeve…
CORAL: Curriculum-Optimized Reward Adaptation for LiDAR-Based Goal-Directed Urban Driving
arXiv:2608.14332v1 Announce Type: new Abstract: Reinforcement learning is promising for autonomous urban driving, but long-horizon goal-directed navigation asks…
Evolve Vision-Language-Action Model into an Agent with On-the-fly Tool-use
arXiv:2608.14047v1 Announce Type: new Abstract: This paper integrates end-to-end Visual-Language-Action (VLA) models with agentic tool-use to propose Agentic Ro…
AdvDex: Learning Dexterous Manipulation from Human Demonstrations via Joint-Aligned Actions and Adversarial Learning
arXiv:2608.14028v1 Announce Type: new Abstract: Dexterous manipulation is a fundamental capability for embodied intelligence, but scaling it remains difficult b…
Communication in modular robotic motor control: Bilateral controllers under realistic constraints
arXiv:2608.13904v1 Announce Type: new Abstract: Robotic motor control in musculoskeletal systems requires fast, accurate movement and robust postural stabilizat…
Ontology-Grounded World Models for Failure Diagnosis and Closed-Loop Repair in Physical AI Systems
arXiv:2608.13901v1 Announce Type: new Abstract: EV-WM represents candidate quality with feature and event scores, but these scores do not explicitly record an u…
LatentAM: Real-Time, Large-Scale Latent Gaussian Attention Mapping via Online Dictionary Learning
arXiv:2602.12314v2 Announce Type: replace Abstract: We present LatentAM, an online 3D Gaussian Splatting (3DGS) mapping framework that builds scalable latent fe…
A Temporal Barrier Framework for Collision Avoidance in Multi-Agent Autonomous Aerial Vehicles
arXiv:2608.14239v1 Announce Type: cross Abstract: Operating teams of autonomous aircraft in dynamic, uncertain, and potentially adversarial environments require…
Estimating Dynamic Soft Continuum Robot States From Boundaries
arXiv:2505.04491v3 Announce Type: replace Abstract: State estimation is one of the fundamental problems in robotics. For soft continuum robots, this task is par…
Reward Machines for Signal Temporal Logic
arXiv:2608.13625v1 Announce Type: cross Abstract: Signal temporal logic (STL) provides a formal language for specifying real-time properties of real-valued obse…
THRIVE: Therapeutic Humanoid Robot In Virtual Environment
arXiv:2608.14462v1 Announce Type: new Abstract: This paper presents THRIVE (Therapeutic Humanoid Robot In Virtual Environment), an at-home rehabilitation platfo…
PRM-as-a-Judge 1.5: A Toolkit for Robot Process Assessment
arXiv:2608.14284v1 Announce Type: new Abstract: Fine-grained robotic evaluation matters for understanding embodied models, going beyond binary success rates and…
AgilePE: Autonomous UAV Pursuit-Evasion via Self-Play Reinforcement Learning
arXiv:2608.14135v1 Announce Type: new Abstract: Autonomous pursuit-evasion is a fundamental challenge for Unmanned Aerial Vehicles (UAVs), requiring rapid decis…