Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 stories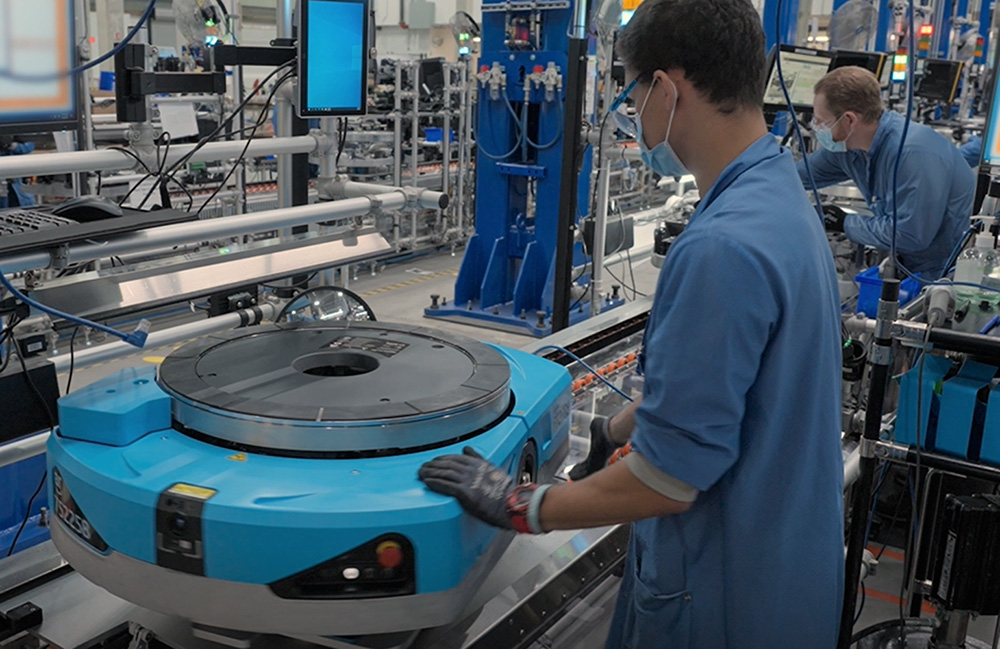
Amazon to invest $100M in new Indiana manufacturing facility
The new facility will produce products that power Amazon's fulfillment and robotics network across North America. The post Amazon to invest $100M in new Indiana…
Morphometric Imitation: From Morphology and Contact Aware Hand Retargeting to Sim-to-Real Visuomotor Policy
arXiv:2609.28660v1 Announce Type: new Abstract: Human hand-object interactions (HOIs) provide a rich source of demonstrations for dexterous manipulation, but le…
Human-in-the-Loop Geospatial Annotation for Rapid Dataset Construction in Field-Deployed UAV Systems
arXiv:2609.28767v1 Announce Type: new Abstract: Real-world perception systems must adapt to changing environments, but manual image annotation cannot scale to f…
Uncertainty-Gated Exploration Noise Suppresses Task Collapse in Online RL Fine-Tuning of a Flow-Matching Vision-Language-Action Policy
arXiv:2609.28838v1 Announce Type: new Abstract: Online reinforcement learning fine-tuning of pretrained flow-matching vision-language-action (VLA) policies prom…
DAWN: Noise-Robust Quadruped Parkour via Depth-Denoising World Models
arXiv:2609.29092v1 Announce Type: new Abstract: Vision-based legged locomotion methods assume clean depth at training time and rely on hand-tuned post-processin…
A Simple Gripper Interface for Simulator-Agnostic Cloth Manipulation
arXiv:2609.29340v1 Announce Type: new Abstract: This paper presents a grasping model for cloth manipulation specifically tailored to ease the deployment of robo…
RACaP: Agentic Reasoning, Acting, and Coding as Policies for Evolvable Robot Learning
arXiv:2609.29394v1 Announce Type: new Abstract: General-purpose robot agents must learn from experience, transfer to new tasks, and act efficiently. Code as Pol…
WRAP: Fixtureless Wrench-aware Multi-Robot Assembly Planning
arXiv:2609.29407v1 Announce Type: new Abstract: Assembly using robots often requires specially designed fixtures, or relies on top-down only assembly strategies…
Markerless Multi-Modal Autonomous Robotic Inspection of Large Space Structures
arXiv:2609.29644v1 Announce Type: new Abstract: Future orbital infrastructures, such as deployable antennas, solar farms, and large orbital platforms will requi…
Self-Adaptive VLA for Robust Robot Deployment
arXiv:2609.30092v1 Announce Type: new Abstract: While Vision-Language-Action (VLA) models demonstrate impressive capabilities in robotic manipulation, their mem…
ReVAMP: Vector-Accelerated Motion Planning for Kinematically-Constrained Systems via Reparameterization
arXiv:2609.30213v1 Announce Type: new Abstract: Robots often must satisfy one or more constraints during motion planning for real-world tasks. When such constra…
GenPHRI: Agentic Generative Simulation for Physical Human-Robot Interaction
arXiv:2604.08664v2 Announce Type: replace Abstract: Real-world physical human-robot interaction (pHRI) development is costly and slow, while simulation requires…
TRACE: Interactive Bi-Directional Tracing of Monochrome Cables Amid Clutter
arXiv:2609.29103v1 Announce Type: new Abstract: Accurate state estimation (tracing) of Deformable Linear Objects (DLOs) such as cables is a critical challenge f…
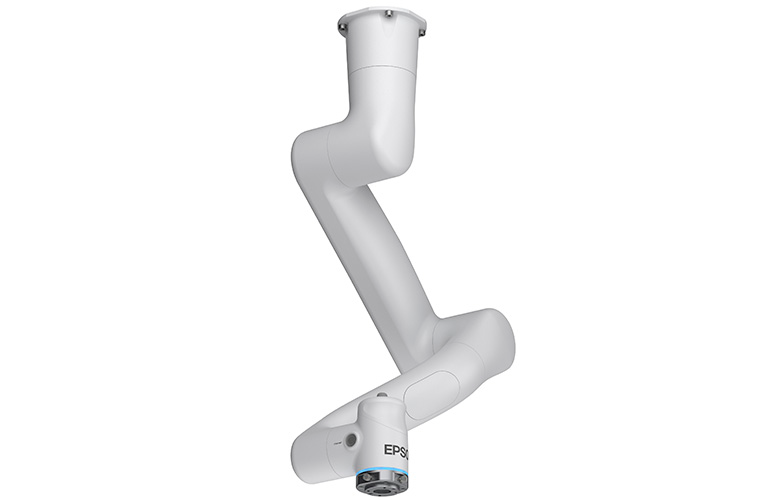
Epson introduces AX6 cobot with compact design, no-code programming
Epson Robots has expanded its six-axis robot line with the AX6, a lightweight force- and power-limited arm. The post Epson introduces AX6 cobot with compact des…
Fine Wrist Control as a Marker of Surgical Teleoperation Expertise
arXiv:2609.27160v1 Announce Type: new Abstract: Unlike most intensely physical pursuits, surgical robotic teleoperation training focuses primarily on task outco…
Learning Dissipative Dynamics with Dissipativity-by-Construction Discrete-Time Neural Networks
arXiv:2609.27188v1 Announce Type: new Abstract: Dissipativity is a fundamental system-theoretic property closely related to stability, passivity, and input--out…
Gray-Box Model Predictive Control for Articulated Dump Trucks via Gaussian Process Learning of Sideslip
arXiv:2609.27597v1 Announce Type: new Abstract: The growing demand for automation in the mining industry, particularly for the autonomous operation of articulat…
Generalizable Robotic Insertion with World Models
arXiv:2609.28258v1 Announce Type: new Abstract: Robotic assembly in high-mixture settings requires adaptable systems that can handle diverse parts, yet current …
Surgical Kinematics from Monocular Video with Learned Articulated Motion Constraints
arXiv:2609.27227v1 Announce Type: cross Abstract: Objective assessment of robotic surgery uses instrument kinematics, which must be reconstructed when only vide…
Lend me an Ear: Speech Enhancement Using a Robotic Arm with a Microphone Array
arXiv:2602.17818v2 Announce Type: replace Abstract: Speech enhancement performance degrades significantly in noisy environments, limiting the deployment of spee…
SlackDrive: Reclaiming Runtime Slack for Adaptive Driving Inference
arXiv:2609.28064v1 Announce Type: cross Abstract: Driving world-action models improve planning by coupling multimodal reasoning with future prediction, but thei…
Multimodal Voice Activity Projection for Social Robot Mediation: Expected Behavior and Deployment Constraints
arXiv:2609.28317v1 Announce Type: new Abstract: Turn-taking prediction is especially relevant for social robots that act as mediators in human-human interaction…
BrickCraft-Duo: Efficient Dual-Arm Skill Learning and Refinement for Compositional Long-Horizon Assembly
arXiv:2609.28281v1 Announce Type: new Abstract: Interlocking brick assembly provides a representative testbed for evaluating real-world robotic manipulation cap…
Helicon brings automation to high-volume composites manufacturing
Helicon has obtained seed funding to use automation to cut composite manufacturing lead times from months to weeks. The post Helicon brings automation to high-v…

Robotics roadmaps from around the world spotlight of the month: China
China is targeting the next industrial revolution by doubling down on embodied AI and humanoid robotics, building directly on its vast manufacturing infrastruct…
Wheel-loader V-Cycle Automation with Deep Koopman MPC
arXiv:2609.26580v1 Announce Type: new Abstract: The repeated forward-reverse maneuvers performed by wheel loaders during earthmoving operations make them well s…
Leveraging Vision-Based Point Cloud Map Priors for Camera-Based 3D Object Detection and Online Vectorized HD Mapping
arXiv:2609.26325v1 Announce Type: cross Abstract: Camera-based 3D object detection and online vectorized HD mapping provide compact scene representations for au…
MicroPush: A Lightweight Simulator for Sim-to-Real Microrobotic Pushing and Assembly
arXiv:2602.23607v2 Announce Type: replace Abstract: Developing learning-based autonomy for microrobotic manipulation is difficult because physical trials are sl…
Manipulation of Deformable Linear Objects Using Model Predictive Path Integral Control with Bidirectional Long Short-Term Memory Learning
arXiv:2609.26238v1 Announce Type: new Abstract: The manipulation of Deformable Linear Objects (DLOs) such as cables poses a significant challenge for automation…
Learning from Humans for Proactive Assistance in Human-Robot Collaborative Transport
arXiv:2609.25351v1 Announce Type: new Abstract: We focus on human-robot collaborative transport, a challenging task of broad relevance spanning logistics, manuf…