News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesInfluence of Operator Expertise on Robot Supervision and Intervention
arXiv:2601.15069v2 Announce Type: replace Abstract: With increasing levels of robot autonomy, robots are increasingly being supervised by users with varying lev…
Injecting Hallucinations in Autonomous Vehicles: A Component-Agnostic Safety Evaluation Framework
arXiv:2510.07749v2 Announce Type: replace Abstract: Perception failures in autonomous vehicles (AV) remain a major safety concern because they are the basis for…
Whole-Body Planning for Humanoids Navigating Confined Spaces via Self-Collision Avoidance References
arXiv:2608.10220v1 Announce Type: new Abstract: Humanoid locomotion in highly confined environments requires navigating dense environmental obstacles and comple…
Real-World Cooperative Bimanual Dexterous Grasp of Large Objects from Single-View Observations
arXiv:2608.10383v1 Announce Type: new Abstract: Bimanual dexterous grasping of large objects is a critical challenge in robotic manipulation. However, most exis…
Nonlinear Model Predictive Control via Sequential Convex Programming for Drone-to-Drone Docking
arXiv:2608.10542v1 Announce Type: new Abstract: Autonomous mid-air docking of multi-rotor vehicles under disturbance-driven target motion poses a constrained no…
BooST: Bridging Semantics and Motions for Efficient Skill Transfer
arXiv:2608.10600v1 Announce Type: new Abstract: Skill abstraction---the process of learning reusable and temporally extended behaviors---has emerged as a key pa…
Toward the Cognitive--Physical Limits of Embodied Intelligence through a World-Model-Centric Autonomous Racing Agent
arXiv:2608.10618v1 Announce Type: new Abstract: Embodied artificial intelligence aims to develop agents that perceive, reason, and act through continuous intera…
OAA: Three Phases of Vocal Guidance in Human-Drone Teleoperation
arXiv:2608.10651v1 Announce Type: new Abstract: Voice-guided teleoperation requires systems that adapt to the evolving dynamics of human guidance. Yet most voic…
Dreamer-SAC: Off-Policy Learning in Latent World Models for Sample-Efficient Autonomous Driving
arXiv:2608.10386v1 Announce Type: cross Abstract: Sample-efficient reinforcement learning for autonomous driving is often limited by the trade-off between data …
Hidden in Plain Sight: Diffusion-Based Unrestricted Robotic Attacks on Vision-Language-Action Models
arXiv:2608.10393v1 Announce Type: cross Abstract: Vision-Language-Action (VLA) models have shown strong capabilities in controlling robots across diverse manipu…
Automatic Field-of-View Adjustment for a View-Expansive Microscope via LSTM-Based Gaze and Pipette Motion Interpretation
arXiv:2608.10401v1 Announce Type: cross Abstract: Intracytoplasmic sperm injection (ICSI) operators frequently adjust the field-of-view (FOV) during procedures,…
Deployment Is Not Destiny: Robot Recomposition in the Field with Unseen Software, Hardware, and Compute Payloads
arXiv:2608.11063v1 Announce Type: new Abstract: The tight coupling of subsystems in most robots, though a natural consequence of their complexity, leads to mono…
JEPA-WAM: Stage-Level Joint-Embedding Prediction for World-Action Models in Robot Manipulation
arXiv:2608.10780v1 Announce Type: new Abstract: Generalist robot policies aim to map multimodal observations and linguistic task instructions to actions across …
TCAM for Autonomous Deformable Manipulation: The RMC2 Champion System for WBCD 2026 Track 4
arXiv:2608.10718v1 Announce Type: new Abstract: This technical report describes the RMC2 Team's champion solution for the WBCD 2026 Track 4: Deformable Manipula…
A 26-Gram Tailless Butterfly-Inspired Flapping-Wing Robot with Onboard Attitude Control
arXiv:2602.06811v3 Announce Type: replace Abstract: Butterfly-inspired flapping-wing robots use broad compliant wings and low-frequency actuation, but pronounce…
Multisource Human-in-the-Loop Digital Twin Testbed for Connected and Autonomous Vehicles in Mixed Traffic Flow
arXiv:2603.17751v5 Announce Type: replace Abstract: In the emerging mixed traffic environments, Connected and Autonomous Vehicles (CAVs) have to interact with s…

Defense drone developer Cambridge Aerospace raises $300M
The round comes just months after the Cambridge Aerospace's $200 million Series B funding in April. The post Defense drone developer Cambridge Aerospace raises …
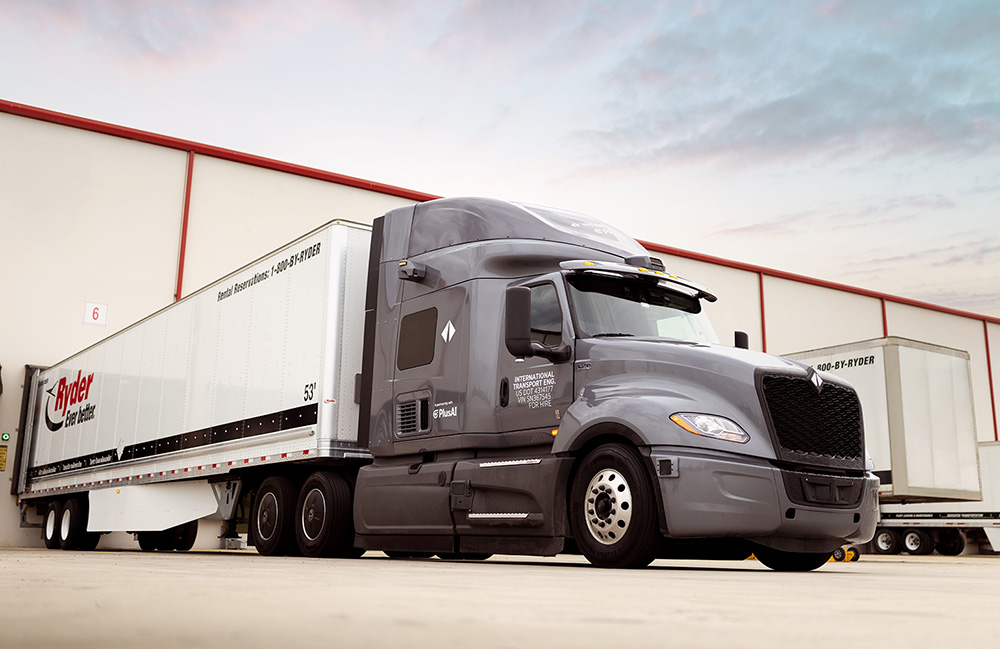
PlusAI reaches key milestones ahead of launching its autonomous trucks
Since the start of the year, PlusAI said it has improved the safety validation, operational maturity, and efficiency of SuperDrive. The post PlusAI reaches key …
The 370-billion-dollar race: How integrated design can help humanoid manufacturers succeed in a rapidly growing market
The future of humanoid robotics is closer than most people realize. The post The 370-billion-dollar race: How integrated design can help humanoid manufacturers …
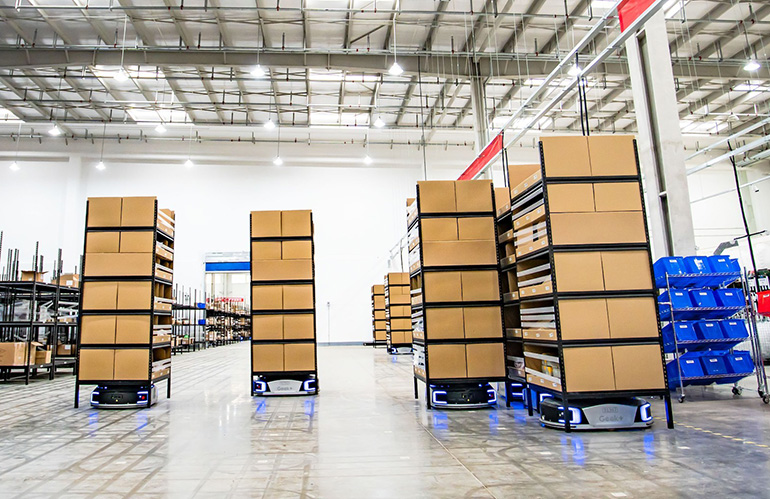
Webinar to discuss safety and scaling robot fleets in the warehouse
Industry experts will discuss how to scale mobile robots in the warehouse while maintaining both safety and productivity. The post Webinar to discuss safety and…
Generalizing deep reinforcement learning across cable-driven parallel robot configurations with actuator-level policies
arXiv:2608.07546v1 Announce Type: new Abstract: Cable-driven parallel robots (CDPRs) present diverse configurations and complex control challenges, which can be…
Self Supervised Learning from Automatically Generated Demonstrations for Visual Robotic Manipulation
arXiv:2608.07553v1 Announce Type: new Abstract: Robotic manipulation often requires object specific programming, manual data annotation, or calibrated perceptio…
You Don't Need To Stay in The Loop: An Agentic Robotics Loop for Robot-Policy Improvement
arXiv:2608.07555v1 Announce Type: new Abstract: Coding agents such as Claude Code and Codex close the software loop: a main agent manages the loop, subagents an…
Learning Physical Interaction: A Survey of Tactile- and Force-aware Robot Learning
arXiv:2608.07558v1 Announce Type: new Abstract: Physically grounded robot intelligence requires robots to perceive, reason about, and regulate their interaction…
Reconfigurable Structural Robotic Assembly: Interlocking 3D Aggregations with Self-Aligning Compound Nested Lattice Modules
arXiv:2608.07576v1 Announce Type: new Abstract: Robotic construction systems often treat the material system and the robot as separate design problems, locating…
LIRA: Local Cross-Layer Information Routing for Vision-Language-Action Decoding
arXiv:2608.07596v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models transform representations from pretrained vision-language models (VLMs) into…
AdaDexGrasp: Adaptive Dexterous Grasping via 3D Visuo-Tactile Representation Fusion
arXiv:2608.07600v1 Announce Type: new Abstract: Humans achieve stable and adaptive grasps by seamlessly integrating visual perception and tactile feedback, a ca…
A Reconfigurable Tracked Robot for Enhanced Obstacle Traversal Through Movable Articulation Point and Internal Mass Relocation
arXiv:2608.07624v1 Announce Type: new Abstract: Tracked robots are widely used in unstructured environments; however, their obstacle traversal capability is fun…
H\"older Signed Distance: A Differentiable, Signed, Parallelizable Metric for Robotics
arXiv:2608.07707v1 Announce Type: new Abstract: Computing distances between sets is essential in robotic motion planning and control, where differentiable gradi…
Complete, Scalable, and Robust Prioritized Planning for Multi-Robot Ordered Storage and Retrieval at Maximum Capacity
arXiv:2608.07734v1 Announce Type: new Abstract: Automated warehouses face a fundamental trade-off between maximizing storage density and achieving high retrieva…