News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesHiTac-WAM: A Hierarchical Tactile World Action Model for Contact-Rich Robot Manipulation
arXiv:2608.19574v1 Announce Type: new Abstract: World action models jointly predict future visual observations and actions, whereas existing tactile-aware varia…
Multimodal Trajectory Planning for Surface Vehicles using Turning Circle-based Control Barrier Functions
arXiv:2608.19537v1 Announce Type: new Abstract: This paper presents a guide path-free multimodal trajectory planning framework for autonomous surface vehicles o…
Learning the Right Abstraction: Neural Reduced Dynamics for Complex Robot Control
arXiv:2608.19375v1 Announce Type: new Abstract: High-fidelity embodied AI simulators provide realistic evaluation of complex robotic systems, but their computat…
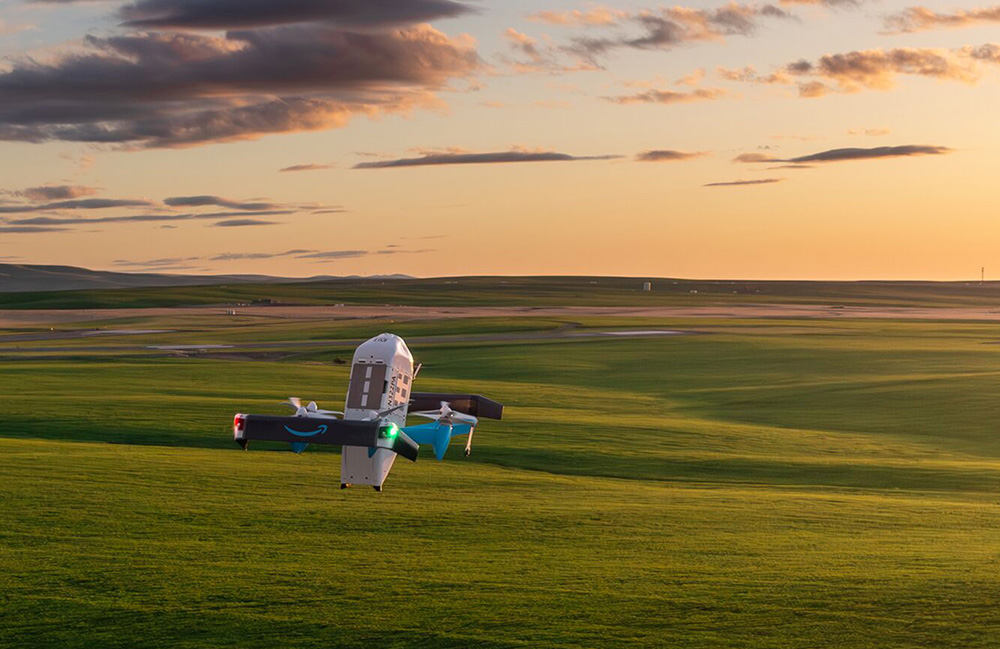
Amazon plans to expand Prime Air to nearly 500 cities by the end of 2026
Amazon said its Prime Air drones can deliver nearly all items 5 lb. or less that can fit in a large shoebox. The post Amazon plans to expand Prime Air to nearly…
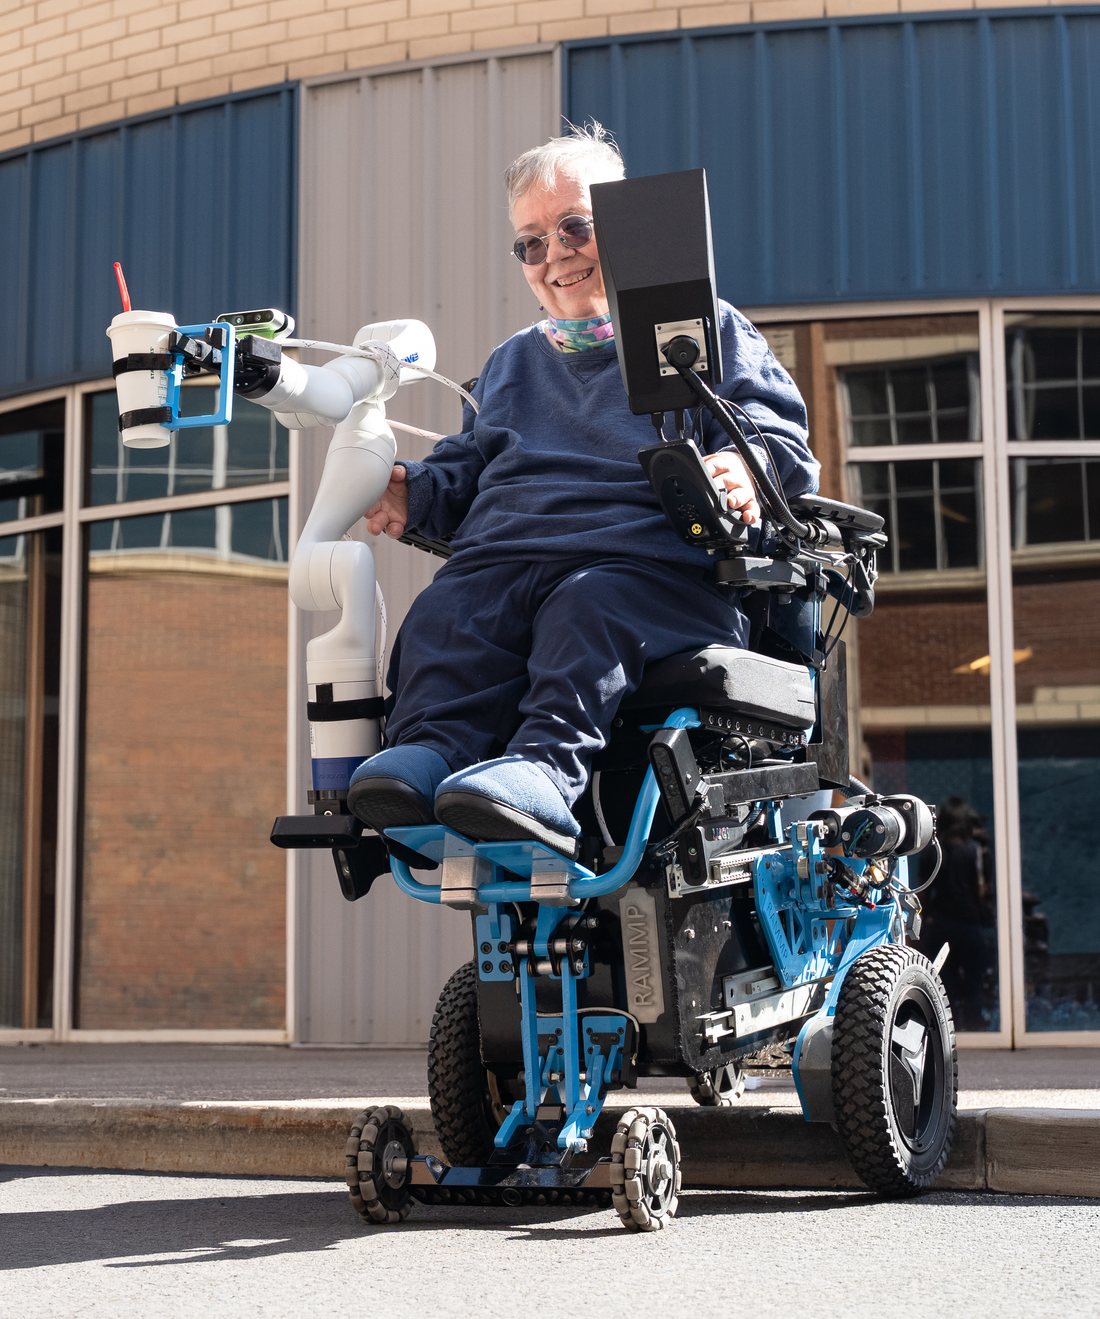
ATDev gives update on its journey building autonomous wheelchairs
ATDev is developing a modern power wheelchair with a coordinated robotic arm that can take on reaching and lifting tasks for the user. The post ATDev gives upda…
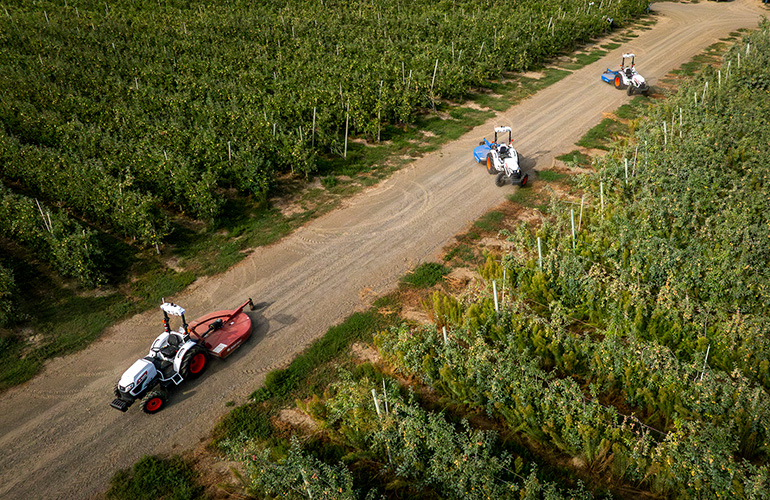
Agtonomy releases new autonomous multi-point turning features
Agtonomy has added autonomous multi-point turning and enhanced field data collection to its commercial off-road platform. The post Agtonomy releases new autonom…
Revisiting the "Push-T" Robot Manipulation Task with Agentic Robotics
arXiv:2608.18227v1 Announce Type: new Abstract: Push-T is an iconic benchmark for learning manipulation policies from human demonstrations. The robot must use a…
GigaBrain-WBC-0.5: A Behavior World Model for Robust Whole-Body Control with Environment Interaction
arXiv:2608.18234v1 Announce Type: new Abstract: Whole-body motion tracking policies turn a humanoid into a robust control interface: the teleoperator---or an up…
VERAGMIL: Virtual Environment for Scooping Granular Foods with Imitation Learning Models
arXiv:2608.18258v1 Announce Type: new Abstract: Robot-Assisted Feeding (RAF) systems are essential for assisting individuals with disabilities or motor impairme…
Backward Layout Search for Sequence-Constrained Robotic Assembly
arXiv:2608.18454v1 Announce Type: new Abstract: Robotic assembly layout planning must determine the assembly site and the initial pose of each part while ensuri…
Beyond Placement and Articulation: Usage-Driven Code Scenes for Embodied Interaction
arXiv:2608.18840v1 Announce Type: new Abstract: Indoor scene synthesis provides essential environments for embodied AI, robotic manipulation, and simulation-bas…
Autonomous Agricultural Tractor: Integrated Weed Detection and LiDAR Navigation for Precision Paddy Farming
arXiv:2608.19004v1 Announce Type: new Abstract: Site-specific weed management in paddy farming offers substantial reductions in herbicide use over conventional …
A Metamorphic Artificial Age Score Decision-Support Prototype for Flight-Log-Based Drone Propeller Health Monitoring
arXiv:2608.18088v1 Announce Type: cross Abstract: Drone propeller faults can create safety and reliability risks when their effects are distributed across multi…
Dynamic SpectraFormer for Ultra-High-Definition Underwater Image Enhancement
arXiv:2608.18662v1 Announce Type: cross Abstract: Underwater images suffer from color distortion, haze, and poor visibility due to light refraction and absorpti…
To Go Far, Go Together: Diverse Preferences Induce a Curriculum for Reward Optimization
arXiv:2608.18770v1 Announce Type: cross Abstract: Learning a reward model from human feedback and optimizing a policy against it is one approach to aligning AI …
Counterfactual Behavior Cloning: Offline Imitation Learning from Imperfect Human Demonstrations
arXiv:2505.10760v2 Announce Type: replace Abstract: Learning from humans is challenging because people are imperfect teachers. When everyday humans show the rob…
Personalized Autonomous Driving via Optimal Control with Clearance Constraints from Questionnaires
arXiv:2602.08326v2 Announce Type: replace Abstract: Driving without considering the preferred separation distance from surrounding vehicles may cause discomfort…
WESPR: Wind-adaptive Energy-Efficient Safe Perception & Planning for Robust Flight with Quadrotors
arXiv:2603.09194v2 Announce Type: replace Abstract: Local wind conditions strongly influence drone performance: headwinds increase flight time, crosswinds and w…
PartialBiGrasp: Inferring Hidden Local Geometry for Bimanual Grasping from Partial Views
arXiv:2608.19188v1 Announce Type: new Abstract: Dual-arm robotic grasping is essential for manipulating large, heavy, and geometrically complex objects that can…
ADEPT: Accelerating Dexterity via Pre-Training and Post-Training using Reinforcement Learning
arXiv:2608.19182v1 Announce Type: new Abstract: We introduce Accelerating Dexterity via Pre-Training (ADEPT), a large-scale reinforcement learning (RL) framewor…
DA-WAM: Decision-Aligned Future Latents for Driving World Models
arXiv:2608.19085v1 Announce Type: new Abstract: Anticipating how scenes evolve under ego actions is fundamental to safe autonomous driving, yet the full potenti…
DevGRU: Depth-guided Visual Navigation using a Collision-aware Recurrent Model
arXiv:2608.18470v1 Announce Type: new Abstract: Existing visual navigation models often aim to develop foundation models that can generalize robot navigation ac…
HarvestPoint-ACT: Explicit Target Selection and Harvest-Point Conditioning for Robotic Fruit Harvesting under Occlusion
arXiv:2608.18446v1 Announce Type: new Abstract: End-to-end imitation learning avoids hand-made robot motion for approaching and grasping, but the policy must st…
The Embodiment Gap in Robot Foundation Models
arXiv:2608.18433v1 Announce Type: new Abstract: Robot foundation models (RFMs), including vision-language-action (VLA) policies, are often discussed through a s…
GuideFetch: A Task Coordination Framework for Concurrent Navigation and Object Retrieval in Assistive Robot Dogs
arXiv:2608.18292v1 Announce Type: new Abstract: Consider a robot guide dog escorting a blind user to an available seat while a second assistive robot dog concur…
Engineering Psychological Safety in Autonomous Vehicles: A Systems-Theoretic Framework for Psychological Safety in Autonomous Vehicles and its Validation in Real-World Scenarios
arXiv:2608.18778v1 Announce Type: cross Abstract: Despite rapid technological advances, the societal acceptability of autonomous vehicles (AVs) remains limited …
LT-Mem: Volatility-Aware Spatio-Temporal Memory for Lifelong Scene Understanding
arXiv:2608.19059v1 Announce Type: new Abstract: Long-term robot operation in evolving environments requires object-level understanding that persists across repe…
RoboEdit: Turning Human Manipulation Videos into Scalable Robot Experience
arXiv:2608.18948v1 Announce Type: new Abstract: Collecting robot hand-object interaction data is costly and embodiment-specific, yet abundant human-object video…
Dream2Reward: Transition-Alignment Reward Models from Positive Demonstrations for Robotic Manipulation
arXiv:2608.18787v1 Announce Type: new Abstract: Learning robotic policies requires dense rewards that remain informative when behavior departs from successful d…
Progressive Experience Fusion for Multi-Task World Model Control in Endovascular Navigation
arXiv:2608.18647v1 Announce Type: new Abstract: Autonomous endovascular navigation could support the delivery of mechanical thrombectomy to underserved areas, b…