News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesLabDex: A Hierarchical Benchmark for Dexterous Manipulation in Laboratories
arXiv:2608.18618v1 Announce Type: new Abstract: Autonomous laboratories hold great promise for accelerating scientific discovery. To achieve this vision, robots…
Transferable Tool-Tissue Contact Detection from Stereo Depth in Robot-Assisted Surgery
arXiv:2608.18270v1 Announce Type: new Abstract: Reliable tool--tissue contact detection can support interaction-aware control and downstream force estimation in…
GAPL: Grounded Action-effect Policy Learning for LLM-Based Trajectory Planning
arXiv:2608.18254v1 Announce Type: new Abstract: Trajectory planning for autonomous driving requires both high-level reasoning and precise low-level control. Lar…
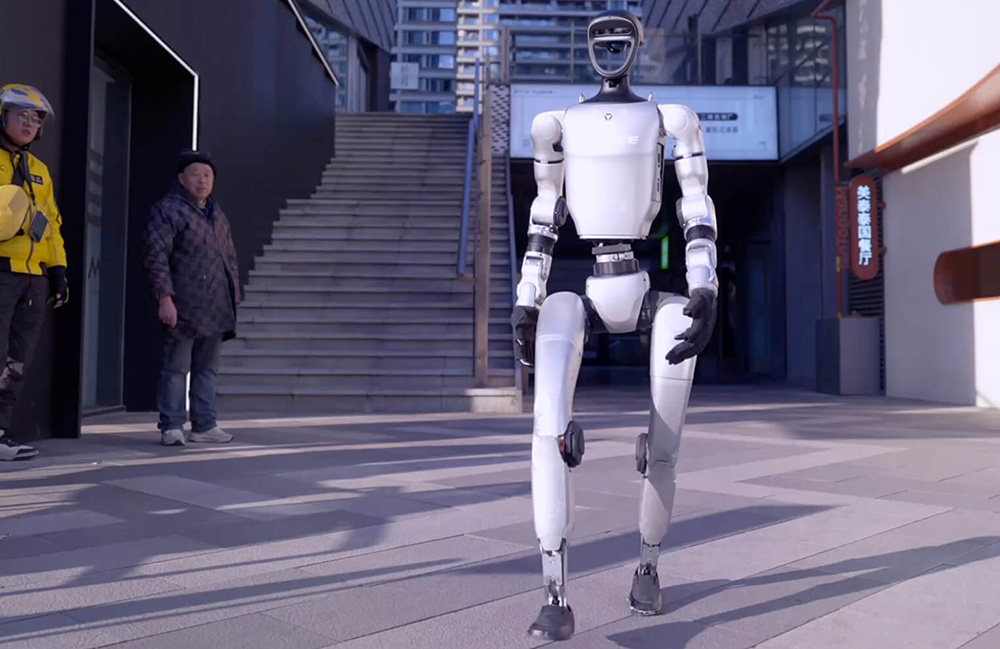
What does Unitree Robotics’ IPO mean for the humanoid industry?
Now that Unitree Robotics has made its IPO, which humanoid robotics companies will follow in its footsteps? The post What does Unitree Robotics’ IPO mean …
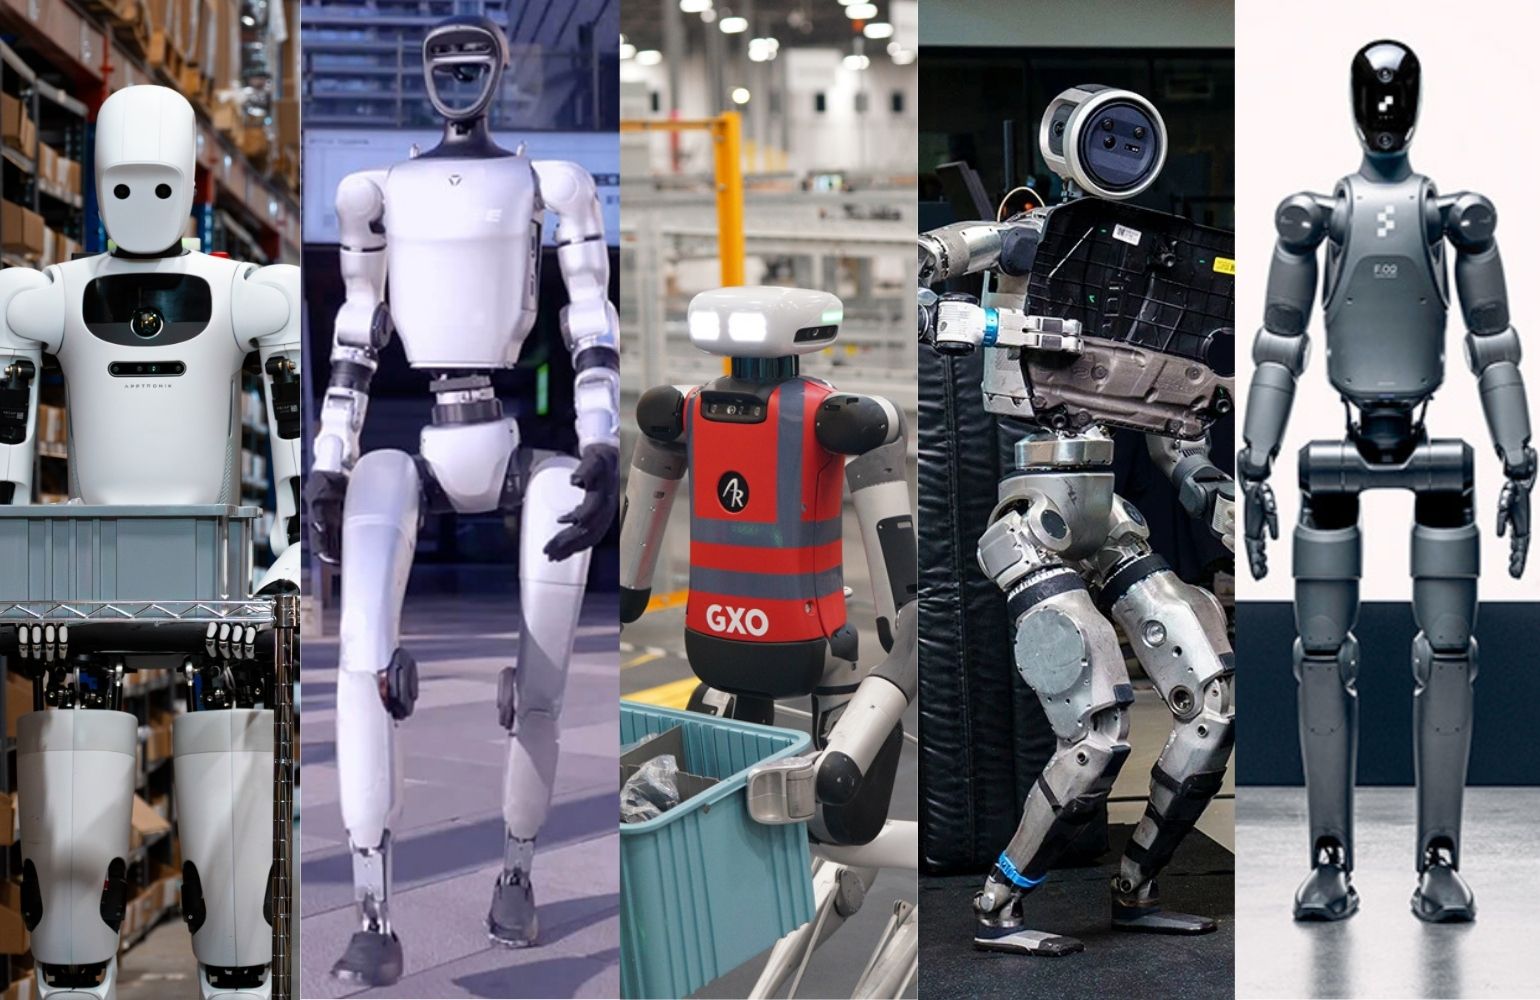
Kollmorgen to give a joint-by-joint guide to humanoid motion at RoboBusiness
The talk at RoboBusiness will outline the unique demands of each body zone and the challenges of scaling for production. The post Kollmorgen to give a joint-by-…

Pudu Robotics launches new MP2000 autonomous forklift
Pudu Robotics has launched the MP2000, an AI-native autonomous robot designed to transport 2,000 kg loads across complex warehouse environments. The post Pudu R…

Serve Robotics to deploy its autonomous delivery robots with Grubhub
Serve's robot delivery will be available from more than 100 participating Grubhub merchants in Chicago and nearly 200 in Los Angeles. The post Serve Robotics to…
Robotics roadmaps from around the world spotlight of the month: Japan
Robots have been a prolific theme in Japanese pop culture and media since the 1950s, which includes global icons like the Transformers, Astro Boy, and Doraemon …
Terrain-Aware Local Path Planning with Global DEM Data Integration for Autonomous UGV Navigation
arXiv:2608.17038v1 Announce Type: new Abstract: Autonomous navigation in complex outdoor terrains presents critical challenges for unmanned ground vehicles (UGV…
PDDL-ART: Autonomous Symbolic Abstraction From Demonstration For Long-Horizon Robotic Manipulation Using Vision-Language Models
arXiv:2608.17146v1 Announce Type: new Abstract: Symbolic planning with PDDL offers a principled framework for long-horizon robot manipulation, but constructing …
Robust Brachiation on a Life-Sized Dual-Arm Robot Using Waypoint-Guided Reinforcement Learning
arXiv:2608.17320v1 Announce Type: new Abstract: Brachiation is a form of locomotion in which primates move primarily using their arms, enabling traversal in env…
HODAgent: Towards On-Demand, Responsive Humanoids for Physical World Human Interaction
arXiv:2608.17584v1 Announce Type: new Abstract: We propose HODAgent, a System-2 embodied agent for humanoid robots in service settings, addressing situated inte…
Collective Ranking of Environmental Signals through Gaussian Belief Propagation in a Patrolling Robot Swarm
arXiv:2608.17690v1 Announce Type: new Abstract: Multi-robot patrolling requires a team to visit all areas of an environment at regular intervals, typically mini…
Effector-Centric NMPC of Tiltable-Multirotors for Offset-Free Omnidirectional Aerial Manipulation
arXiv:2608.17819v1 Announce Type: new Abstract: Aerial manipulation extends robotic operations to previously inaccessible aerial environments. Unlike arm-equipp…
ControlledShifts: Towards Standardizing Robustness Evaluation in Trajectory Prediction Under Distribution Shifts
arXiv:2608.17882v1 Announce Type: new Abstract: Trajectory prediction is central to safety in autonomous driving, yet learning-based predictors tend to degrade …
PRISM: Precision and contact-rich Real-world Industrial Skill dataset with Multimodal sensing
arXiv:2608.17962v1 Announce Type: new Abstract: Recent progress in robotic learning has been fueled by large-scale datasets collected in everyday environments. …
Optimal control of a swimming robot based on Purcell's microswimmer model
arXiv:2608.17455v1 Announce Type: cross Abstract: Purcell's swimmer is a well-known planar model of a swimming microorganism, governed by low Reynolds number hy…
LoopVLA: Learning Sufficiency in Recurrent Refinement for Vision-Language-Action Models
arXiv:2605.09948v2 Announce Type: replace-cross Abstract: Current Vision-Language-Action (VLA) models typically treat the deepest representation of a vision-lan…
Efficient Dynamic Shielding for Parametric Safety Specifications
arXiv:2505.22104v2 Announce Type: replace-cross Abstract: Shielding has emerged as a promising approach for ensuring safety of AI-controlled autonomous systems.…
KAN We Flow? Advancing Robotic Manipulation with 3D Flow Matching via KAN & RWKV
arXiv:2602.01115v3 Announce Type: replace Abstract: Diffusion-based visuomotor policies excel at modeling action distributions but are inference-inefficient, si…
PROBE: Manipulation-Grounded Visual Question Answering with VLM Agents
arXiv:2608.17129v1 Announce Type: cross Abstract: Vision-language Models (VLMs) excel at 2D grounding, spatial reasoning and agentic tool-based planning in stat…
Stability Control for Real World Testing in Autonomous Racing
arXiv:2608.17779v1 Announce Type: new Abstract: Controlling an autonomous vehicle at the limits of handling is a challenging task. Due to external influences, s…
Iterative Grasp Pose Refinement: A Deep Reinforcement Learning Approach for 2D Vision
arXiv:2608.17628v1 Announce Type: new Abstract: Developing robots capable of understanding and manipulating objects requires compact, interpretable, and general…
LIBERO-VIFO: Benchmarking the Capability and Safety of Visual Cue Following in Vision-Language-Action Models
arXiv:2608.17600v1 Announce Type: new Abstract: Visual cues are increasingly adopted to guide robot learning, but whether Vision-Language-Action (VLA) models ca…
Scalix: Uncertainty-Aware Scale-Consistent Monocular SLAM
arXiv:2608.17553v1 Announce Type: new Abstract: Cameras are ubiquitous sensors in robotics due to their compact form factor and the perceptual richness captured…
EATR-Stereo: Embodiment-Aware Routing of Paired Stereo Evidence for Humanoid Vision-Language-Action Control
arXiv:2608.17453v1 Announce Type: new Abstract: Long-horizon humanoid vision--language--action (VLA) control with head-mounted stereo cameras requires visual in…
Bi-Layer Ant Colony Optimization for Multi-Robot Task Allocation and Routing in Delivery Applications
arXiv:2608.17416v1 Announce Type: new Abstract: This paper addresses the multi-robot task allocation (MRTA) problem, which is essential for delivery and logisti…
ORPA: Online Residual Policy Adaptation for Robot Manipulation Control with Human Feedback
arXiv:2608.17323v1 Announce Type: new Abstract: Robotic manipulation policies trained via imitation learning, such as Action Chunking with Transformers (ACT), c…
MANIGUARD: A Benchmark and Data Suite for Specification-Grounded Safety Evaluation and Improvement of Robotic Manipulation
arXiv:2608.17386v1 Announce Type: new Abstract: Foundation-model policies for robotic manipulation are advancing rapidly on task success, but rigorous evaluatio…
Teach and Grow: An Agent-Centered Architecture for General Robot Learning
arXiv:2608.17209v1 Announce Type: new Abstract: End-to-end vision-language-action (VLA) and world-action models offer an elegant route to general-purpose roboti…