News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 stories
Use a digital twin to explore automation before committing capital
While a digital twin does not replace a systems integrator, it can help manufacturers evaluate robots and plan applications, says RoboDK. The post Use a digital…
Robots don’t run themselves: The workforce powering physical AI
The addition of physical AI to the workforce requires more key performance indicators than throughput, according to the president of HireArt. The post Robots do…
The technology that could bring robot mowers to one in two American lawns
Improvements in AI, satellite navigation, and machine vision are helping robotic lawn mowers spread in the U.S., writes Sunseeker's founder. The post The techno…
How software-defined manufacturing fits into real factory operations
Roby Lynn explains how R2 Labs bridges PLCs, robots, and AI to unify fragmented manufacturing systems. The post How software-defined manufacturing fits into rea…
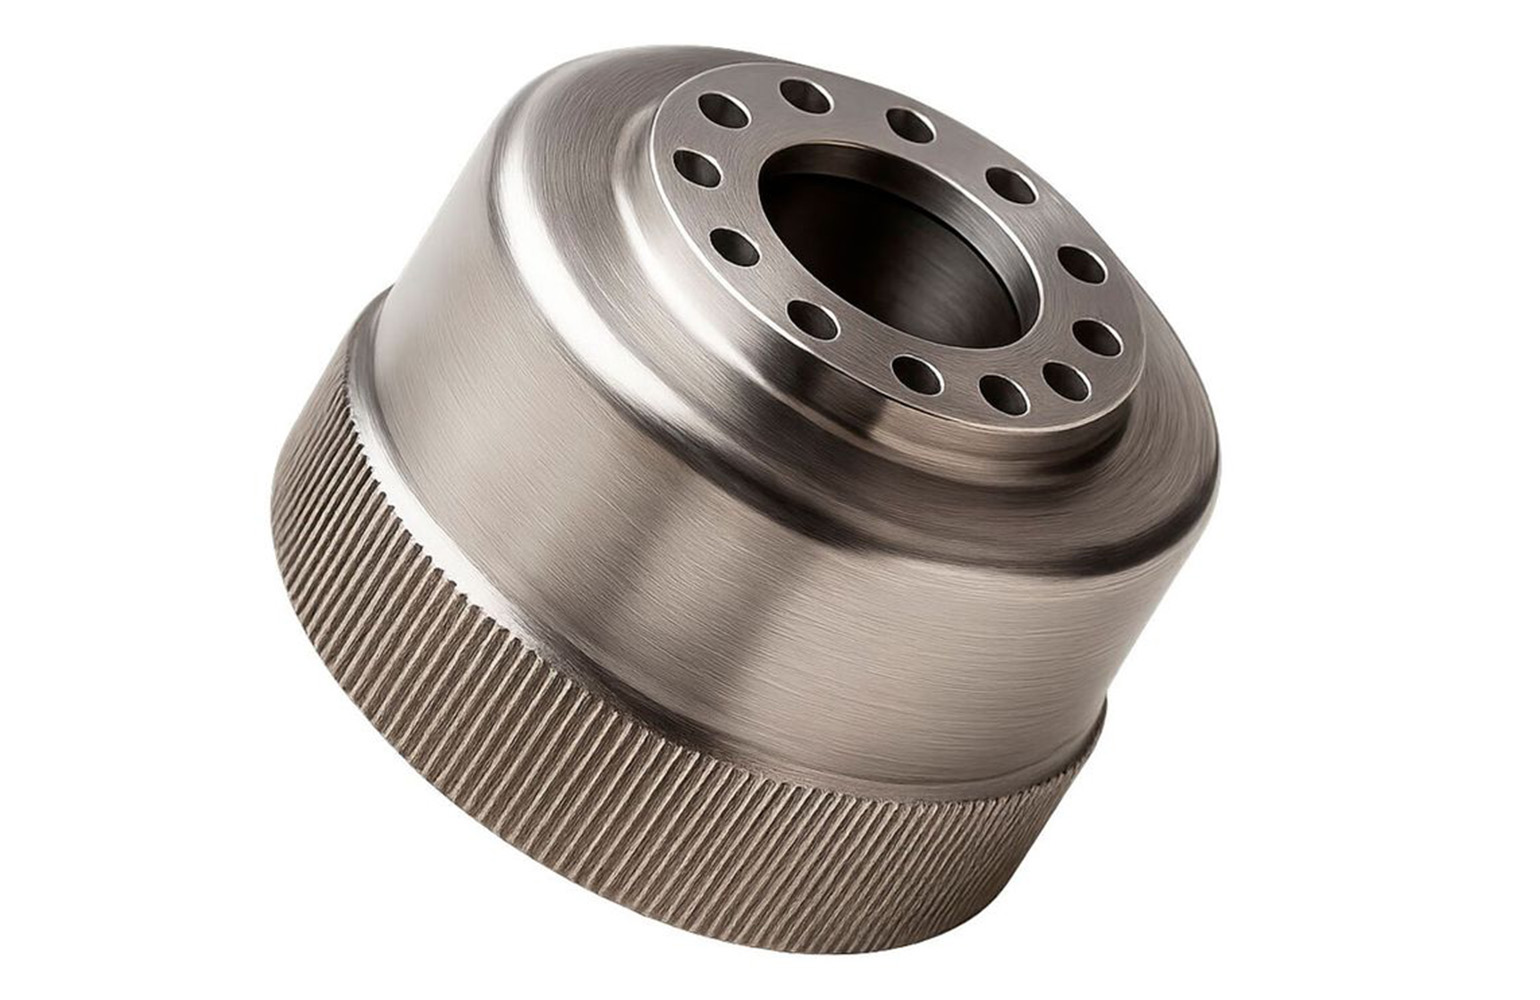
Schaeffler plans to mass produce gearboxes for humanoid robots in 2027
Schaeffler is creating its strain wave gearboxes with a forming technology that will enable mass production of the components. The post Schaeffler plans to mass…
Amazon’s Bhavana Chandrashekhar to speak at RoboBusiness’ Women in Robotics Lunch
The Women in Robotics Lunch at RoboBusiness is an opportunity to form new connections and deepen relationships. The post Amazon’s Bhavana Chandrashekhar t…
Wave-Based Bilateral Teleoperation between Nonlinear Manipulators with Direct Contact Force Feedback
arXiv:2608.20043v1 Announce Type: cross Abstract: We study bilateral teleoperation between nonlinear, multi-DOF robotic manipulators in the presence of constant…
Multi-Tool Robotics Enables In-Situ Sample Manipulation for Time-Resolved Synchrotron Measurements
arXiv:2608.19280v1 Announce Type: cross Abstract: The high photon flux at synchrotron beamlines allows for the measurement of fast dynamical processes. However,…
PVRA: A Pointwise Key-point Voting Framework for Robotic Assembly
arXiv:2608.19968v1 Announce Type: new Abstract: Modern computer vision has enabled partial autonomy in robotic assembly manipulation. However, performing autono…
Memory Centric Power Allocation for Multi-Agent Embodied Question Answering
arXiv:2604.17810v2 Announce Type: replace Abstract: This paper considers multi-agent embodied question answering (MA-EQA), which enables robot teams to answer q…
Calming Robot Pitches? Exploring the Influence of Robot Voice Pitch on Children's Stress Levels
arXiv:2608.19826v1 Announce Type: cross Abstract: This study examined whether variations in robot speech pitch influence children's stress levels during a robot…
World-Model-Grounded LLM Planning for AUV and ASV Navigation Near Offshore Wind Farms
arXiv:2608.19661v1 Announce Type: new Abstract: Large language models can turn a natural-language mission into a sequence of robot actions, but they do not have…
Keeping the Franka Emika Panda alive: a ROS 2 stack with a reliable position interface
arXiv:2608.19740v1 Announce Type: new Abstract: This paper presents an open-source software stack that restores ROS 2 support for the Franka Emika Panda robot w…
Towards general embodied intelligence: integrating large language models, knowledge bases, and reasoning capabilities to build the next generation of AI agents
arXiv:2608.19794v1 Announce Type: cross Abstract: The convergence of large language models (LLMs), structured knowledge bases (KBs), and reasoning ability (RA) …
DECOWAM: Decoupled Whole-Body World-Action Model for Legged Mobile Manipulation
arXiv:2608.20114v1 Announce Type: cross Abstract: Mobile manipulation requires a robot to predict how locomotion and arm motion jointly alter future observation…
DiffDef: A Diffusion Model for Generating Multimodal Goal Shapes From Demonstrations for Deformable Object Manipulation
arXiv:2506.18779v2 Announce Type: replace Abstract: Deformable object manipulation is a key capability in many robotic applications. A promising paradigm for th…
Learning Vision-Driven Reactive Soccer Skills for Humanoid Robots
arXiv:2511.03996v2 Announce Type: replace Abstract: Humanoid soccer poses a representative challenge for embodied intelligence, requiring robots to coordinate a…
Design strategies for empathetic AI robots for older adults
arXiv:2510.01192v2 Announce Type: replace-cross Abstract: Emulating empathy in human-robot interaction is a key component for achieving satisfying social, trust…
WaveVerif: Acoustic Side-Channel based Verification of Robotic Workflows
arXiv:2510.25960v2 Announce Type: replace-cross Abstract: In this paper, we present a framework that uses acoustic side-channel analysis (ASCA) to monitor and v…
Hybrid Feedback Sampling for Sample-Efficient Model Predictive Control
arXiv:2608.19443v1 Announce Type: new Abstract: Thanks to its parallelizability and flexibility, sampling-based Model Predictive Control (MPC) has become widely…
APPROVE: Visual End-User-in-the-Loop Robot Programming with LLMs
arXiv:2608.19281v1 Announce Type: new Abstract: Programming robots remains challenging for non-experts, as traditional methods require expert knowledge and even…
Planning-Oriented End-to-End Autonomous Driving: Architectures, Evaluation, and Emerging Paradigms
arXiv:2608.20111v1 Announce Type: new Abstract: End-to-end autonomous driving has evolved from camera-to-control regression toward planning-oriented systems tha…
Towards Professional Tennis Styles for Humanoid Robots with Adaptive Motion Planning and Tracking
arXiv:2608.20087v1 Announce Type: new Abstract: Humanoid robots have recently demonstrated promising capabilities in real-world ball sports. However, achieving …
GOAG: Generative and Object-Agnostic Grasp Planner for Dexterous Robotic Manipulation
arXiv:2608.19759v1 Announce Type: new Abstract: Multifingered grasping is a crucial robotic skill, but current deep-learning grasp planners often struggle to ge…
SAGE: Ergodic Control for Autonomous and Adaptive Inspection of Subsea Infrastructure
arXiv:2608.19671v1 Announce Type: new Abstract: Subsea Christmas Trees (XTs) are underwater structures that use valves for directing oil flow, needing constant …
What Matters for Latent Actions in Robot Learning
arXiv:2608.19613v1 Announce Type: new Abstract: Latent Action Models (LAMs) have emerged as a promising paradigm for enabling robot learning to leverage large-s…
The Missing Touch: Spatially Distributed Tactile Feedback Brings Teleoperation Closer to Human Dexterity
arXiv:2608.19372v1 Announce Type: new Abstract: A fundamental challenge in robotic teleoperation is enabling an operator to control a remote robot as effortless…
SCAPE: Scenario-Conditioned Simulation-Augmented Policy Evaluation
arXiv:2608.19425v1 Announce Type: new Abstract: Reliable performance evaluation is a central bottleneck for deploying robot-learning policies in real-world cond…
The Verification Gap in Networked Physical AI: A Post-Semantic Communication Framework
arXiv:2608.19593v1 Announce Type: new Abstract: A task-effective proposal is not yet a justified physical action. In networked Physical AI, a proposal may be un…
OrthoSkillVLA: Continual Skill Learning via Gradient-Informed Skill Subspace Adaptation
arXiv:2608.19589v1 Announce Type: new Abstract: Pretrained Vision-Language-Action models provide a strong foundation for robot learning, but sequentially adapti…