News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesVLCP: Vision Language Control Policy Closed-Loop Code Replanning for Robot Manipulation
arXiv:2608.16978v1 Announce Type: new Abstract: Turning a frontier vision-language model into a robot policy usually means fine-tuning it to emit an action repr…
Planning-aligned Token Compression for Long-Context Autonomous Driving
arXiv:2606.07464v2 Announce Type: replace Abstract: Monolithic vision-action models represent an emerging paradigm in autonomous driving. However, this architec…
Bootstrap Dynamic-Aware 3D Visual Representation for Scalable Robot Learning
arXiv:2512.00074v4 Announce Type: replace Abstract: Despite strong results on recognition and segmentation, current 3D visual pre-training methods often underpe…
Visual Prompting for Robotic Manipulation with Annotation-Guided Pick-and-Place Using ACT
arXiv:2508.08748v2 Announce Type: replace Abstract: Robotic pick-and-place tasks in convenience stores pose challenges due to dense object arrangements, occlusi…
ManiCM: Real-time 3D Diffusion Policy via Consistency Model for Robotic Manipulation
arXiv:2406.01586v4 Announce Type: replace Abstract: Diffusion models have been verified to be effective in generating complex distributions from natural images …
Training with synthetic data for drone detection in thermal imagery
arXiv:2608.17799v1 Announce Type: cross Abstract: Ground-to-Air (G2A) drone detection in medium- and long-wave infrared (MWIR/LWIR) imagery is challenging due t…
Hydra-0: Action Flow for Generalist World Modeling and Control
arXiv:2608.18077v1 Announce Type: new Abstract: We introduce Hydra-0, a generalist world model conditioned on action flow, which represents robot actions as pix…
CompCPZ: Preserving Multi-Modal Intent in Language-Guided Robot Manipulation
arXiv:2608.17717v1 Announce Type: new Abstract: A robot asked to "place the cup near the red plate or the blue plate" may reach the centroid between them and ap…
FetchMan: Learning Visual Humanoid Loco-Manipulation Policies from Simulated Experiences
arXiv:2608.17027v1 Announce Type: new Abstract: Visual loco-manipulation policies that can generalize to novel scenes and objects have long been a goal of robot…
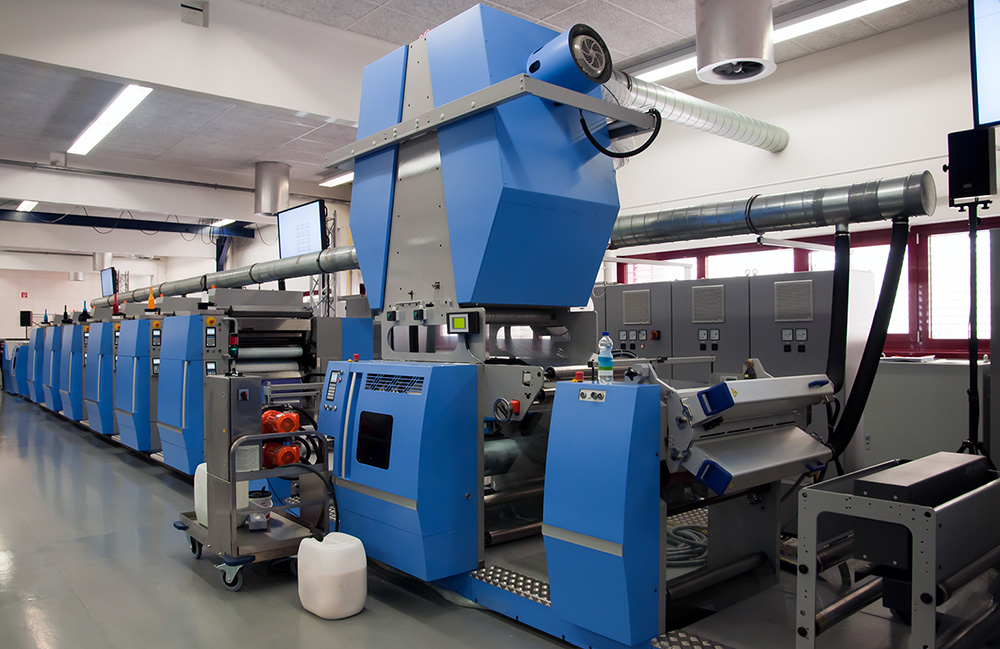
How to achieve high voltage in industrial systems without high complexity
Kollmorgen discusses the importance of fitting voltage systems closely to the application while still making the best use of infrastructure. The post How to ach…
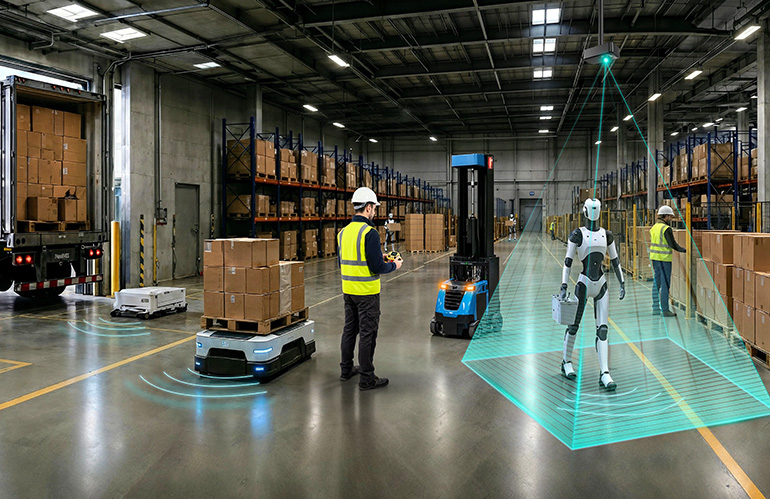
FORT Robotics to take safety stack public via SPAC merger
FORT Robotics said it expects valuation of more than $500 million as it lists on Nasdaq with plans to accelerate safety software development. The post FORT Robo…
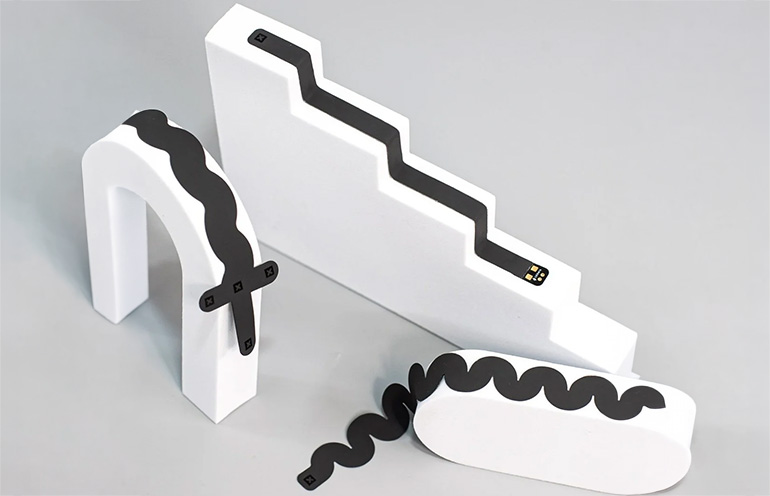
Unichem acquires Loomia to accelerate entry into the humanoid ‘skin’ market
Automotive suppliers Unichem and R&Y are working with Loomia to develop tactile sensors for automotive and robotics applications. The post Unichem acquires…
SpotlessGS: Relightable 3D Gaussian Splatting under Dynamic Illumination for Robotic Perception
arXiv:2608.14713v1 Announce Type: new Abstract: Robots operating in dark or poorly lit environments rely on onboard lights, which often produce uneven illuminat…
Imagining Recovery: Inference-Time Counterfactual Realignment for Vision-Language-Action Models
arXiv:2608.14822v1 Announce Type: new Abstract: Vision-language-action (VLA) models have improved the flexibility and generality of robotic manipulation, yet th…
Real-time Estimator of Actuator Control and Health (REACH) on an Eel-Inspired Soft Robot
arXiv:2608.14865v1 Announce Type: new Abstract: An actuator health estimation algorithm for a soft swimming robot that can perform anguilliform swimming is deve…
GaussMemory: Task-Driven 3D Gaussian Scene Memory for Long-Horizon Robotic Manipulation
arXiv:2608.14986v1 Announce Type: new Abstract: Long-horizon robotic manipulation fundamentally relies on persistent spatial memory. However, existing 3D memory…
NPU Offloading of a Frozen Visual Encoder for Robot Policy Training
arXiv:2608.15002v1 Announce Type: new Abstract: When a robot policy is trained for a new task or dataset, its visual encoder can be frozen and only its action g…
LAPF: LLM-Agent-Based Path Finder Using the UAVScenes Dataset
arXiv:2608.15175v1 Announce Type: new Abstract: Uncrewed aerial vehicles (UAVs) are increasingly deployed for autonomous navigation in complex outdoor environme…
Vision-Based Tactile Intelligence for Robotics: Sensing, Learning, and Embodied Manipulation
arXiv:2608.15490v1 Announce Type: new Abstract: Tactile sensing is essential for robots in contact-rich tasks, yet many tactile sensors still provide sparse, lo…
ReForce: Learning Force-aware Retargeting for Dexterous Manipulation
arXiv:2608.15560v1 Announce Type: new Abstract: Human demonstrations offer a scalable data source for dexterous manipulation, but transferring them to robot act…
Not All History Helps: Velocity-Aware Selective Memory for Long-Horizon End-to-End Autonomous Driving
arXiv:2608.15573v1 Announce Type: new Abstract: Reliable long-horizon planning remains a key challenge in end-to-end autonomous driving. By accounting for futur…
GAINS: Leveraging Inconsistent Human Intervention Signals in Reinforcement Learning
arXiv:2608.15707v1 Announce Type: new Abstract: Correcting robot manipulation policies through human intervention holds great promise for real-world deployment,…
Some Modifications to Our End-to-End UAV Planner
arXiv:2608.15741v1 Announce Type: new Abstract: The one-stage planner YOPO maps a single depth image and the robot state directly to a set of candidate trajecto…
Making two action heads agree: coordination mechanisms and a runtime collapse certificate for flow-matching policies
arXiv:2608.15748v1 Announce Type: new Abstract: A dual-representation flow-matching policy decodes each predicted motion into joint and end-effector spaces, and…
Reliable Piezoresistive Strain Sensing Through Physical Limits and Uncertainty Monitoring
arXiv:2608.15784v1 Announce Type: new Abstract: Soft piezoresistive strain sensors are one of the most common sensing solutions for wearable and soft robotic ap…
H-PAC Hand: Control-Oriented Modeling and Tendon-Elasticity Compensation for an Underactuated Robotic Hand
arXiv:2608.16712v1 Announce Type: new Abstract: Underactuated tendon-driven hands offer compact actuation and passive compliance, but tendon elongation under re…
MatchingPolicy: Correspondence-Aware Policy Enables Cross-Object In-Context Learning
arXiv:2608.16715v1 Announce Type: new Abstract: In-context imitation learning enables few-shot policy generalization but struggles to maintain performance on un…
Adaptive Repulsive Pheromone Clustering for Foraging Robot Swarms
arXiv:2608.16822v1 Announce Type: new Abstract: The Central Place Foraging Algorithm (CPFA) combines site fidelity, pheromone-guided navigation, and uninformed …
Don't Drop the BATON: Long-Horizon Robot Manipulation via Agentic Subtask Exploration and Transition-aware Memory
arXiv:2608.16889v1 Announce Type: new Abstract: Long-horizon robot manipulation chains many contact-rich skills into one multi-stage task. Vision-language-actio…
Pluralistic Human-Robot Interaction: Designing for Robot Interaction with Diverse Communities
arXiv:2608.16049v1 Announce Type: cross Abstract: Social robots are being developed for homes, schools, and other environments where they will interact with div…