News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesMorFiC: Fixing Value Miscalibration for Zero-Shot Quadruped Transfer
arXiv:2603.14554v2 Announce Type: replace Abstract: Generalizing learned locomotion policies across quadrupedal robots with different morphologies remains a cha…
Reactive Planning based Control for Mobile Robots in Obstacle-Cluttered Environments
arXiv:2605.14232v2 Announce Type: replace Abstract: This paper addresses the motion control problem for mobile robots in obstacle-cluttered environments. The mo…
A Unified Neural-Aided Alignment and Calibration Method for AUVs
arXiv:2608.22496v1 Announce Type: new Abstract: Autonomous underwater vehicles (AUVs) rely on the fusion of inertial navigation systems (INS) and Doppler veloci…
Inferring Action from Future Latent State for Robotic Manipulation
arXiv:2608.22067v1 Announce Type: new Abstract: World-Action Models (WAMs) build robot control on video-generation backbones, which jointly predict dense future…
In-Situ Reconstruction of the International Space Station Using 3D Gaussian Splatting and Astrobee
arXiv:2608.21685v1 Announce Type: new Abstract: This article presents a novel 3D reconstruction and mapping of the interior of the International Space Station (…
Betting for Sim-to-Real Performance Certificates
arXiv:2608.21572v1 Announce Type: new Abstract: Consider a typical test of a robot system: one observes a sequence of outcomes concerning some aspect of interes…
RiskWorld: Object-Centric Latent World Modeling for Autonomous Driving Risk Identification
arXiv:2608.21414v1 Announce Type: new Abstract: Autonomous driving risk identification aims to determine which observed object is likely to become safety-critic…
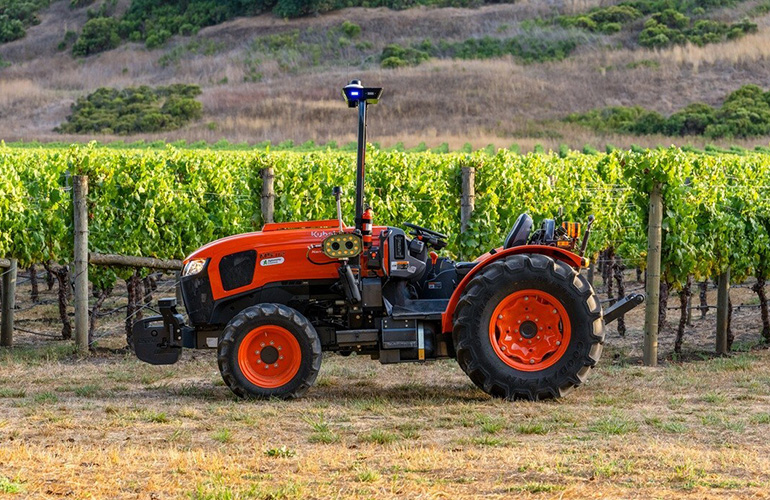
The next big AI play isn’t apps or humanoids; it’s machines with brains and brawn
For agricultural and construction equipment makers to stay relevant as workforces dwindle, they need to add AI, says Agtonomy's founder. The post The next big A…
XPeng Motors humanoid robot unit Dogotix raises $900M
Dogotix, the humanoid unit of XPeng Motors, has attained a valuation of $6.3 billion as it plans to produce robots at scale. The post XPeng Motors humanoid robo…
Demonstration-Guided Humanoid Stand-Up on an Emulated Deformable Surface
arXiv:2608.20852v1 Announce Type: new Abstract: This paper presents a reference-guided reinforcement learning framework to generate stand-up motion for a 29-DOF…
Beyond Imitation: Self-Improving Robot Policies via Off-Policy Q-Planning
arXiv:2608.21204v1 Announce Type: new Abstract: Behaviour Cloning (BC) has driven remarkable progress in robot manipulation, yet it is fundamentally limited by …
Mining beyond Earth with Space Robots: Exploration, Sampling, and Extraction
arXiv:2608.21358v1 Announce Type: new Abstract: Space resource acquisition and utilization, commonly referred to as Space Mining, represent critical pathways fo…
Pneumatic Units for Logic-based Sequential Excitation (PULSE) in Wearable Haptic Devices
arXiv:2608.20626v1 Announce Type: cross Abstract: Soft, wearable robotic devices can deliver haptic feedback to support a wide range of tasks, such as extended …
A Collaborative Multi-Modality Interaction for VLA-based End-to-End Autonomous Driving
arXiv:2608.20890v1 Announce Type: cross Abstract: Vision-Language-Action (VLA) models have emerged as a powerful paradigm for end-to-end autonomous driving by j…
Update-Free On-Policy Steering via Verifiers
arXiv:2603.10282v3 Announce Type: replace Abstract: In recent years, Behavior Cloning (BC) has become one of the most prevalent methods for learning manipulatio…
Just Noticeable Difference Modeling for Token Compression in Vision-Language-Action Models
arXiv:2608.21247v1 Announce Type: cross Abstract: Token compression has become a key technique for reducing the inference cost of large foundation models, with …
A Safety-Driven Architectural Framework for Fail-Operational Drone Swarms in Critical Missions
arXiv:2608.20906v1 Announce Type: cross Abstract: The certification of Unmanned Aerial Vehicle (UAV) swarms for safety-critical operations requires verifiable d…
Multi-Modal Traffic Sign Detection with Semantic Attributes for Autonomous Driving
arXiv:2608.20874v1 Announce Type: cross Abstract: Reliable traffic sign detection is a prerequisite for the global deployment of autonomous driving systems, whe…
GhostTac: Manipulating Tactile Sensors without Physical Contact
arXiv:2608.20817v1 Announce Type: cross Abstract: Tactile sensors are integral to modern robotic systems, enabling robots to perceive and interact with the phys…
SRL-MPC: Shape-Aware Reinforcement Learned Model Predictive Control
arXiv:2608.21175v1 Announce Type: new Abstract: Safe and efficient shape-aware navigation in heterogeneous crowds and robot fleets remains challenging. Traditio…
Neural-Primitive: An Efficient End-to-end Local Planner with Primitive-based Imitation Learning for Autonomous Flight
arXiv:2608.20948v1 Announce Type: new Abstract: Autonomous flight in unknown cluttered environments is hindered by the computation-quality-memory trilemma of on…
Natural Sit-to-Stand Motion Synthesis For Humanoids via Guided Assistance Curricula and Staged Rewards
arXiv:2608.20823v1 Announce Type: new Abstract: A humanoid has infinitely many ways to stand up from sitting while maintaining balance, making sit-to-stand (STS…
Roadside-Cooperative Autonomous Driving: From Data Platform to Vision-Language End-to-End Reasoning
arXiv:2608.21032v1 Announce Type: new Abstract: Vehicle-to-Everything (V2X) cooperation enables beyond-line-of-sight perception, mitigating occlusions in single…
Teaching is a Process: The TOSS Framework for Modeling Human Teaching Decisions in Human-Interactive Robot Learning
arXiv:2608.21083v1 Announce Type: new Abstract: Successful Human-Robot Teaching assumes alignment between robot processing needs and human teaching intent. To b…
Rapid Manufacturing of Lightweight Drone Frames Using Single-Tow Architected Composites
arXiv:2509.09024v2 Announce Type: replace Abstract: The demand for lightweight and high-strength composite structures is rapidly growing in aerospace and roboti…
The Coastline as a Structural Constraint: Harnessing Scene Geometry for Autonomous Surface Vessel Localization
arXiv:2608.21276v1 Announce Type: new Abstract: Coastal environments contain rich, largely unexploited geometric structure capable of providing globally referen…
PhysCaP: Grounding Code-as-Policy Agent with Physics-Informed Exploration
arXiv:2608.21031v1 Announce Type: new Abstract: We present PhysCaP, a Physics-Informed Code-as-Policy agent for active perception in robotic manipulation. While…
Koala Gripper: Co-designing Robotic Grippers and Data-Capture Devices for Scaling Dexterous Manipulation Learning
arXiv:2608.20546v1 Announce Type: new Abstract: As the demand for larger manipulation datasets grows, handheld robotic gripper data collection and the associate…
Humanoid Musical Robots as Experimental Interfaces for Music-Evoked Emotion
arXiv:2608.20433v1 Announce Type: new Abstract: Advances in technology have led to increasingly sophisticated musical humanoid robots. However, their use has la…
A hidden “on switch” in human DNA has finally been decoded
Researchers have used AI to uncover the DNA signature of a key genetic “switch” involved in turning genes on. After analyzing about 500,000 DNA sequences, the m…