Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesUncertainty Quantification for Flow-Based Vision-Language-Action Models
arXiv:2606.18043v1 Announce Type: new Abstract: Vision-language-action models (VLAs) combine vision-language backbones with expressive generative action heads t…
Any2Any: Efficient Cross-Embodiment Transfer for Humanoid Whole-Body Tracking
arXiv:2605.23733v2 Announce Type: replace Abstract: Whole-body tracking (WBT) models have become a key foundation for humanoid robots, enabling them to imitate …
RLRC: Reinforcement Learning-based Recovery for Compressed Vision-Language-Action Models
arXiv:2506.17639v2 Announce Type: replace Abstract: Vision-Language-Action models (VLA) have demonstrated remarkable capabilities and strong potential in comple…
VISTA: Scale-Aware Visual Navigation via Action History Conditioning
arXiv:2606.17294v1 Announce Type: new Abstract: Vision Navigation Foundation Models (VNMs) promise end-to-end learned navigation policies capable of zero-shot d…
Pegasus Tech Ventures launches $60M fund for physical AI startups
Pegasus and CYBERDYNE will invest in startups developing robotics, physical AI, healthcare, automation, and intelligent systems. The post Pegasus Tech Ventures …
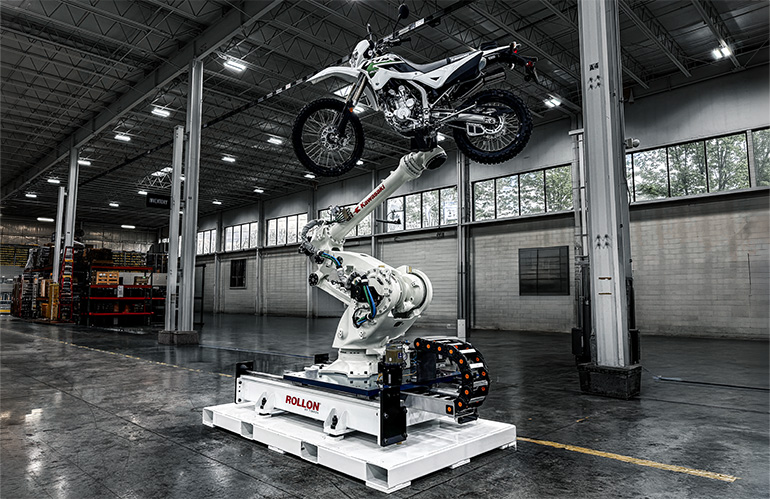
Kawasaki Robotics to debut RL030N physical AI platform at Automate
Kawasaki Robotics says its 8-DoF robot, Pulseboard inspection tech, and other systems will show its vision for intelligent automation. The post Kawasaki Robotic…
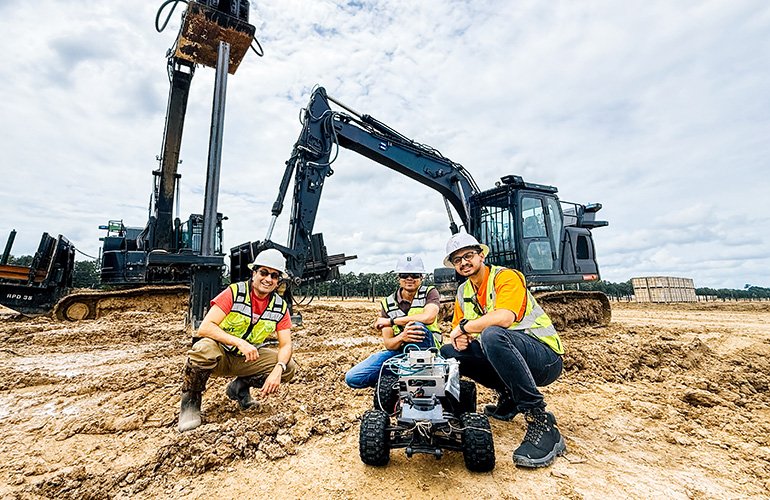
Built Robotics, Penn xLAB to develop physical AI for construction
xLAB and Built Robotics partner to capture additional data, advancing AI models to improve construction site safety. The post Built Robotics, Penn xLAB to devel…
Unified Motion-Action Modeling for Heterogeneous Robot Learning
arXiv:2606.16917v1 Announce Type: new Abstract: We present Unified Motion-Action (UMA) Model, an approach that uses 3D object motion trajectories as a shared in…
A Deployment Case Study in Robotic Apparel Automation: Digital Twin Integration, Interoperability, and Workforce Enablement
arXiv:2606.16078v1 Announce Type: new Abstract: Despite steady advances in flexible automation in sectors such as electronics and automotive manufacturing, appa…
FARM: Find Anything using Relational Spatial Memory
arXiv:2606.15476v1 Announce Type: new Abstract: Robots operating in homes, warehouses, and other object-rich environments need memory systems that can find spec…
Acting While Understanding: Asynchronous Semantic-Action Decoupling for Real-Time Vision-Language-Action Models
arXiv:2606.15285v1 Announce Type: new Abstract: Vision-Language-Action models (VLAs) have demonstrated strong task understanding and generalization in robotic m…
MimicIK: Real-Time Generative Inverse Kinematics from Teleoperation with FK Consistency
arXiv:2606.15148v1 Announce Type: new Abstract: Inverse kinematics (IK) remains a critical bottleneck for real-time robot manipulation. Classical numerical solv…
GenZ-LIO: Generalizable LiDAR-Inertial Odometry Beyond Confined--Open Boundaries
arXiv:2603.16273v2 Announce Type: replace Abstract: For field robotic missions such as inspection, search-and-rescue, and exploration, light detection and rangi…
AetheRock: An Arm-Worn Robot Teaching System for Force-Guided Vision-Tactile Learning
arXiv:2606.09777v2 Announce Type: replace Abstract: Force and tactile sensing are indispensable in contact-rich manipulation. However, force-aware robot learnin…
DataLadder: A Simulation-Enabled Interconversion Toolchain for the Embodied Data Pyramid
arXiv:2606.16776v1 Announce Type: new Abstract: Generalist robot policies require trustworthy evaluation and robot-usable training data, but both are difficult …
Inference-time Policy Steering via Vision and Touch
arXiv:2606.14981v1 Announce Type: new Abstract: Inference-time steering adapts pre-trained generative robot policies during deployment by verifying candidate ac…
Understanding and Modeling Perceived Cognitive and Physical Strain Dynamics for Planning-Oriented Human-Robot Collaboration in Prefabricated Construction
arXiv:2606.15494v1 Announce Type: new Abstract: Human-robot collaboration (HRC) in prefabricated construction requires planning approaches that consider not onl…
Reinforcement Learning-Guided Retrieval with Soft Fusion for Robust Multimodal Imitation Learning under Missing Modalities
arXiv:2606.15514v1 Announce Type: new Abstract: Robotic systems perceive the world through multiple input modalities -- including visual camera streams and natu…
Automated Digital Twin Construction for Highway Scenarios Using LiDAR Point Clouds and OpenStreetMap
arXiv:2606.16570v1 Announce Type: new Abstract: Accurate road environment modeling is fundamental to the simulation and validation of automated driving systems.…
PATCH: Action-Chunk-Conditioned Latent Patch Innovation Monitoring for Robot Manipulation
arXiv:2606.16690v1 Announce Type: new Abstract: Learning-based manipulation policies have made substantial progress in real-world robot manipulation, particular…
Explainable deep learning improves human mental models of self-driving cars
arXiv:2411.18714v3 Announce Type: replace Abstract: Self-driving cars increasingly rely on deep neural networks to achieve human-like driving. The opacity of su…
Neural Minimum-Distance Estimation for Collision-Aware Operation of Multi-Arm Laparoscopy Surgical Robots Through Learning-from-Simulation
arXiv:2601.15459v2 Announce Type: replace Abstract: This study presents an integrated framework for enhancing the safety and operational efficiency of robotic a…
Multi-Robot Motion Planning from Vision and Language using Heat-Inspired Diffusion
arXiv:2512.13090v2 Announce Type: replace Abstract: Diffusion models have recently emerged as powerful tools for robot motion planning by capturing the multi-mo…
Towards Next-Generation Healthcare: A Survey of Medical Embodied AI for Perception, Decision-Making, and Action
arXiv:2606.15647v1 Announce Type: cross Abstract: Foundation models have demonstrated impressive performance in enhancing healthcare efficiency across a wide ra…
Leveraging Deep Learning for Object and Position Recognition of Load Carriers for Autonomous Logistics Vehicles
arXiv:2606.16042v1 Announce Type: new Abstract: This work explores the use of artificial intelligence in mobile robotics to achieve autonomous detection and pos…
FlashNav: Ultra-Fast Policy Training for Robot Navigation within 20 Seconds
arXiv:2606.15846v1 Announce Type: new Abstract: Deep reinforcement learning has shown strong potential for robot navigation, but its practical deployment is sti…
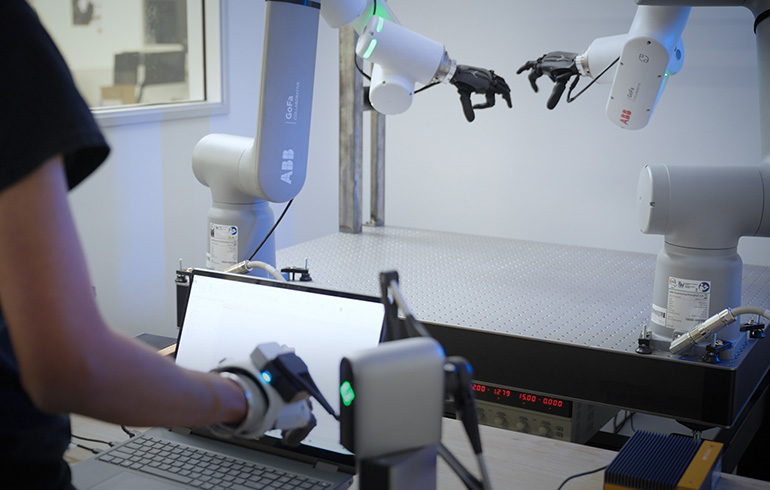
PSYONIC partners with ABB Robotics to apply human touch to robot dexterity
PSYONIC is combining its Ability Hand with ABB Robotics' GoFa cobot arm to apply data from prosthetics users to robotic grasping. The post PSYONIC partners with…
Efficient Domain-Adaptive Policy Learning via Kernel Representation with Application to Quadrotor Control under Non-Stationary Disturbances
arXiv:2606.13842v1 Announce Type: new Abstract: We present an algorithm for efficient domain-adaptive policy learning via kernel representations. Learning domai…
BIM-Loc: BIM-Integrated Discrepancy-Aware LiDAR-based Indoor Localization
arXiv:2606.14237v1 Announce Type: new Abstract: Accurate and robust localization is a fundamental requirement for service and inspection robots, particularly in…
Lifted Schr\"odinger Bridges for Gaussian Mixture Endpoints: Projection Gaps and Path-Space Obstructions
arXiv:2605.24795v2 Announce Type: replace-cross Abstract: We study stochastic density control between Gaussian-mixture endpoint distributions under Brownian pri…