Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesSensitivity Shaping for Latent Modeling
arXiv:2606.14585v1 Announce Type: new Abstract: Generative dynamics models enable planning in challenging robotic systems, but safe deployment requires reliably…
Digital Twin Driven Textile Classification and Foreign Object Recognition in Automated Sorting Systems
arXiv:2603.05230v2 Announce Type: replace-cross Abstract: The increasing demand for sustainable textile recycling requires robust automation solutions capable o…
A Unified Control Architecture for Macro-Micro Manipulation using a Active Remote Center of Compliance for Manufacturing Applications
arXiv:2602.01948v2 Announce Type: replace Abstract: Macro-micro manipulators combine a macro manipulator with a large workspace, such as an industrial robot, wi…
Learning Dynamic Swing-Up of an Inverted Pendulum using Remote Magnetic Actuation
arXiv:2606.13915v1 Announce Type: new Abstract: Electromagnetic Navigation Systems (eMNS) have gained considerable attention for minimally invasive surgery and …
Cross-Stage Sensorimotor Perception Scheduling and Sparse Map Encoding for Efficient Edge Embodied Navigation
arXiv:2405.14154v5 Announce Type: replace Abstract: Embodied agents must close a perception-to-action loop on embedded hardware under tight latency, memory, and…
Safe Reinforcement Learning of Autonomous Highway Driving: A Unified Framework for Safety and Efficiency
arXiv:2606.14609v1 Announce Type: new Abstract: Deep reinforcement learning (DRL) offers a compelling route to decision-making for advanced autonomous vehicles …
RT-VLA: Real-Time Vision-Language-Action Models via Knowledge Distillation
arXiv:2606.14010v1 Announce Type: cross Abstract: Vision-Language-Action (VLA) models have shown strong potential for end-to-end autonomous driving by jointly m…
Provably Safe, Yet Scalable Reinforcement Learning
arXiv:2606.14536v1 Announce Type: cross Abstract: Safe reinforcement learning (RL) aims to learn policies that optimize rewards while satisfying constraints. Pr…
ADAPT: An Autonomous Forklift for Construction Site Operation
arXiv:2503.14331v4 Announce Type: replace Abstract: Efficient material logistics play a critical role in controlling costs and schedules in the construction ind…
Development of a 3 in Sewer Pipe Inspection Robot with an Articulated Differential Mechanism using X-shaped Linkages
arXiv:2606.14070v1 Announce Type: new Abstract: This paper proposes, an improved version of the 3 in sewer pipe inspection robot equipped with an emergency evac…
Hy-Embodied-0.5-VLA: From Vision-Language-Action Models to a Real-World Robot Learning Stack
arXiv:2606.14409v1 Announce Type: new Abstract: In this report, we present Hy-Embodied-0.5-VLA, abbreviated as HyVLA-0.5, an end-to-end system that spans the fu…
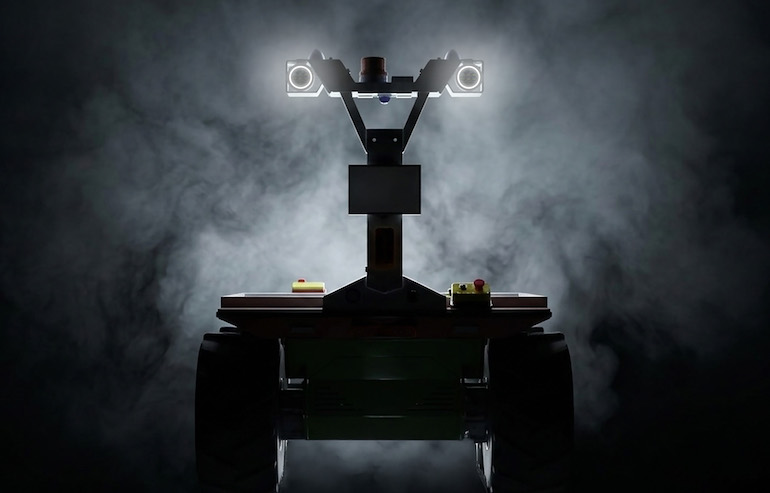
Burro introduces Grande 44 with proven outdoor autonomy built for heavy industry
The 44 hp Burro Grande brings more than 1 million hours of real-world experience to industrial towing, site logistics, and facilities operations. The post Burro…
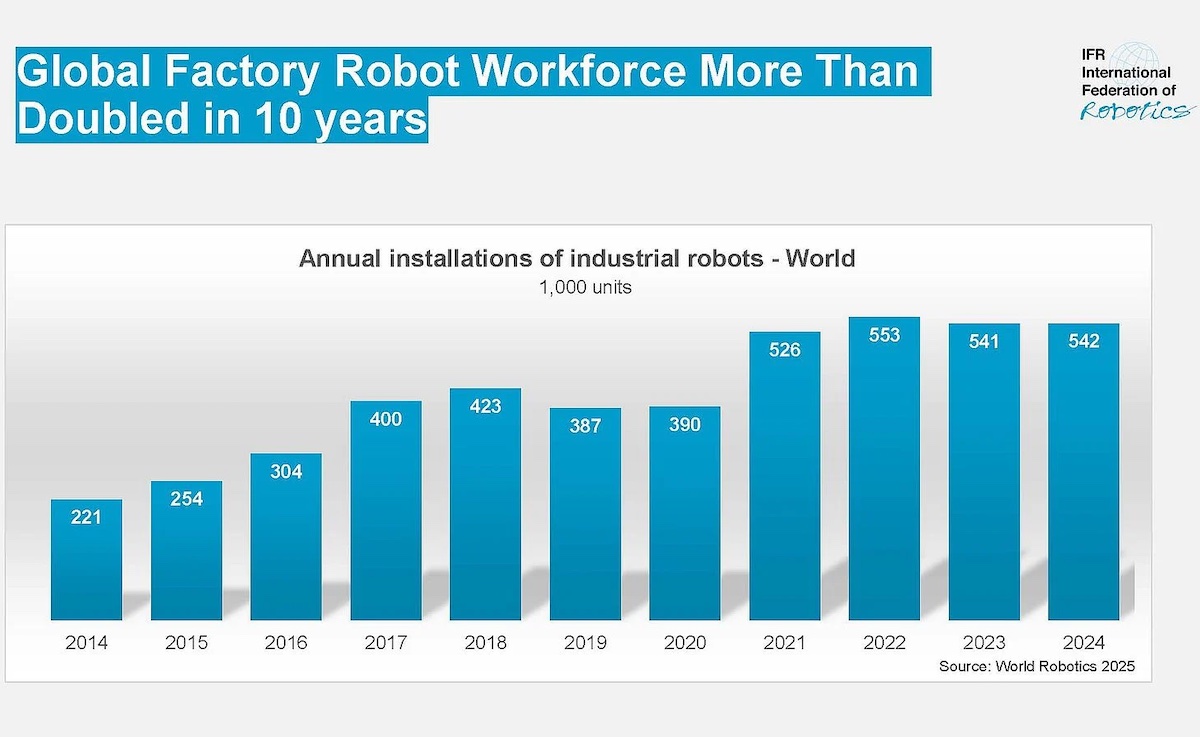
Modernizing the global economy with industrial robotics is needed but not inevitable
While service robotics adoption grows, industrial automation faces greater demand and bigger obstacles, notes a columnist. The post Modernizing the global econo…
AI in Warehousing: Akash Gupta’s vision for the future
Explore how GreyOrange's software revolutionizes warehouse automation with AI, transforming logistics into dynamic, predictive ecosystems. The post AI in Wareho…
Robot Talk Episode 160 – Robotic blacksmiths, with Edward Mehr
Claire chatted to Edward Mehr from Machina Labs about their RoboCraftsman that shapes complex metal parts for the aerospace, defence, and automotive industries.…
EWAM: An Enhanced World Action Model for Closed-Loop Online Adaptation in Embodied Intelligence
arXiv:2606.12690v1 Announce Type: new Abstract: In this paper, we propose the Enhanced World Action Model (EWAM), a closed-loop online adaptation architecture b…
EmbodiSteer: Steering Embodiment-Agnostic Visuomotor Policies with Joint-Space Guidance for Zero-Shot Cross-Embodiment Deployment
arXiv:2606.12965v1 Announce Type: new Abstract: Scalable robot imitation learning relies on large-scale heterogeneous data from diverse robots or body-free data…
Y-BotFrame: An Extensible Embodied Agent Framework for Quadruped Robot Assistants
arXiv:2606.13049v1 Announce Type: new Abstract: Quadruped robots are capable of traversing a wide range of complex terrains with high flexibility. As highly mob…
Comparing Commercial Depth Sensor Accuracy for Medical Applications
arXiv:2606.13028v1 Announce Type: new Abstract: Depth estimation has numerous medical and surgical applications. We benchmark four depth sensors on a porcine bo…
SCALE: Self-uncertainty Conditioned Adaptive Looking and Execution for Vision-Language-Action Models
arXiv:2602.04208v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models have emerged as a promising paradigm for general-purpose robotic control…
Adaptive-Horizon Conflict-Based Search for Closed-Loop Multi-Agent Path Finding
arXiv:2602.12024v2 Announce Type: replace Abstract: MAPF is a core coordination problem for large robot fleets in automated warehouses and logistics. Existing a…
AssemLM: A Spatial Reasoning Multimodal Large Language Model for Robotic Assembly
arXiv:2604.08983v2 Announce Type: replace Abstract: Spatial reasoning is a fundamental capability for embodied intelligence, especially for fine-grained manipul…
From Digital to Physical: Digital Agents as Autonomous Coaches for Physical Intelligence
arXiv:2601.21570v2 Announce Type: replace-cross Abstract: The field of Embodied AI is witnessing a rapid evolution toward general-purpose robotic systems, fuele…
Low cost, easily manufactured, highly flexible strain and touch sensitive fiber for robotics applications
arXiv:2606.13352v1 Announce Type: new Abstract: Existing stretch and touch sensors for robots are generally expensive with respect to at least one of material c…
EMG-Based Adaptation of Anisotropic Virtual Fixtures for Robot-Assisted Surgical Resection and Dissection
arXiv:2606.13340v1 Announce Type: new Abstract: In this paper, we address the development of an adaptive assistance system for robot-assisted laparoscopic surge…
From Imitation to Alignment: Human-Preference Flow Policies for Long-Horizon Sidewalk Navigation
arXiv:2606.12603v1 Announce Type: new Abstract: Autonomous long-horizon sidewalk navigation is essential for micro-mobility applications such as robotic food de…
PLUME: Probabilistic Latent Unified World Modeling and Parameter Estimation for Multi-Finger Manipulation
arXiv:2606.11396v1 Announce Type: new Abstract: Dexterous manipulation with multi-finger hands can be sensitive to physical parameters such as object shape, pos…
A Modular Dual-Camera Pipeline for Micro-Inspection Using Aerial Robots
arXiv:2606.11419v1 Announce Type: new Abstract: Most existing drone-based inspection systems require the drone to fly dangerously close to the target or follow …
Adversarial Attacks on Learned Policies for Surgical Robotic Tasks
arXiv:2606.11535v1 Announce Type: new Abstract: Learning-based policies are being considered to augment the dexterity of human surgeons in robot-assisted surger…
Point Cloud Segmentation for Autonomous Clip Positioning in Laparoscopic Cholecystectomy on a Phantom
arXiv:2606.12048v1 Announce Type: new Abstract: High-risk applications in robotics, such as robot-assisted surgery, present unique challenges. These systems mus…