Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesLarge-Scale Tunnel Air--Ground Collaboration With FLISP: Fast LiDAR-IMU Synchronized Path Planne
arXiv:2606.25393v1 Announce Type: new Abstract: Hydropower tunnel inspection is critical for infrastructure integrity yet remains inefficient and hazardous usin…
RigPI: Dynamic Parameter Identification of Rigid Body via VLM-Seeded Differentiable Simulation
arXiv:2606.25212v1 Announce Type: new Abstract: Accurate physical parameter identification of manipulated objects is fundamental to advanced robotic manipulatio…
An Integrated Hardware-Software Design for Low-Data Spatial Defect Detection in Robotic Visual Inspection with Hybrid Optoelectronic Neural Networks
arXiv:2606.25277v1 Announce Type: new Abstract: To address data overload and inefficient shape-level annotation in robotic visual inspection, this paper propose…
Stage-Aware and Roughness-Constrained Diffusion Policy for Multi-Stage Robotic Polishing
arXiv:2606.25754v1 Announce Type: new Abstract: Polishing is a critical finishing process in high-end manufacturing fields such as aerospace, where surface qual…
MIL-LC: A Robust Magnetometer-Inertial-LiDAR Fusion Multimodal Localization Framework
arXiv:2606.25796v1 Announce Type: new Abstract: Localization in challenging environments, such as GNSS-denied, geometrically repetitive, or textureless scenes c…
RAVEN: Long-Horizon Reasoning & Navigation with a Visuo-Spatio-Temporal Memory
arXiv:2606.25206v1 Announce Type: new Abstract: Long-term robot deployment requires a compact and scalable memory that preserves fine-grained visual semantics, …
ARTOO-DARTU: Studying AR-HRC With AR Obstruction Mitigation During a Warehouse Task
arXiv:2606.25202v1 Announce Type: cross Abstract: Human-robot collaboration (HRC) often requires robot intentions and internal states to be conveyed to users fo…
ReaDy-Go: Real-to-Sim Dynamic 3D Gaussian Splatting Simulation for Environment-Specific Visual Navigation with Moving Obstacles
arXiv:2602.11575v3 Announce Type: replace Abstract: Visual navigation models often struggle in real-world dynamic environments due to limited robustness to the …
Deep Reinforcement Learning-Enhanced Event-Triggered Data-Driven Predictive Control for a 3D Cable-Driven Soft Robotic Arm
arXiv:2606.26048v1 Announce Type: new Abstract: Soft robots are challenging to control due to their nonlinear and time-varying dynamics. Data-enabled predictive…
SurveilNav: Collaborative Object Goal Navigation with Robot and Surveillance System
arXiv:2606.25119v1 Announce Type: new Abstract: With the growing deployment of surveillance systems in factories, offices, and homes, integrating them with robo…
From Rubble Simulation to Active Magnetic Mapping: Quantum Sensing for Disaster Response
arXiv:2606.25957v1 Announce Type: new Abstract: Locating survivors of building collapses within the first 72 hours is a critical challenge in disaster response,…
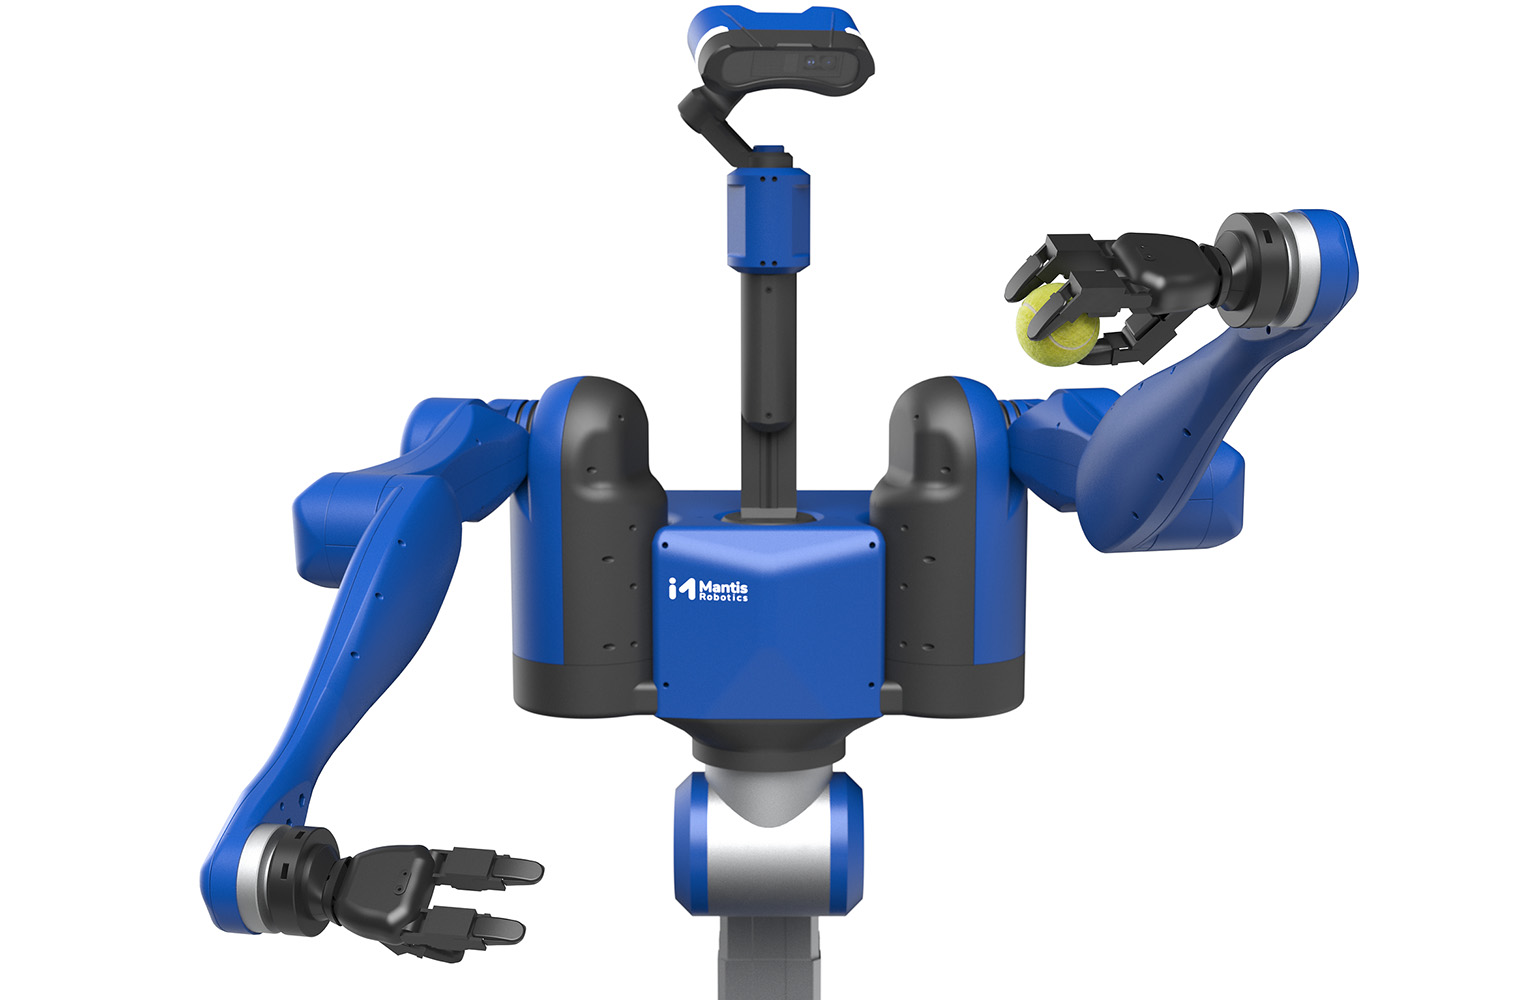
Mantis Robotics launches dual-arm, fenceless robot
Mantis said the robot allows for new flexibility in how to configure automation in complex, real-world environments. The post Mantis Robotics launches dual-arm,…
Grounding Generative Policies in Physics: Optimization-Guided Diffusion for Robot Control
arXiv:2606.24208v1 Announce Type: new Abstract: Diffusion models sample effectively from high-dimensional, multimodal distributions, but their outputs may viola…
Explaining Failures of Cyber-Physical Systems with Actual Causality
arXiv:2606.24546v1 Announce Type: new Abstract: Modern autonomous Cyber-Physical Systems (CPSs), such as self-driving cars, face increasingly complex demands, a…
Wh0: Generative World Models as Scalable Sources of Egocentric Human Hand Manipulation Data
arXiv:2606.22136v2 Announce Type: replace Abstract: Scaling dexterous manipulation requires generalization across objects, scenes, and tasks, yet existing data …
Critique of Agent Model
arXiv:2606.23991v1 Announce Type: cross Abstract: What is an agent? What constitutes agency? With the rise of Large Language Model (LLM) systems marketed as ``c…
From Open Waters to Enclosed Cabins: ProteusVPR for Cross-Scene Visual Place Recognition in Maritime Perception and Cabin Inspection
arXiv:2606.24234v1 Announce Type: cross Abstract: Autonomous robotic inspection in maritime environments presents unique challenges for Visual Place Recognition…
Sim-to-Real Betting on the E-Process: Bringing "simulators" to anytime-valid confidence sequences
arXiv:2606.24038v1 Announce Type: new Abstract: This note describes an integration of the sim-to-real performance estimate with betting (from Chen et al.) and t…
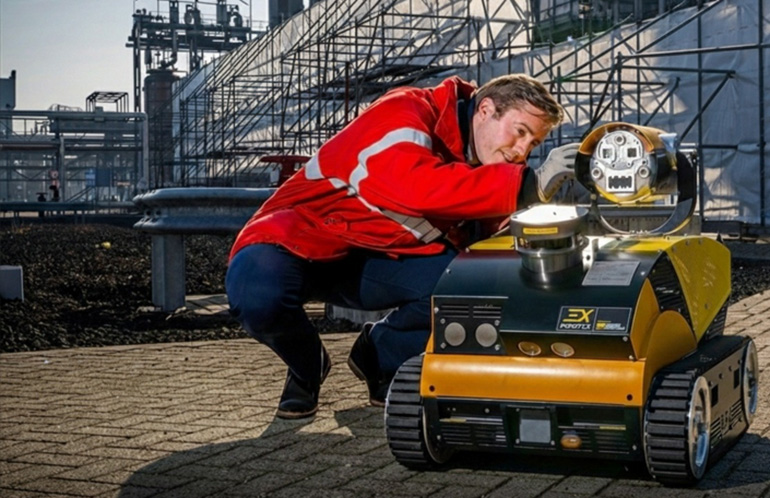
ExRobotics launches UL-certified inspection robot for hazardous environments
ExRobotics says its ExR-2.5 inspection robot is certified for safe operations in explosive environments in North America. The post ExRobotics launches UL-certif…
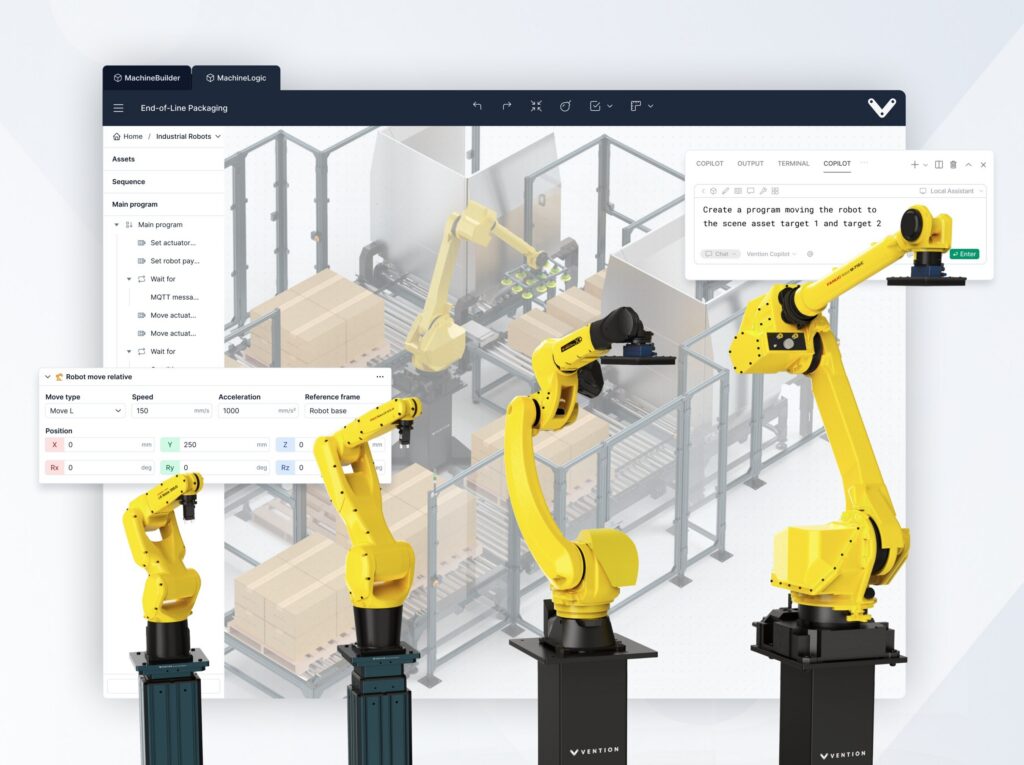
Vention collaborates with FANUC and Universal Robots on software-defined automation
Vention is working with partners to make design and deployment of industrial and collaborative robots easier for manufacturers. The post Vention collaborates wi…

Eclipse Automation launches RealitySync simulation platform
Eclipse said its new RealitySync platform allows manufacturers to step into their future factory before it’s built. The post Eclipse Automation launches Reality…
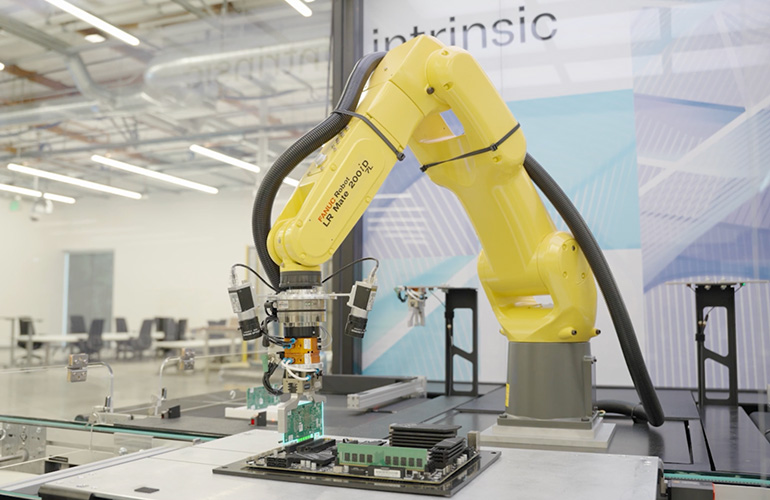
How Intrinsic eliminates manual robot coding
Alphabet’s Intrinsic has debuted its AI-powered "Intelligence Cell" to simplify factory automation and eliminate complex robot programming. The post How Intrins…
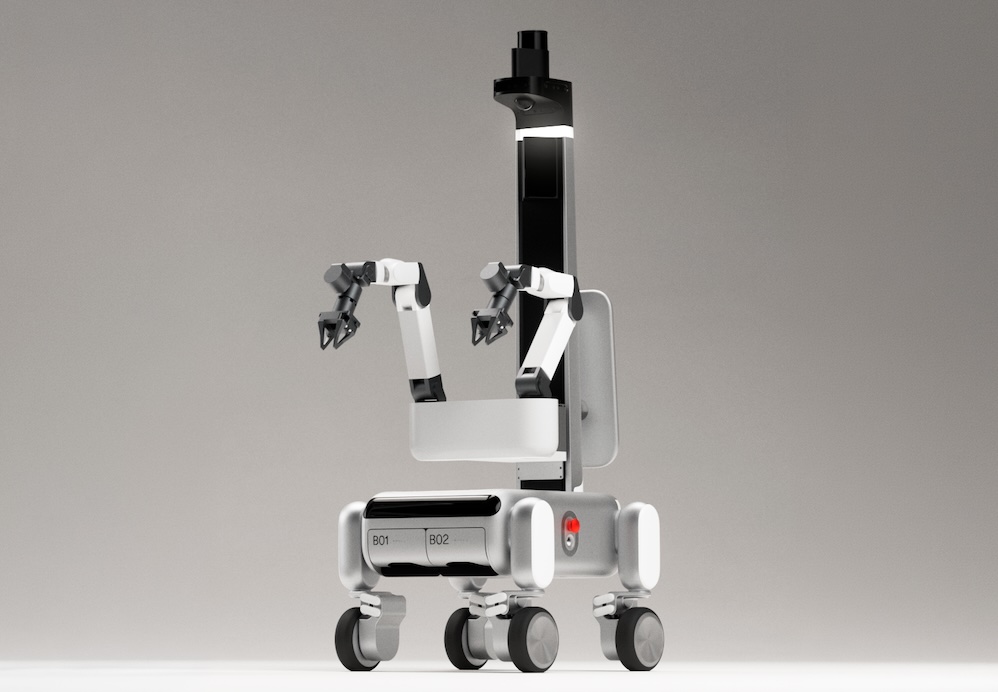
Cobot’s Proxie Gen 2 robot adds autotasking, mobile manipulation
Cobot founder and CEO Brad Porter said Proxie Gen 2 can determine when materials are ready to move, identify destinations, and create tasks without human interv…
NVIDIA releases Halos, a full-stack safety system for robotics
NVIDIA said Halos connects AI compute, system software, sensor data, safety applications, and inspection for robotic systems. The post NVIDIA releases Halos, a …
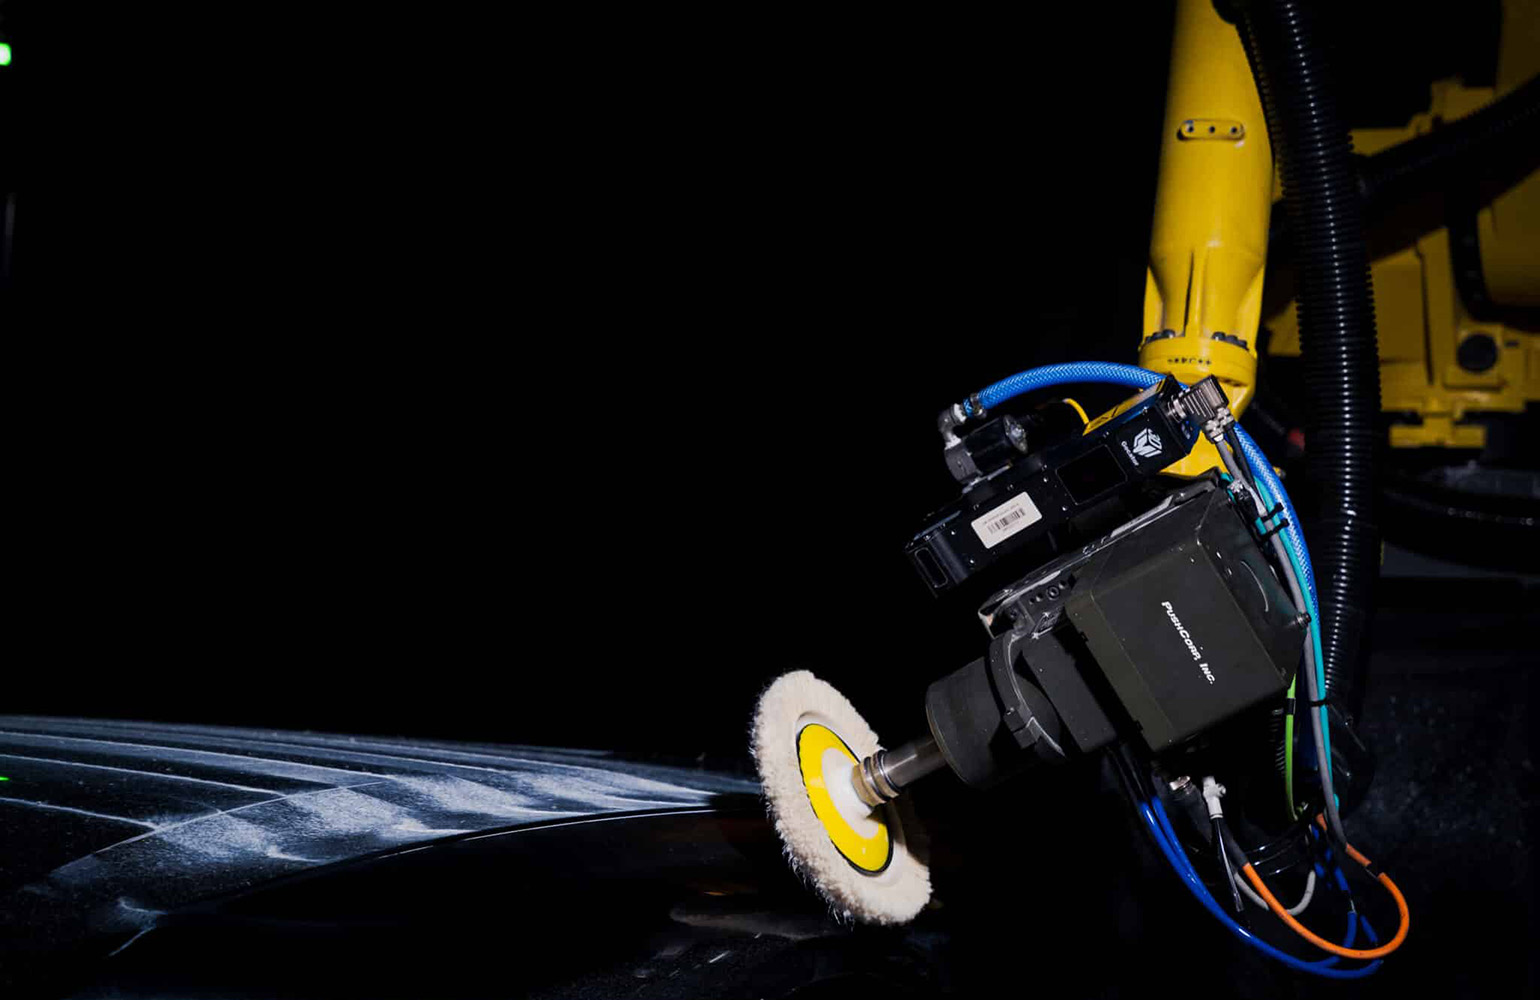
Defense manufacturing readiness hinges on autonomous finishing, says GrayMatter Robotics
The Navy's industrial base review identified a projected need for 174,000 new workers. GrayMatter says robotics can fill this gap. The post Defense manufacturin…
Robot Talk Episode 161 – Collaborative haptic systems, with Allison Okamura
Claire chatted to Allison Okamura from Stanford University about developing advanced robotic systems for haptic (touch) interaction. Allison Okamura is the Rich…
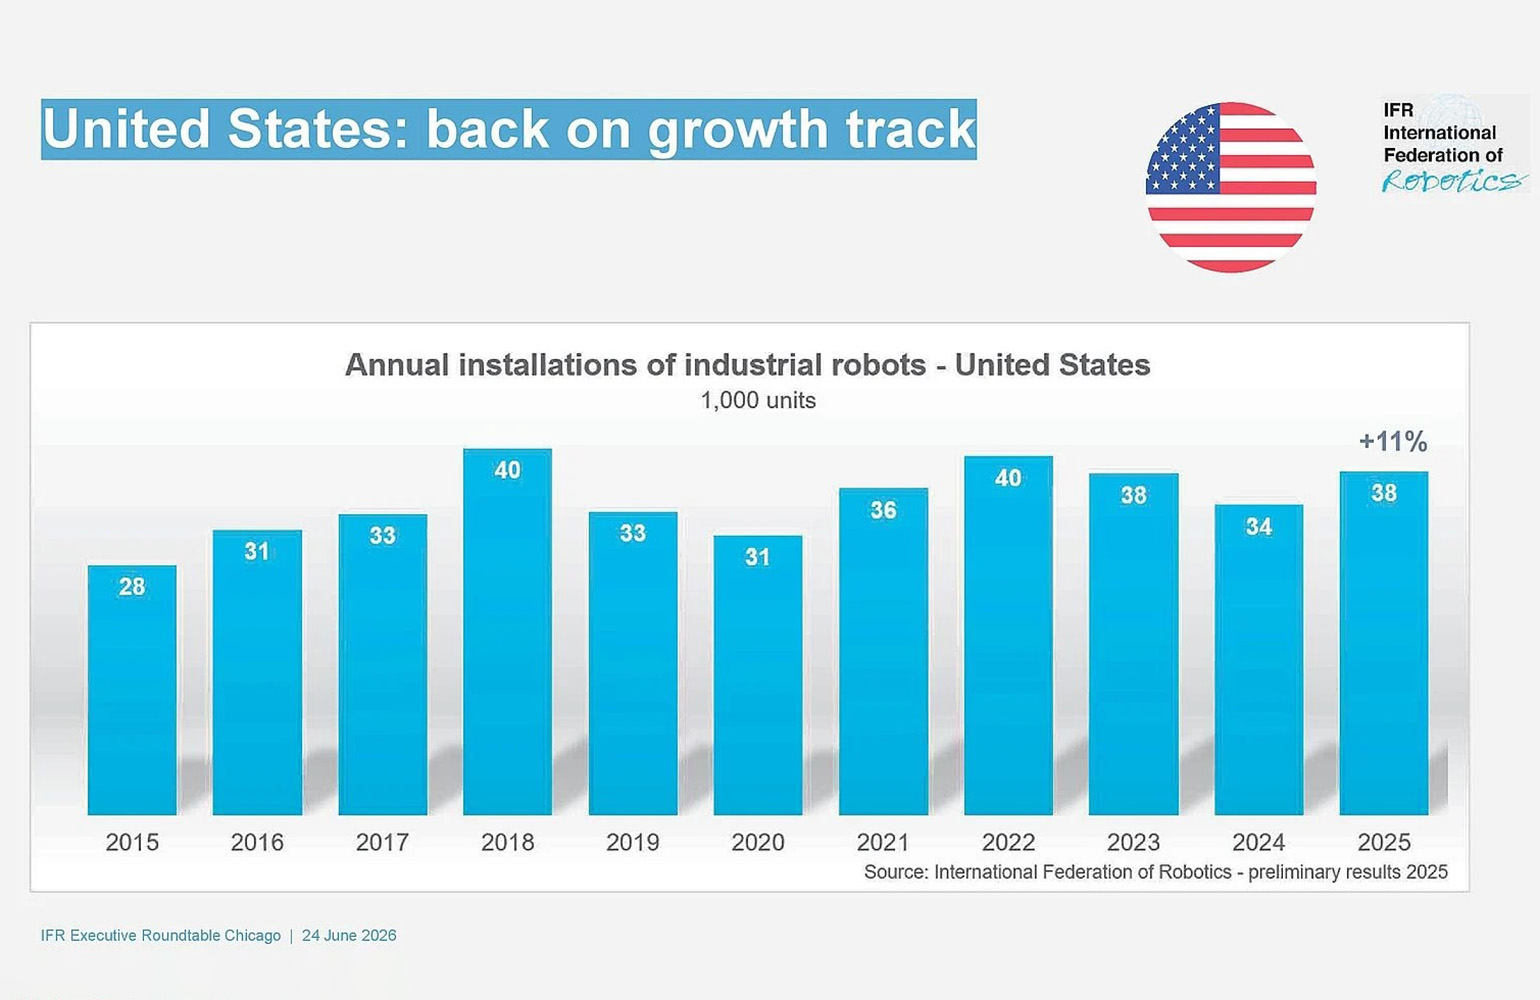
U.S. robotics industry saw double-digit growth in 2025, says IFR
The IFR said robust growth in the food industry and other non-manufacturing sectors drove this recovery in the U.S. robotics industry. The post U.S. robotics in…
Dual-Agent Framework for Cross-Model Verified Translation of Natural-Language Protocols into Robotic Laboratory Platform
arXiv:2606.20120v1 Announce Type: new Abstract: Biological experiment protocols are written in natural language, whereas automation systems rely on predefined c…
WorkBenchMark: A LEGO-Based Assembly Benchmark with an Assembly-by-Disassembly Baseline for the Smart Manufacturing League
arXiv:2606.19358v1 Announce Type: new Abstract: We introduceWorkBenchMark, a LEGO Duplo-based robotic assembly benchmark motivated by the RoboCup Smart Manufact…
Formal Verification of Learned Multi-Agent Communication Policies via Decision Tree Distillation
arXiv:2606.19632v1 Announce Type: new Abstract: Multi-agent reinforcement learning (MARL) enables agents to develop coordination strategies through emergent com…