Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesGroundControl: Anticipating Navigation Failures in Vision-Language Agents via Trajectory-Consistent Uncertainty Estimates
arXiv:2606.20479v1 Announce Type: new Abstract: Vision-language navigation agents achieve competitive average success on benchmark tasks, yet failures often ari…
Robust Assembly State Reasoning from Action Recognition for Human-Robot Collaboration
arXiv:2606.20150v1 Announce Type: new Abstract: Human Action Recognition (HAR) is frequently investigated in Human-Robot Collaboration (HRC) research to underst…
CoLI: A Reproducible Platform for Continuum Robot Learning via Monolithic 3D Printing and Isomorphic Teleoperation
arXiv:2606.20389v1 Announce Type: new Abstract: Continuum robots offer strong potential for manipulation tasks due to their high degrees of freedom, compliant s…
Bistable Quad-Nets Composed of Four-Bar Linkages
arXiv:2604.00527v2 Announce Type: replace-cross Abstract: We study a novel type of mechanical structures, composed of spatial four-bar linkages, that are bistab…
The Token Is a Group Element: On Lie-Algebra Attention over Matrix Lie Groups
arXiv:2606.20547v1 Announce Type: cross Abstract: We place the attention token on the group: a token is an element $g_i$ of a matrix Lie group $G$ -- a bare tra…
RoboSSM: Scalable In-context Imitation Learning via State-Space Models
arXiv:2509.19658v2 Announce Type: replace Abstract: In-context imitation learning (ICIL) enables robots to learn tasks from prompts consisting of just a handful…
BIM Informed Visual SLAM for Construction Environments
arXiv:2509.13972v3 Announce Type: replace Abstract: Monitoring building construction sites requires comparing the as-planned design with the as-built state, whi…
Fail-RAG : A Retrieval Augmented Generation Informed Framework for Robot Failure Identification
arXiv:2606.19598v1 Announce Type: new Abstract: Industry automation is witnessing an evolution in robotics driven by both technological breakthroughs and societ…
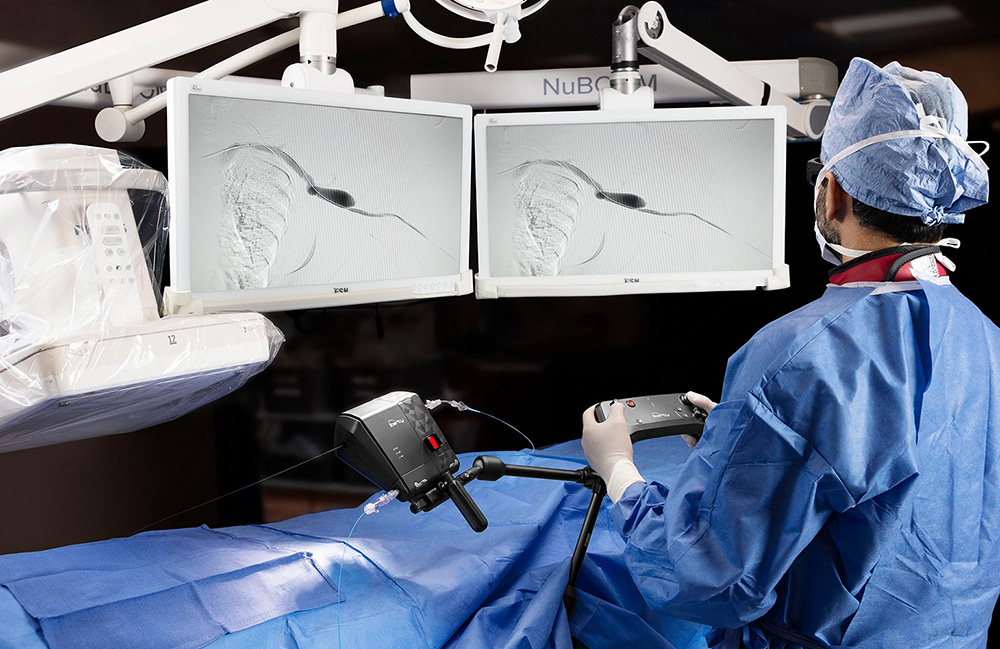
Microbot Medical to expand veteran access to robotic surgery with LIBERTY
Lovell Government Services will become Microbot's service-disabled veteran-owned small business vendor to supply federal programs. The post Microbot Medical to …
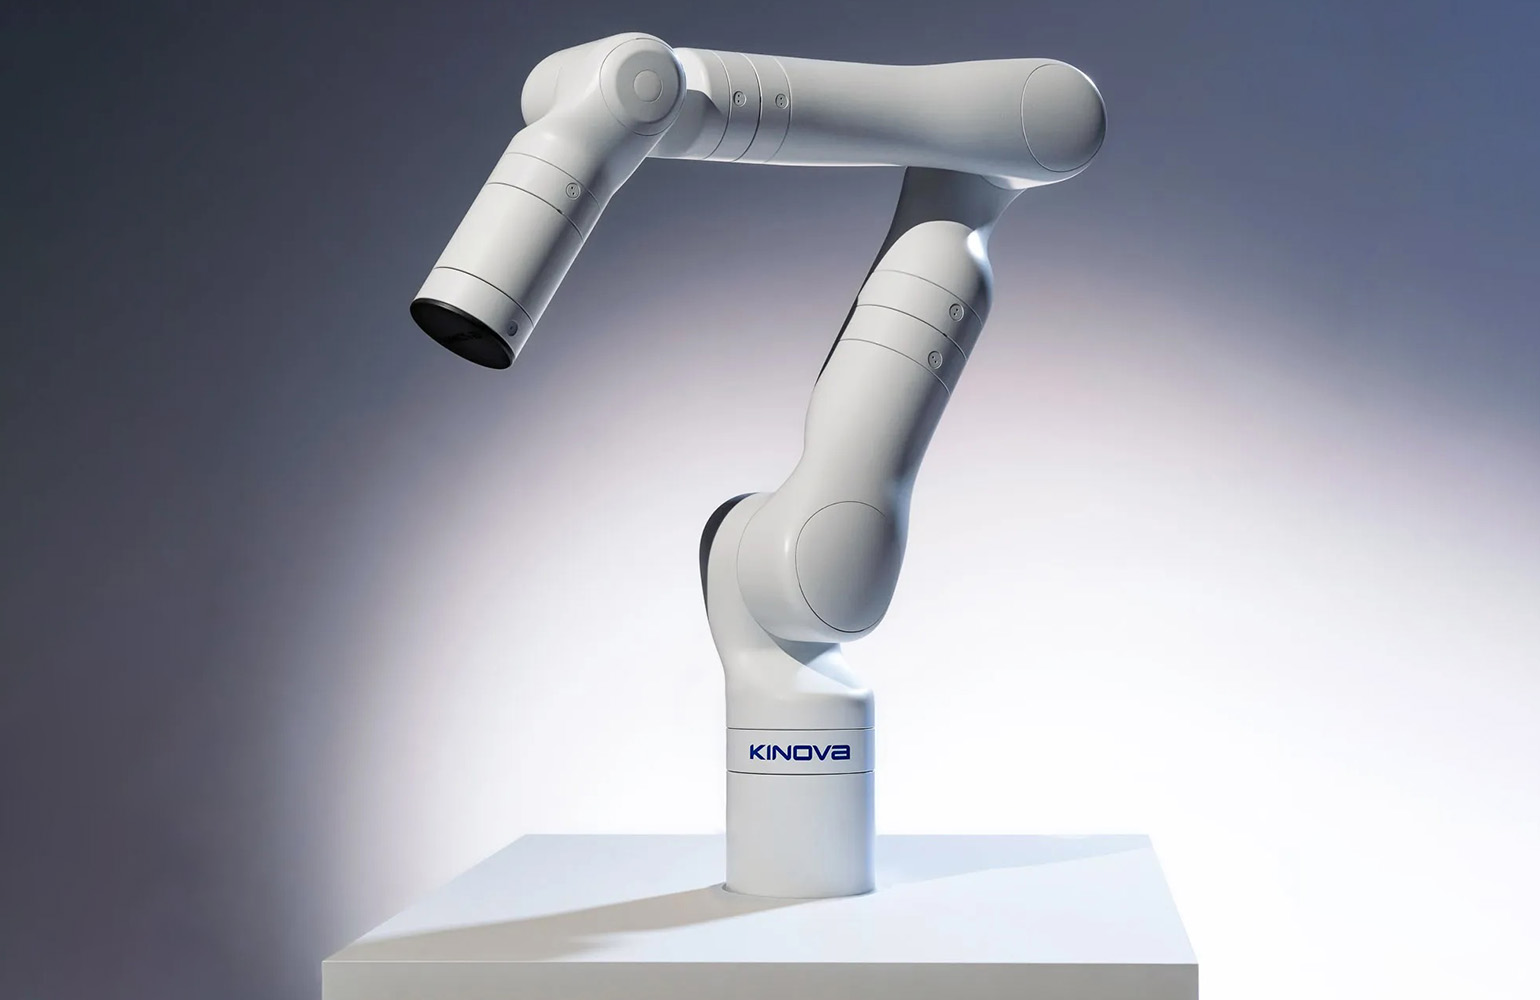
Kinova launches KIMA medical robotic arm
Instead of adapting the robot from industrial technology, Kinova said it designed KIMA from the ground up for clinical use. The post Kinova launches KIMA medica…
Quantile Transfer for Reliable Operating Point Selection in Visual Place Recognition
arXiv:2602.04401v2 Announce Type: replace Abstract: Visual Place Recognition (VPR) is a key component for localisation in Global Navigation Satellite System (GN…
SRL: Combining SLIP Model and Reinforcement Learning for Agile Robotic Jumping
arXiv:2606.18625v1 Announce Type: new Abstract: Robotic jumping is pivotal in applications such as search and rescue and logistics, where crossing obstacles and…
Why Automate This? Exploring Correlations Between Desire for Robotic Automation, Invested Time and Well-Being
arXiv:2501.06348v4 Announce Type: replace-cross Abstract: Understanding the motivations underlying the human inclination to automate tasks is vital for developi…
Enhancing Fatigue Detection through Heterogeneous Multi-Source Data Integration and Cross-Domain Modality Imputation
arXiv:2507.16859v5 Announce Type: replace Abstract: Fatigue detection for human operators is important in safety-related applications such as aviation, mining, …
N(CO)$^2$: Neural Combinatorial Optimization with Chance Constraints to Solve Stochastic Orienteering
arXiv:2606.18514v1 Announce Type: new Abstract: Neural combinatorial optimization (NCO) offers a promising alternative to traditional heuristic-based methods fo…
Monocular 3D Occupancy Perception for Robots on Sidewalks via Hybrid 2D-3D Learning
arXiv:2606.19122v1 Announce Type: new Abstract: Sidewalks in the real world are crowded, cluttered, and less structured than roads, making 3D occupancy predicti…
Admittance-Based Surface Alignment for Human-in-the-Loop Robotic Visual Inspection
arXiv:2606.18601v1 Announce Type: new Abstract: Precision visual inspection underpins quality assurance across aerospace, semiconductor, and medical manufacturi…
ROBOSHACKLES: A Safety Dataset for Human-Injury Prevention in Embodied Foundation Models
arXiv:2606.18632v1 Announce Type: new Abstract: Embodied Foundation Models (EFMs) integrate multimodal understanding, future-state reasoning, and executable rob…
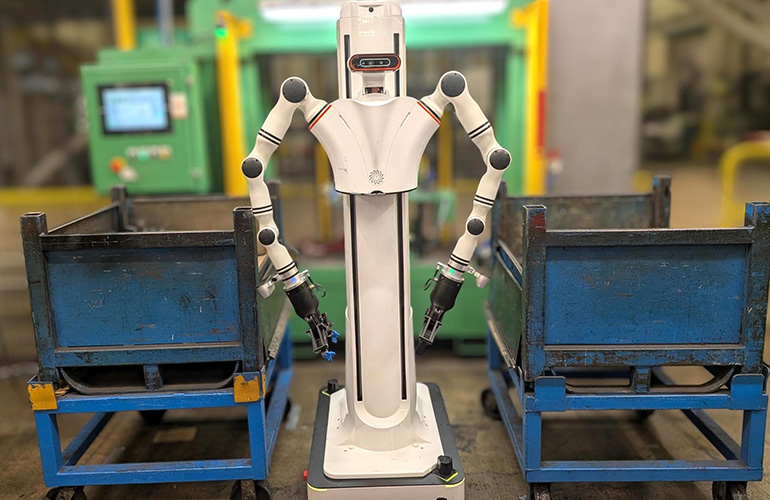
Autonomique deploys semi-humanoid robots and AI at Canadian Tier 1
Autonomique has moved its AI-powered robots from pilot to production at F&P Mfg., with plans for deployment across F-tech's global network. The post Autono…

Evaluating humanoids for surface finishing applications
Manufacturing processes such as sanding, polishing, blasting, grinding, coating, and painting are used in a wide variety of industries. These manufacturing task…
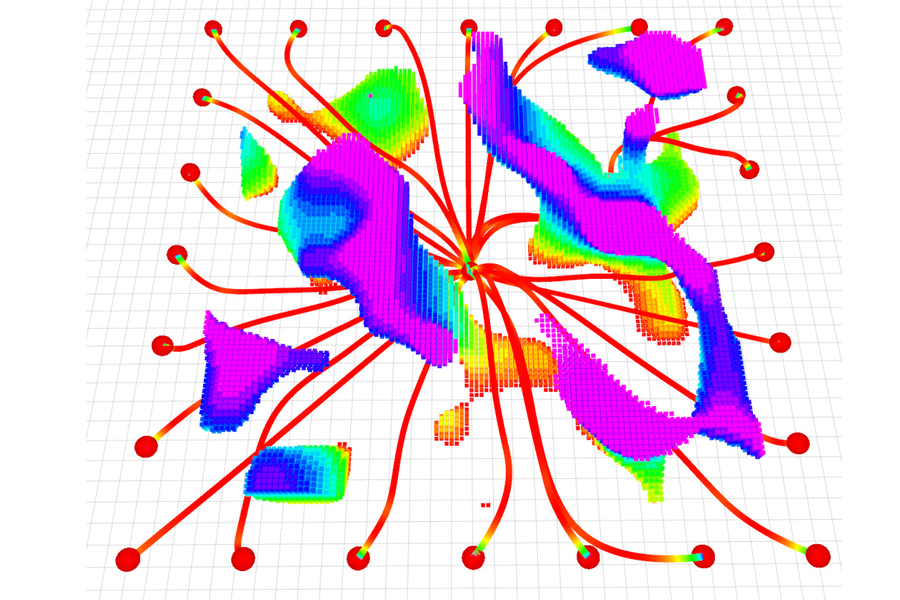
New research enables a robot to chart a better course
By rapidly generating a smooth path plan that cuts travel time and avoids obstacles, the open-source “MIGHTY” system could streamline disaster recovery and parc…
HRDX: A Large-Scale Vector HD-Map Dataset
arXiv:2606.17080v1 Announce Type: new Abstract: Reliable autonomous driving requires vectorized HD maps that are geometrically accurate, semantically rich, and …
EgoInfinity: A Web-Scale 4D Hand-Object Interaction Data Engine for Any-View Robot Retargeting and Video-to-Action Robot Learning
arXiv:2606.17385v1 Announce Type: new Abstract: Internet videos constitute the largest reservoir of embodied human manipulation knowledge, yet converting arbitr…
WireCraft: A Simulation Benchmark for Industrial DLO Manipulation
arXiv:2606.18097v1 Announce Type: new Abstract: Deformable Linear Objects (DLOs), such as wires and cables, are central to industrial assembly. Unlike rigid obj…
Extracting Semantics: LLM-Guided Automatic Population of Robot Ontology from URDF
arXiv:2606.17073v1 Announce Type: new Abstract: While commonsense knowledge may suffice for virtual agents, embodied robots interacting with humans require grou…
Beyond Benchmarks: Continuous Edge Inference for Fine-Grained Roadside Perception
arXiv:2606.17241v1 Announce Type: cross Abstract: Continuous AI inference on resource-constrained edge hardware introduces deployment effects that are largely i…
OpenTie: Open-vocabulary Sequential Rebar Tying System
arXiv:2509.00064v2 Announce Type: replace Abstract: Robotic practices on the construction site emerge as an attention-attracting manner owing to their capabilit…
Can Vision Foundation Models Navigate? Zero-Shot Real-World Evaluation and Lessons Learned
arXiv:2603.25937v2 Announce Type: replace Abstract: Visual Navigation Models (VNMs) promise generalizable, robot navigation by learning from large-scale visual …
SimTO: A two-stage, simulation-driven topology optimization framework for bespoke soft robotic grippers
arXiv:2601.19098v2 Announce Type: replace Abstract: Soft robotic grippers are essential for grasping delicate, geometrically complex objects in manufacturing, h…
Contactless Respiratory Monitoring on Heterogeneous Mobile Robots: A Multimodal Edge-Computing Framework
arXiv:2606.17376v1 Announce Type: new Abstract: Respiratory-rate (RR) monitoring is a critical component of remote triage and victim assessment in emergency res…