Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesLearning from Mistakes: Rollout-Retrieval Lifelong Policy Learning for Autonomous Driving
arXiv:2606.30537v1 Announce Type: new Abstract: Autonomous driving policies should be able to improve continually as deployment exposes them to increasingly div…
LNN-Fly: Continuous-Time UAV Navigation for Robust Obstacle Avoidance under Timing Mismatch
arXiv:2606.28827v1 Announce Type: new Abstract: End-to-end unmanned aerial vehicle (UAV) navigation can achieve impressive agility in simulation, yet its obstac…
MOAR Planner: Multi-Objective and Adaptive Risk-Aware Path Planning for Infrastructure Inspection with a UAV
arXiv:2606.30575v1 Announce Type: new Abstract: The problem of autonomous navigation for UAV inspection remains challenging as it requires effectively navigatin…
He3-Seeker: Robotic Information Planning for Lunar Helium-3 Distribution Mapping
arXiv:2606.28746v1 Announce Type: new Abstract: Lunar helium-3 is a highly valuable strategic resource, pivotal to the advancement of both deep-space exploratio…
AsyncMDE: Real-Time Monocular Depth Estimation via Asynchronous Spatial Memory
arXiv:2603.10438v2 Announce Type: replace Abstract: Foundation-model-based monocular depth estimation offers a viable alternative to active sensors for robot pe…
Learning to Throw: Agile and Accurate Cable-Suspended Payload Delivery with a Quadrotor
arXiv:2606.27603v1 Announce Type: new Abstract: Quadrotors offer the agility needed to rapidly transport suspended payloads during time-critical applications, i…
AI-Driven Synthesis for High-Tech System Design: Automating Innovation
arXiv:2606.28126v1 Announce Type: cross Abstract: This article addresses the combinatorial complexity inherent in modern high-tech system design by presenting a…
Drifting in the Future: Stabilizing Path Following Drifting on High-Latency Vehicle Systems
arXiv:2606.27914v1 Announce Type: new Abstract: Autonomously controlling and handling a vehicle at and beyond its stability limit is a mathematically and comput…
MobileManiBench: Simplifying Model Verification for Mobile Manipulation
arXiv:2602.05233v2 Announce Type: replace Abstract: Vision-language-action models have advanced robotic manipulation but remain constrained by reliance on the l…
SpikeVLA: Vision-Language-Action Models with Spiking Neural Networks
arXiv:2606.27807v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have become a dominant paradigm for embodied intelligence. However, most exi…
Driver-WM: A Driver-Centric Traffic-Conditioned Latent World Model for In-Cabin Dynamics Rollout
arXiv:2605.05092v2 Announce Type: replace Abstract: Safe L2/L3 driving automation requires anticipating human-in-the-loop reactions during shared-control transi…
LocalNav: Distilling Frontier VLMs and Embodied RL for On-Device Object Goal Navigation
arXiv:2606.27871v1 Announce Type: new Abstract: Vision Language Models (VLMs) have emerged in the robotic domain as a powerful tool that enables environmental p…
SimFoundry: Modular and Automated Scene Generation for Policy Learning and Evaluation
arXiv:2606.28276v1 Announce Type: new Abstract: Training and evaluating robot policies in the real world is costly and difficult to scale. We introduce SimFound…
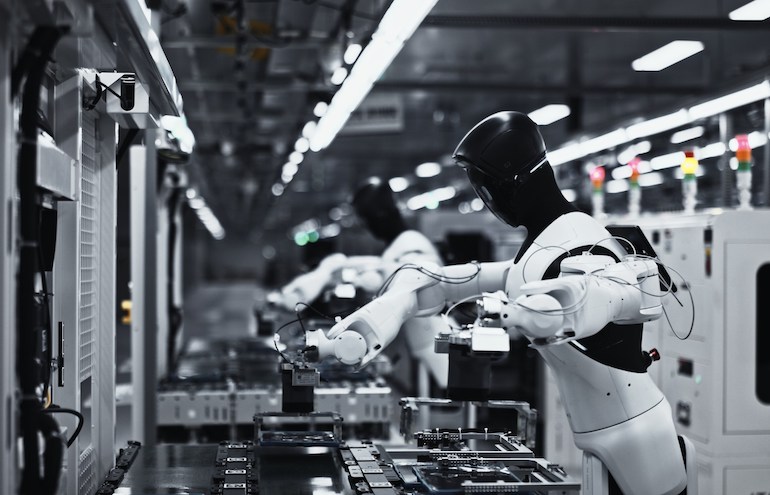
AGIBOT produces 15,000th robot, marking a milestone in embodied AI deployment
AGIBOT has rolled out 15,000 wheeled semi-humanoid robots as it moves from embodied AI from development and production to deployment. The post AGIBOT produces 1…
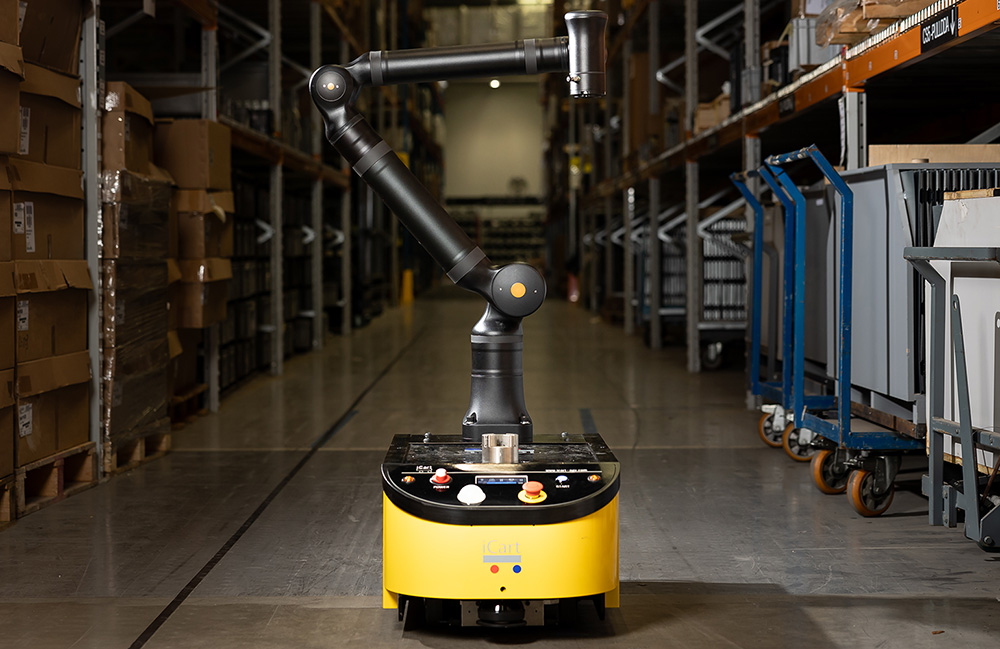
How compact cobot integration enhances autonomous mobile robot applications
Cobots are quickly shaping the future of warehousing, with their use rising 10-fold from 2018 to 2025, Kassow said. The post How compact cobot integration enhan…
We know how to build smarter robots. Now, we need to learn smarter ways to test them
Atharv Kolhar, a staff test automation engineer at Figure AI, says the robotics industry needs a testing philosophy that scales alongside autonomy. The post We …
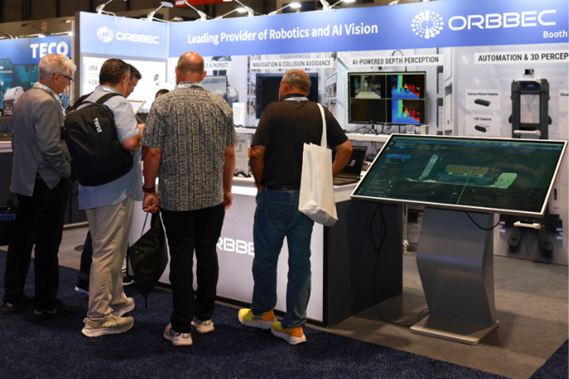
Orbbec shows AI-powered vision systems at Automate 2026
Orbbec presented industrial-grade 3D cameras for challenging automation scenarios, as well as AI integration for enhanced robotic perception. The post Orbbec sh…
Robot Talk Episode 162 – The robot doctor will see you now
Since the first robot-assisted surgery was performed, over 40 years ago, major advances in robotics, computer vision and artificial intelligence have fundamenta…
Play2Perfect: What Matters in Dexterous Play Pretraining for Precise Assembly?
arXiv:2606.26428v1 Announce Type: new Abstract: Multi-fingered robots promise the speed and dexterity of human hands, yet challenging problems such as precise a…
CycleRL: Sim-to-Real Deep Reinforcement Learning for Robust Autonomous Bicycle Control
arXiv:2603.15013v3 Announce Type: replace Abstract: Autonomous bicycles offer a promising agile solution for urban mobility and last-mile logistics. However, co…
Tactile-WAM: Touch-Aware World Action Model with Tactile Asymmetric Attention
arXiv:2606.26663v1 Announce Type: new Abstract: World Action Models (WAMs) generate actions together with predicted futures, offering a powerful interface for r…
Continual Robot Policy Learning via Variational Neural Dynamics
arXiv:2606.27353v1 Announce Type: new Abstract: Robots deployed in the real world rarely operate under a single fixed dynamics model: wind changes, payloads var…
Proposal-Conditioned Latent Diffusion for Closed-Loop Traffic Scenario Generation
arXiv:2606.27123v1 Announce Type: new Abstract: Closed-loop traffic simulation remains challenging because it must generate interactive multi-agent behaviors th…
RouterVLA: Turning Smoke Tests into Supervision for Heterogeneous VLA Selection
arXiv:2606.27355v1 Announce Type: new Abstract: We study whether pre-deployment evaluation rollouts can be reused to supervise policy selection. Robot teams rou…
RobOralScan: Learning Active Intraoral Scanning for Robotic Dental Reconstruction
arXiv:2606.26955v1 Announce Type: new Abstract: Intraoral scanning is widely used for digital optical impressions in prosthodontic, implant, and orthodontic tre…
ForesightSafety-VLA: A Unified Diagnostic Safety Benchmark for Vision-Language-Action Models
arXiv:2606.27079v1 Announce Type: new Abstract: In embodied intelligence, safety is a prerequisite for reliable robot deployment in the physical world. Current …
Real-Time Safety Evaluation of Human Arm Operations Using a Wrist-Mounted IMU with PSM System
arXiv:2502.09241v2 Announce Type: replace Abstract: This paper presents a novel approach to real-time safety monitoring in human-robot collaborative manufacturi…
Reinforcement Learning Enables Autonomous Microrobot Navigation and Intervention in Simulated Blood Capillaries
arXiv:2606.26154v1 Announce Type: new Abstract: Autonomous microrobots navigating biological vasculature could enable targeted drug delivery and thrombolysis, y…
History-Conditioned Spatio-Temporal Visual Token Pruning for Efficient Vision-Language Navigation
arXiv:2603.06480v2 Announce Type: replace Abstract: Vision-Language Navigation (VLN) enables robots to follow natural-language instructions in visually grounded…
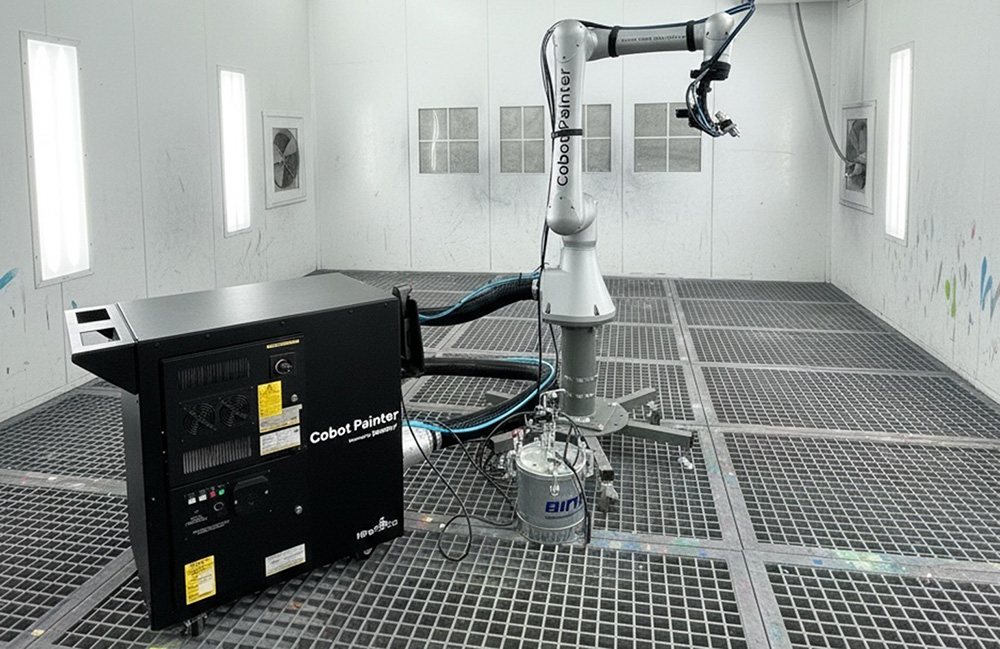
Hirebotics offers no-code, explosion-proof cobot for painting
Hirebotics' Cobot Painter supports stationary painting, with parts placed in a paint booth where robots perform all spraying operations. The post Hirebotics off…