Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesRule-VLN: Bridging Perception and Compliance via Semantic Reasoning and Geometric Rectification
arXiv:2604.16993v2 Announce Type: replace-cross Abstract: As embodied AI transitions to real-world deployment, the success of the Vision-and-Language Navigation…
RoboWorld: Fast and Reliable Neural Simulators for Generalist Robot Policy Evaluation
arXiv:2607.01060v1 Announce Type: new Abstract: Video world models are emerging as a scalable alternative for evaluating generalist robot policies, bypassing th…
A Unified Benchmark for RCM-Constrained Visual Servoing: Modeling-Controller Interaction and Robustness Analysis in Laparoscopic Robots
arXiv:2607.00030v1 Announce Type: new Abstract: In robot-assisted laparoscopic minimally invasive surgery (MIS), accurate enforcement of the remote center of mo…
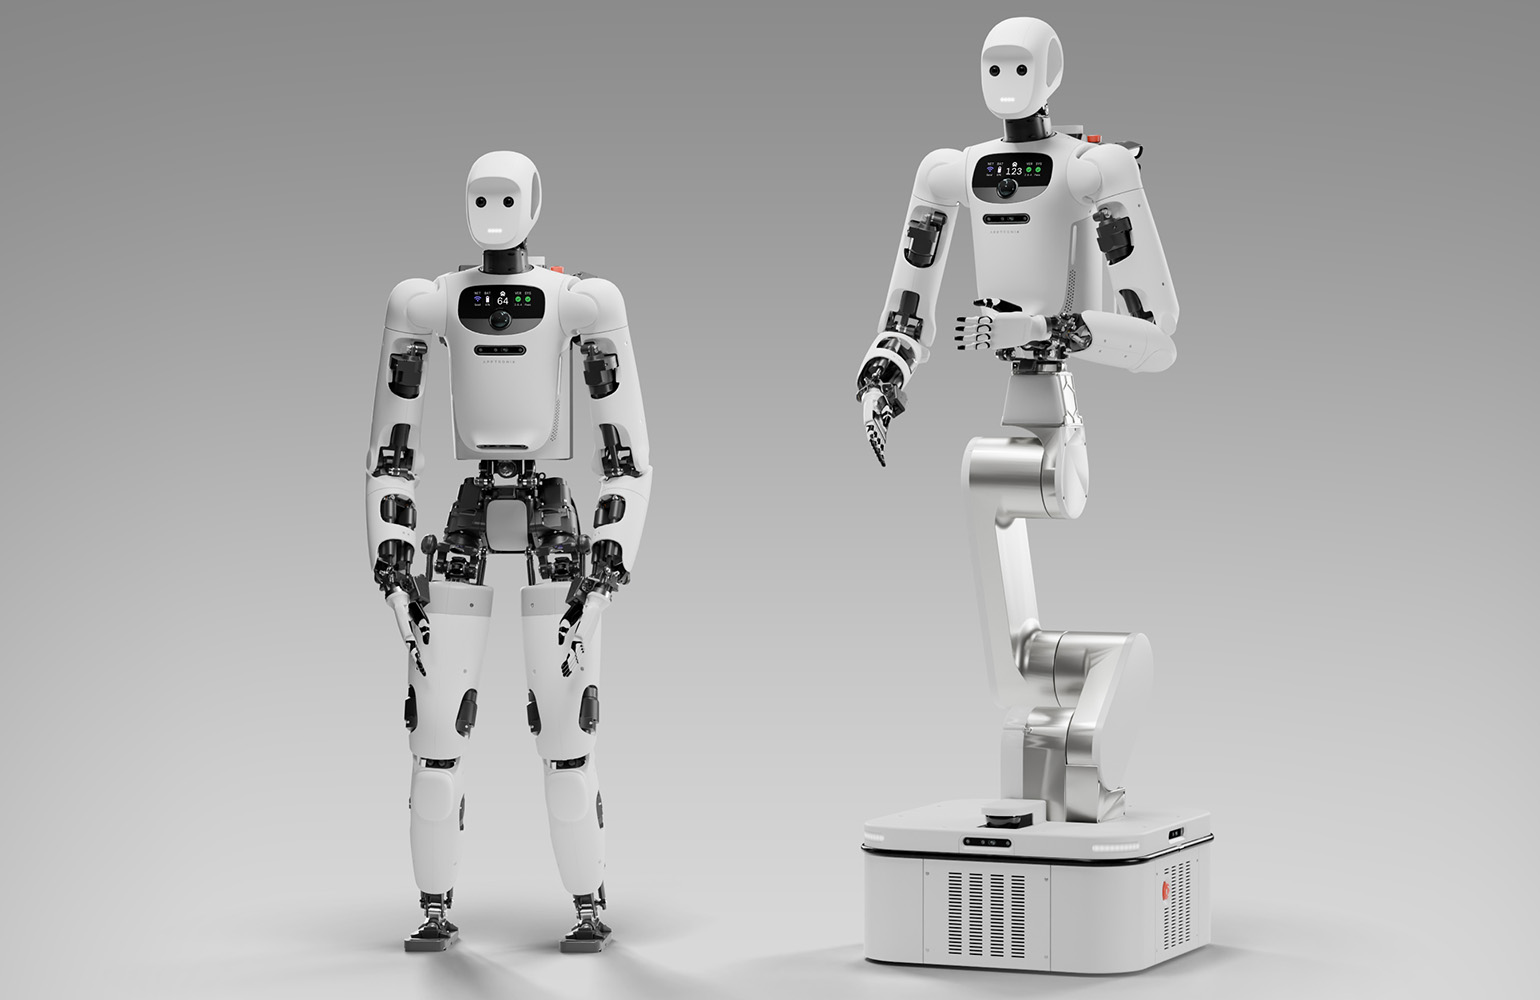
Apptronik unveils Apollo 2 and a flagship data collection and training facility
Built as a data collection and training platform, Apollo 2 enables continuous learning through deployment, Apptronik said. The post Apptronik unveils Apollo 2 a…
Hierarchical 3D Scene Graph Construction and Belief-based Planning for Semantic Navigation
arXiv:2606.31071v1 Announce Type: cross Abstract: Semantic navigation is a fundamental task for embodied agents operating in unseen environments, requiring both…
RhinoVLA Technical Report
arXiv:2606.07383v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models have shown strong potential for robotic manipulation, but real-time depl…
FalconApp: Rapid iPhone Deployment of End-to-End Perception via Automatically Labeled Synthetic Data
arXiv:2604.25949v2 Announce Type: replace Abstract: Reliable perception for robotics depends on large-scale labeled data, yet real-world datasets rely on heavy …
RRT-Rope: A deterministic shortening approach for fast near-optimal path planning in large-scale uncluttered 3D environments
arXiv:2606.31948v1 Announce Type: new Abstract: Many path planning algorithms have been introduced so far, but most are costly, in path cost and in processing t…
Multimodal Benchmark for Safety Assessment in Industrial Inspection Scenarios
arXiv:2601.21173v2 Announce Type: replace Abstract: With the rapid development of industrial intelligence and unmanned inspection, reliable perception and safet…
Prompting Robot Teams with Natural Language
arXiv:2509.24575v2 Announce Type: replace Abstract: This paper presents a framework to prompt multi-robot teams with high-level tasks using natural language exp…
Locker-based Truck-Drone Routing with Integrated Considerations of Pickups, Deliveries, and No-Fly Zones
arXiv:2606.30680v1 Announce Type: new Abstract: Truck-drone delivery is an emerging last-mile logistics mode combining the long-haul capacity of trucks with the…
Labimus: A Simulation and Benchmark for Humanoid Dexterous Manipulation in Chemical Laboratory
arXiv:2606.31037v1 Announce Type: new Abstract: Laboratory automation has made remarkable progress through robotic platforms and AI-driven scientific reasoning.…
Robust Autonomous UAV Landing on Maritime Platforms via Multimodal Agentic AI and Active Wave Compensation
arXiv:2606.31613v1 Announce Type: cross Abstract: Autonomous aerial inspection of marine infrastructure is frequently compromised by stochastic sea states, intr…
Receptogenesis in a Vascularized Robotic Embodiment
arXiv:2603.09473v3 Announce Type: replace Abstract: Equipping robotic systems with the capacity to generate $\textit{ex novo}$ hardware during operation extends…
Scenario Generation for Testing of Autonomous Driving Systems Using Real-World Failure Records
arXiv:2606.31131v1 Announce Type: cross Abstract: To ensure safe on-road behavior, pre-deployment testing and failure discovery of Autonomous Driving Systems (A…
Breaking the Epistemic Trap: Active Perception Under Compound Uncertainty
arXiv:2605.26627v2 Announce Type: replace-cross Abstract: Deploying reinforcement learning in safety critical domains, from autonomous vehicles to medical decis…
Behavior Uncloning: Distilling Mode Redirection into Policy Weights without Inference-Time Steering
arXiv:2606.29201v1 Announce Type: new Abstract: Behavior-cloned policies often learn multiple behavior modes from demonstration datasets, including modes that a…
RocketSmith: Agentic Additive Manufacturing of High-Powered Rockets
arXiv:2606.00097v3 Announce Type: replace Abstract: RocketSmith is an agentic system which intelligently automates the DFAM process for the development of high …
A Query-Driven Communication-Efficient Digital Twins Design for Autonomous Driving
arXiv:2606.28384v1 Announce Type: new Abstract: Digital twins (DTs) have become a potential technology to perform risk-free simulation of physical entities for …
Real-time Rendering-based Surgical Instrument Tracking via Evolutionary Optimization
arXiv:2603.11404v3 Announce Type: replace Abstract: Accurate and efficient tracking of surgical instruments is fundamental for Robot-Assisted Minimally Invasive…
WoVR: World Models as Reliable Simulators for Post-Training VLA Policies with RL
arXiv:2602.13977v2 Announce Type: replace Abstract: Reinforcement learning (RL) promises to unlock capabilities beyond imitation learning for Vision--Language--…
GaRLILEO: Gravity-aligned Radar-Leg-Inertial Enhanced Odometry
arXiv:2511.13216v2 Announce Type: replace Abstract: Deployment of legged robots for navigating challenging terrains (e.g., stairs, slopes, and unstructured envi…
Critical Interval MSE: Toward Reliable Offline Validation for Robot Manipulation Policies
arXiv:2606.29898v1 Announce Type: new Abstract: Real-world evaluation is the gold standard for robot policies because it tests them against the physical conditi…
Auditing LLM-Governed Social Robots with Culture-Specific Moral Gradients
arXiv:2606.28345v1 Announce Type: new Abstract: LLM-governed social robots increasingly decide who receives real-world assistance first. As prioritization norms…
Trajectory Optimization for Collision-Aware Redundant Robotic Multi-Axis Additive Manufacturing by Constrained Gradient Projection
arXiv:2606.29766v1 Announce Type: new Abstract: Redundant robotic multi-axis additive manufacturing (MAAM) enables support-free and conformal fabrication, but t…
DRIVE-Nav: Directional Reasoning, Inspection, and Verification for Efficient Open-Vocabulary Navigation
arXiv:2603.28691v2 Announce Type: replace Abstract: Open-Vocabulary Object Navigation (OVON) requires an embodied agent to locate a language-specified target in…
BioProVLA-Agent: An Affordable, Protocol-Driven, Vision-Enhanced VLA-Enabled Embodied Multi-Agent System with Closed-Loop-Capable Reasoning for Biological Laboratory Manipulation
arXiv:2605.07306v2 Announce Type: replace Abstract: Biological laboratory automation can reduce repetitive manual work and improve reproducibility, but reliable…
AERIS: Aerial-Edge Role-Driven Intelligence at Runtime via Orchestrated Language-Model Swarm
arXiv:2606.30151v1 Announce Type: new Abstract: Integrating large language models into robotic systems holds promise for enhancing autonomy, yet practical deplo…
CSAR: Containerized System Architecture for Robotics
arXiv:2606.30293v1 Announce Type: new Abstract: Robotic applications increasingly rely on distributed computational infrastructures that combine embedded device…
Vision-Language-Action Models: Experimental Insights from a Real-World UR5 Platform
arXiv:2606.30456v1 Announce Type: new Abstract: This project investigates whether recent Vision-Language-Action (VLA) models can be transferred from controlled …