Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesTiROD: Tiny Robotics Dataset and Benchmark for Continual Object Detection
arXiv:2409.16215v4 Announce Type: replace Abstract: Detecting objects with visual sensors is crucial for numerous mobile robotics applications, from autonomous …
Closing the Reality Gap: Zero-Shot Sim-to-Real Deployment for Dexterous Force-Based Grasping and Manipulation
arXiv:2607.04940v1 Announce Type: new Abstract: Human-like dexterous hands with multiple fingers offer human-level manipulation capabilities but remain difficul…
MOSAIC: Modular Scalable Autonomy for Intelligent Coordination of Heterogeneous Robotic Teams
arXiv:2601.23038v3 Announce Type: replace Abstract: Mobile robots have become indispensable for exploring hostile environments, such as in space or disaster rel…
Sample-Efficient Pareto Front Modeling for Energy-Aware Reinforcement Learning Using Bayesian Optimization
arXiv:2607.03140v1 Announce Type: cross Abstract: Industrial automation increasingly demands control strategies that balance operational performance with strict…
SurgAM: Surgical Affordance Map Prediction with Multimodal Feature Fusion for Robot Autonomy
arXiv:2607.04378v1 Announce Type: new Abstract: Surgical automation is being increasingly studied, yet bridging visual scene understanding with autonomous actio…
MorphQuad: Morphable Quadrotor for Superhuman Maneuverability, Manipulation, and Resiliency
arXiv:2607.02764v1 Announce Type: new Abstract: Infrastructure maintenance, contact-based inspection, and emergency response can benefit from aerial vehicles th…
SLAM: Structured and Localized Analytic Manifold Adaptation for Lifelong VPR
arXiv:2607.04764v1 Announce Type: new Abstract: Visual Place Recognition (VPR) in lifelong deployment requires continuous adaptation to new environments without…
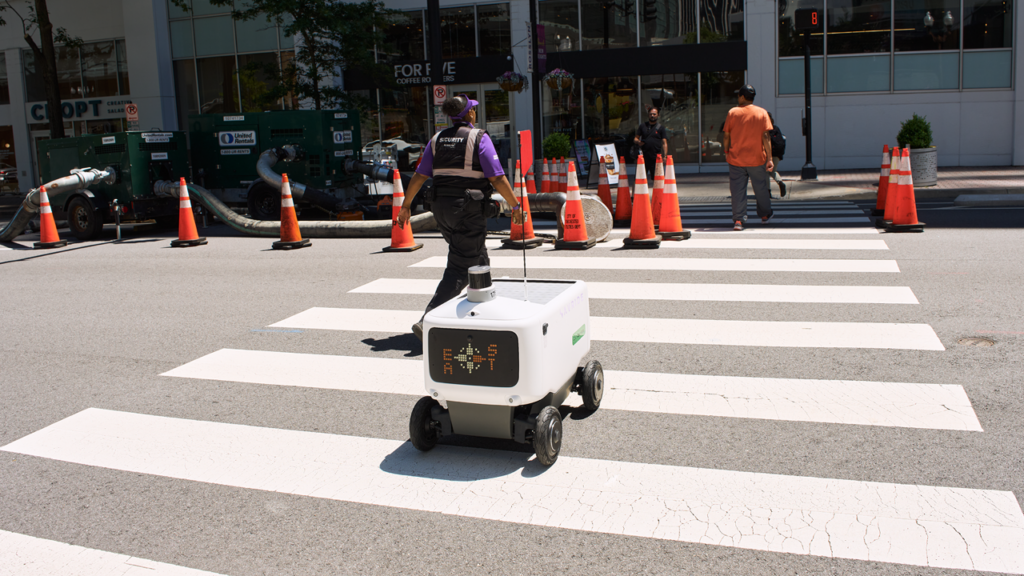
Context is king: How Avride uses cloud VLMs as a safety net for delivery robots
Avride uses vision-language models, or VLMs, to improve the environmental awareness of its delivery robots. The post Context is king: How Avride uses cloud VLMs…
Simulation Based Reward Function Validation for Multi-Agent On Orbit Inspection
arXiv:2607.01367v1 Announce Type: cross Abstract: A proposed method for the control of groups of inspection spacecraft is Multi-Agent Reinforcement Learning (MA…
Embodied.cpp: A Portable Inference Runtime of Embodied AI Models on Heterogeneous Robots
arXiv:2607.02501v1 Announce Type: new Abstract: Embodied AI models now span vision-language-action (VLA) models and world-action models (WAMs), but practical de…
Cross-Platform Control for Autonomous Surface Vehicles via Adaptive Reinforcement Learning
arXiv:2607.02037v1 Announce Type: new Abstract: Autonomous surface vehicles vary widely in hydrodynamic and actuation characteristics, yet most controllers are …
Robust Image Processing Techniques for Construction Environment Monitoring Using Underwater Robots
arXiv:2607.01915v1 Announce Type: cross Abstract: This paper proposes a robust image processing framework for underwater robot-based construction environment mo…
NEUROSYMLAND: Neuro-Symbolic Landing-Site Assessment for Robust and Edge-Deployable UAV Autonomy
arXiv:2607.02277v1 Announce Type: new Abstract: Safe landing-site assessment in unstructured environments remains a key challenge for autonomous UAV deployment,…
Imagining the Sense of Touch: Touch-Informed Manipulation via Imagined Tactile Representations
arXiv:2607.01684v1 Announce Type: new Abstract: Tactile sensing can substantially improve contact-rich robotic manipulation, yet its practical deployment remain…
Episodic-to-Semantic Consolidation Without Identity Drift
arXiv:2607.01988v1 Announce Type: cross Abstract: Long-running adaptive intelligent agents face a structural tension between knowledge consolidation and informa…
DL-VINS-Factory: A Modular Framework for Learned Visual Front-Ends in Visual-Inertial SLAM
arXiv:2607.01757v1 Announce Type: cross Abstract: Deep-learning features excel in visual matching, yet their practical value in tightly coupled visual-inertial …
CoFL-S: Spatially Queryable Sector Flow Fields for Local Language-Conditioned Navigation
arXiv:2607.02222v1 Announce Type: new Abstract: Vision-Language Navigation has increasingly emphasized high-level instruction reasoning, memory, global map cons…
Neuro-Symbolic Safety Guidance for Vision-Language-Action Models via Constrained Flow Matching
arXiv:2607.01378v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have demonstrated promising generalization capabilities across robotic manip…
Lightweight Safe Reinforcement Learning for End-to-End UAV Navigation
arXiv:2607.01794v1 Announce Type: new Abstract: With the rapid development of autonomous aerial systems, Unmanned Aerial Vehicles (UAVs) are increasingly deploy…
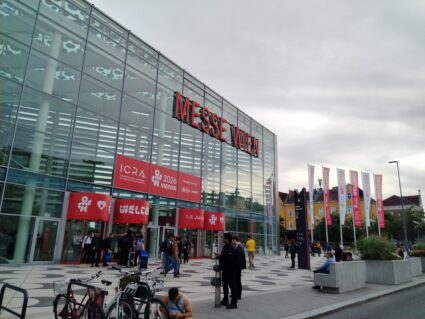
Reflections from ICRA 2026
From the 1st-5th June, the robots descended on Vienna. The 2026 IEEE International Conference on Robotics & Automation (ICRA) brought together the top minds…
Robotics Deployment & Automation: Docker, Kubernetes, and CI/CD Pipelines for Robot Systems (2026 Guide)
Luxonis closes Series A round to scale physical AI perception layer
Luxonis said it plans to scale production of its OAK camera and refine its platform to support robotics and industrial automation. The post Luxonis closes Serie…
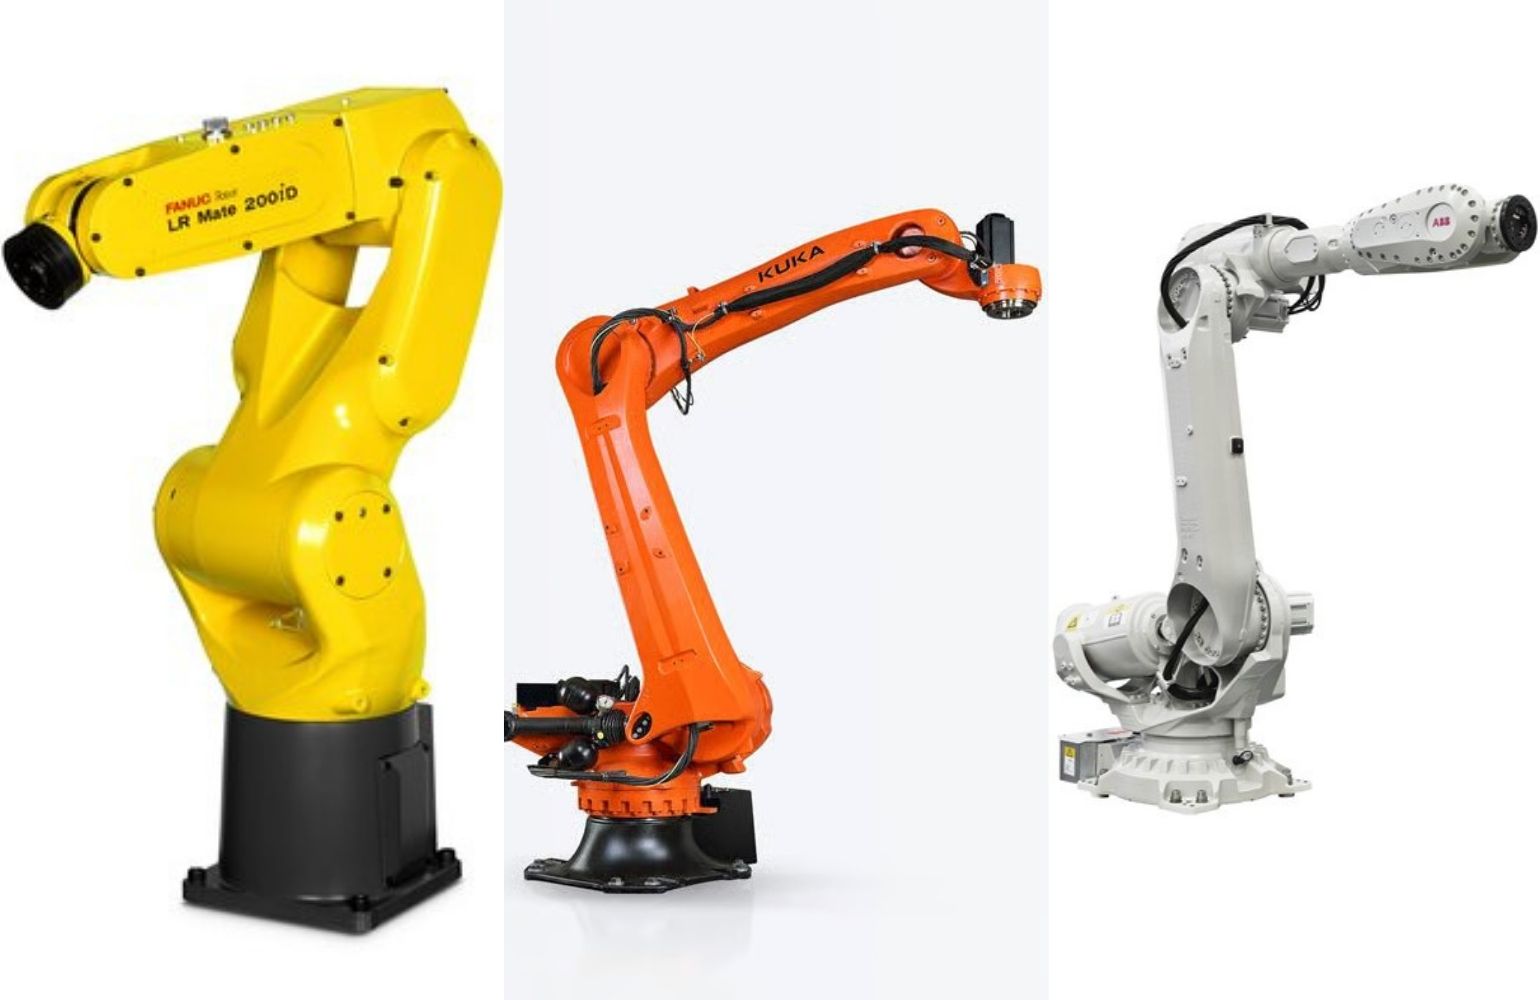
Why you should combine robot dexterity with mechanical positioning for complex assembly operations
Experts are recognizing the importance of mechanical positioning and its impact on the machine’s mobility, range and speed. The post Why you should combine robo…
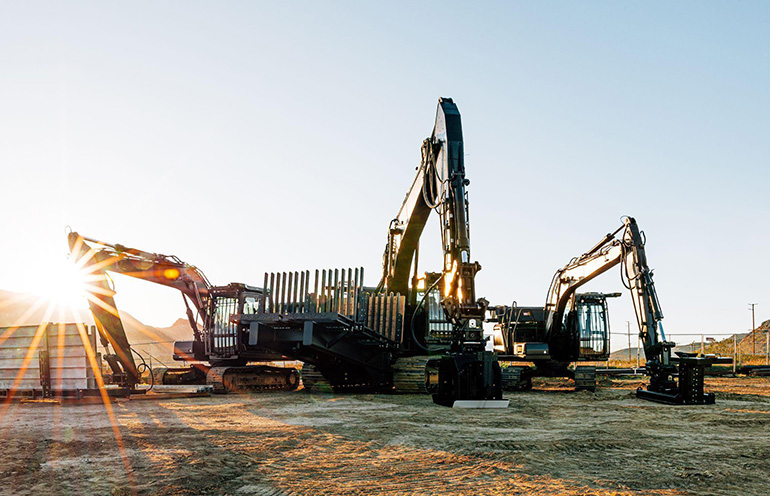
Blattner awards Built Robotics $75M contract for physical AI to help meet energy demand
Blattner has expanded its partnership with Built Robotics to scale autonomous systems for solar construction. The post Blattner awards Built Robotics $75M contr…
DriveVA: Video Action Models are Zero-Shot Drivers
arXiv:2604.04198v2 Announce Type: replace-cross Abstract: Generalization is a central challenge in autonomous driving, as real-world deployment requires robust …
FurnitureVLA: Learning Long-Horizon Bimanual Furniture Assembly with Vision-Language-Action Model
arXiv:2607.01212v1 Announce Type: new Abstract: Current work on robot furniture assembly mostly focuses on toy-scale settings or single-arm manipulation. We int…
ROSA: A Robotics Foundation Model Serving System for Robot Factories
arXiv:2607.01088v1 Announce Type: new Abstract: Robotics foundation models (RFMs) are making general-purpose robots increasingly practical for factory deploymen…
Path Planning in Physically Viable World Models
arXiv:2607.00673v1 Announce Type: new Abstract: Robots deployed in unstructured outdoor environments often plan from scene reconstructions collected before depl…
From Real-Time Planning to Reliable Execution:Scalable Coordination for Heterogeneous Multi-Robot Fleets in Industrial Environments
arXiv:2607.00591v1 Announce Type: new Abstract: With the increasing deployment of heterogeneous robot fleets in industrial environments, efficient coordination …
MineRobot: An Actuator-Centered Kinematic Modeling and Solving Framework for Underground Mining Robots
arXiv:2603.22055v2 Announce Type: replace-cross Abstract: Underground mining robots are increasingly modeled for planning, operator training, and digital-twin w…