Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 stories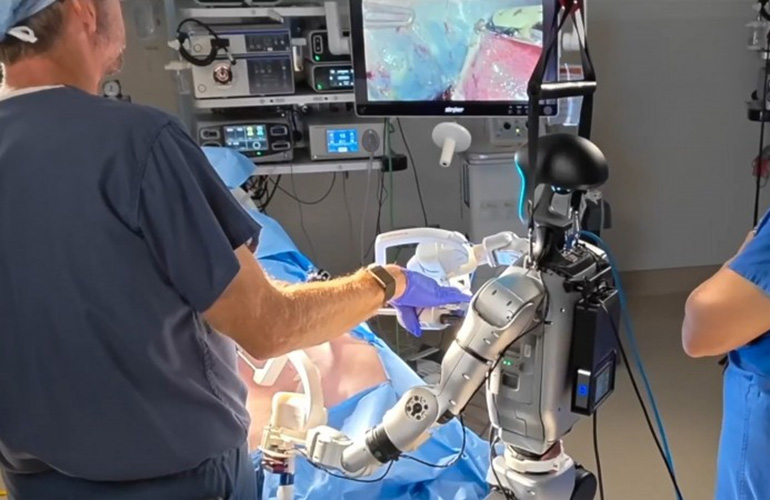
Beyond da Vinci: Why versatile humanoid robots are the next frontier in surgery
For the first time, teleoperated humanoid robots successfully performed surgeries during a UC San Diego preclinical trial. The post Beyond da Vinci: Why versati…
Towards Reliable Aerial Ground Vehicle Collaboration: An Integrated Planning and Autonomy Framework for Field Deployment
arXiv:2607.07350v1 Announce Type: new Abstract: Limited flight endurance significantly restricts the operational range of unmanned aerial vehicles (UAVs) in lon…
Context-Aware Force Estimation for Deformable Tool Manipulation in Robotic Environmental Swabbing via Few-Shot Continual Adaptation
arXiv:2607.07574v1 Announce Type: new Abstract: Robotic surface swabbing requires sustained interaction between a compliant tool and heterogeneous environments,…
Dynamic Object Detection and Tracking in Construction: A Fisheye Camera and LiDAR Sensor Fusion Model
arXiv:2607.06896v1 Announce Type: new Abstract: Robust dynamic object detection and tracking are essential for enabling robots to operate safely and effectively…
End-to-End LLM Flight Planning with RAG-based Memory and Multi-modal Coach Agent
arXiv:2607.06964v1 Announce Type: new Abstract: Bridging the gap between human pilot intent and autonomous flight operation is critical for real-world electric …
MiLSD: A Micro Line-Segment Detector for Resource-Constrained Devices
arXiv:2607.06600v1 Announce Type: cross Abstract: Line segment detection is a key building block in visual SLAM, 3D reconstruction, and industrial inspection. R…
A Continual Learning Framework for Adaptive Control of Modular Soft Robots
arXiv:2607.06740v1 Announce Type: new Abstract: Soft robots have attracted significant attention in applications such as medical intervention, rehabilitation, a…
Exploring Human-Robot Collaboration: Analysis of Interaction Modalities in Challenging Tasks
arXiv:2605.13380v2 Announce Type: replace Abstract: This work compares three interaction modalities for human-robot collaboration: passive, reactive, and proact…
Hilti-Trimble-Oxford Dataset: 360 Visual-Inertial Benchmark with Floor Plan Priors for SLAM and Localization
arXiv:2607.06464v1 Announce Type: new Abstract: Automated progress monitoring on construction sites is an active area of research and development. Robot and hum…
OrchardBench: A Physically-Grounded, GPU-Parallel Apple-Orchard Simulation Benchmark for Agricultural Robotics
arXiv:2607.06337v1 Announce Type: new Abstract: Robotic tree-fruit harvesting is a flagship problem for agricultural automation, but progress is bottlenecked by…
HERB: Human-augmented Efficient Reinforcement learning for Bin-packing
arXiv:2504.16595v2 Announce Type: replace Abstract: Packing objects efficiently is a fundamental problem in logistics, warehouse automation, and robotics. When …
Uncertainty-Aware Velocity Correction for Proprioceptive Vehicle Localization using Evidential Mamba
arXiv:2607.05669v1 Announce Type: new Abstract: Reliable localization in GNSS-denied environments remains a fundamental challenge for intelligent vehicles, as i…
A Digital Twin Framework for Traffic-Aware UAV Pavement Monitoring in Open-Traffic Conditions
arXiv:2606.20742v2 Announce Type: replace Abstract: UAV-based pavement inspection can reduce the cost and risk of road-surface monitoring, but real-world deploy…
EVA-Client: A Unified Data Collection, Inference, and Deployment Framework for Embodied Policies on Real Robots
arXiv:2607.02646v1 Announce Type: new Abstract: We present EVA-Client, an open-source framework for deployment, data collection, and evaluation of trained manip…
DREAMSTEER: Latent World Models Can Steer VLA Policies During Deployment Without Any Finetuning
arXiv:2607.02865v1 Announce Type: new Abstract: Pretrained vision-language-action (VLA) policies show promising zero-shot generalization, but often fail under d…
A Vision Based System for Guided and Collaborative Reconstruction of Fragmented Documents
arXiv:2607.03621v1 Announce Type: cross Abstract: This paper presents the development and evaluation of a collaborative system for real-time reconstruction of f…
Language-Guided Grasping under Partial Observation for Mobile Manipulation in Field Inspection and Maintenance
arXiv:2603.07866v3 Announce Type: replace Abstract: Offshore inspection and maintenance have increasingly been using legged robots for routine sensing, yet many…
CoRE-VLA: Towards Scalable and Robust Vision-Language-Action Modeling via Conditional Routing of Experts
arXiv:2607.03693v1 Announce Type: new Abstract: Vision-language-action (VLA) models have advanced generalist robotic manipulation, yet real-world deployment rev…
XS-VLA: Coupling Coarse-grained Spatial Distillation with Latent Flow Matching for Lightweight Robotic Control
arXiv:2607.04171v1 Announce Type: new Abstract: Large Vision-Language Models (LVLMs) have shown strong multimodal understanding and spatial grounding, but their…
RoboDojo: A Unified Sim-and-Real Benchmark for Comprehensive Evaluation of Generalist Robot Manipulation Policies
arXiv:2607.04434v1 Announce Type: new Abstract: Generalist robot manipulation policies have advanced rapidly, yet existing benchmarks remain limited in systemat…
Socially-Aware Autonomous Doorway Traversal and Payload Delivery for Emergency Assistance
arXiv:2607.05315v1 Announce Type: new Abstract: In this work, we focus on the scenario of a robot-assisted emergency evacuation. We consider two capabilities re…
GaP: A Graph-as-Policy Multi-Agent Self-Learning Harness For Variational Automation Tasks
arXiv:2607.05369v1 Announce Type: new Abstract: For robots to work reliably in commercial and industrial applications, can recent advances in agentic coding sys…
Nano-U: Efficient Terrain Segmentation for Tiny Robot Navigation
arXiv:2605.10210v2 Announce Type: replace Abstract: Terrain segmentation is a fundamental capability for autonomous mobile robots operating in unstructured outd…
iVISION-2DCD: A Long-Term Change Detection Dataset for Large-Scale Outdoor Construction Monitoring
arXiv:2607.03553v1 Announce Type: cross Abstract: Automation in construction is essential for reducing costs and human errors in large-scale projects. We approa…
SilvaScenes: Tree Detection and Species Classification from Under-Canopy Images in Natural Forests
arXiv:2510.09458v2 Announce Type: replace-cross Abstract: Interest in forestry automation is growing alongside rapid advances in deep learning. In particular, t…
From Fixed to Free Cameras: Calibration-Free View-Robust Vision-Language-Action Model
arXiv:2607.05396v1 Announce Type: cross Abstract: Real-world robot deployment rarely maintains the training-stage camera setup, where cameras often experience r…
Qantara: Bridge-Flow Training for Multi-Paradigm JEPA Control
arXiv:2607.04978v1 Announce Type: cross Abstract: Joint-Embedding Predictive Architectures (JEPAs) underpin a growing family of latent world models for control …
Layout-independent actuation allocator for fin-actuated marine robots
arXiv:2607.03204v1 Announce Type: new Abstract: In this study, we propose a layout-independent control allocator capable of zero-shot deployment across diverse …
CableTract: A Co-Designed Cable-Driven Field Robot for Low-Compaction, Off-Grid Capable Agriculture
arXiv:2604.09938v2 Announce Type: replace Abstract: Conventional field operations spend most of their energy moving the tractor body, not the implement. Yet fea…
Hope for the Best, Prepare for the Worst: Occlusion-Aware Contingency Planning for Autonomous Vehicles
arXiv:2607.03155v1 Announce Type: new Abstract: The deployment of autonomous vehicles in urban environments introduces significant safety challenges, particular…