Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesDiffusion for Long-Horizon Multi-Robot Path Planning in Human-Shared Environments
arXiv:2607.09911v1 Announce Type: new Abstract: Multi-robot path planning in human-shared environments requires a delicate balance between robust inter-robot co…
FlashBEV: Fast and Memory-Efficient Exact BEV Transformation with IO-Awareness
arXiv:2607.10071v1 Announce Type: cross Abstract: Bird's-eye-view (BEV) perception is a core component of camera-based 3D understanding in autonomous driving, w…
SmoothTurn: Learning to Turn Smoothly for Agile Navigation with Quadrupedal Robots
arXiv:2603.12842v2 Announce Type: replace Abstract: Quadrupedal robots show great potential for valuable real-world applications such as fire rescue and industr…
Task Planning for Mobile Manipulation in Retail Stores using Foundation Models with Iterative Re-planning
arXiv:2607.09962v1 Announce Type: new Abstract: Automation in industries such as retail, warehousing and logistics presents opportunities for greater throughput…
Stop to Decide: Latency-Aware Proprioceptive Navigation Primitives for Mapping-Free Quadruped Inspection
arXiv:2607.11204v1 Announce Type: new Abstract: Compute-constrained quadrupeds often run their navigation loop far below the controller's design rate: sharing t…
Coverage Path Planning: Classical Foundations, Recent Advances, and Future Directions
arXiv:2607.10649v1 Announce Type: new Abstract: Coverage path planning (CPP) is a fundamental problem in robot motion planning, whose aim is to produce robot tr…
CSI-Assisted Edge SLAM Testbed Platform for 5G Connected Unmanned Autonomous Vehicles
arXiv:2607.10394v1 Announce Type: cross Abstract: The evolution from 5G towards 6G reinforces interest in connected robotics, where mobile robots offload comput…
From Sketch Prior to Trajectories: A Mission-Oriented Coordinated Navigation Framework for Indoor UAV Swarm
arXiv:2607.11386v1 Announce Type: new Abstract: UAV swarm for applications, such as indoor inspection, security patrol, and logistics delivery, are often missio…
On the Efficiency of LoRA Fine-Tuning for Vision-Language-Action Models in Industrial Robotic Manipulation
arXiv:2607.10172v1 Announce Type: new Abstract: Deploying billion-parameter Vision-Language-Action (VLA) models on industrial hardware requires fine-tuning to b…
Think When It Matters: Conditional VLM Reasoning for Social Navigation with RL Policies
arXiv:2607.10991v1 Announce Type: new Abstract: As mobile robots become more integrated into everyday human environments, social robot navigation is becoming es…
Robotic Contextual Awareness for Human-Robot Collaboration and Environmental Understanding
arXiv:2607.10372v1 Announce Type: new Abstract: The transition of autonomous mobile robots from controlled industrial settings to dynamic, human-centric environ…
Self-Healing Visual Recovery for Autonomous Ground Vehicles Using Camera-Only Visual Odometry
arXiv:2607.11686v1 Announce Type: new Abstract: Low-cost unmanned ground vehicles are often used in indoor places like warehouses, inspection corridors, and far…
Artificial Foveated Perception for Mitigating Shortcut Learning in Robotic Foundation Models
arXiv:2607.10655v1 Announce Type: new Abstract: Robotic foundation models have recently made substantial progress in multi-task capability, cross-embodiment tra…
A Risk-Field Enhanced Closed-Loop Digital Twin Framework for Autonomous Driving Safety Validation
arXiv:2607.09772v1 Announce Type: new Abstract: Autonomous driving systems require reliable safety validation before real-world deployment. However, large-scale…
Closed-Loop Control with Rule-Aligned Small Language Models and Multi-Agent Self-Correction
arXiv:2607.09713v1 Announce Type: cross Abstract: A key step toward autonomous industrial operation is the ability to create and reconfigure control policies fr…
BucketKD: A Safety-Aware Bucket-Based Knowledge Distillation Framework for End-to-End Motion Planning
arXiv:2607.10565v1 Announce Type: new Abstract: End-to-end motion planning has emerged as a promising paradigm in autonomous driving, directly mapping raw senso…
Wearing A Coat: Dual-Arm Robot-Assisted Dressing with Differentiable Clothing Simulation
arXiv:2607.10999v1 Announce Type: new Abstract: The development of assistive robots for dressing tasks serves to augment human convenience and improve the quali…
Breaking the 15% Barrier: A Real-World Data-Driven System for Proactive Social Robot Triggered by User Nonverbal Cues
arXiv:2607.11633v1 Announce Type: new Abstract: Service robots in retail stores increasingly rely on cascaded speech pipelines (STT-LLM-TTS), yet many customer-…
Robust Fleet Sizing for Multi-UAV Inspection Missions under Synchronized Replacement Demand
arXiv:2604.15890v2 Announce Type: replace Abstract: Multi-UAV inspection missions require spare drones to replace active drones during recharging cycles. Existi…
LLM-Centric Agentic AI for UAV Swarms: Architecture, Enabling Technologies, and Open Problems
arXiv:2607.09756v1 Announce Type: new Abstract: Uncrewed Aerial Vehicle (UAV) swarms have significant potential for applications such as Search and Rescue (SAR)…
Hydra++: Real-Time Hierarchical 3D Scene Graph Construction With Object-Level Shape Estimation
arXiv:2607.09455v1 Announce Type: cross Abstract: 3D scene graphs provide a hierarchical abstraction of environments by encoding spatial entities, such as objec…
How Mobile Gas Sensor Trajectories Govern Hydrogen Leak Detection: A Safety Gap in Manual Leak Inspection of Hydrogen System Components
arXiv:2607.09527v1 Announce Type: new Abstract: The integrity of hydrogen infrastructure relies on reliable leak detection, performed almost exclusively via man…
CORAL-AUV: CFD Oriented Reinforcement Learning for Autonomous Underwater Vehicles
arXiv:2607.09557v1 Announce Type: new Abstract: Fine grain control and positioning of autonomous underwater vehicles (AUVs) is critical for sampling, maintenanc…
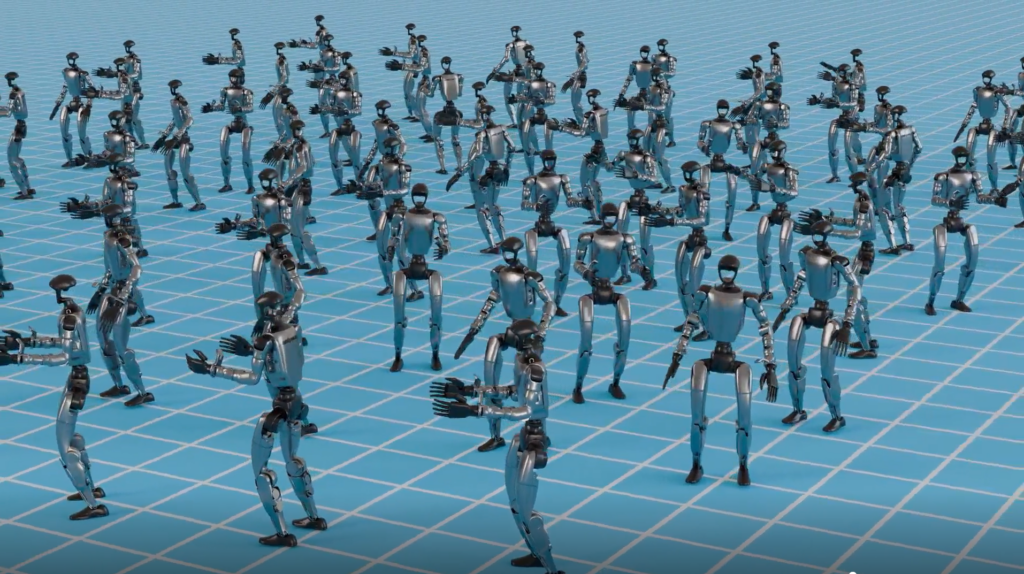
Why robotics teams need virtual gyms before deployment
To address environmental and task variability, robots can benefit from 'virtual gyms' to bridge the sim-to-real gap, says SoftServe. The post Why robotics teams…
ZAPS-DA: Zero-Phase Action Policy Smoothing with Decoupled Actor for Continuous Control in Reinforcement Learning
arXiv:2605.30612v2 Announce Type: replace Abstract: Continuous control policies trained with off-policy reinforcement learning frequently exhibit high-frequency…
SkillPlug: Unsupervised Skill Mining for Few-Shot Adaptation in Robotic Manipulation
arXiv:2607.08354v1 Announce Type: new Abstract: Learning transferable visuomotor imitation policies that generalize across diverse manipulation tasks and adapt …
A Collaborative Reasoning Framework for Anomaly Diagnostics in Underwater Robotics
arXiv:2511.03075v2 Announce Type: replace Abstract: The safe deployment of autonomous systems in safety-critical settings requires a paradigm that combines huma…
In vivo feasibility study of humanoid robots in surgery
arXiv:2607.07972v1 Announce Type: new Abstract: Recent advances in actuation, control and learning have rapidly pushed humanoid robots from a distant vision tow…
Harness VLA: Steering Frozen VLAs into Reliable Manipulation Primitives via Memory-Guided Agents
arXiv:2607.08448v1 Announce Type: new Abstract: Language-conditioned manipulation requires both precise contact-rich control and robust reasoning over language,…
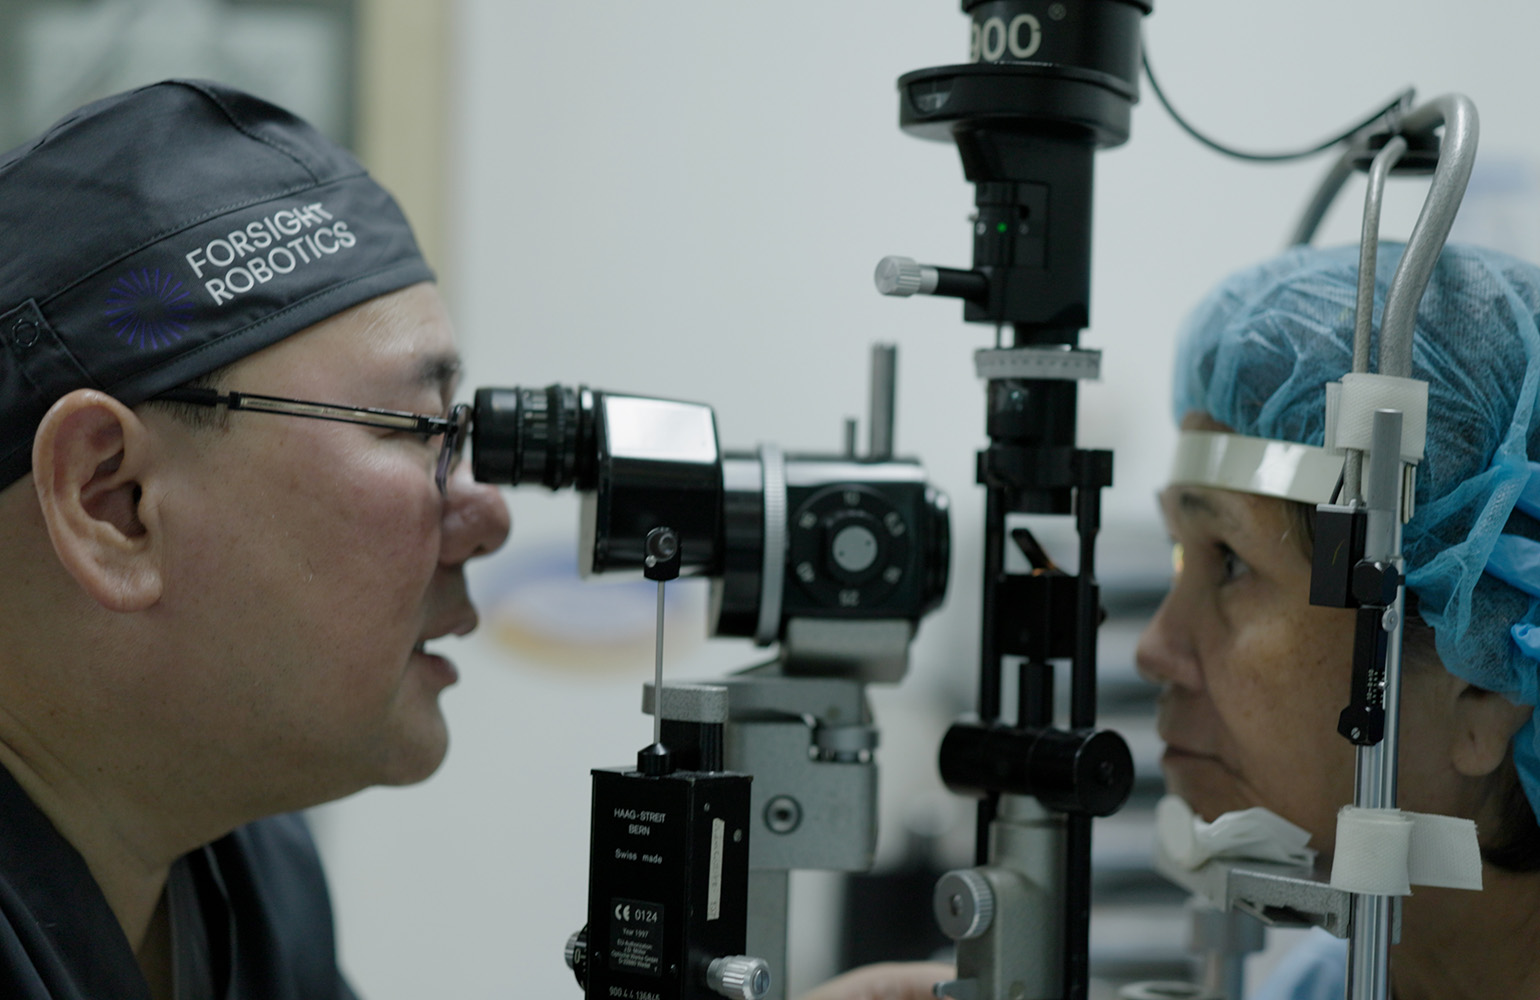
ForSight Robotics’ road to performing a fully robotic cataract surgery
ForSight Robotics' JASPER Platform assists surgeons with cataract surgeries, while still leaving the power in the surgeon's hands. The post ForSight Robotics…