Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesVisibility-Aware Cooperative Tracking with Decentralized LiDAR-Based Aerial Swarms
arXiv:2512.01280v2 Announce Type: replace Abstract: Autonomous aerial tracking with drones offers vast potential for surveillance, cinematography, and industria…
Reinforcement Learning on Cost-Constrained Quadrupedal Hardware
arXiv:2607.26434v1 Announce Type: new Abstract: Deploying learned control policies on low-cost robotic platforms introduces transport latencies and noisy motor …
Can Vision-Language-Action Models Learn from Real-World Data Continually without Forgetting?
arXiv:2605.26820v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models provide a promising foundation for general-purpose robotics, yet their r…
RoboMME-Interference: Benchmarking Robot Memory Under Interference
arXiv:2606.22338v2 Announce Type: replace Abstract: Robots deployed in realistic settings will accumulate experience across many sessions and tasks over their d…
Diff2DGS: Reliable Reconstruction of Occluded Surgical Scenes via 2D Gaussian Splatting
arXiv:2602.18314v2 Announce Type: replace-cross Abstract: Real-time reconstruction of deformable surgical scenes is vital for advancing robotic surgery, improvi…
Track-Leakage-Free Hold-Out Self-Validation for Photogrammetric Reconstruction: Protocol, Sensitivity, and Limits
arXiv:2607.24852v1 Announce Type: cross Abstract: Automated photogrammetric inspection emits metric measurements from a 3D reconstruction whose own correctness …
INTACT: Isomorphic Intent-to-Action Learning for Search-Free World Models
arXiv:2607.26056v1 Announce Type: new Abstract: Forward latent world models predict how actions change a scene, but recover actions for a desired change only th…
Tripody: An Overconstrained 3-SPR-like Parallel Robot for High-Reach Construction Tasks
arXiv:2607.25781v1 Announce Type: new Abstract: Many ceiling construction tasks still rely on heavy serial manipulators that are difficult to deploy in cluttere…
Nanobot Algorithms for Treatment of Diffuse Cancer
arXiv:2509.06893v2 Announce Type: replace-cross Abstract: Motile nanosized particles, or "nanobots", promise more effective and less toxic targeted drug deliver…
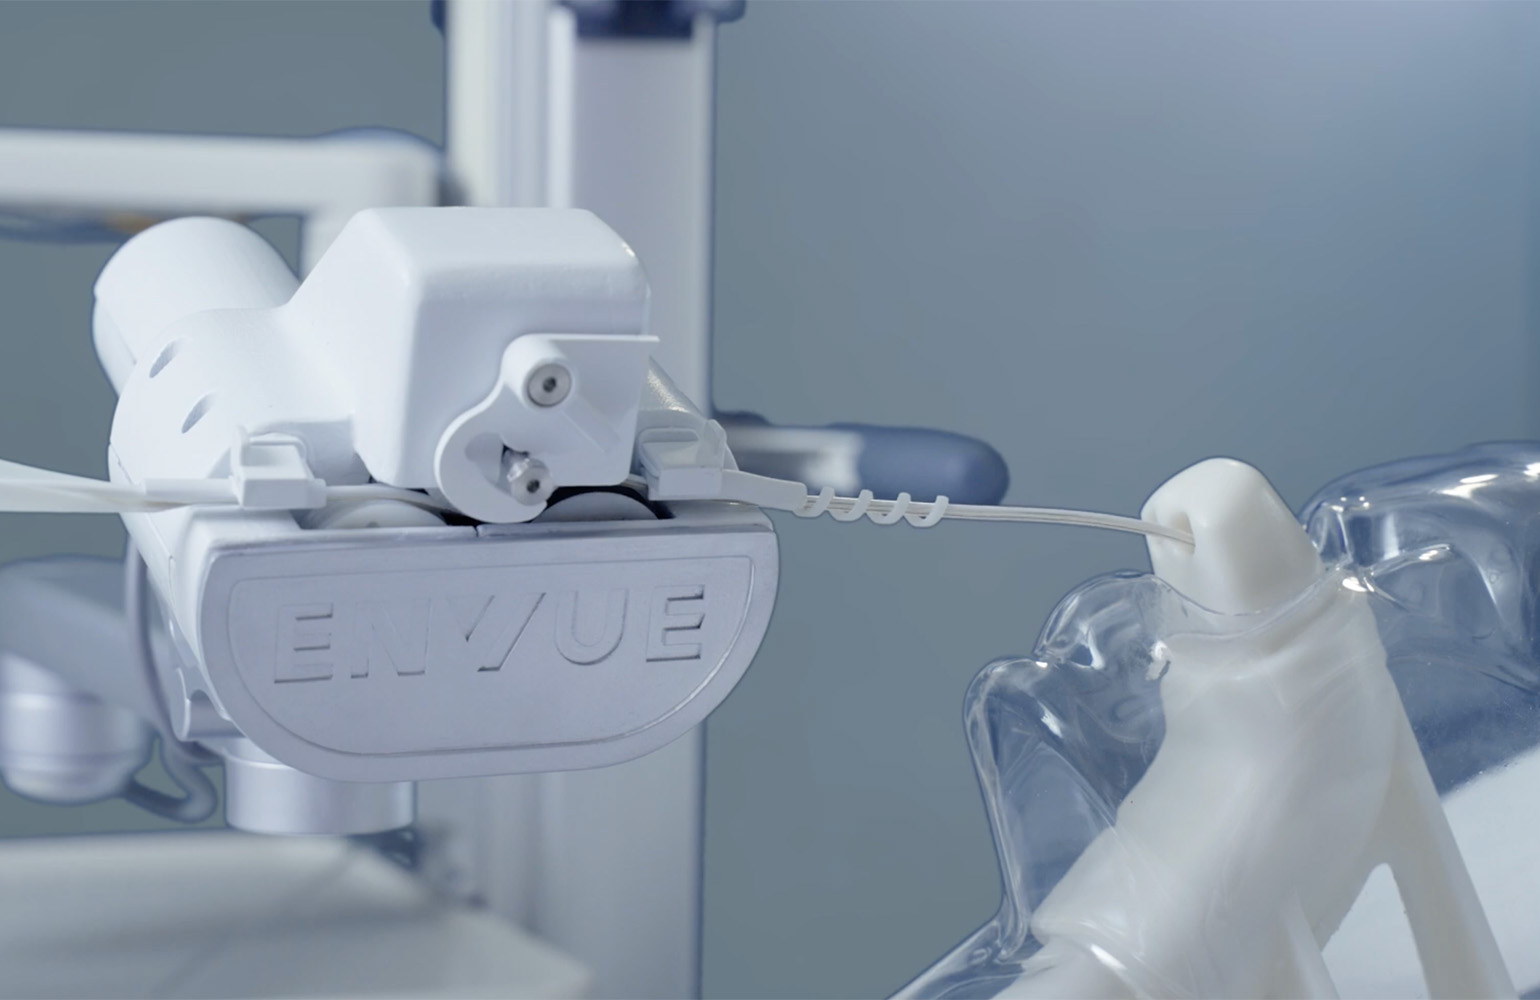
ENvue Medical develops robotic feeding tube placement system
ENvue Drive is designed to assist, not replace, the clinician, who retains full control of the procedure at all times. The post ENvue Medical develops robotic f…
The Curse of Precision: A Data Scaling Law for High-Precision Robotic Manipulation
arXiv:2607.23108v1 Announce Type: new Abstract: While scaling laws for imitation learning have primarily focused on generalization in open-world settings, the r…
Imitation Learning for Robot Assistance in Open Surgery: A Multi-Policy Evaluation on Suture Following
arXiv:2605.28736v2 Announce Type: replace Abstract: This study presents the first evaluation of general-purpose imitation learning for surgeon-robot collaborati…
ArmnetBench v0.1: Parallel Real-World Evaluation of Manipulation Policies on a Low-Cost Arm Farm
arXiv:2607.24481v1 Announce Type: new Abstract: Real-world evaluation is a bottleneck in developing generalist robot manipulation policies. Each rollout require…
LabRobFail: A Benchmark for Robotic Failure Analysis in Chemical Self-driving Laboratories
arXiv:2607.23704v1 Announce Type: new Abstract: The deployment of embodied agents in self-driving laboratories could accelerate scientific discovery, yet their …
Phenology-based learning framework for yield estimation and harvest forecasting of raspberry fruits
arXiv:2411.00967v2 Announce Type: replace-cross Abstract: The future of agriculture is intertwined with automation. Accurate fruit detection, yield estimation, …
Distributed Coordination for Resilient Multi-UAV Remote Sensing: A Photovoltaic Inspection Case Study
arXiv:2607.24482v1 Announce Type: new Abstract: Deploying multiple UAVs for remote sensing enables proportional reductions in mission time, but realizing these …
MAGS-SLAM: Monocular Multi-Agent Gaussian Splatting SLAM for Geometrically and Photometrically Consistent Reconstruction
arXiv:2605.10760v2 Announce Type: replace Abstract: Collaborative photorealistic 3D reconstruction from multiple agents enables rapid large-scale scene capture …
Co-planning of Flight Corridors and Communication Infrastructure for Urban Drone Logistics Networks
arXiv:2607.23989v1 Announce Type: new Abstract: Reliable wireless connectivity is essential for urban air mobility (UAM) networks in dense urban environments. I…
CReF: Cross-modal and Recurrent Fusion for Depth-conditioned Humanoid Locomotion
arXiv:2603.29452v3 Announce Type: replace Abstract: Stable traversal over geometrically complex terrain increasingly requires exteroceptive perception, yet prio…
A Cyclic Adaptation-Generalization Framework with Uncertainty-Guided Self-Paced Learning for Long-Term Brain-Machine Interfaces
arXiv:2607.24031v1 Announce Type: cross Abstract: Brain-Machine Interfaces (BMIs), which link the brain to external devices, hold great potential in rehabilitat…
$N_0$-VTLA: Scaling Vision-Tactile-Language-Action Model with Latent Tactile Tokens
arXiv:2607.23782v1 Announce Type: new Abstract: We present $N_0$-VTLA, a vision-tactile-language-action (VTLA) foundation model capable of (1) fine-grained cont…
FutureRTC: Real-Time Robot Execution with Anticipatory-Conditioned Action Chunking
arXiv:2607.24008v1 Announce Type: new Abstract: Real-time deployment of Vision-Language-Action (VLA) policies necessitates asynchronous execution, wherein subse…
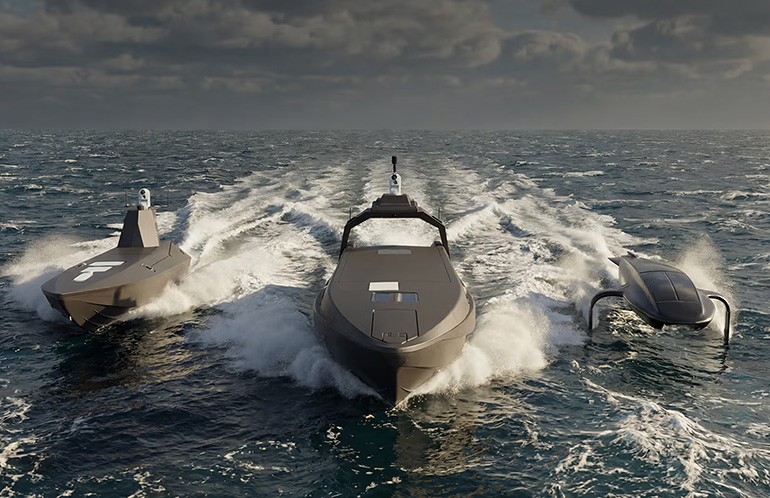
Kraken Technology raises Series B funding for autonomous vessels
Kraken Technology plans to use its funding to continue developing uncrewed surface vessels and localizing manufacturing around the world. The post Kraken Techno…
OpenNavMap: Multi-Session Appearance-Based Topometric Mapping for Scalable Visual Navigation
arXiv:2601.12291v2 Announce Type: replace Abstract: Scalable and maintainable maps are fundamental to large-scale navigation and the long-term deployment of rob…
A Monolithic Hand with Asymmetric Origami Bending and Dual-chamber Actuators
arXiv:2607.22320v1 Announce Type: new Abstract: The passive adaptability inherent in soft robotic hands affords them advantages in applications that require saf…
Benchmarking the Safety of Large Language Models for Robotic Health Attendant Control
arXiv:2604.26577v2 Announce Type: replace-cross Abstract: Large language models (LLMs) are increasingly considered for deployment as the control component of ro…
GRACE: Gradient-Free Robot Action Generation via Combined Diffusion-MPPI Posterior Mean Estimation
arXiv:2607.21661v1 Announce Type: new Abstract: Diffusion policies generate multimodal robot action sequences from demonstrations, but steering them toward depl…
A Unified Framework for Automated Assembly Sequence and Production Line Planning using Graph-based Optimization
arXiv:2512.13219v2 Announce Type: replace Abstract: This paper presents PyCAALP (Python-based Computer-Aided Assembly Line Planning), a framework for automated …
CorVS+: Correspondence-Driven Association of Video Trajectories and Sensors for Identity-Aware Person Localization in Warehouses
arXiv:2510.26369v2 Announce Type: replace-cross Abstract: Logistics warehouses have struggled with labor shortages, but the inbound processes remain particularl…
Geometric 2D Scene Graph Generation
arXiv:2607.22325v1 Announce Type: cross Abstract: In production processes for consumer products, assembly instructions are essential not only for planning but a…