Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesTowards General Language-Conditioned Latent Safety Filters
arXiv:2608.00315v1 Announce Type: new Abstract: Robot policies are becoming increasingly general, with vision-language-action (VLA) models enabling a single pol…
Minute-Scale Training for Microrobot Navigation
arXiv:2608.00854v1 Announce Type: new Abstract: Microrobots hold significant potential for various applications, where targeted navigation is a basic requiremen…
Stress-Relief Annealing: Polynomial-Time Simulation-Free Layout Optimization for Automated Warehouses
arXiv:2608.01024v1 Announce Type: cross Abstract: We study the problem of optimizing physical layouts for automated warehouses, where hundreds to thousands of r…
Perception-and-action system for humanoid robot task execution in construction
arXiv:2608.01600v1 Announce Type: new Abstract: Humanoid robots, with their human-like shape and multi-tasking capabilities, are well-aligned with human-dominat…
A Robotic System for Automated Manufacturing of Dielectric Elastomer Actuators
arXiv:2608.00369v1 Announce Type: new Abstract: This letter presents an automated robotic manufacturing system for soft capacitors which operate as actuators an…
Long-Term Memory for VLA-based Agents in Open-World Task Execution
arXiv:2604.15671v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models have demonstrated significant potential for embodied decision-making; ho…
BWM: A Low-Cost High-Fidelity World Simulator for Robot Learning
arXiv:2607.29302v1 Announce Type: new Abstract: Reliable robot learning requires a world simulator that can predict action consequences before execution on phys…
Combining Large Language Models and Symbolic Reasoning for Multi-Robot Temporal Planning through Explainable Knowledge Bases
arXiv:2502.19135v2 Announce Type: replace-cross Abstract: We present PLANTOR, a framework for generating and executing multi-robot task plans from natural-langu…
Vision-based Goal-Reaching Control for Mobile Robots Using a Hierarchical Learning Framework
arXiv:2601.00610v2 Announce Type: replace Abstract: Reinforcement learning (RL) has strong potential in robotics, but exploration-based training complicates saf…
Vision-Based Agile Landing on Turbulent Waters
arXiv:2605.23717v2 Announce Type: replace Abstract: Autonomous landing of Unmanned Aerial Vehicles on maritime vessels is challenging due to the coupled motion …
Receding-Horizon Next-Best-View Planner for Autonomous Leaf Surface Reconstruction
arXiv:2607.28995v1 Announce Type: new Abstract: Accurate plant leaf modeling is fundamental to downstream tasks such as plant growth monitoring, and phenotyping…
CLIFT: Turning Gemini Robotics On-Device into Humanoid Specialists via Non-Invasive Closed-Loop Iterative Fine-Tuning
arXiv:2607.29172v1 Announce Type: new Abstract: While robot foundation models are growing increasingly capable, the strongest models are typically trained on pr…
Bootstrapping Self-Supervised Learning of Binary Classification Using Error Bounds: A Case Study on a Robotic Insertion Task
arXiv:2607.29640v1 Announce Type: new Abstract: Flexible manufacturing requires rapid deployment of solutions and minimal setup time to remain competitive. An e…
RAPiD: Reward-Guided Consistency Distillation of Diffusion Planners for Real-Time Autonomous Driving
arXiv:2602.07339v2 Announce Type: replace-cross Abstract: Diffusion-based trajectory planners can model multi-modal driving behavior, but their iterative denois…
Choose What to Manipulate: Revealing Data Scaling Laws in Bounding-Box Guided Policies for Semantic Manipulation
arXiv:2602.11885v2 Announce Type: replace Abstract: Diffusion-based policies generalize poorly in semantic manipulation, a key obstacle to real-world deployment…
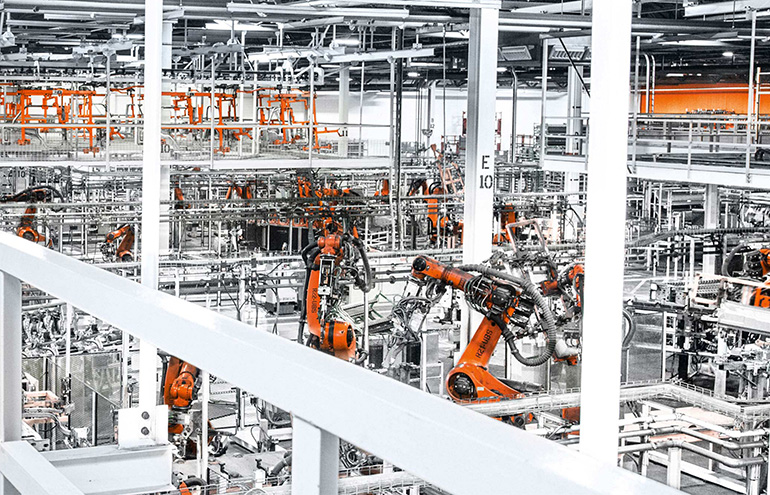
KUKA deploys Automation Management Platform for North American automakers
KUKA has deployed its Automation Management Platform at KTPO, a major manufacturing facility in Ohio. The post KUKA deploys Automation Management Platform for N…
FCC robot ruling shines a spotlight on U.S. policy; how next-gen AI can help warehousing
Osaro’s Derek Pridmore says warehouse robots are advancing, but real-world safety and reliability still depend on specialized, layered AI systems. The post FCC …
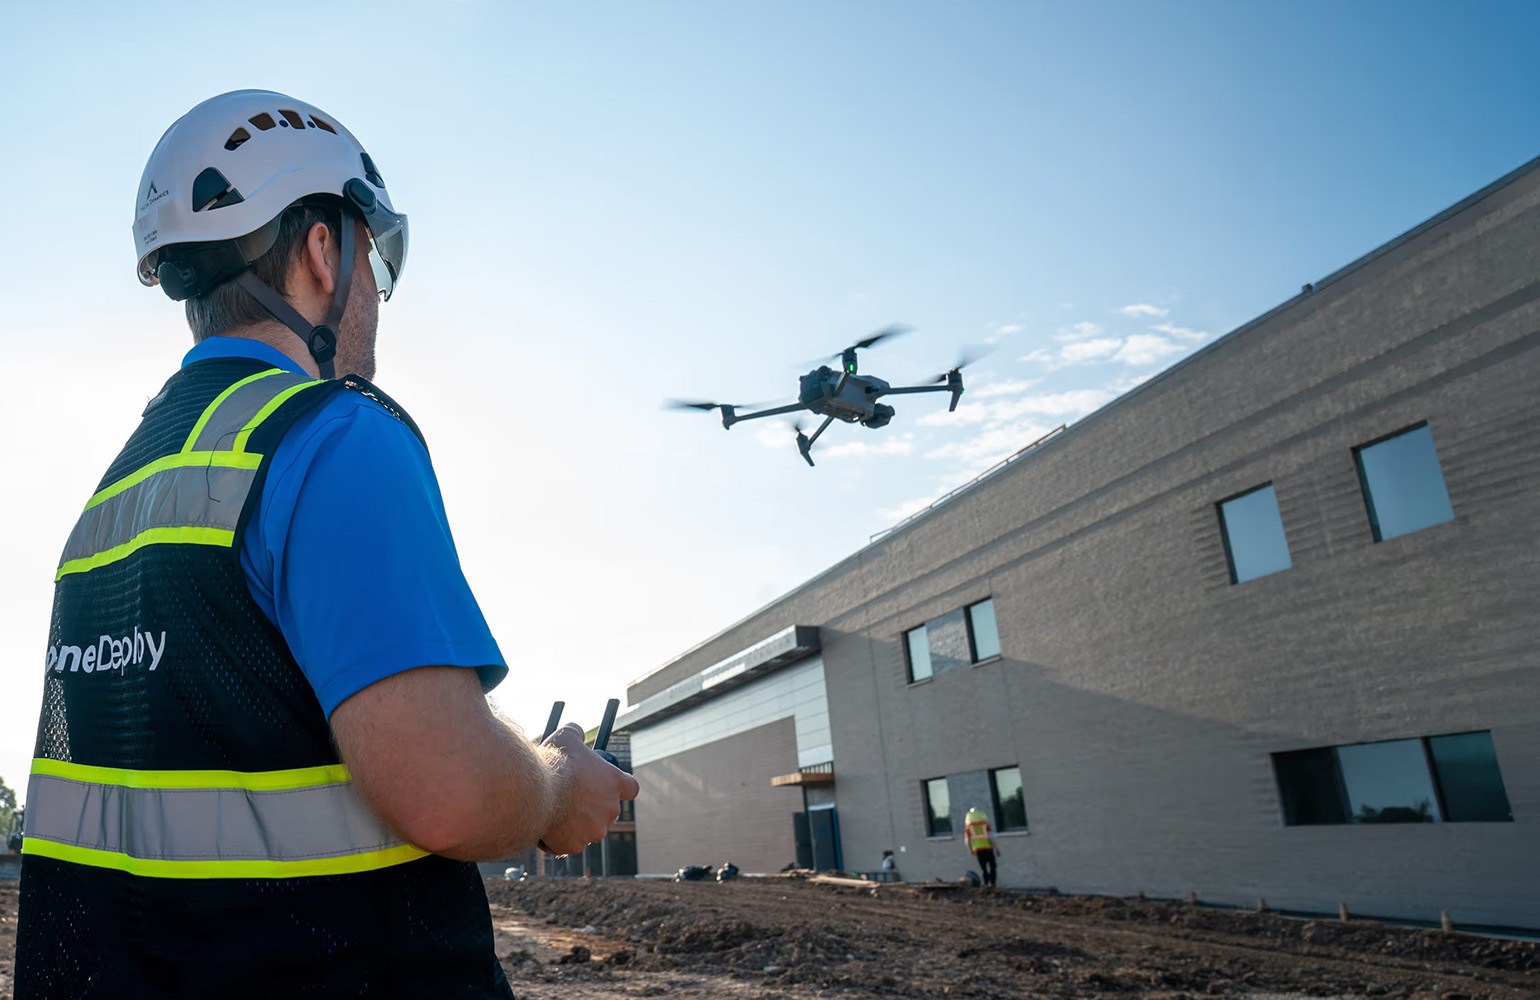
Procore Technologies acquires DroneDeploy for $845M
Procore will integrate DroneDeploy's visual intelligence technology to link the digital world with physical construction sites. The post Procore Technologies ac…
PAC-MAN: Perception-Aware CBF-RL for Whole-Body Safety in Humanoid Dodgeball
arXiv:2607.28623v1 Announce Type: new Abstract: We present PAC-MAN, a perception-aware CBF-RL framework that couples control-barrier safety with deployment-real…
When Robots Exchange Meaning: A Demo of Goal-Oriented Semantic Communications for Collaborative Robotics
arXiv:2607.28256v1 Announce Type: new Abstract: Collaborative robotics is a representative task-oriented 6G use-case, where communication quality should be refl…
Active Lubrication of Transluminal Medical Instruments
arXiv:2506.07225v2 Announce Type: replace-cross Abstract: Transluminal minimally invasive surgery uses natural orifices and small incisions to access internal a…
SharedAssembly: A Data Collection Approach via Shared Tele-Assembly
arXiv:2503.12287v2 Announce Type: replace Abstract: High-precision, tight-clearance assembly demonstrations are indispensable for training tactile-aware robotic…
RedFlow: Redirect Failure into Action-Level Corrections for Flow-matching VLA Policy
arXiv:2607.27782v1 Announce Type: new Abstract: Flow-matching Vision-Language-Action (VLA) policies have shown strong potential for robotic manipulation but oft…
Failure Detection for Surgical Robot Imitation Policies via Flow-Matching World Modeling
arXiv:2607.27511v1 Announce Type: new Abstract: Imitation learning has shown increasing promise for autonomous robotic surgery, yet safe deployment remains chal…
One Future, Every Robot: Label-Efficient Collective-State Prediction with Decentralized JEPA
arXiv:2607.28443v1 Announce Type: new Abstract: Can every robot in a swarm predict the same future collective state from only local observations and bandwidth-l…
Compact Task-Aligned Imitation Learning for Laboratory Automation
arXiv:2603.01110v2 Announce Type: replace Abstract: Robotic laboratory automation has traditionally relied on carefully engineered motion pipelines and task-spe…
DoorDash gains FAA certification to operate its own drone delivery program
The FAA approval came nearly a year after DoorDash unveiled its delivery robot and reflects its increasing interest in building automation in-house. The post Do…
Invariant Extended Kalman Filtering with Partial Orientation Measurement Integration: Theoretical Derivations and Application to Autonomous Surface Vessels
arXiv:2506.10850v2 Announce Type: replace Abstract: Autonomous surface vessels (ASVs) are increasingly vital for marine science, offering robust platforms for u…
PACE: Phase-Aware Chunk Execution for Robot Policies with Action Chunking
arXiv:2606.00537v2 Announce Type: replace Abstract: Recent vision-language-action and diffusion-based robot policies often use action chunking, where each polic…
Multi-Objective Compliance-Integrated Coevolution For Simulated And Real-World Deployment Of Multi-Robot Marine Autonomy
arXiv:2607.26279v1 Announce Type: new Abstract: Collaborative robots are well-suited to maritime missions that benefit from coordination, such as the exploratio…