Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesSAFECAST: Robust Failure Detection for VLA Policies with Contrast-Set Training and Calibration
arXiv:2608.04246v1 Announce Type: new Abstract: Vision-language-action policies often fail under deployment-time distribution shifts such as clutter, distractor…
Structured LLM Reasoning for Zero-Shot Human--Robot Coordination Under Hidden Goals
arXiv:2608.04309v1 Announce Type: new Abstract: We present a structured large-language-model (LLM) architecture for zero-shot human--robot coordination in a coo…
A GitOps-Driven Annotation Catalog for Fully Automatic Railway Operations
arXiv:2608.04724v1 Announce Type: new Abstract: Automatic train operation (ATO) at grade of automation 3 and above (GoA3-GoA4) requires robust AI-based percepti…
A Multi-Sensor Dataset for Monitoring the Operational Environment of Rail Vehicles
arXiv:2608.04704v1 Announce Type: cross Abstract: Reliable environment monitoring is essential for the safe and efficient operation of automated railway systems…
SACK : Safe Active Continual Koopman Learning for Uncertain Systems with Contractive Guarantees
arXiv:2605.09659v2 Announce Type: replace Abstract: Koopman operator theory provides a powerful framework for representing nonlinear dynamics through a linear o…
Enabling Urgency-aware Robot Swarm Intralogistics using Smart IoT Tags
arXiv:2608.04721v1 Announce Type: new Abstract: Warehouse items differ in how urgently they must be moved: perishable goods, pharmaceutical shipments, and just-…
RESample: A Robust Data Augmentation Framework via Exploratory Sampling for Robotic Manipulation
arXiv:2510.17640v4 Announce Type: replace Abstract: Vision-Language-Action (VLA) models have shown strong manipulation capability when trained with large-scale …
Exact Model-Free Policy Iteration for Co-safe LTL Planning
arXiv:2608.05047v1 Announce Type: cross Abstract: This work studies model-free reinforcement learning for co-safe linear temporal logic (sc-LTL) objectives in f…
SiMDex: Mining Similar Egocentric Videos for Cross-Embodiment Dexterous Manipulation
arXiv:2608.04196v1 Announce Type: new Abstract: Recent years have witnessed an explosive trend of scaling ego-centric human videos for robot manipulation, yet i…
AI-based single-shot structured-light depth reconstruction for real-time laparoscopic surgical guidance
arXiv:2608.05109v1 Announce Type: cross Abstract: Significance. Accurate intraoperative depth perception is important for autonomous and semi-autonomous robotic…

University of Florida opens new robotics lab dedicated to industrialized construction
Fueled by Autodesk, UF opened a robotics lab for industrialized construction to fight housing shortages and labor declines. The post University of Florida opens…

GAM Enterprises to produce Schaeffler’s PSC gear reducers
Acquiring the IP from this core supplier allows GAM to vertically integrate its supply chain and expand its manufacturing capabilities. The post GAM Enterprises…
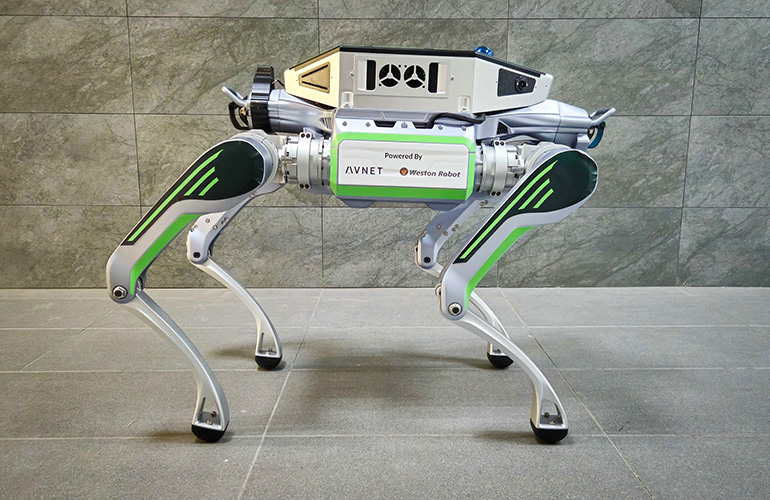
Avnet and Weston Robot partner to launch edge AI inspection platform
Avnet and Weston Robot have partnered to launch an AI-powered autonomous inspection platform for complex industrial environments. The post Avnet and Weston Robo…
A Low-Cost Hybrid Reservoir Computing Model for Isolated Sign Language Video Recognition
arXiv:2608.03444v1 Announce Type: new Abstract: Sign language recognition (SLR) enhances communication between hearing and hearing-impaired individuals. Althoug…
PhyAI: Real-Time Physical AI at the Edge, Scalable Rollouts in the Cloud
arXiv:2608.03682v1 Announce Type: cross Abstract: Physical AI policies require inference throughout their lifecycle, including model evaluation, cloud reinforce…
Graph Neural Planning and Predictive Control for Multi-Robot Communication-Constrained Unlabeled Motion Planning
arXiv:2605.19209v2 Announce Type: replace Abstract: The multi-robot unlabeled motion planning problem of concurrently assigning robots to goals and generating s…
EvoHIL: Self-Evolving Reward and Flow-Matched Policy Optimization for Robust Human-in-the-Loop Reinforcement Learning
arXiv:2608.03872v1 Announce Type: new Abstract: Human-in-the-loop reinforcement learning (HIL-RL) enables robots to learn contact-rich manipulation from limited…
PACE: Adaptive Budget Allocation for Time-Efficient Embodied Planning
arXiv:2608.03034v1 Announce Type: new Abstract: Reasoning-enhanced large language models have achieved remarkable improvements in planning tasks, yet their depl…
DeRP: An Algorithm for Self-Assembly of Power-Delivery Networks using Recursive Branching in Information-Limited Environments
arXiv:2608.02904v1 Announce Type: new Abstract: Delivering sustained power to distributed equipment in unstructured field environments using pre-planned wired n…
Forbidden Region Dynamic Active Constraints in Robot-Assisted Minimally Invasive Surgery
arXiv:2608.03010v1 Announce Type: new Abstract: In robot-assisted surgery, Forbidden Region Active Constraints (FRAC) represent a control strategy that helps ma…
Contact-Driven Localization in a Freeform Robotic Self-Assembled Structure
arXiv:2608.02895v1 Announce Type: new Abstract: Accurate localization remains a key challenge in swarm robotics, particularly for self-reconfigurable systems th…
On-the-fly hand-eye calibration for the da Vinci surgical robot
arXiv:2601.14871v3 Announce Type: replace Abstract: In Robot-Assisted Minimally Invasive Surgery (RMIS), accurate tool localization is crucial to ensure patient…
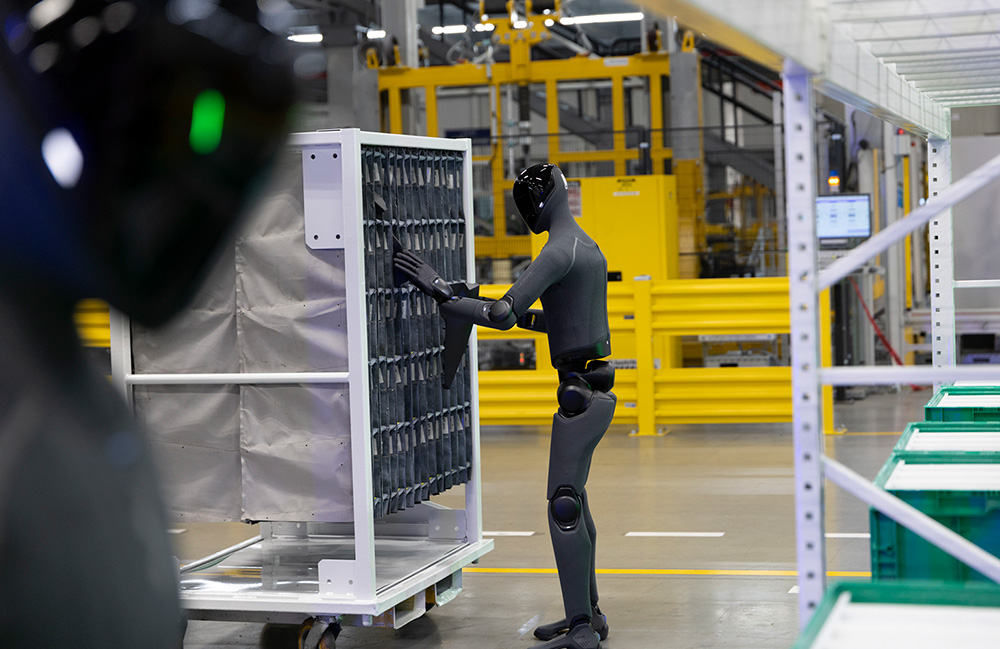
Humanoids won’t scale on factory floors until costs drop
The race to commercialize humanoids is on. What’s left to prove is that humanoid robots can beat the economics of the automation manufacturers are already runni…
Grounded Vision-Language Interpreter for Long-Horizon Bimanual Task and Motion Planning
arXiv:2506.03270v3 Announce Type: replace Abstract: While recent advances in vision-language models have accelerated language-guided robot planning, their black…
Toward Geometry-Scalable Whole-Body Touch for Humanoids: A 3D-Printed Conformal EIT Skin
arXiv:2608.02080v1 Announce Type: new Abstract: Whole-body tactile sensing is a prerequisite for humanoids that operate in contact-rich human environments, but …
World Action Models in Real Time: An Empirical Study of Smooth Execution via Asynchronous Deployment
arXiv:2608.01880v1 Announce Type: new Abstract: World Action Models generate fixed-horizon action chunks through iterative denoising, creating substantial infer…
SSTG-Nav: Metric-Grounded Spatial-Semantic Topological Graphs for Reusable Object Navigation
arXiv:2608.00527v1 Announce Type: new Abstract: Service robots operating for months in the same homes, offices, and facilities should become more reliable with …
WAM-Diff2: Hierarchical AR-to-Diffusion Distillation for Highly Efficient Autonomous Driving VLA
arXiv:2608.01035v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have emerged as a prominent paradigm for end-to-end autonomous driving; howe…
CoNav-UAV: Cooperative Dual-Altitude Aerial Navigation via Stackelberg Learning
arXiv:2608.01802v1 Announce Type: cross Abstract: Target-oriented vision-and-language navigation (VLN) on aerial platforms is attracting growing attention for m…
Learning-Based Motion Planning for Dynamic Environments: From Foundational Algorithms to Emerging Paradigms
arXiv:2608.00625v1 Announce Type: new Abstract: Motion planning in dynamic environments is a fundamental problem in robotics, aiming to generate safe and effici…