Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesDrive As You Like: Multi-Head Diffusion with Reinforcement Learning for Personalized Driving
arXiv:2508.16947v2 Announce Type: replace Abstract: Despite significant progress, imitation learning-based autonomous driving planners remain largely restricted…
VoLN: Vision-Only Long-Horizon Navigation---Paradigm, Benchmark, and Method
arXiv:2607.21400v1 Announce Type: new Abstract: Vision-and-Language Navigation (VLN) enables embodied agents to follow natural-language instructions. However, r…
FORGE-plus: Force-Budgeted Recovery for Contact-Rich Assembly with a Frozen LLM Supervisor
arXiv:2607.21227v1 Announce Type: new Abstract: Force-conditioned reinforcement learning (RL) enables tight-clearance assembly under a commanded force ceiling, …
A real-time RGB-D perception pipeline for autonomous impact hammers in mining: self-filtering, rock segmentation and rock-breaking poses generation
arXiv:2607.20748v1 Announce Type: new Abstract: Impact hammers, also known as rock-breakers, are essential machines in mining operations, where they perform sec…
ZONDA: Zero-shot Object Navigation with Dynamic Avoidance in Multi-floor Environments
arXiv:2607.21025v1 Announce Type: new Abstract: In Object Goal Navigation task, existing methods are typically restricted to static and single-floor environment…
Scalable Low-Cost Laboratory Automation: A Digital Twin-Integrated Robotic Platform for Autonomous Liquid Handling (RAINBOTTM)
arXiv:2607.20662v1 Announce Type: new Abstract: Laboratory automation accelerates discovery, yet its adoption is constrained by the high cost, proprietary desig…
Force-Aware Residual DAgger via Trajectory Editing for Precision Insertion with Impedance Control
arXiv:2603.04038v3 Announce Type: replace Abstract: Imitation learning (IL) has shown strong potential for contact-rich precision insertion tasks. However, its …
Safe and Scalable Multi-Drone Payload Transport via CBF-based Reinforcement Learning with Zero-Shot Sim-to-Real Transfer
arXiv:2607.20665v1 Announce Type: new Abstract: Multi-drone payload transportation has emerged as a promising research paradigm with potential applications in c…
Robostral Navigate
arXiv:2607.20785v1 Announce Type: new Abstract: Deploying navigation systems at scale requires a recipe that minimizes sensor assumptions, generalizes across ro…

Uber co-founder raises $1.7B for new robotics startup ATOMS
Travis Kalanick, the former CEO of Uber, said with ATOMS, he hopes to create physical automation to transform industry. The post Uber co-founder raises $1.7B fo…
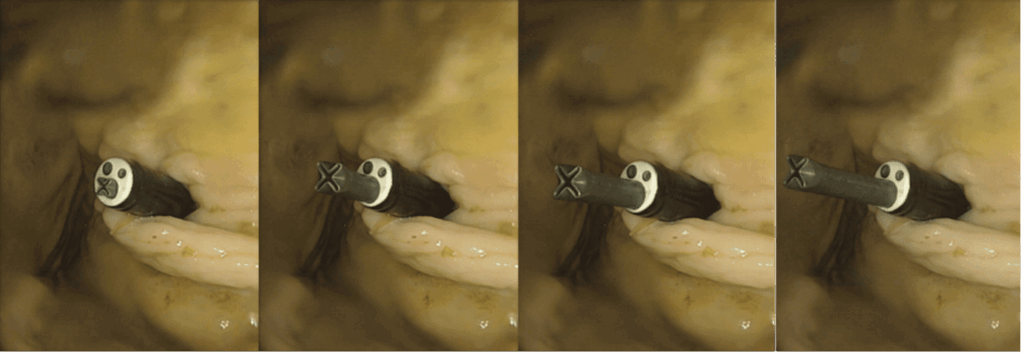
Pressure-free growing robots for soft medical robotics
Researchers at the University of Leeds and collaborators from the University of California San Diego won the Best Paper Award at RoboSoft, the leading internati…
Optimal Placement of Docking Stations and Resident AUVs for Subsea Pipeline Inspection
arXiv:2607.19944v1 Announce Type: cross Abstract: A two-stage mixed-integer linear programming framework is introduced for subsea pipeline incident response pla…
Towards Miniature Humanoid Tele-Loco-Manipulation Using Virtual Reality and Reinforcement Learning
arXiv:2607.20399v1 Announce Type: new Abstract: Full-sized humanoid robot capabilities have grown exponentially in recent years, aiming towards general-purpose …
Directional Mollification for Knot-Preserving $C^{\infty}$ Smoothing of Polygonal Chains with Explicit Curvature Bounds
arXiv:2603.21831v3 Announce Type: replace Abstract: We introduce the \textit{directional mollification} operator, which acts on polygonal chains to produce $C^{…
Counterfactual Reasoning and Environment Design for Active Preference Learning
arXiv:2507.05458v2 Announce Type: replace Abstract: For effective real-world deployment, robots should adapt to human preferences, such as balancing distance, t…
Dynamic Multi-Agent Pickup and Delivery in Robotic Cellular Warehousing Systems
arXiv:2606.05669v2 Announce Type: replace Abstract: Robotic Cellular Warehousing Systems (RCWS) give rise to multi-agent pickup and delivery (MAPD) processes in…
Clinical Pathways as Safety Specifications for Physical AI in Hospital Wards
arXiv:2607.19827v1 Announce Type: new Abstract: Ensuring safety in Physical AI systems operating in real-world environments is a critical challenge, particularl…
NavVerse: Benchmarking Indoor-to-Outdoor Embodied Navigation in Continuous Robot Simulation
arXiv:2607.19695v1 Announce Type: new Abstract: Robots deployed in delivery, campus, and emergency-response settings often need to navigate from buildings to st…
LENS: LLM-guided Environment Simplification for Planning and Control in Clutter
arXiv:2607.19633v1 Announce Type: new Abstract: Despite recent advances in general-purpose robotic manipulation, real-world multi-object clutter remains challen…

Medtronic to launch AI compute platform for the operating room
Touch Surgery bridges pre-operative planning and training, intra-operative tele-mentoring and tele-proctoring, and post-operative insights. The post Medtronic t…
Computing on the Fly: Navigating a Vision for the Future of Drone Computing
arXiv:2607.19213v1 Announce Type: new Abstract: The report envisions a decade in which drones move goods, medical supplies, and information at a scale comparabl…
Recti-Q: Feature-Space Rectification for Out-of-Distribution-Robust Quantized Perception in Edge Robotics
arXiv:2607.18540v1 Announce Type: cross Abstract: Robotic perception pipelines increasingly rely on large vision backbones deployed on SWaP-constrained edge pla…
Correct-by-Construction Behavior Tree Synthesis from Signal Temporal Logic Specifications with Application to Robotic Missions
arXiv:2607.18731v1 Announce Type: new Abstract: Behavior Trees (BTs) are widely adopted for complex task execution in robotics, providing modular, reactive cont…
TiBCLaG: Hybrid design approach for a trigger-induced bistable compliant laparoscopic grasper
arXiv:2603.18559v2 Announce Type: replace Abstract: Industrial laparoscopic graspers rely on multi-link rigid mechanisms manufactured to tight tolerances, resul…
RAPT: Model-Predictive Out-of-Distribution Detection and Failure Diagnosis for Sim-to-Real Humanoid Deployment
arXiv:2602.01515v2 Announce Type: replace Abstract: Deploying learned control policies is risky because policies that appear robust in simulation can confidentl…
Fly, Track, Land: Infrastructure-less Magnetic Localization for Heterogeneous UAV-UGV Teaming
arXiv:2603.08926v2 Announce Type: replace Abstract: Persistent air ground robot teams require nano UAVs that can leave a mobile UGV, perform short scouting or i…
MVP-Tac: A Miniaturized Dual-Modal Vision and Photoelastic Tactile Sensor for Robot-Assisted Minimally Invasive Surgery
arXiv:2607.18660v1 Announce Type: new Abstract: Robot-assisted minimally invasive surgery (RMIS) offers major benefits over open and conventional laparoscopic p…
Intelligent Multi-UAV Navigation in ITNTNs: A Hierarchical LLM Approach
arXiv:2607.18604v1 Announce Type: new Abstract: The deployment of high-speed Uncrewed Aerial Vehicles (UAVs) in 3D aerial highways necessitates robust coordinat…
Beyond Fixed Goal Delivery: Online POMDP Planning for Target Interception in Crowds
arXiv:2607.18517v1 Announce Type: new Abstract: Target interception in crowded environments requires reaching a moving objective while navigating among multiple…

MISUMI Americas releases reshoring report, supports manufacturing training bill
MISUMI Americas has examined reshoring of U.S. manufacturing and supported legislation to send workers overseas for training. The post MISUMI Americas releases …