Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesRobustVLA: On Robustness of Vision-Language-Action Model against Multi-Modal Perturbations
arXiv:2510.00037v5 Announce Type: replace-cross Abstract: In Vision-Language-Actionf(VLA) models, robustness to real-world perturbations is critical for deploym…
UMCP: A Unified Multi-Task Collaborative Perception Network for Luggage Trolley Pose Estimation
arXiv:2607.17950v1 Announce Type: new Abstract: In robotic autonomous luggage trolley collection, robots must continuously localize scattered luggage trolleys i…
Foresight Residual RL for Long-Horizon Robot Manipulation with Vision-Language-Action Models
arXiv:2607.16506v1 Announce Type: new Abstract: Vision-Language-Action (VLA) policies offer strong general-purpose manipulation priors, but often fail on tight-…
Manifold-Guided Motion Planning for Tight Assemblies
arXiv:2607.17898v1 Announce Type: new Abstract: Motion planning for rigid-body assembly poses a fundamental challenge in robotics due to tight geometric constra…
SinD 2.0: A Multi-City UAV Dataset with Semantic Risk Annotations for SOTIF-Oriented Safety Validation at Signalized Intersections
arXiv:2607.16943v1 Announce Type: new Abstract: Safety validation at signalized intersections remains a critical bottleneck for the deployment of autonomous dri…
GLidE-SLAM: GL-Accelerated Indirect-Direct Embedded SLAM
arXiv:2607.16897v1 Announce Type: new Abstract: With the growing demand for robotics, autonomous drones, and wearable extended reality systems, the deployment o…
Unsupervised Discovery of Failure Taxonomies from Deployment Logs
arXiv:2506.06570v4 Announce Type: replace Abstract: As robotic systems become increasingly integrated into real-world environments, ranging from autonomous vehi…
Physically-Feasible Reactive Synthesis for Terrain-Adaptive Locomotion
arXiv:2509.23185v2 Announce Type: replace Abstract: We present an integrated planning framework for quadrupedal locomotion over dynamically changing, unforeseen…
xperception -- Making Robotic Grasping Easier
arXiv:2607.16312v1 Announce Type: cross Abstract: The transition toward high-mix low-volume manufacturing demands flexibility in robotic manipulation. However, …
Multi-Resolution Voxelized Map-Based Stereo Visual-Inertial Odometry
arXiv:2607.17332v1 Announce Type: new Abstract: Incorporating prior maps significantly enhances the accuracy and robustness of pose estimation in visual-inertia…
A BIM-enabled, Agent-based Discrete-event Simulation Platform for Robotic Studies: A Method based on Graph Theory
arXiv:2607.16920v1 Announce Type: new Abstract: Indoor robots are increasingly employed for facility management tasks such as cleaning and inspection. These app…
Seeing Where to Deploy: Metric RGB-Based Traversability Analysis for Aerial-to-Ground Hidden Space Inspection
arXiv:2603.14639v2 Announce Type: replace Abstract: Inspection of confined infrastructure such as culverts often requires accessing hidden spaces whose entrance…
VersualRL: Closed-Loop Verbal Reinforcement Learning with Visual Execution Feedback for Task-Level Robot Planning
arXiv:2603.22169v3 Announce Type: replace Abstract: We introduce VersualRL, a closed-loop framework for task-level robot planning that uses visual execution fee…
Lifelong Multi-Subsystem Pickup and Delivery with Buffer-Limited Handover Stations
arXiv:2607.17724v1 Announce Type: new Abstract: Coordinating payload transfers between subsystems is a critical challenge in lifelong Multi-Agent Pickup and Del…
Receiver-Centered Robot-to-Human Handover with Grasp-Aware Object Orientation
arXiv:2607.17839v1 Announce Type: new Abstract: Collaborative robots are increasingly sharing workspaces with human operators, making tool handover a frequent a…
Does Robust VIO Need More Learning? Geometry-Verified Visual Measurements under Distribution Shift
arXiv:2607.17956v1 Announce Type: new Abstract: Learning is increasingly introduced into visual-inertial odometry (VIO), ranging from learned feature front-ends…
Hybrid Machine Learning for Articulation Angle Estimation of Truck-Semitrailer Combinations
arXiv:2607.16758v1 Announce Type: cross Abstract: Accurate articulation angle estimation of trucks with trailers is critical for autonomous driving and advanced…
Leveraging Two Robotic Arms for Tight Assembly Performance Gains
arXiv:2607.17876v1 Announce Type: new Abstract: We provide a novel end-to-end framework for the execution of an assembly operation by two robotic arms, given th…
ContactFusion: Stochastic Poisson Surface Maps from Visual and Contact Sensing
arXiv:2503.16592v2 Announce Type: replace Abstract: Robust and precise robotic assembly entails insertion of constituent components. Insertion success is hinder…
PIXIE: A Zero-Shot texture-invariant 6D pose estimation framework for unseen objects with assembly defects
arXiv:2607.16015v1 Announce Type: cross Abstract: 6D pose estimation remains a key challenge in robotics and computer vision, particularly in industrial environ…
On the Use of AI-Driven Immersive Digital Technologies for Designing and Operating UAVs
arXiv:2407.16288v4 Announce Type: replace Abstract: Uncrewed Aerial Vehicles (UAVs) offer agile, cost-effective, and efficient solutions for communication relay…
Deployment-Ready UWB Localization for Industrial Ground Robots with Automatic Anchor Calibration and Terrain-Aware Fusion
arXiv:2607.15807v1 Announce Type: new Abstract: Ultra-Wideband (UWB) ranging has become a viable option for industrial Autonomous Mobile Robot (AMR) localizatio…
Robust Silicone Pour Casting and Sensor Embedding Procedures for Soft Robotic Actuators
arXiv:2607.15422v1 Announce Type: new Abstract: Soft robots are well-suited for applications such as rehabilitation and surgery that require adaptable and safe …
Human-Inspired Neuro-Symbolic World Modeling and Logic Reasoning for Interpretable Safe UAV Landing Site Assessment
arXiv:2510.22204v3 Announce Type: replace Abstract: Reliable assessment of safe landing sites in unstructured environments is essential for deploying Unmanned A…
MemoGuard: An Adaptive Runtime for Guarding Against Memory Traps in Communication-Limited Robot Navigation
arXiv:2607.15589v1 Announce Type: new Abstract: Communication-limited robots in mission-critical scenarios such as disaster inspection and search-and-rescue mus…
EmbodiedDiffusion: End-to-End Traversability-Guided Visual Diffusion for Heterogeneous Robot Navigation
arXiv:2512.02851v4 Announce Type: replace Abstract: Visual traversability estimation is central to autonomous navigation, yet most approaches either rely on pro…
PACE: Persona Adaptation through Conversational Elicitation in Human-Robot Interaction
arXiv:2607.15579v1 Announce Type: new Abstract: Equipping humanoid robots with coherent and adaptable personas is crucial for fostering natural, engaging, and t…

Founder of Maximo discusses how robotics is accelerating solar construction
Maximo founder Deise Yumi Asami discusses the process of automating solar construction with robotics. The post Founder of Maximo discusses how robotics is accel…
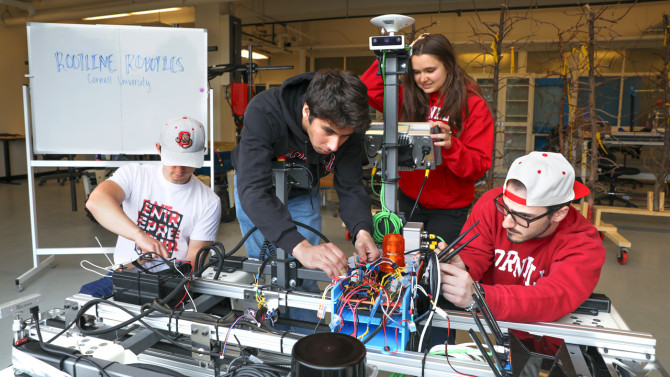
Undergrads’ weed-killing robot wins top prize
Andrew James (from left), Neil Morrison, Natalia Kurz and Michael Neiss work on a prototype of their weed-killing robot ahead of The Farm Robotics Challenge, wh…

With new funding, Monumental plans to bring its construction robots to the U.S.
Monumental acts as a subcontractor during construction tasks. Contractors pay the company for finished walls rather than for robots. The post With new funding, …