Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesParticle-Based Conformal Prediction for Contact-Aware Uncertainty Calibration in Stratified Configuration Spaces
arXiv:2608.09166v1 Announce Type: new Abstract: Reliable uncertainty representation is essential for deploying autonomous systems that interact with their envir…
SAFE-CHEM: Uncertainty-Aware Policy Switching for Robust Robotic Chemistry
arXiv:2608.09303v1 Announce Type: new Abstract: The deployment of autonomous robotic systems in chemistry laboratories is accelerating experimental workflows an…
DH-VLM: Dual-Horizon Cooperative Latent Reasoning for Autonomous Driving
arXiv:2608.09333v1 Announce Type: new Abstract: Large-scale language models for autonomous driving enable enhanced global understanding and long-horizon plannin…
JEPA-WAM: Learning Vision-Language-Action Policies with Joint-Embedding World Modeling
arXiv:2608.09381v1 Announce Type: new Abstract: Robust robot control benefits from explicitly modeling state transitions, but video-generation world action mode…
VANE: Reliable Test-Time Training for Vision-Language-Action Models via Future Visual Representation Prediction
arXiv:2608.09448v1 Announce Type: new Abstract: Test-time training (TTT) offers a lightweight way to adapt vision--language--action (VLA) policies from unlabele…
XPolicyLab: A Unified Standard and Open Ecosystem for Robot Policy Evaluation and Deployment
arXiv:2608.09892v1 Announce Type: new Abstract: Robot policy evaluation and deployment remain fragmented by model-specific software dependencies, data represent…
CADEngBench: It Looks Like CAD, but Does It Work? Evaluating Parametric Design, Assembly Reasoning, and Physics Simulation
arXiv:2608.09296v1 Announce Type: cross Abstract: A CAD model is not engineering-grade merely because it looks correct. It must satisfy design requirements, res…
A Height-Constrained 2-Point Minimal Solver for Pose Estimation from Active LED Markers with Event Cameras
arXiv:2608.09520v1 Announce Type: cross Abstract: In many autonomous applications requiring real-time localization, active marker-based systems are preferred du…
A Semantic Communication Approach to Fiducial Marker Processing in 5G-Enabled Edge SLAM
arXiv:2608.09620v1 Announce Type: cross Abstract: Autonomous robots increasingly rely on edge computing to offload computationally intensive perception tasks wh…
RAG-3DSG: Enhancing 3D Scene Graphs with Re-Shot Guided Retrieval-Augmented Generation
arXiv:2601.10168v3 Announce Type: replace-cross Abstract: Open-vocabulary 3D Scene Graph (3DSG) can enhance various downstream tasks in robotics by leveraging s…
Model Predictive Control of Hybrid Dynamical Systems
arXiv:2604.21989v2 Announce Type: replace-cross Abstract: The problem of controlling hybrid dynamical systems using model predictive control (MPC) is formulated…
Epically Powerful: An open-source software and mechatronics infrastructure for wearable robotic systems
arXiv:2511.05033v2 Announce Type: replace Abstract: Epically Powerful is an open-source robotics infrastructure that streamlines the underlying framework of wea…
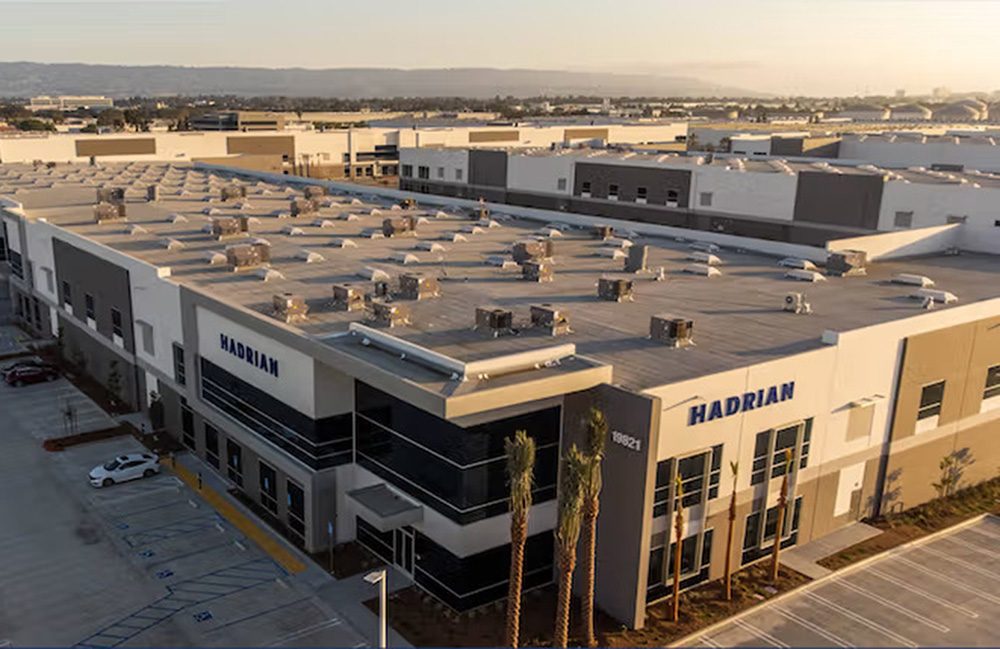
Hadrian raises $1.37B to accelerate U.S. defense, aerospace manufacturing
The raise values Hadrian at $7.87 billion. It is Hadrian's second funding round this year, following a round in January 2026. The post Hadrian raises $1.37B to …
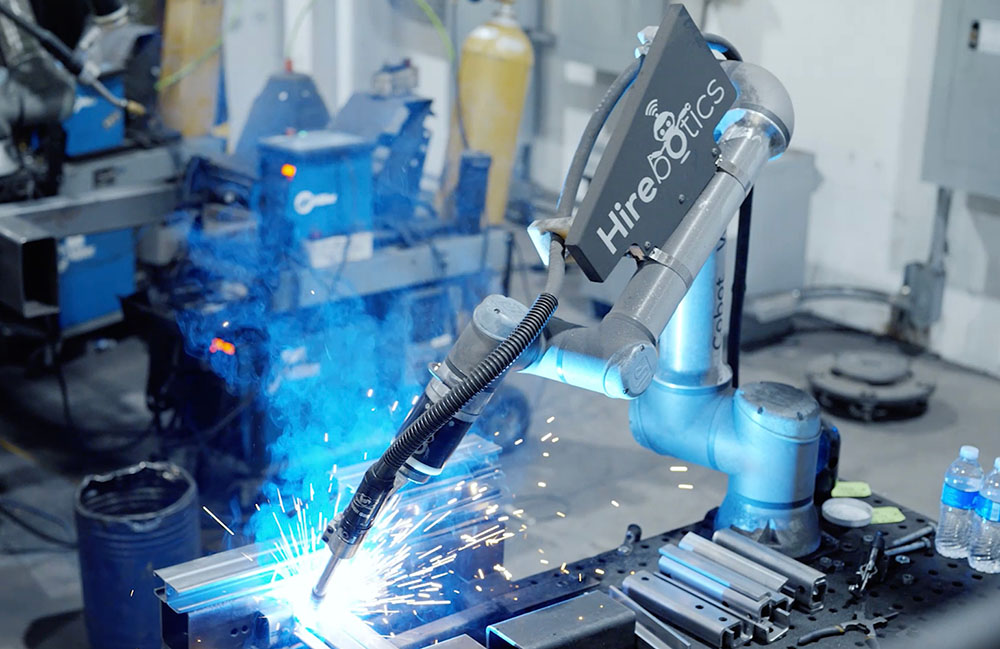
Tate deploys 58 Hirebotics cobot welders across multiple facilities
Tate decided to move from traditional hand welding to an agile, cloud-connected automation network powered by Hirebotics. The post Tate deploys 58 Hirebotics co…
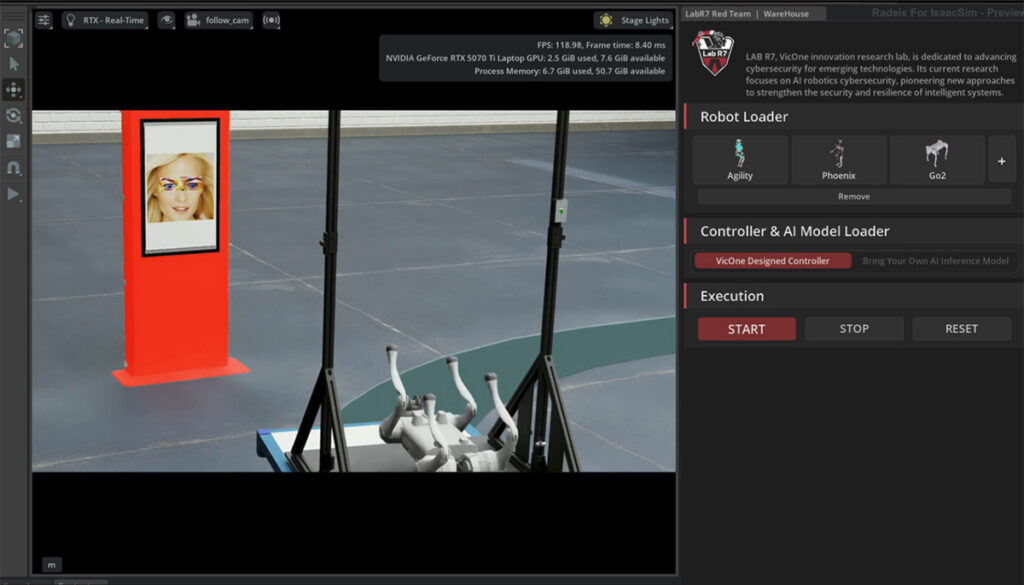
VicOne releases free NVIDIA Isaac Sim cybersecurity extension based on DEF CON 34 research
VicOne says its free Radeis Extension for NVIDIA Isaac Sim enables developers to test robot cyber safety before deployment. The post VicOne releases free NVIDIA…
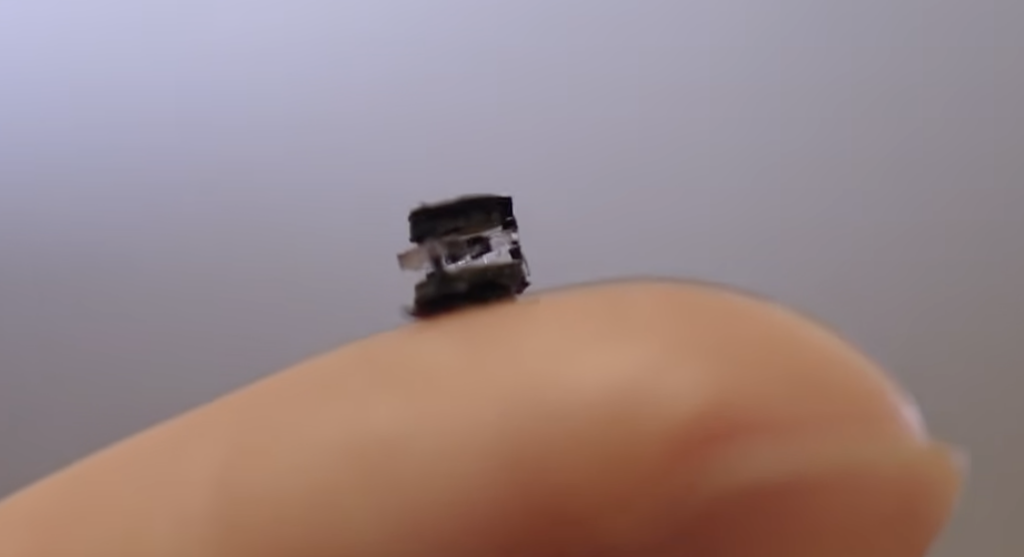
A ‘5-in-1’ seed-sized surgical robot
Scientists from Nanyang Technological University, Singapore (NTU Singapore) have developed a tiny seed-sized robot that can navigate across soft and uneven surf…
Representation Handoffs for OpenArm-Based Laboratory Mobile Manipulation
arXiv:2608.07154v1 Announce Type: new Abstract: Open-source robotics and foundation models have lowered the barrier to embodied AI, yet language-guided laborato…
Benchmarking and Reasoning Distillation of Large Language Models for Feedback Controller Design in Complex Dynamical Systems
arXiv:2608.07004v1 Announce Type: new Abstract: Although remarkable capabilities have been demonstrated by Large Language Models (LLMs) across scientific domain…
Automated Terminal-to-Housing Assembly System for Flat Ribbon Cable Harness
arXiv:2608.06996v1 Announce Type: new Abstract: This paper presents a sensor-minimal automated assembly system for bidirectional single-row flat ribbon cable ha…
Unordered Landmark Visual Navigation
arXiv:2608.06833v1 Announce Type: new Abstract: Image-goal navigation is a fundamental capability for embodied AI, yet its practical deployment is strained by s…
LyEvO: Lyapunov-Guided Evolutionary Optimization for Safe and Robust Sim-to-Real Policy Learning
arXiv:2608.06481v1 Announce Type: new Abstract: Training controllers that are safe and robust in simulation, and systematically assessing their readiness for re…
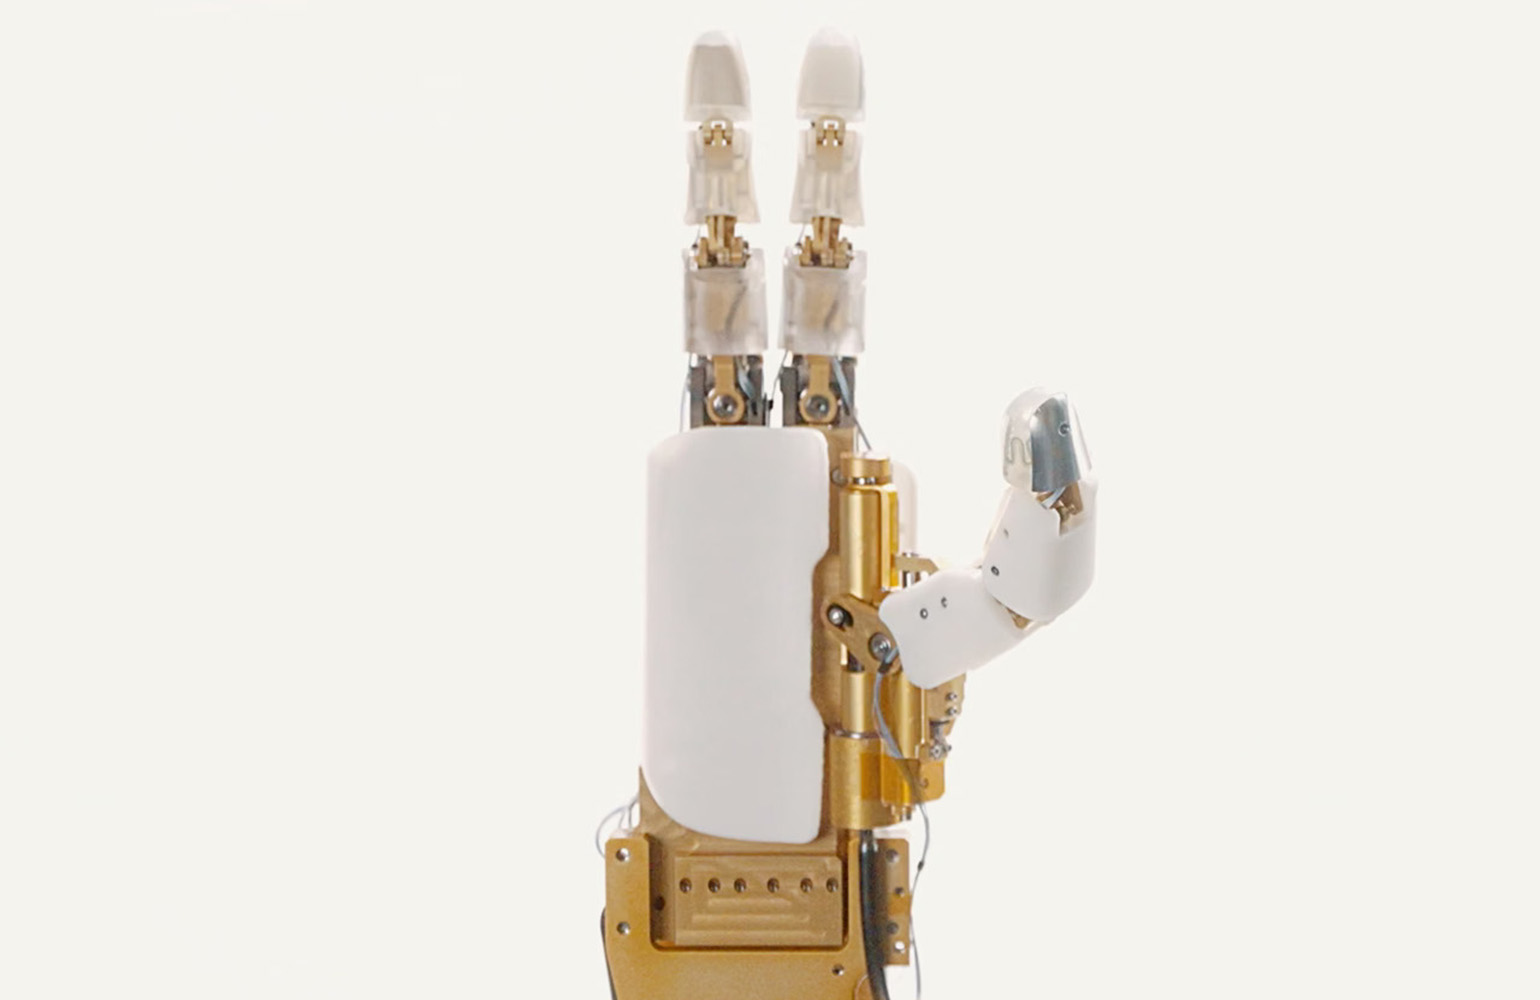
Tacta Systems takes aim at high-skilled manufacturing work with TactaBot
Tacta Systems unveiled a three-part system, including its robotic hand, that enables users to teach its robot new dexterous skills. The post Tacta Systems takes…
Building robots that survive the warehouse
Nomagic says its real moat is production data, because the messiness of real warehouses is where robots either prove themselves or fail. The post Building robot…
ErgoSurf: Ergodic Control for the Coverage of Unknown Surfaces
arXiv:2608.06208v1 Announce Type: new Abstract: Contact-centric tasks on surfaces, ranging from inspection and cleaning to sanding and polishing, require robots…
Robotic Nanoparticle Synthesis via Solution-based Processes
arXiv:2604.12169v2 Announce Type: replace Abstract: We present a screw geometry-based manipulation planning framework for the robotic automation of solution-bas…
Adaptive-WAM: Quality-Guided Early-Exit Planning from Intermediate Video-Diffusion Features
arXiv:2608.06008v1 Announce Type: new Abstract: Large video diffusion models provide rich spatiotemporal priors for autonomous driving, but existing world-actio…
Coordinated Multi-Robot Disassembly for Makespan Optimization of Large-Scale Assemblies
arXiv:2608.05830v1 Announce Type: new Abstract: Multi-robot task and motion planning for disassembly tasks requires robots to operate in confined workspaces whi…
Failing Gracefully: Mitigating Impact of Inevitable Robot Failures
arXiv:2608.05313v1 Announce Type: new Abstract: Service robots operate in household environments shared with humans, pets, and everyday objects, where they are …
A System for Train Condition Monitoring and Structural Health Assessment of Rail Vehicles
arXiv:2608.05221v1 Announce Type: new Abstract: The ongoing digitalization of rail systems and the increasing use of artificial intelligence (AI) are fundamenta…
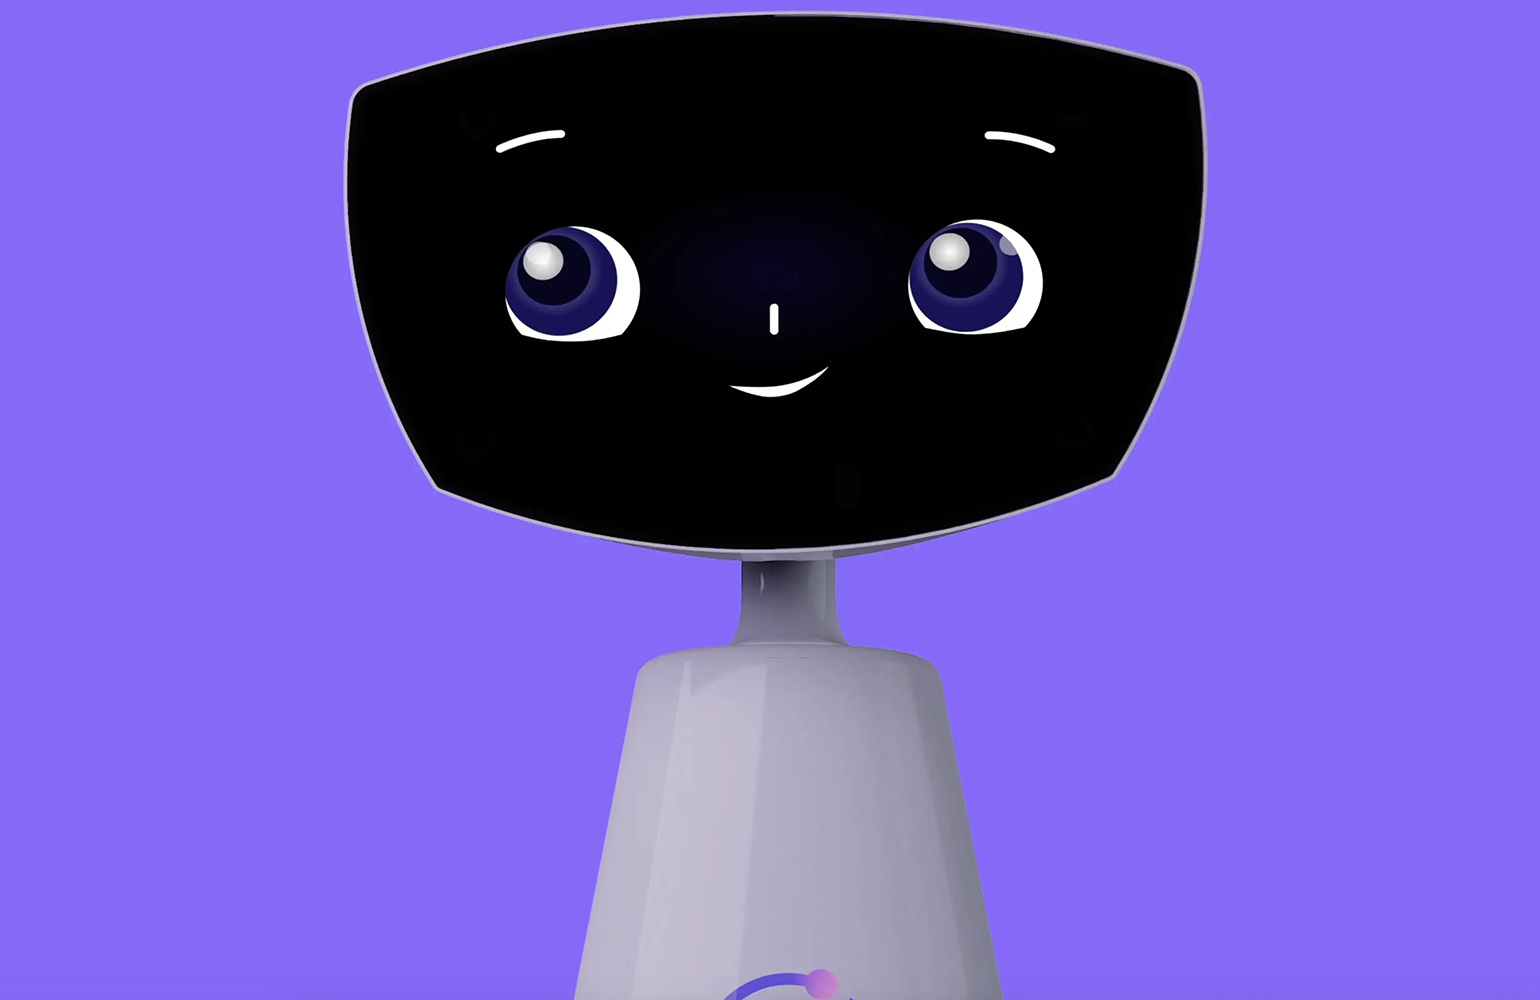
How Robin, the robotic companion, keeps patients calm during hospital visits
Robin is deployed across 30 different health systems, and Expper has plans to deploy 10 more in different states. The post How Robin, the robotic companion, kee…