Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesFrom Reach to Insert: Tactile-Augmented Precision Assembly under Sub-Millimeter Tolerances
arXiv:2605.04649v2 Announce Type: replace Abstract: High-precision assembly frequently involves tight-tolerance insertions, where even slight pose errors can ca…

How Protolabs turns CAD files into parts in under 24 hours
Protolabs CTO Marc Kermisch explains how AI, simulation, and design for manufacturing turn CAD files into production parts faster. The post How Protolabs turns …
Manufacturing Complex Airtight Soft Pneumatic Actuators for Soft Robotics: Process Evaluation and Optimization
arXiv:2608.13233v1 Announce Type: new Abstract: Manufacturing complex soft pneumatic actuators remains challenging because geometric fidelity, compliance, struc…
Capstan-driven Continuum Surgical Robot: Design, Modeling, and Perception
arXiv:2608.13396v1 Announce Type: new Abstract: Shape and force sensing have long been critical bottlenecks in the development of compact capstan-driven continu…
Decoding Task Progress from VLA Representations
arXiv:2608.13474v1 Announce Type: new Abstract: Vision-language-action models (VLAs) are moving rapidly towards deployment as general-purpose manipulation polic…
A Browser-Native Digital Test Range for Benchmarking 4D Ocean-Glider Planning Algorithms
arXiv:2608.13511v1 Announce Type: new Abstract: Repeated in-situ evaluation of ocean-glider planners requires scarce vehicles, operators, deployment and recover…
APEX: Learning Adaptive High-Platform Traversal for Humanoid Robots
arXiv:2602.11143v3 Announce Type: replace Abstract: Humanoid locomotion has advanced rapidly with deep reinforcement learning (DRL), enabling robust feet-based …
OpenRC: An Open-Source Robotic Colonoscopy Framework for Multimodal Data Acquisition and Autonomy Research
arXiv:2604.03781v2 Announce Type: replace Abstract: Colorectal cancer screening critically depends on colonoscopy, yet existing platforms offer limited support …
AMR-Pose: An Active LED Marker-Based Relative Pose Estimation Framework With Probabilistic Switching PnP for Cooperative AUVs
arXiv:2608.12866v1 Announce Type: new Abstract: Reliable relative pose estimation between autonomous underwater vehicles (AUVs) is critical for cooperative ocea…
ARM Institute calls for defense manufacturing technology projects
The ARM Institute and the U.S. Department of War are seeking technology project submissions to help rapid U.S. production. The post ARM Institute calls for defe…
Energy-Aware Wind-Resilient Routing for Truck-Assisted Multi-UAV Delivery under Wind Uncertainty
arXiv:2608.11641v1 Announce Type: cross Abstract: Energy feasibility under wind uncertainty is a critical safety issue for low-altitude air-ground delivery. In …
Keep the Future, Drop the Rollout: RIFT for World Action Models
arXiv:2608.11521v1 Announce Type: new Abstract: World action models (WAMs) condition robot actions on predicted futures, but iterative video rollout increases d…
Learning-Based Behavior Planning for Automated Driving: Real-World Integration and Deployment
arXiv:2608.12198v1 Announce Type: new Abstract: Recent research in machine and deep learning has shown the potential of learningbased motion planning approaches…
DaViNCi: A Dataset Towards Outdoor Vision-and-Language Navigation with Continuous Actions and Dynamic Elements
arXiv:2608.11901v1 Announce Type: new Abstract: Vision-and-Language Navigation (VLN) has progressively expanded from indoor to outdoor environments. However, ex…
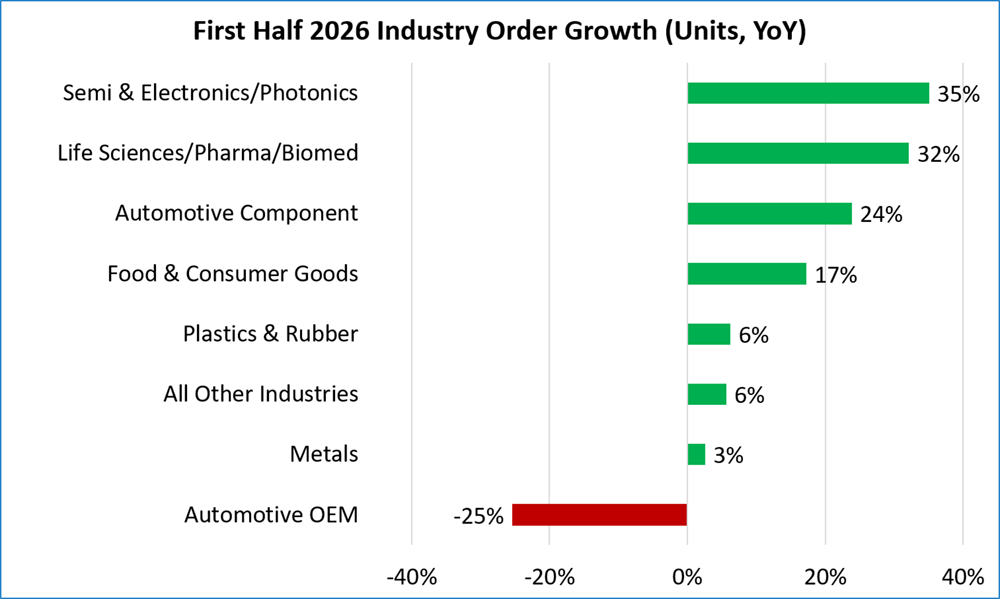
Q2 2026 robotics demand increased across industries, reports A3
A3 said that Q2 2026 robotics orders in food, electronics, and healthcare helped offset soft demand from automotive manufacturing. The post Q2 2026 robotics dem…
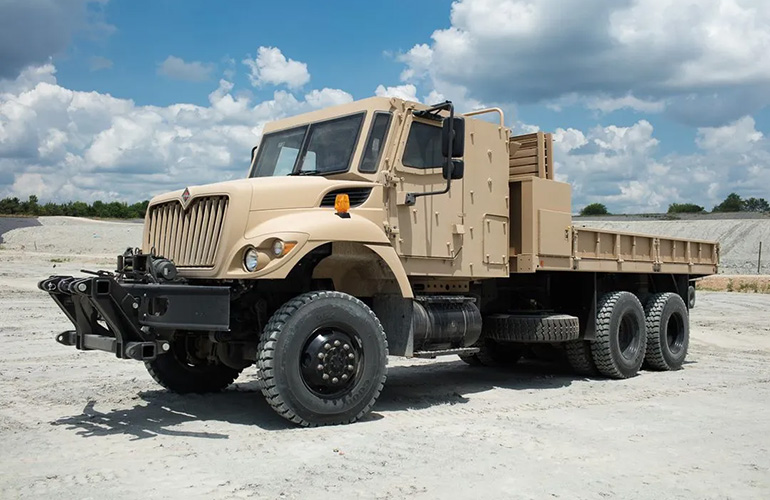
Strengthening U.S. Army sustainment: TALUS to deliver autonomous distribution
A Stratom-led team won a U.S. Army contract to develop TALUS, an autonomous logistics system for contested environments. The post Strengthening U.S. Army sustai…
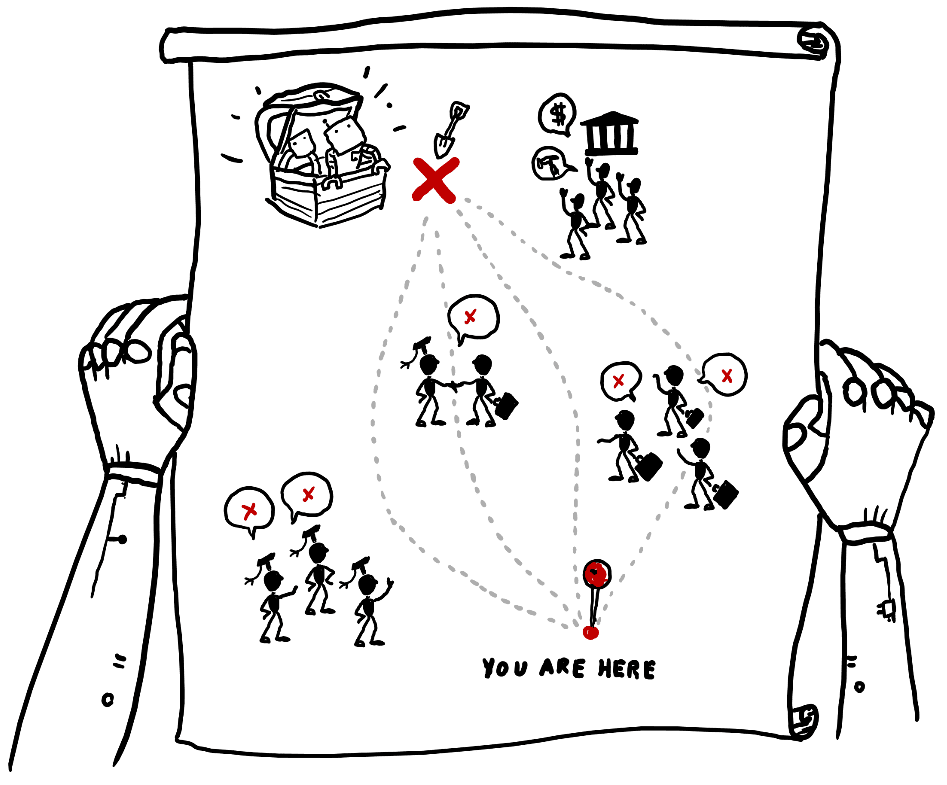
Robotics roadmaps from around the world
What’s a robotics roadmap, and why should we care? Machines with pre-defined capabilities will soon be old-school. Future machines are expected to learn and ada…
OmniVTA: Visuo-Tactile World Modeling for Contact-Rich Robotic Manipulation
arXiv:2603.19201v3 Announce Type: replace Abstract: Contact-rich manipulation tasks, such as wiping and assembly, require accurate perception of contact forces,…
BooST: Bridging Semantics and Motions for Efficient Skill Transfer
arXiv:2608.10600v1 Announce Type: new Abstract: Skill abstraction---the process of learning reusable and temporally extended behaviors---has emerged as a key pa…
Robust Sliding Mode and Admittance Control of Underactuated Aerial Manipulators for Contact-Based Inspection
arXiv:2608.10656v1 Announce Type: new Abstract: Contact-based industrial inspection requires aerial platforms to maintain stable interaction while rejecting dis…
Deployment Is Not Destiny: Robot Recomposition in the Field with Unseen Software, Hardware, and Compute Payloads
arXiv:2608.11063v1 Announce Type: new Abstract: The tight coupling of subsystems in most robots, though a natural consequence of their complexity, leads to mono…
PBD-AG: Persistent Baseline-Delta Active Graphs with Uncertainty-Aware Inspection for Long-Horizon Service Robots
arXiv:2608.10449v1 Announce Type: new Abstract: Long-horizon service robots require persistent world models that can be built autonomously in unseen environment…
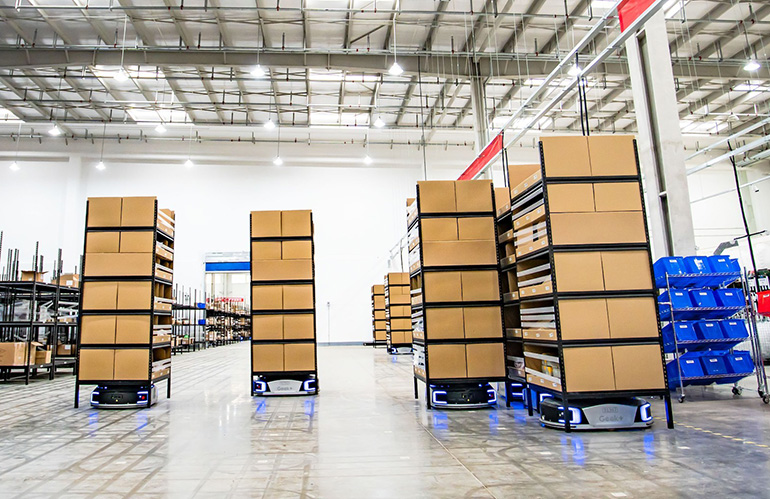
Webinar to discuss safety and scaling robot fleets in the warehouse
Industry experts will discuss how to scale mobile robots in the warehouse while maintaining both safety and productivity. The post Webinar to discuss safety and…
Self Supervised Learning from Automatically Generated Demonstrations for Visual Robotic Manipulation
arXiv:2608.07553v1 Announce Type: new Abstract: Robotic manipulation often requires object specific programming, manual data annotation, or calibrated perceptio…
AeroDPO: Unleashing Lightweight UAV Navigation with High-Fidelity Perception and Automated Preference Optimization
arXiv:2608.07557v1 Announce Type: new Abstract: Vision-Language Navigation for Unmanned Aerial Vehicles (UAV-VLN) requires rapid and reactive control in complex…
Reconfigurable Structural Robotic Assembly: Interlocking 3D Aggregations with Self-Aligning Compound Nested Lattice Modules
arXiv:2608.07576v1 Announce Type: new Abstract: Robotic construction systems often treat the material system and the robot as separate design problems, locating…
Stochastic Physics-Informed Neural Networks on Lie Groups for Learning Underwater Vehicle Dynamics
arXiv:2608.08356v1 Announce Type: new Abstract: Accurate models of underwater vehicle motion are needed for autonomous execution of marine tasks like infrastruc…
SHRIMP: Iterative Refinement of Robot Task Plans
arXiv:2608.08884v1 Announce Type: new Abstract: As collaborative robots have entered domains such as manufacturing, agriculture, and healthcare, programming or …
UnsDrive: Towards Robust End-to-End Autonomous Driving in Unstructured Scenes
arXiv:2608.09098v1 Announce Type: new Abstract: End-to-end planning has shown strong promise for autonomous driving, but most existing methods are designed for …
SpeedTuning: Speeding Up Policy Execution with Lightweight Reinforcement Learning
arXiv:2608.09138v1 Announce Type: new Abstract: While learned robotic policies hold promise for advancing generalizable manipulation, their practical deployment…