Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesPRISM: Precision and contact-rich Real-world Industrial Skill dataset with Multimodal sensing
arXiv:2608.17962v1 Announce Type: new Abstract: Recent progress in robotic learning has been fueled by large-scale datasets collected in everyday environments. …
EXPO-FT: Sample-Efficient Reinforcement Learning Finetuning for Vision-Language-Action Models
arXiv:2605.25477v2 Announce Type: replace Abstract: The ability to efficiently and reliably learn new tasks has been a foundational challenge in robotics. Visio…
KAN We Flow? Advancing Robotic Manipulation with 3D Flow Matching via KAN & RWKV
arXiv:2602.01115v3 Announce Type: replace Abstract: Diffusion-based visuomotor policies excel at modeling action distributions but are inference-inefficient, si…
Embodied-Navigator: Point, Think, Memorize, and Align for Efficient Navigation
arXiv:2608.17512v1 Announce Type: new Abstract: Although Large Vision-Language Models (VLMs) have significantly advanced embodied navigation, their direct deplo…
Bi-Layer Ant Colony Optimization for Multi-Robot Task Allocation and Routing in Delivery Applications
arXiv:2608.17416v1 Announce Type: new Abstract: This paper addresses the multi-robot task allocation (MRTA) problem, which is essential for delivery and logisti…
ORPA: Online Residual Policy Adaptation for Robot Manipulation Control with Human Feedback
arXiv:2608.17323v1 Announce Type: new Abstract: Robotic manipulation policies trained via imitation learning, such as Action Chunking with Transformers (ACT), c…
Force-Based Offset Estimation for Keyed Peg-in-Hole Assembly Using Local Gaussian Process Regression
arXiv:2608.17691v1 Announce Type: new Abstract: Key-keyway assembly tasks impose strict geometric constraints and are highly sensitive to grasp pose deviations …
MM-BEV: Enhancing Timeliness by Computing Where and When it Matters
arXiv:2608.15437v1 Announce Type: new Abstract: Multimodal bird's-eye-view (BEV) perception combines LiDAR depth accuracy with dense camera semantics, but its h…
GAINS: Leveraging Inconsistent Human Intervention Signals in Reinforcement Learning
arXiv:2608.15707v1 Announce Type: new Abstract: Correcting robot manipulation policies through human intervention holds great promise for real-world deployment,…
FlexWorm: Primitive-augmented Hybrid Contact-motion Planning for Suction-based Multi-segment Deformable Robots
arXiv:2608.16853v1 Announce Type: new Abstract: Multi-segment suction-based soft robots are promising for inspection and maintenance in confined or fragile envi…
Pluralistic Human-Robot Interaction: Designing for Robot Interaction with Diverse Communities
arXiv:2608.16049v1 Announce Type: cross Abstract: Social robots are being developed for homes, schools, and other environments where they will interact with div…
PerFACT: Motion Policy with LLM-Powered Dataset Synthesis and Fusion Action-Chunking Transformers
arXiv:2512.03444v2 Announce Type: replace Abstract: Deep learning methods have significantly enhanced motion planning for robotic manipulators by leveraging pri…
MiDAS: A Multimodal Data Acquisition System and Dataset for Robot-Assisted Minimally Invasive Surgery
arXiv:2602.12407v3 Announce Type: replace Abstract: Background: Robot-assisted minimally invasive surgery (RMIS) research increasingly relies on multimodal data…
EcoVLA: Energy-Efficient Device-Edge Co-Inference for Vision-Language-Action Models under Real-Time Constraints
arXiv:2608.15502v1 Announce Type: cross Abstract: Vision-Language-Action (VLA) models have emerged as a promising foundation for Embodied AI, but their high inf…
Observation-Constrained Joint-Space Viewpoint Optimization for Robotic Inspection of Cylindrical Cavities
arXiv:2608.16442v1 Announce Type: new Abstract: Inspection is a core capability in many mobile robotics applications, including industrial facility monitoring, …
MISTac: A Vision-Based Tactile Sensor for Minimally Invasive Surgery
arXiv:2608.14772v1 Announce Type: new Abstract: Minimally invasive and robot-assisted surgery offer many advantages over traditional open surgery, but deprive s…
ForceU-VLA: A Force-Aware Vision-Language-Action Model for Embodied Ultrasound Scanning
arXiv:2608.15009v1 Announce Type: new Abstract: Embodied intelligent ultrasound scanning enables the automation and standardization of the ultrasound examinatio…
Language-Guided Generation for Personalized Inspection Planning
arXiv:2506.02917v2 Announce Type: replace Abstract: We propose a training-free, Vision-Language Model (VLM)-guided approach for efficiently generating trajector…
Relay-Based Coordination for Energy-Efficient Multi-Robot Pickup and Delivery
arXiv:2509.14127v3 Announce Type: replace Abstract: We consider the problem of delivering multiple packages from a single depot to distinct goal locations using…
X$^2$Localizer: Cross-grained Alignment for Progressive Cross-view Video Geo-localization
arXiv:2608.16658v1 Announce Type: cross Abstract: Cross-view Video Geo-localization (CVG) aims to localize ground-view videos by retrieving their corresponding …
Two by Two: Learning Multi-Task Pairwise Objects Assembly for Generalizable Robot Manipulation
arXiv:2504.06961v2 Announce Type: replace Abstract: 3D assembly tasks, such as furniture assembly and component fitting, play a crucial role in daily life and r…
NebulaVLA: A Dual-Frequency Vision-Language-Action Model With Guide Action for Robotic Manipulation
arXiv:2608.16503v1 Announce Type: new Abstract: Real-world deployment of Vision-Language-Action (VLA) models is often bottlenecked by efficiency-performance tra…
ViTaR: Visuo-Tactile Residual Adaptation for Foundation VLA Manipulation
arXiv:2608.15816v1 Announce Type: new Abstract: As Vision-Language-Action (VLA) models scale toward real-world deployment, contact-rich manipulation exposes a c…
Algorithm-Architecture Co-Design for Efficient VLA Inference via Speculative Inference and Verification
arXiv:2608.15636v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have demonstrated remarkable capabilities in the field of embodied AI, but t…
VTInstructor: Visual Trajectory Prompting for Navigation Instruction Generation in Continuous Environments
arXiv:2608.15284v1 Announce Type: new Abstract: Navigation instruction generation from ego-centric RGB video in continuous environments is an important yet chal…
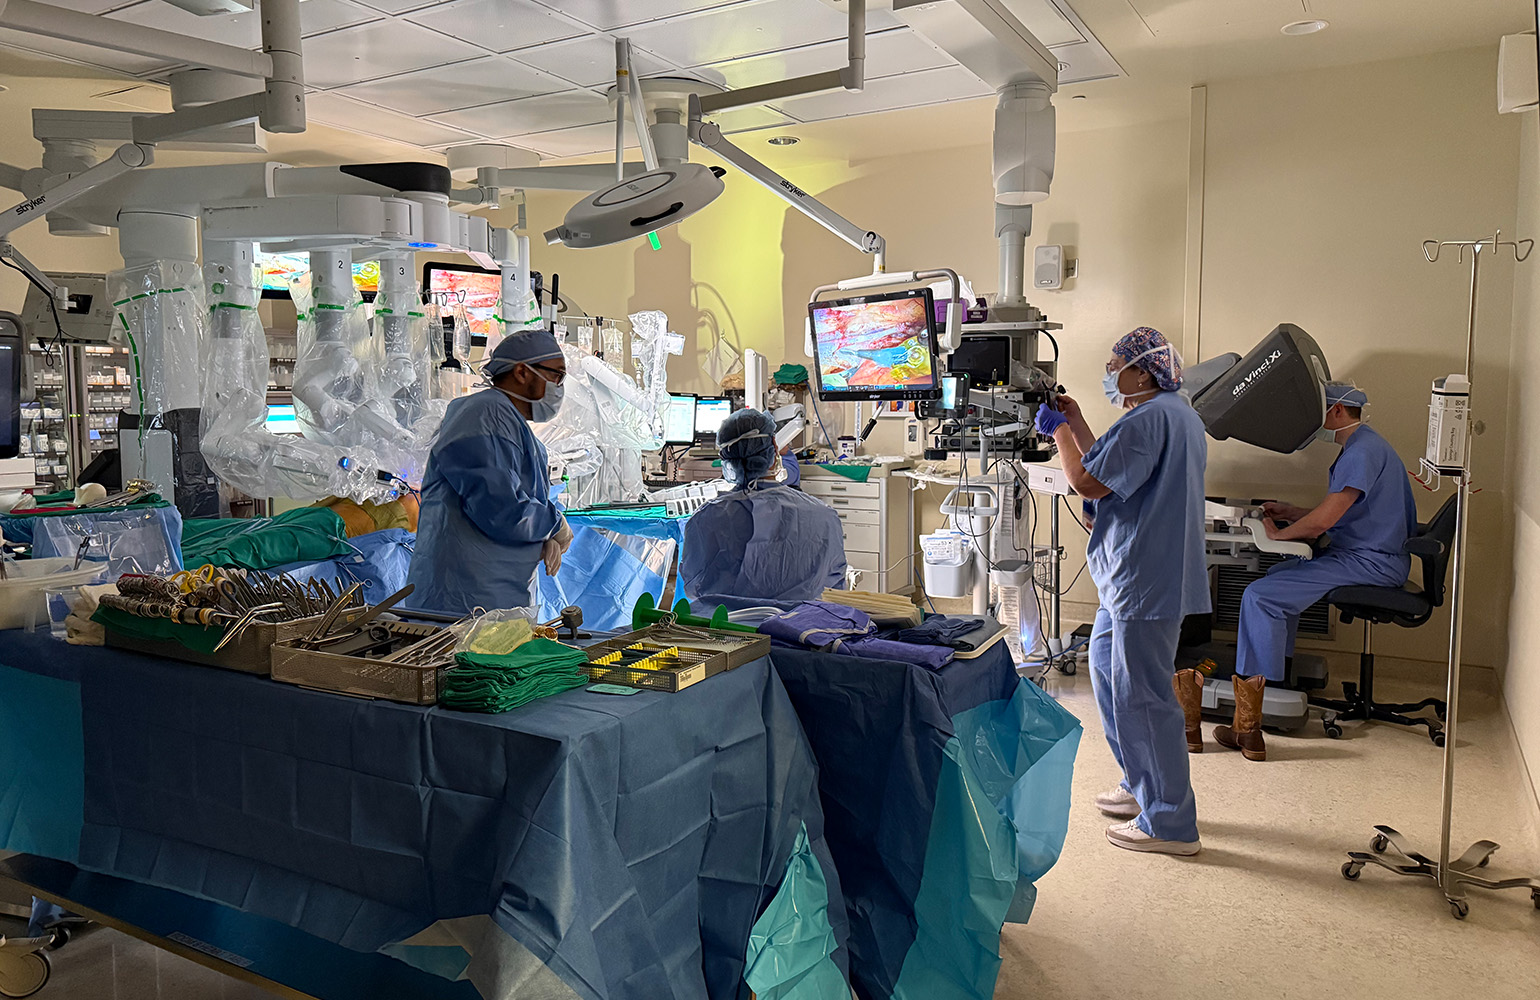
Surgeons use da Vinci surgical robot to perform common cardiac surgery
At the El Camino Health Heart and Vascular Institute, surgeons are now performing cardiac procedures with Intuitive's da Vinci robot. The post Surgeons use da V…
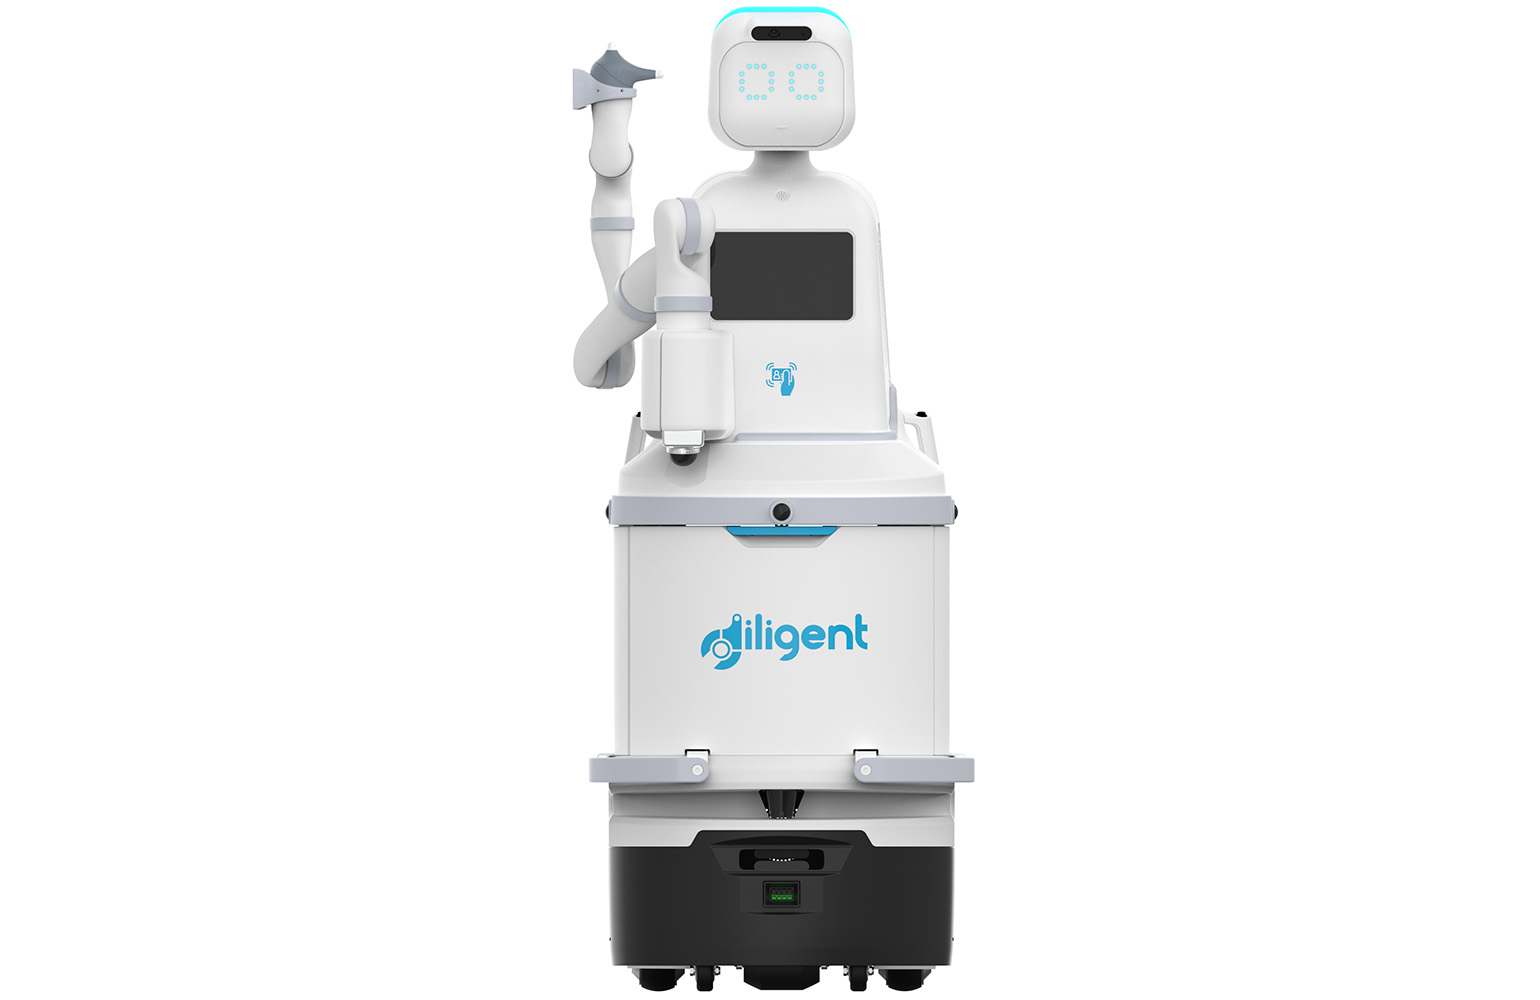
Five years of operation shape Diligent Robotics rollout of Moxi 2.0
Diligent is now rolling out Moxi 2.0 to health systems including Endeavor Health Edward Hospital and Children’s Hospital Los Angeles. The post Five years of ope…
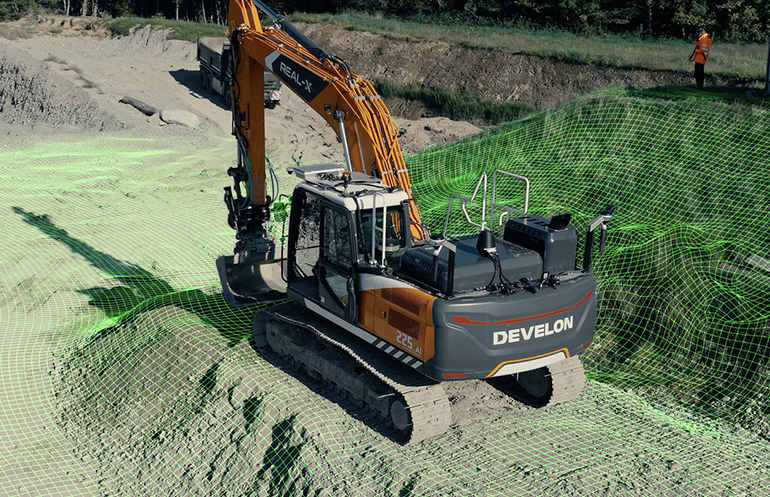
Gravis Robotics raises $200M for autonomous construction
Gravis Robotics has designed autonomy AI and hardware for a wide range of excavators and construction equipment and plans to scale globally. The post Gravis Rob…
CoViLLM: An Adaptive Human-Robot Collaborative Assembly Framework Using Large Language Models
arXiv:2603.11461v3 Announce Type: replace Abstract: With increasing demand for mass customization, traditional manufacturing robots that rely on rule-based oper…
Effective Game-Theoretic Motion Planning via Nested Search
arXiv:2511.08001v3 Announce Type: replace Abstract: To facilitate effective, safe deployment in the real world, individual robots must reason about interactions…