Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesPrivileged Critic Training Enables Sensor-Free Thruster Fault Adaptation in End-to-End RL
arXiv:2608.22976v1 Announce Type: new Abstract: Fault-tolerant navigation for thruster-actuated robots requires online adaptation to failures that are neither b…
AI Visual Inspection for Garment Production
arXiv:2608.21426v1 Announce Type: cross Abstract: The garment manufacturing industry is under increasing pressure to improve product quality, reduce costs, and …
A Unified Neural-Aided Alignment and Calibration Method for AUVs
arXiv:2608.22496v1 Announce Type: new Abstract: Autonomous underwater vehicles (AUVs) rely on the fusion of inertial navigation systems (INS) and Doppler veloci…
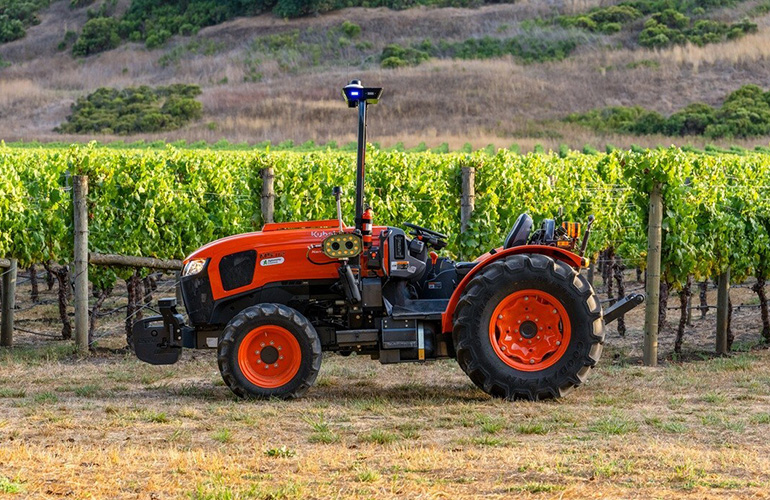
The next big AI play isn’t apps or humanoids; it’s machines with brains and brawn
For agricultural and construction equipment makers to stay relevant as workforces dwindle, they need to add AI, says Agtonomy's founder. The post The next big A…
EndoLIFT: Language-Disambiguated Latent-Conditioned Rectified Flow for Bidirectional Endoscopic Control
arXiv:2608.20478v1 Announce Type: new Abstract: Routine gastrointestinal endoscopy is intrinsically bidirectional: the instrument is advanced to reach target an…
Mining beyond Earth with Space Robots: Exploration, Sampling, and Extraction
arXiv:2608.21358v1 Announce Type: new Abstract: Space resource acquisition and utilization, commonly referred to as Space Mining, represent critical pathways fo…
Multi-Modal Traffic Sign Detection with Semantic Attributes for Autonomous Driving
arXiv:2608.20874v1 Announce Type: cross Abstract: Reliable traffic sign detection is a prerequisite for the global deployment of autonomous driving systems, whe…
SRL-MPC: Shape-Aware Reinforcement Learned Model Predictive Control
arXiv:2608.21175v1 Announce Type: new Abstract: Safe and efficient shape-aware navigation in heterogeneous crowds and robot fleets remains challenging. Traditio…
Scalable Distributed Simulation-Based Testing for Automated Driving Systems
arXiv:2608.20904v1 Announce Type: new Abstract: Virtual scenario-based testing is a key enabler for validating automated driving systems (ADS) and intelligent t…
ForeTime-VLA: Causal Future-Token Distillation from a World Action Model for Conveyor-Belt Manipulation
arXiv:2608.20735v1 Announce Type: cross Abstract: Manipulating moving objects requires a policy to anticipate contact events, yet vision-language-action (VLA) p…
Rapid Manufacturing of Lightweight Drone Frames Using Single-Tow Architected Composites
arXiv:2509.09024v2 Announce Type: replace Abstract: The demand for lightweight and high-strength composite structures is rapidly growing in aerospace and roboti…
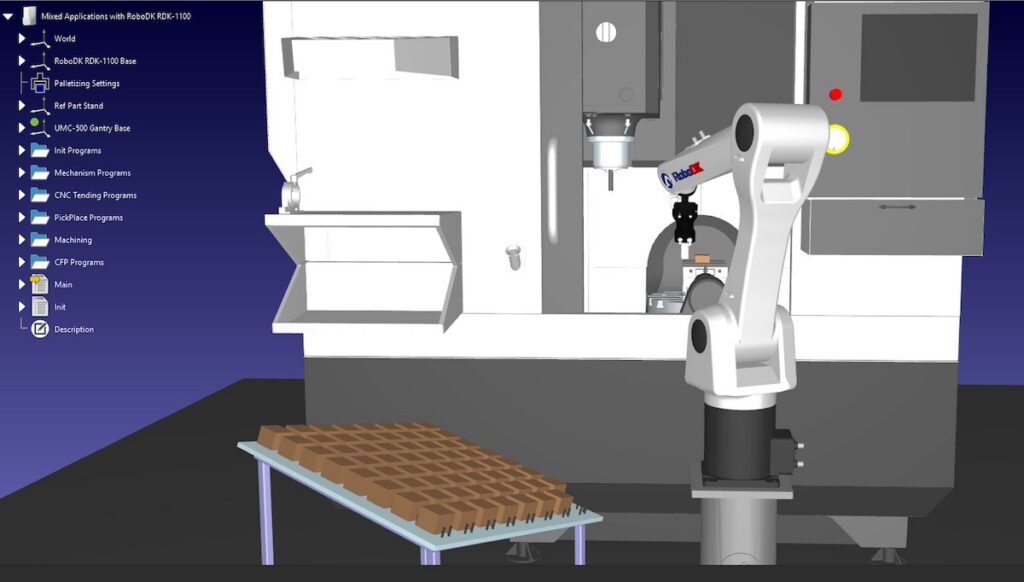
Use a digital twin to explore automation before committing capital
While a digital twin does not replace a systems integrator, it can help manufacturers evaluate robots and plan applications, says RoboDK. The post Use a digital…
How software-defined manufacturing fits into real factory operations
Roby Lynn explains how R2 Labs bridges PLCs, robots, and AI to unify fragmented manufacturing systems. The post How software-defined manufacturing fits into rea…
PVRA: A Pointwise Key-point Voting Framework for Robotic Assembly
arXiv:2608.19968v1 Announce Type: new Abstract: Modern computer vision has enabled partial autonomy in robotic assembly manipulation. However, performing autono…
UAV-Based Infrastructure Inspections: A Literature Review and Proposed Framework for AEC+FM
arXiv:2601.11665v3 Announce Type: replace-cross Abstract: Unmanned Aerial Vehicles (UAVs) are transforming infrastructure inspections in the Architecture, Engin…
SAGE: Ergodic Control for Autonomous and Adaptive Inspection of Subsea Infrastructure
arXiv:2608.19671v1 Announce Type: new Abstract: Subsea Christmas Trees (XTs) are underwater structures that use valves for directing oil flow, needing constant …
Backward Layout Search for Sequence-Constrained Robotic Assembly
arXiv:2608.18454v1 Announce Type: new Abstract: Robotic assembly layout planning must determine the assembly site and the initial pose of each part while ensuri…
Beyond Placement and Articulation: Usage-Driven Code Scenes for Embodied Interaction
arXiv:2608.18840v1 Announce Type: new Abstract: Indoor scene synthesis provides essential environments for embodied AI, robotic manipulation, and simulation-bas…
Autonomous Agricultural Tractor: Integrated Weed Detection and LiDAR Navigation for Precision Paddy Farming
arXiv:2608.19004v1 Announce Type: new Abstract: Site-specific weed management in paddy farming offers substantial reductions in herbicide use over conventional …
Zero-Shot Transfer of Force Map Estimation Across GelSight Mini Sensors
arXiv:2608.18240v1 Announce Type: cross Abstract: Despite the rapid industrialization of the touch sensor manufacturing process, most of these sensors are still…
Reproducible Multimodal Affordance Prediction
arXiv:2608.18317v1 Announce Type: cross Abstract: Affordance prediction is the identification of potential actions an agent can perform on a target object from …
Payload Swing Estimation and Damping Without Payload Parameters for Multirotor UAVs
arXiv:2608.18625v1 Announce Type: cross Abstract: Cable-suspended payload transport by multirotor UAVs is flexible but generates periodic swing disturbance that…
HarvestPoint-ACT: Explicit Target Selection and Harvest-Point Conditioning for Robotic Fruit Harvesting under Occlusion
arXiv:2608.18446v1 Announce Type: new Abstract: End-to-end imitation learning avoids hand-made robot motion for approaching and grasping, but the policy must st…
The Embodiment Gap in Robot Foundation Models
arXiv:2608.18433v1 Announce Type: new Abstract: Robot foundation models (RFMs), including vision-language-action (VLA) policies, are often discussed through a s…
Orienteering Problem with Uncertain Time-Varying Rewards: Framework and Benchmark for Everyday Service Robotics
arXiv:2608.18672v1 Announce Type: new Abstract: We present the orienteering problem with uncertain time-varying rewards (OP-UTVR), a novel variant of the orient…
Reconstruction of continuum robots by marker-free shape registration of image data using a kinematic model
arXiv:2405.15336v2 Announce Type: replace Abstract: Continuum robots are slender, flexible manipulators that navigate confined, curved workspaces and are gainin…
Progressive Experience Fusion for Multi-Task World Model Control in Endovascular Navigation
arXiv:2608.18647v1 Announce Type: new Abstract: Autonomous endovascular navigation could support the delivery of mechanical thrombectomy to underserved areas, b…
Transferable Tool-Tissue Contact Detection from Stereo Depth in Robot-Assisted Surgery
arXiv:2608.18270v1 Announce Type: new Abstract: Reliable tool--tissue contact detection can support interaction-aware control and downstream force estimation in…

Pudu Robotics launches new MP2000 autonomous forklift
Pudu Robotics has launched the MP2000, an AI-native autonomous robot designed to transport 2,000 kg loads across complex warehouse environments. The post Pudu R…

Serve Robotics to deploy its autonomous delivery robots with Grubhub
Serve's robot delivery will be available from more than 100 participating Grubhub merchants in Chicago and nearly 200 in Los Angeles. The post Serve Robotics to…