Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesSaliency-Depth Conditioning for Zero-Shot Segmentation of Communication-Tower Components in Cluttered UAV Imagery
arXiv:2608.25435v1 Announce Type: cross Abstract: Fine-grained segmentation of communication-tower components in UAV imagery is essential for automated inspecti…
GaussianDream++: Efficient 3D Gaussian World Modeling for Robotic Manipulation
arXiv:2608.25659v1 Announce Type: new Abstract: Vision-Language-Action (VLA) policies have advanced language-conditioned robotic manipulation, yet action-imitat…
Transient multimode heat transfer of an industrial automated tape laying process under rapidly changing conditions
arXiv:2608.25470v1 Announce Type: new Abstract: This work presents a transient heat-transfer model of an industrial automated tape laying (ATL) process designed…
A Taxonomy of Construction Task Activities for Robot Workers
arXiv:2608.25395v1 Announce Type: new Abstract: Recent vision-language-action models offer a path toward robots with broader repertoires than conventional task-…
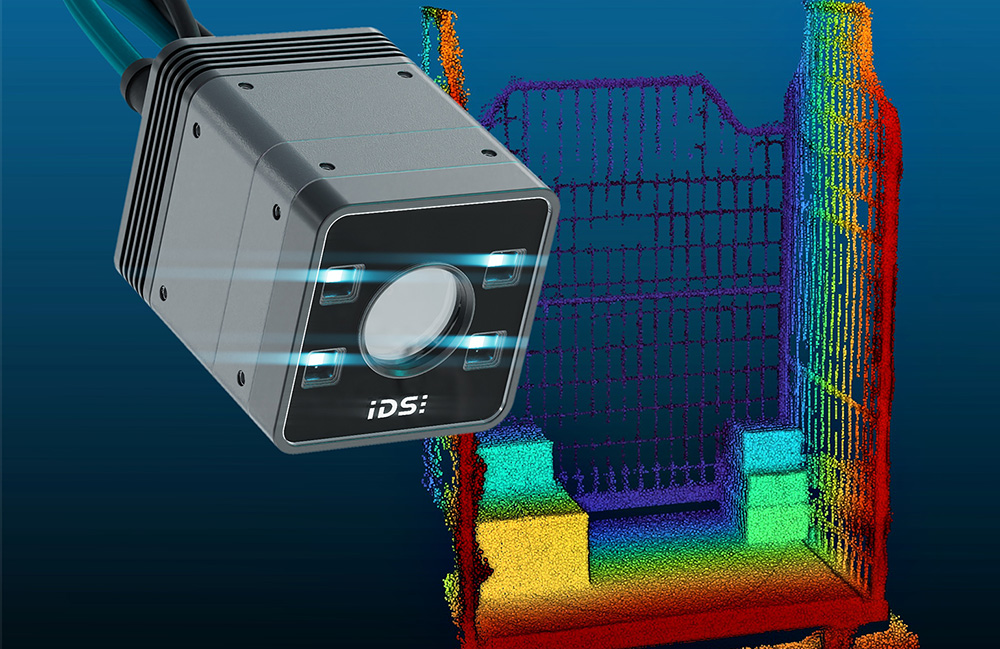
IDS Imaging adds Nion ToF sensor to its portfolio of 3D cameras
IDS said Nion is suitable for applications where precise 3D data is required at real-world process speeds, such as logistics and robotics. The post IDS Imaging …
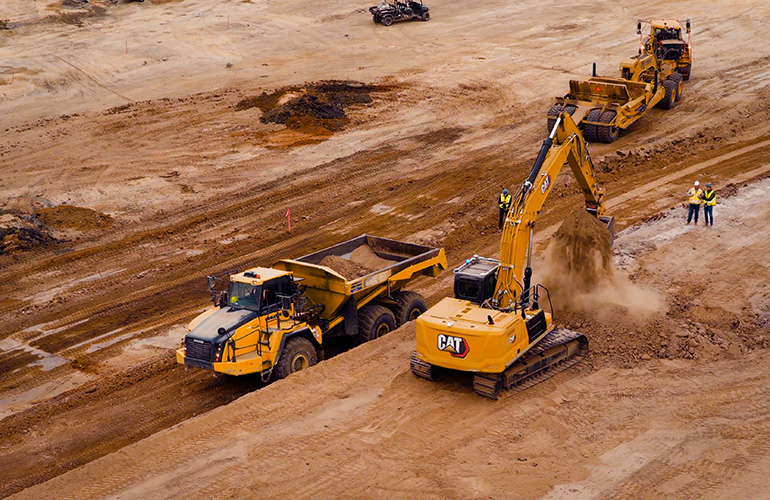
Bedrock Robotics’ first operator-free excavator deployments take off
Bedrock Robotics deploys autonomous excavators to active job sites, tackling construction labor shortages with AI-powered heavy machinery. The post Bedrock Robo…
Enhancing RL Generalizability in Robotics through SHAP Analysis of Algorithms and Hyperparameters
arXiv:2605.02867v3 Announce Type: replace-cross Abstract: Despite significant advances in Reinforcement Learning (RL), model performance remains highly sensitiv…
NeuralParker: A Reinforcement Learning Planner for Irregular Parking Environments
arXiv:2608.24485v1 Announce Type: new Abstract: Automated parking commonly assumes marked slots and short approach maneuvers. Delivery and service vehicles, how…
Learning to Act While Waiting: RL Finetuning of Generalist Robot Policies Under Inference Latency
arXiv:2608.23831v1 Announce Type: new Abstract: While reinforcement learning (RL) allows generalist robot policies to continually improve during deployment, the…
DreamLedger: Execution-Settled Credit Files for World-Model Imagination in Robot Decision Loops
arXiv:2608.23863v1 Announce Type: new Abstract: Robots are beginning to act on world-model predictions, yet reliability is still expressed through instantaneous…
Bridging Teacher Expectations and Robot Learning via Coupling Dynamics
arXiv:2608.23994v1 Announce Type: new Abstract: Human-robot teaching focuses on enabling nontechnical experts to customize robots according to their needs after…
Design-to-Plan: A Large Language Model-Based Multi-Agent Framework for Manufacturing Process Planning from 3D CAD Models and 2D Engineering Drawings
arXiv:2608.24039v1 Announce Type: new Abstract: Manufacturing process planning transforms heterogeneous design information into coherent manufacturing decisions…
Topology-Aware Decision Making for Multi-Session Localization and Mapping
arXiv:2602.17226v2 Announce Type: replace Abstract: Operating in previously visited environments is becoming increasingly crucial for autonomous systems, with d…
Design and Evaluation of a Compliant Quasi Direct Drive End-effector for Safe Robotic Ultrasound Imaging
arXiv:2410.03086v2 Announce Type: replace Abstract: Robot-assisted ultrasound scanning promises to advance autonomous and accessible medical imaging. However, e…
VIP: Variation-based Iterative-learning Planning for Robotic Navigation
arXiv:2608.24618v1 Announce Type: new Abstract: Over the past decade, autonomous robotic systems have been increasingly deployed in applications such as surveyi…
Resilience Matters for Embodied Agents System: New Metrics, Systematic Evaluation, and Optimization
arXiv:2608.23839v1 Announce Type: new Abstract: Embodied Agents System (EAS) are increasingly deployed in open-world physical domains, where reliability directl…
Constructing Predictive Surgical Path for AI-based Capsulorhexis Skill Transfer
arXiv:2608.21441v1 Announce Type: new Abstract: Automated training of surgeons is one of the most crucial factors that significantly minimize surgical training …
Model-Free Adaptive Parameter Tuning for Efficient Multi-Robot Warehouse Operations
arXiv:2608.21533v1 Announce Type: new Abstract: Robotic Fulfillment Centers (FCs) store inventory on shelves (pods) arranged in dense blocks. Retrieving a targe…
Why Personalization Matters: Cross-Subject Challenges in EMG-IMU-based HRI Activity Recognition
arXiv:2608.21620v1 Announce Type: new Abstract: This paper investigates wearable-based recognition of human activities and gestures to support Human-Robot Inter…
Contact-Rich Robotic Manipulation in Construction via Zero-Shot Learning: A Diffusion Policy-Guided Adaptive Control
arXiv:2608.22100v1 Announce Type: new Abstract: Construction robotics and automation offer promising means of improving productivity, alleviating workforce shor…
RACO: Reliability-Aware Coarse-Goal Optimization for Inspection-Oriented UAV Vision-Language Navigation
arXiv:2608.22678v1 Announce Type: new Abstract: UAV vision-language navigation (UAV-VLN) is commonly evaluated as goal reaching, but inspection-oriented deploym…
ROS2SmolVLA: Enabling Small Vision-Language-Action Models for Integration into Industrial-Grade Lightweight Robots
arXiv:2608.23320v1 Announce Type: new Abstract: Industrial demand changes the paradigms of production. Due to smaller batch sizes and more variations in product…
Reward-Free Continual Adaptation for Resilient Space Robots
arXiv:2608.23452v1 Announce Type: new Abstract: Space robots operate in extreme environments where hardware degradation can critically compromise traditional co…
Retrieval-grounded robot program generation and simulation-based correction via Model Context Protocol
arXiv:2608.21417v1 Announce Type: cross Abstract: Flexible manufacturing requires industrial robots to be reprogrammed rapidly as product variants change. This …
Agentic AI for Safety-critical Multi-drone Systems: Challenges and Opportunities
arXiv:2608.21444v1 Announce Type: cross Abstract: Multi-drone systems are increasingly positioned for safety-critical missions such as search and rescue (SAR) a…
WAM-OPD: On-Policy Distillation for World Action Models
arXiv:2608.22364v1 Announce Type: cross Abstract: World action models (WAMs) couple visual future prediction with robot action generation, but accelerated stude…
Learning Diffusion Policies for Robotic Manipulation of Timber Joinery under Fabrication Uncertainty
arXiv:2511.17774v4 Announce Type: replace Abstract: Fabrication uncertainty arising from tolerance accumulation, material imperfection, and positioning errors r…
A Latency-Aware Framework for Visuomotor Policy Learning on Industrial Robots
arXiv:2602.14255v2 Announce Type: replace Abstract: Industrial robots are increasingly deployed in construction and manufacturing tasks, where the deployment of…
Learning While Deploying: Fleet-Scale Reinforcement Learning for Generalist Robot Policies
arXiv:2605.00416v3 Announce Type: replace Abstract: Generalist robot policies increasingly benefit from large-scale pretraining, but offline data alone is insuf…
Tolerance-Dependent Inspection Disagreement Between a Fixed CMM and a Portable Articulated-Arm CMM
arXiv:2608.21404v1 Announce Type: new Abstract: Fixed coordinate measuring machines (CMMs) and portable articulated-arm CMMs are often assigned to the same insp…