News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesFSD-VLN: Fast-Slow Dual-System Modeling for Aerial Long-Horizon Vision-Language Navigation
arXiv:2607.08359v1 Announce Type: new Abstract: Vision-Language Navigation (VLN) enables UAV autonomous navigation in unknown environments by mapping language i…
Learning Adaptive Solvers for Distributed Factor Graph Optimization on Matrix Lie Groups
arXiv:2607.08735v1 Announce Type: new Abstract: Modern robotic perception increasingly involves large-scale geometric optimization problems distributed across m…
Post-Training in End-to-End Autonomous Driving
arXiv:2607.08072v1 Announce Type: cross Abstract: End-to-end models that map multimodal inputs directly to future trajectories/maneuvers have emerged as an incr…
D-CLIPSE: Distributed Consensus-based Localization with Passive Listening on Shared State Exchange
arXiv:2607.07995v1 Announce Type: new Abstract: Multi-robot localization that is accurate and consistent is imperative for downstream tasks such as planning and…
X-ACTA: eXtended Analytic Center Tension distribution Algorithm for fixed and mobile cable-driven-parallel-robot
arXiv:2607.08265v1 Announce Type: new Abstract: Steering Cable-Driven Parallel Robots (CDPRs) beyond their Wrench-Feasible Workspace (WFW) augments their capabi…
Simulator Ensembles for Trustworthy Autonomous Driving Systems Testing
arXiv:2503.08936v3 Announce Type: replace-cross Abstract: Scenario-based testing with driving simulators is extensively used to identify failing conditions of a…
Shift & Drift: A Zero-Shot Benchmark for Generalizable and Robust Autonomous Driving Motion Planning
arXiv:2607.07844v1 Announce Type: new Abstract: While closed-loop motion planners trained on large-scale, object-level datasets, e.g., nuPlan, demonstrate stron…
Time-to-Collision Based Dynamic Obstacle Avoidance Using Pretrained Vision Models for Robots in Unstructured Environments
arXiv:2607.07885v1 Announce Type: new Abstract: Dynamic obstacle avoidance in unstructured outdoor environments remains a critical challenge for autonomous mobi…
Swapping Faces, Saving Features: A Dual-Purpose Pipeline for Pedestrian Privacy in ITS
arXiv:2607.08402v1 Announce Type: cross Abstract: Large-scale and diverse datasets are needed to train AI models to take real-time decisions for autonomous vehi…
DexVerse: A Modular Benchmark for Multi-Task, Multi-Embodiment Dexterous Manipulation
arXiv:2607.08751v1 Announce Type: new Abstract: Building general-purpose dexterous manipulation policies requires benchmarks that go beyond isolated tasks to sy…
Soft Robotic Exogloves for Dexterous Mobility -- Towards Personalized Rehabilitation
arXiv:2607.07968v1 Announce Type: new Abstract: Soft robotic exogloves can provide hand rehabilitation and assistance. Fitting these gloves often relies on stan…
STEMbot: A Compliant Robot for Under-Canopy Plant Navigation
arXiv:2607.07873v1 Announce Type: new Abstract: The scalability of organic agriculture is partially limited by the labor costs associated with monitoring for pe…
Graph-Loc: Robust Graph-Based LiDAR Pose Tracking with Compact Structural Map Priors under Low Observability and Occlusion
arXiv:2602.08417v2 Announce Type: replace Abstract: Map-based LiDAR pose tracking is essential for long-term autonomous operation, where onboard map priors need…
Physics-Guided Biomechanical Gait Adaptation for Humanoid Locomotion on Extreme Sloped Terrains
arXiv:2607.07830v1 Announce Type: new Abstract: Model-free reinforcement learning has enabled impressive humanoid locomotion; however, control on steep slopes r…
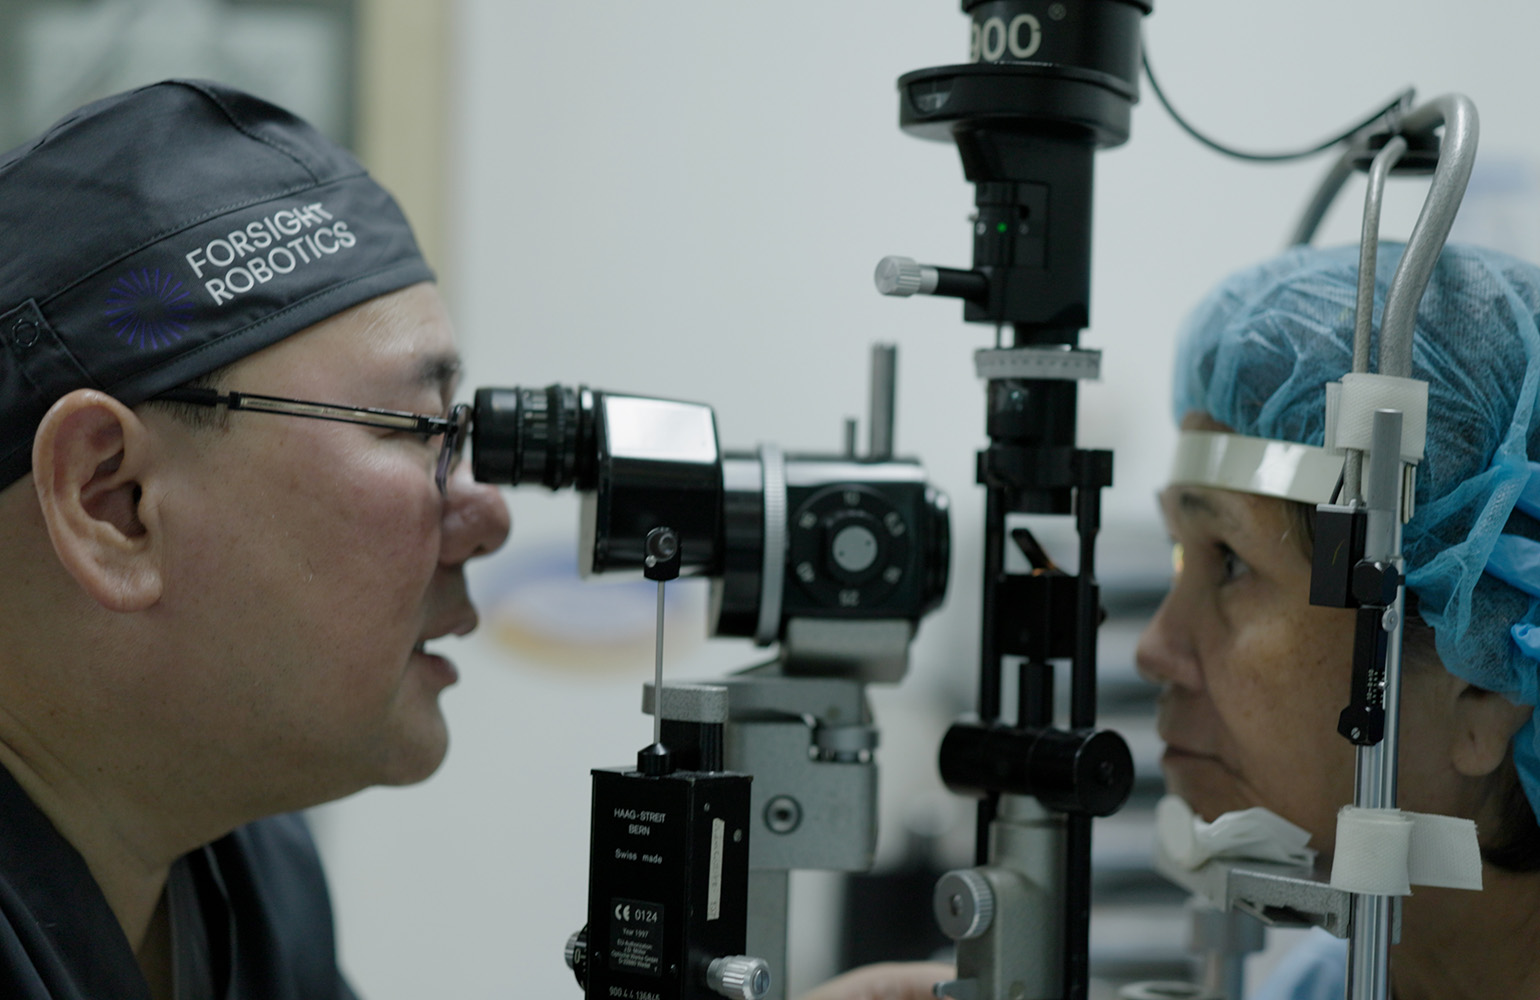
ForSight Robotics’ road to performing a fully robotic cataract surgery
ForSight Robotics' JASPER Platform assists surgeons with cataract surgeries, while still leaving the power in the surgeon's hands. The post ForSight Robotics…
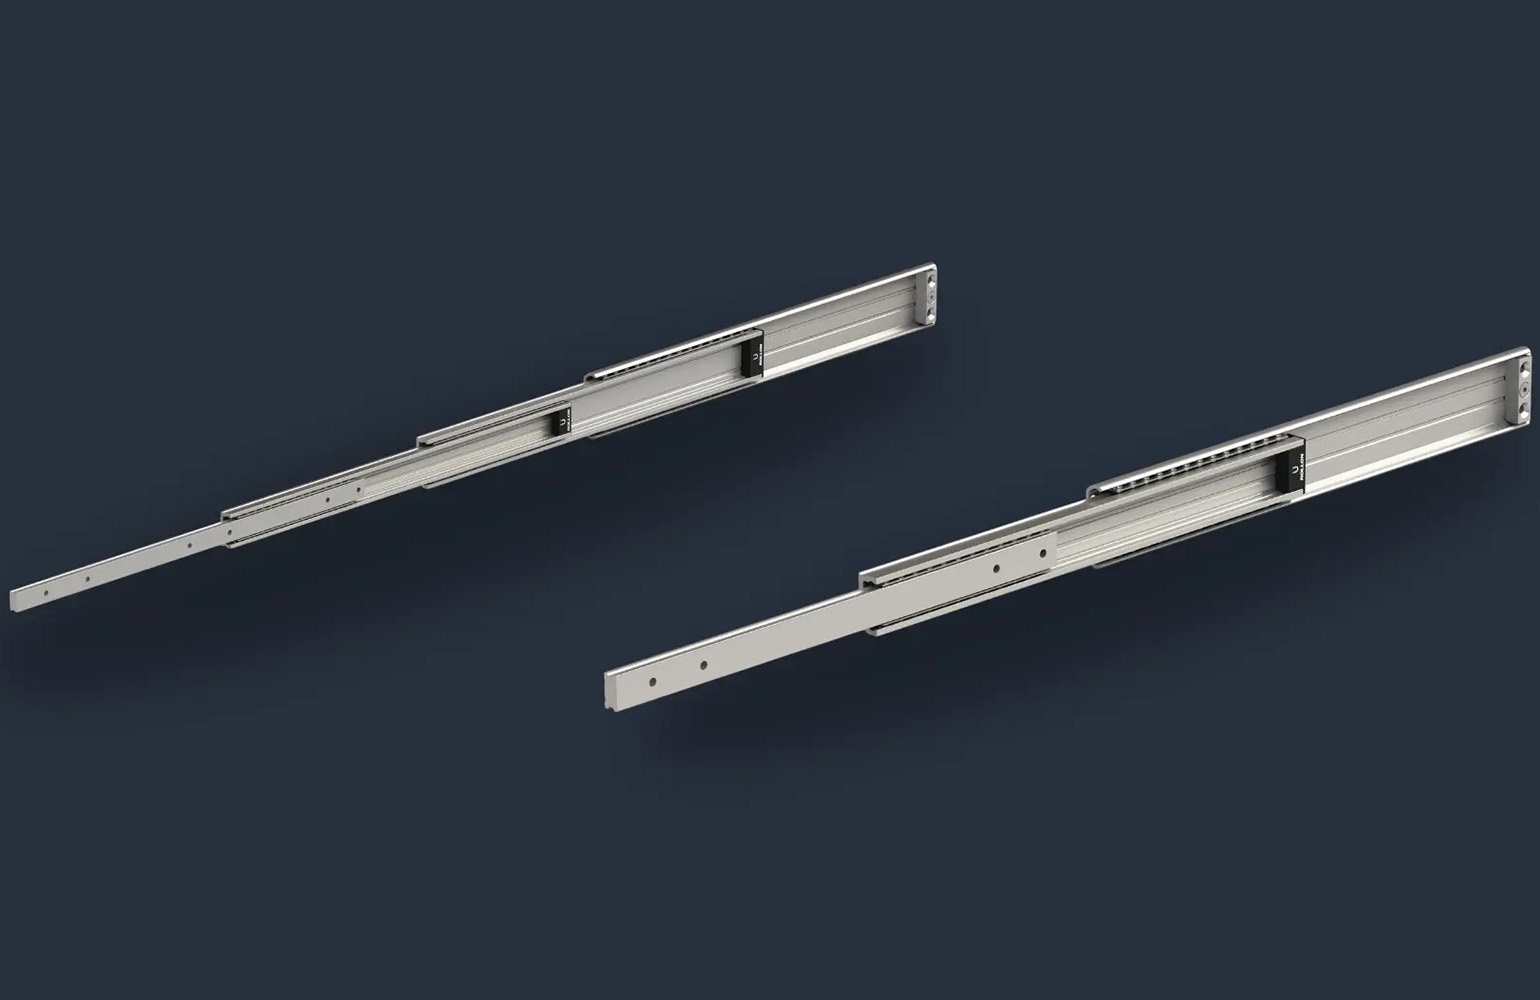
Rollon launches two telescopic rails with integrated magnets
Rollon said the magnets deliver improved load management, smoother extension, and increased durability, even under intensive operating conditions. The post Roll…
Calling all robotics startups: apply to RoboBusiness Startup Alley
We're looking for robotics startups that are creating a full system, component, or software system to show off their work at RoboBusiness. The post Calling all …
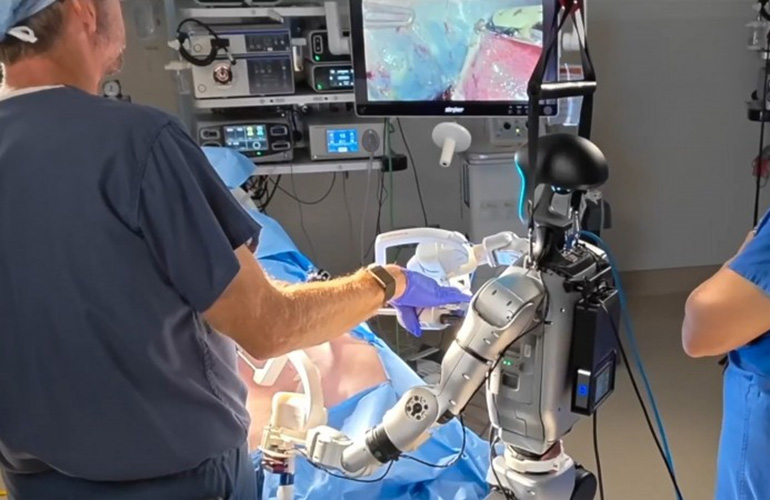
Beyond da Vinci: Why versatile humanoid robots are the next frontier in surgery
For the first time, teleoperated humanoid robots successfully performed surgeries during a UC San Diego preclinical trial. The post Beyond da Vinci: Why versati…
A Closed-Loop Multi-Agent Framework for Robust Multi-Robot Manipulation
arXiv:2607.06990v1 Announce Type: new Abstract: Multi-robot systems provide the parallelism and redundancy necessary for long-horizon tasks, while Large Languag…
Multi-Agent Robotic Control with Onboard Vision-Language Models
arXiv:2607.07403v1 Announce Type: cross Abstract: Vision Language Models (VLMs) and Vision Language Action (VLA) models have shown promise in robotic control. Y…
Compositional Motion Generation from Demonstration with Object-Centric Neural Fields
arXiv:2607.07129v1 Announce Type: new Abstract: Compositionality, by organizing complex behavior as combinations of simpler elements, enables robot learning tha…
HiMoE-VLA: Hierarchical Mixture-of-Experts for Generalist Vision-Language-Action Policies
arXiv:2512.05693v2 Announce Type: replace Abstract: Generalist vision--language--action (VLA) policies are typically trained on heterogeneous mixtures of robot …
HumAIN: Human-Aware Implicit Social Robot Navigation
arXiv:2607.07357v1 Announce Type: new Abstract: Effective social robot navigation requires sensitivity to human behavior, often revealed through subtle skeletal…
SPECTRA: Context-Conditioned Spectral Movement Primitives for Robot Skill Generalization
arXiv:2607.06978v1 Announce Type: new Abstract: Robot imitation learning for manipulation should preserve demonstrated task geometry while producing dynamically…
Initiation Safety: A Missing Dimension in Generalist-Robot Safety
arXiv:2607.07420v1 Announce Type: new Abstract: Safety for generalist robots is usually discussed in terms of motion or dialogue. We argue a third question is m…
GeoProp: Grounding Robot State in Vision for Generalist Manipulation
arXiv:2607.07101v1 Announce Type: new Abstract: Proprioception is fundamental to robotic manipulation, yet standard fusion methods often treat it as an isolated…
Context-Aware Force Estimation for Deformable Tool Manipulation in Robotic Environmental Swabbing via Few-Shot Continual Adaptation
arXiv:2607.07574v1 Announce Type: new Abstract: Robotic surface swabbing requires sustained interaction between a compliant tool and heterogeneous environments,…
SPEAR: A Simulator for Photorealistic Embodied AI Research
arXiv:2607.06701v1 Announce Type: cross Abstract: Interactive simulators have become powerful tools for training embodied agents and generating synthetic visual…
GrandTour: A Legged Robotics Dataset in the Wild for Multi-Modal Perception and State Estimation
arXiv:2602.18164v3 Announce Type: replace Abstract: Accurate state estimation and multi-modal perception are prerequisites for autonomous legged robots in compl…
RoboLight: A Dataset with Linearly Composable Illumination for Robotic Manipulation
arXiv:2603.04249v2 Announce Type: replace Abstract: In this paper, we introduce RoboLight, the first real-world robotic manipulation dataset capturing synchroni…