News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesAn Incremental Sampling and Segmentation-Based Approach for Motion Planning Infeasibility
arXiv:2501.11434v3 Announce Type: replace Abstract: We present a simple and easy-to-implement algorithm to detect plan infeasibility in kinematic motion plannin…
PhysV2A: Reachability-Gated and Semantic-Mask-Constrained Feasibility Completion for Video-to-Robot Manipulation
arXiv:2607.09365v1 Announce Type: new Abstract: Video-based manipulation provides object-centric motion priors from human demonstrations, generated videos, or R…
Vascular Geometry Characterization for AI-Based Endovascular Navigation
arXiv:2607.09130v1 Announce Type: new Abstract: Mechanical thrombectomy (MT) is a time-critical intervention for acute ischemic stroke; however, access remains …
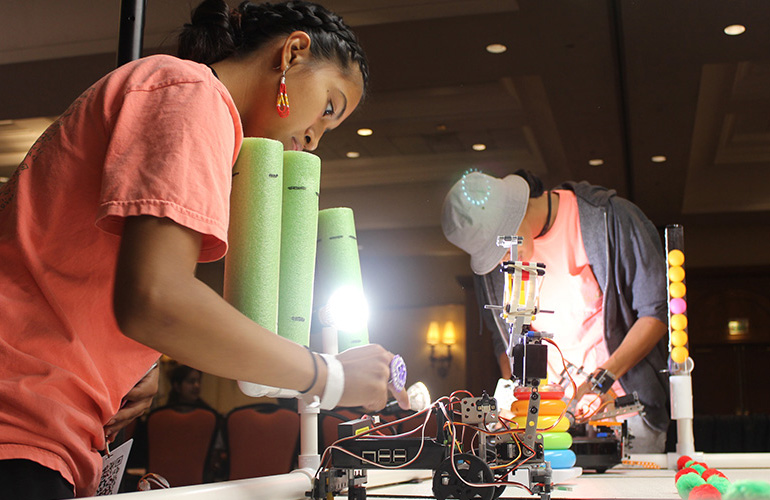
STEM education in the classroom, introducing BotBall
Botball addresses STEM education with autonomous robotics, real coding, and a level playing field driven entirely by students. The post STEM education in the cl…
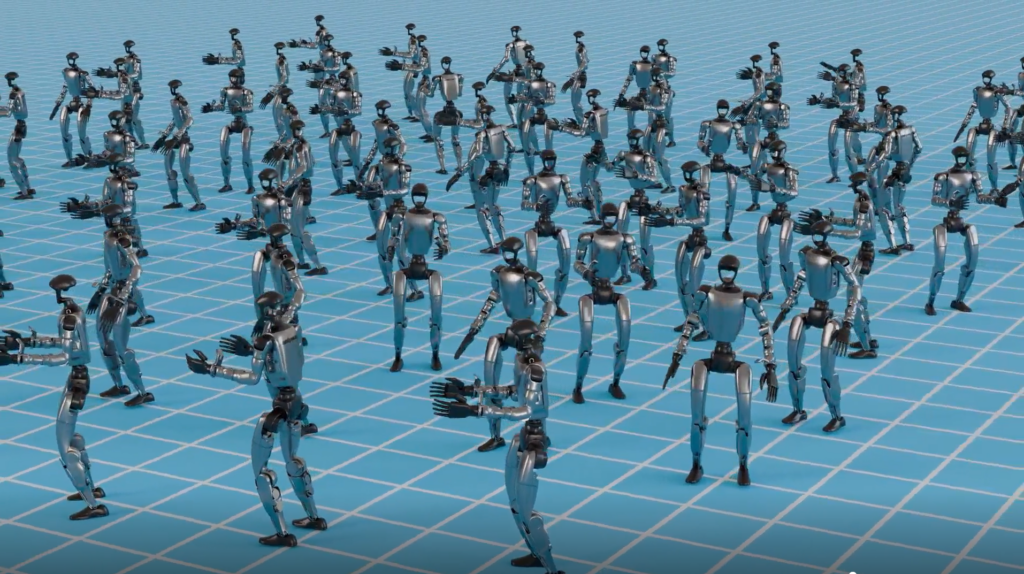
Why robotics teams need virtual gyms before deployment
To address environmental and task variability, robots can benefit from 'virtual gyms' to bridge the sim-to-real gap, says SoftServe. The post Why robotics teams…
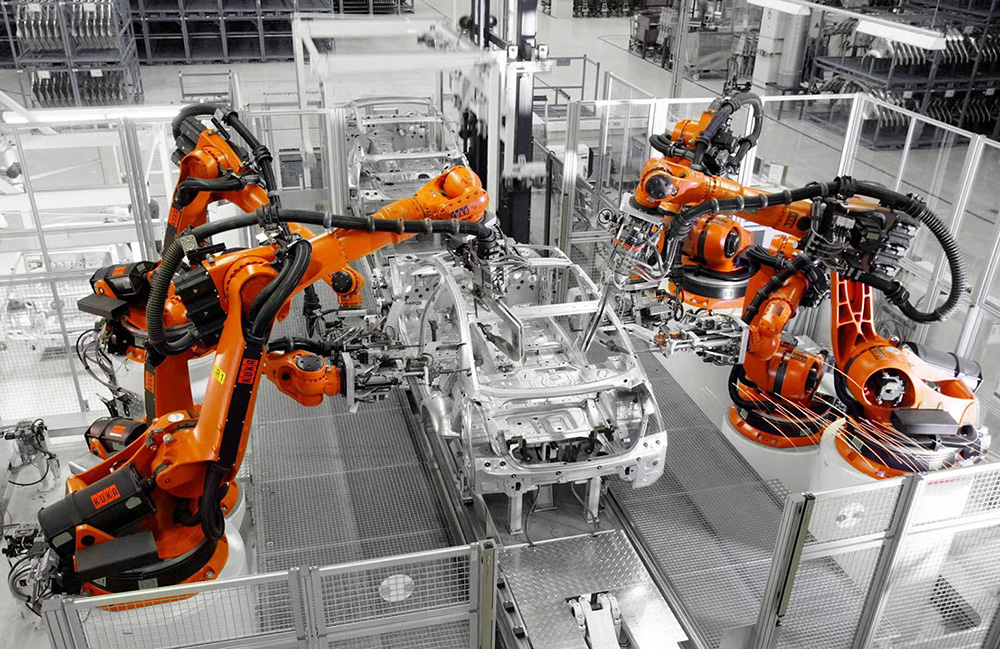
Are suppliers ready for new robot safety standards?
Suppliers that are well prepared for standard changes will benefit, while underprepared companies may face market access disruption. The post Are suppliers read…
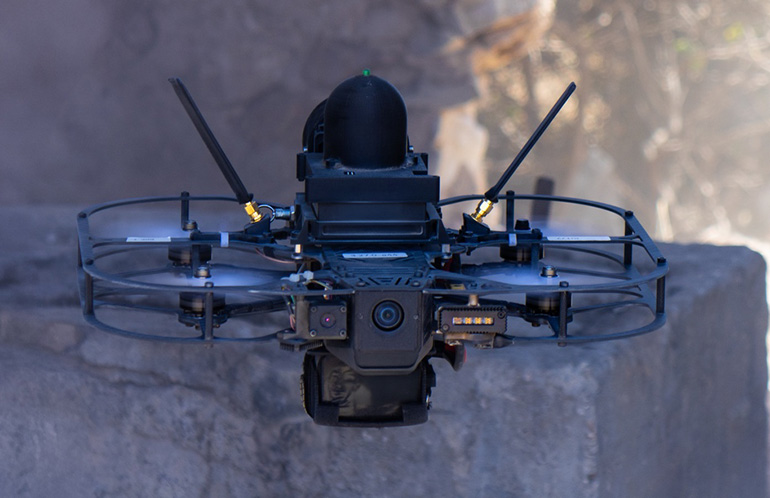
XTEND secures U.S. patent for autonomous navigation technology
XTEND said the newly granted patent expands its portfolio supporting autonomous navigation, operator assistance, and mission execution. The post XTEND secures U…
How Path Robotics uses AI to optimize robotic welding
CEO Andy Lonsberry explains how Path Robotics applies AI to welding, and UC San Diego professor Michael Yip discusses robot learning. The post How Path Robotics…
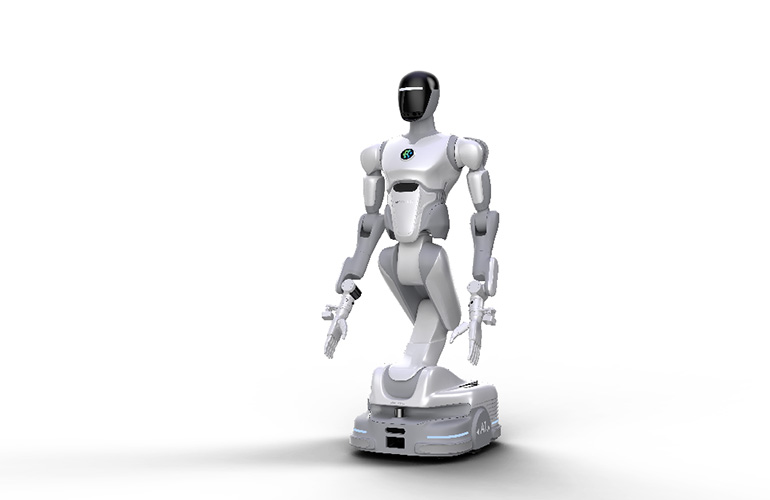
AI² Robotics raises $735M at $3B valuation for wheeled humanoid robots
Shenzhen’s Ai2 Robotics raised $735 million at a $2.8 billion valuation, backed by state, corporate, and financial giants. The post AI² Robotics raises $735M at…
OREN: Octree Residual Network for Real-Time Euclidean Signed Distance Mapping
arXiv:2510.18999v3 Announce Type: replace Abstract: Reconstructing signed distance functions (SDFs) from point cloud data benefits many robot autonomy capabilit…
SkillPlug: Unsupervised Skill Mining for Few-Shot Adaptation in Robotic Manipulation
arXiv:2607.08354v1 Announce Type: new Abstract: Learning transferable visuomotor imitation policies that generalize across diverse manipulation tasks and adapt …
Factors Influencing Conversational Engagement in Robot-Delivered Individual Cognitive Stimulation Therapy (iCST) for Dementia in Home Settings
arXiv:2607.07998v1 Announce Type: new Abstract: Social robots offer a promising means of supporting cognitive therapies for dementia care by guiding structured …
EVIS: A Physics-Grounded Event Camera Plugin for NVIDIA Isaac Sim
arXiv:2607.08098v1 Announce Type: cross Abstract: Event cameras offer microsecond temporal resolution, low latency, and high dynamic range, making them attracti…
INTENT: An LSTM Framework for Vehicle Intention Prediction in Intersection Scenarios with Comprehensive Ablation Analysis
arXiv:2607.08316v1 Announce Type: cross Abstract: Vehicle intention prediction is a pivotal aspect in the agility and safety of autonomous vehicles in all drivi…
V-VLAPS: Value-Guided Planning for Vision-Language-Action Models
arXiv:2601.00969v3 Announce Type: replace Abstract: Vision-language-action (VLA) models provide strong action priors for robotic manipulation, but their reactiv…
APIVOT: Adaptive Planning with Interleaved Vision-Language Thoughts
arXiv:2607.08024v1 Announce Type: cross Abstract: Long-horizon robot planning requires jointly reasoning over semantic task structure and geometric feasibility.…
TriphiBot: A Triphibious Robot Combining FOC-based Propulsion with Eccentric Design
arXiv:2602.01385v2 Announce Type: replace Abstract: Triphibious robots capable of multi-domain motion and cross-domain transitions are promising to handle compl…
FunHOI: Annotation-Free 3D Hand-Object Interaction Generation via Functional Text Guidance
arXiv:2502.20805v3 Announce Type: replace Abstract: Hand-object interaction(HOI) is the fundamental link between human and environment, yet its dexterous and co…
AnyDexRT: Calibration-Free Dexterous Hand Retargeting with Few-Shot Human Guidance
arXiv:2607.08341v1 Announce Type: new Abstract: Teleoperation is a key interface for controlling dexterous robotic hands and collecting demonstrations for imita…
A Collaborative Reasoning Framework for Anomaly Diagnostics in Underwater Robotics
arXiv:2511.03075v2 Announce Type: replace Abstract: The safe deployment of autonomous systems in safety-critical settings requires a paradigm that combines huma…
ARDY: Autoregressive Diffusion with Hybrid Representation for Interactive Human Motion Generation
arXiv:2607.08741v1 Announce Type: cross Abstract: Generating realistic 3D human motions in real-time within interactive applications is key for animation, simul…
Native Video-Action Pretraining for Generalizable Robot Control
arXiv:2607.08639v1 Announce Type: new Abstract: The advent of video-action models offers a promising path for robot control. Nevertheless, we argue that repurpo…
Towards Soft Robotic Exogloves for Musculoskeletal Manipulation to Reduce Pain and Spasticity
arXiv:2607.07958v1 Announce Type: new Abstract: Hand spasticity and resulting pain affect 12 million people worldwide, including stroke survivors, arthritis pat…
EgoWAM: World Action Models Beyond Pixels with In-the-Wild Egocentric Human Data
arXiv:2607.08436v1 Announce Type: new Abstract: Egocentric human data offers scalable supervision for robot manipulation. However, behavior cloning entangles tr…
In vivo feasibility study of humanoid robots in surgery
arXiv:2607.07972v1 Announce Type: new Abstract: Recent advances in actuation, control and learning have rapidly pushed humanoid robots from a distant vision tow…
ContactMimic: Humanoid Object Interaction via Contact Control
arXiv:2607.08742v1 Announce Type: new Abstract: Keypoint tracking alone is insufficient for object interaction tasks such as sitting on a chair, wiping a board,…
Idiobionics: The Unification of Privacy and Intelligent Robotic Prostheses
arXiv:2607.07775v1 Announce Type: cross Abstract: The human body is at the center of a growing family of technologies designed to tightly and persistently coupl…
SeFA-Policy: Fast and Accurate Visuomotor Policy Learning with Selective Flow Alignment
arXiv:2511.08583v2 Announce Type: replace Abstract: Developing efficient and accurate visuomotor policies poses a central challenge in robotic imitation learnin…
Understanding and Mitigating the Video-Action Generalization Gap via Temporal Ratio
arXiv:2607.08127v1 Announce Type: cross Abstract: Generative video foundation models exhibit strong compositional priors, yet world-action models (WAMs) and vid…
A New Human-Likeness and Comfort Index for Robot Movements Along Prescribed Paths
arXiv:2607.08620v1 Announce Type: new Abstract: As human-robot interaction rapidly spreads in numerous fields, the subject of robot acceptance gains increasing …