News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesZero-Human Demonstration End-to-end Autonomous Driving with Trajectory Scorer
arXiv:2510.24108v2 Announce Type: replace Abstract: Human demonstrations are widely considered the cornerstone of end-to-end (E2E) autonomous driving despite hu…
EmbodiedGen V2: An Agentic, Simulation-Ready 3D World Engine for Embodied AI
arXiv:2607.07459v1 Announce Type: new Abstract: We present EmbodiedGen V2, a generative 3D world engine for building executable sim-ready environments for embod…
Shared Modular Recurrence in Contextual MDPs for Universal Morphology Control
arXiv:2506.08630v3 Announce Type: replace-cross Abstract: A universal controller for any robot morphology would greatly improve computational and data efficienc…
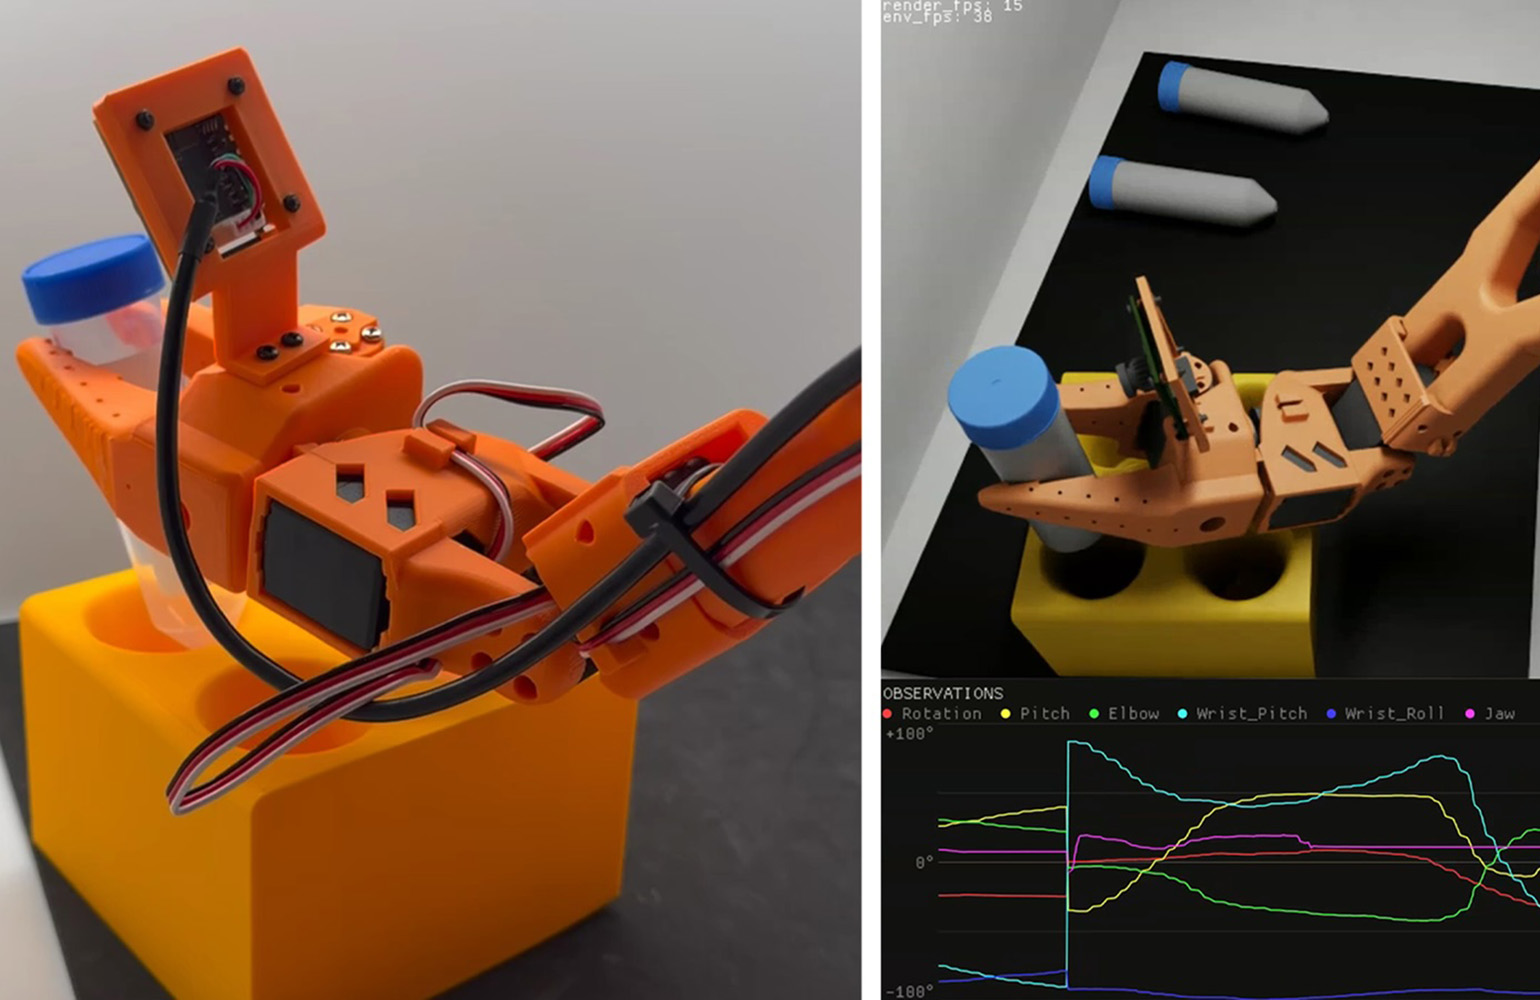
NVIDIA and Hugging Face bring new models and frameworks to LeRobot
Hugging Face LeRobot is an open-source robotics library for training, running, and sharing robot datasets, models, policies, and workflows. The post NVIDIA and …
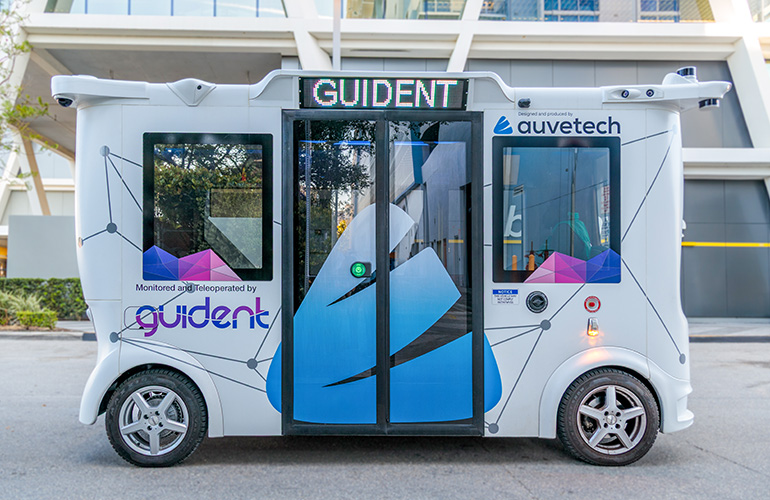
Tickets, geofences, and 1M miles: The new reality of California AV compliance
Guident CEO Harald Braun breaks down the new AV mandates in California mandates and how they will affect the driverless industry. The post Tickets, geofences, a…
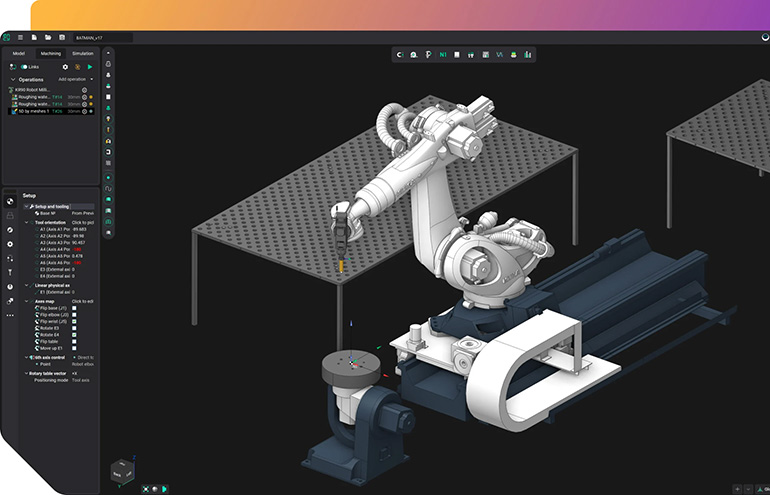
ENCY Software and Stäubli Robotics partner to simplify robot programming
ENCY Software and Stäubli Robotics have signed a global agreement to make robot programming more intuitive, faster, and more accessible. The post ENCY Software …
Preference-Calibrated Human-in-the-Loop Reinforcement Learning for Robotic Manipulation
arXiv:2606.03949v2 Announce Type: replace Abstract: Human-in-the-loop reinforcement learning (HIL-RL) improves sample efficiency in real-robot manipulation thro…
RynnWorld-Teleop: An Action-Conditioned World Model for Digital Teleoperation
arXiv:2607.06558v1 Announce Type: new Abstract: Scaling robot learning requires massive, diverse trajectory data, yet collection is currently bottlenecked by ph…
Learning to Throw Objects Safely in Multi-Obstacle Environments
arXiv:2607.06388v1 Announce Type: new Abstract: Robotic throwing enables fast and efficient object placement beyond the robot's immediate workspace, but reliabl…
Training-Free Acceleration for Vision-Language-Action Models with Action Caching and Refinement
arXiv:2607.06370v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have emerged as a promising approach for generalizable robotic manipulations…
$\pi_0$-EqM: Equilibrium Matching for Closed-Loop Vision-Language-Action Control
arXiv:2605.23128v2 Announce Type: replace Abstract: Currently, Vision-Language-Action (VLA) models have become the most adopted paradigm for robotic manipulatio…
O3N: Omnidirectional Open-Vocabulary Occupancy Prediction
arXiv:2603.12144v2 Announce Type: replace-cross Abstract: Understanding and reconstructing the 3D world through omnidirectional perception is becoming increasin…
Learning 4D Geometric Priors for Inference-Efficient World Action Models
arXiv:2607.05468v1 Announce Type: new Abstract: World Action Models (WAMs) have shown strong potential for robotic manipulation by jointly modeling visual futur…
Thor: Towards Human-Level Whole-Body Reactions for Intense Contact-Rich Environments
arXiv:2510.26280v3 Announce Type: replace Abstract: Humanoids hold great potential for service, industrial, and rescue applications, in which robots must sustai…
Hypothesis-driven Model Expansion under Uncertainty for Open-World Robot Planning
arXiv:2607.06501v1 Announce Type: new Abstract: We consider an open-world planning setting in which service robots must operate in unknown environments with inc…
Diagnosing Semantic Handoff Failures in Agent-Orchestrated Vision-Language-Action Skill Composition
arXiv:2607.06256v1 Announce Type: new Abstract: Long-horizon household tasks require robots to compose many language-conditioned skills, yet the boundary betwee…
Dynamic Evaluation of Classical and Control-Aware Optimal Trajectory Planning in Robot Manipulators
arXiv:2607.05544v1 Announce Type: new Abstract: Trajectory planning strongly influences tracking accuracy, actuator demand, and overall execution behavior in ro…
UniLM-Nav: A Unified Framework for Zero-Shot Last-Mile Navigation
arXiv:2607.06537v1 Announce Type: new Abstract: Mobile manipulation requires a robot to navigate to a target object or receptacle and then perform intended mani…
IndoorR2X: Indoor Robot-to-Everything Coordination with LLM-Driven Planning
arXiv:2603.20182v4 Announce Type: replace Abstract: Although robot-to-robot (R2R) communication improves indoor scene understanding beyond what a single robot c…
Edge-Based QoS-Aware Adaptive Task Placement: A Closed-Loop Control in Multi-Robot Systems
arXiv:2606.00552v2 Announce Type: replace-cross Abstract: Multi-robot systems (MRS) increasingly offload compute-intensive perception tasks to edge nodes to mee…
Exploring Human-Robot Collaboration: Analysis of Interaction Modalities in Challenging Tasks
arXiv:2605.13380v2 Announce Type: replace Abstract: This work compares three interaction modalities for human-robot collaboration: passive, reactive, and proact…
Hilti-Trimble-Oxford Dataset: 360 Visual-Inertial Benchmark with Floor Plan Priors for SLAM and Localization
arXiv:2607.06464v1 Announce Type: new Abstract: Automated progress monitoring on construction sites is an active area of research and development. Robot and hum…
First Plan Then Evaluate: Multi-Target Planning with Post-Planning Success Evaluation Improves Learning-Based Grasping Pipelines
arXiv:2509.07162v2 Announce Type: replace Abstract: Autonomous multi-finger grasping is a fundamental capability in robotic manipulation. Optimization-based app…
OrchardBench: A Physically-Grounded, GPU-Parallel Apple-Orchard Simulation Benchmark for Agricultural Robotics
arXiv:2607.06337v1 Announce Type: new Abstract: Robotic tree-fruit harvesting is a flagship problem for agricultural automation, but progress is bottlenecked by…
A Four-Tier Communication Architecture and Sim-to-Real Validation of a Graphical Open-Source Platform for Robotic Engineering Education
arXiv:2606.00550v2 Announce Type: replace-cross Abstract: The persistent challenge in scaling authentic manipulator education within university laboratories is …
Lift3D-VLA: Lifting VLA Models to 3D Geometry and Dynamics-Aware Manipulation
arXiv:2607.06564v1 Announce Type: new Abstract: Recently, Vision-Language-Action (VLA) models have demonstrated strong generalization across diverse tasks. Howe…
RynnWorld-4D: 4D Embodied World Models for Robotic Manipulation
arXiv:2607.06559v1 Announce Type: new Abstract: Robotic manipulation in the open world requires not only recognizing what a scene looks like, but also anticipat…
ThorArena: Benchmarking Humanoid Physical Interaction with Human Motion-Force Demonstrations
arXiv:2607.06052v1 Announce Type: new Abstract: Humanoid robots are increasingly expected to perform contact-rich tasks that require not only accurate whole-bod…
WristMimic: Full-Body Humanoid Control with Wrist-Guided Manipulation
arXiv:2607.06438v1 Announce Type: new Abstract: Retargeting human object interaction demonstrations to physics based simulation requires reproducing not only bo…
RoboTALES: Learning Reasoning-Guided Robot Policies via Task-Aligned Simulated Futures
arXiv:2607.06018v1 Announce Type: new Abstract: Pretrained video generative models are promising backbones for visuomotor control, but their imagined futures of…