News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 stories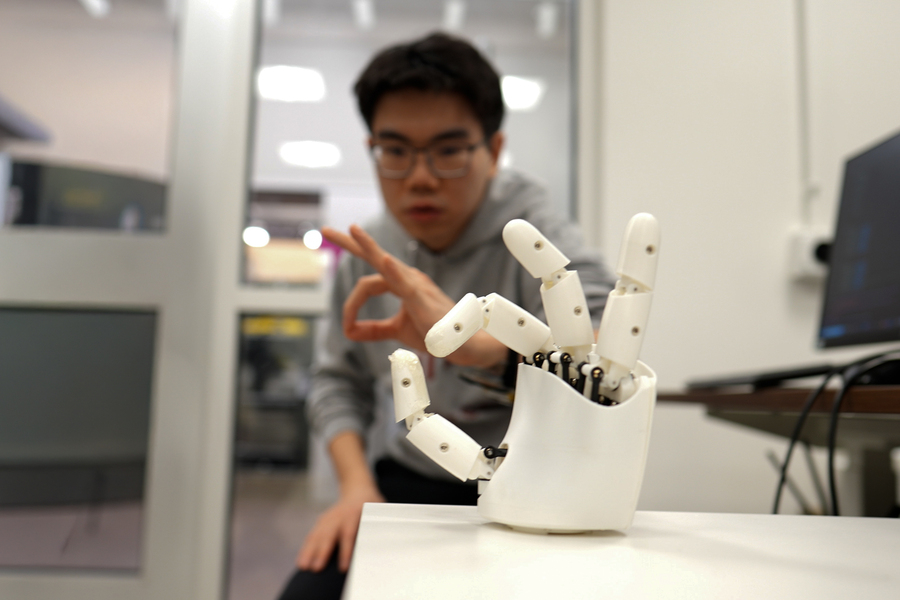
Wristband enables wearers to control a robotic hand with their own movements
By moving their hands and fingers, users can direct a robot to play piano or shoot a basketball, or they can manipulate objects in a virtual environment.…
Effects of Robotic Touch on Older Users During Walking Guidance by a Humanoid Robot
arXiv:2607.09323v1 Announce Type: new Abstract: The shortage of healthcare staff is a challenge in geriatric care. To address this, robots can be integrated int…
SplatCtrl: Perception-Action Coupling via Gaussian Scene Representations and Reactive Robot Control
arXiv:2607.08948v1 Announce Type: new Abstract: Robotic manipulators excel in structured environments but face substantial challenges in unstructured and dynami…
Dec-MARVEL: Decentralized Multi-Agent Exploration without Communication under Budget Constraints
arXiv:2607.09060v1 Announce Type: new Abstract: Multi-UAV exploration is often constrained by unreliable communication, limited field-of-view sensing (e.g., lig…
Single-Frame Point-Pixel Registration via Supervised Cross-Modal Feature Matching
arXiv:2506.22784v2 Announce Type: replace-cross Abstract: Point-pixel registration between LiDAR point clouds and camera images is a fundamental yet challenging…
AgenticFocus: Object-Preserving Mixed Reality Synthesis from Human FPV Video for Dexterous Humanoid Learning
arXiv:2607.08857v1 Announce Type: new Abstract: Human egocentric video is a scalable supervision source for humanoid policy learning, but current pipelines stru…
Causally Debiased Latent Action Model for Embodied Action Conditioned World Models
arXiv:2607.09185v1 Announce Type: cross Abstract: Action-conditioned world models (ACWMs) aim to simulate future observations conditioned on embodied actions, o…
CoDiMAD: Diffusion-Based Privileged Distillation for Communication-Free Multi-Robot Coordination
arXiv:2607.09587v1 Announce Type: new Abstract: Decentralized multi-robot coordination under partial observability remains challenging, especially in communicat…
Tactile and Vision Conditioned Contact-Centric Control for Whole-Arm Manipulation
arXiv:2607.09218v1 Announce Type: new Abstract: Whole-arm manipulation involves direct contact with the environment while the robot completes a task by distribu…
BeyondSight: Object Permanence for End-to-End Autonomous Driving
arXiv:2607.09138v1 Announce Type: new Abstract: Autonomous driving operates in partially observable environments where actors may become fully occluded by other…
PAC-ACT: Post-training Actor-Critic for Action Chunking Transformers
arXiv:2607.09590v1 Announce Type: new Abstract: Precision industrial contact manipulation requires reliable robot policies under pose perturbations and contact-…
DemoBridge: A Simulation-in-the-Loop Toolkit for Single-View Human Demonstration Retargeting
arXiv:2607.09519v1 Announce Type: new Abstract: We present DemoBridge, an toolkit that turns a single-view RGB stereo recording of a human hand demonstration in…
Implicit-Behavior Coordination from Unlabeled Sub-Task Demonstrations for Rearrangement Tasks
arXiv:2607.09234v1 Announce Type: new Abstract: Long-horizon robotic rearrangement tasks are often treated as skill sequencing problems, requiring predefined sk…
Tactile Genesis: Exploring Tactile Sensors at Scale for Learning Dexterous Tasks
arXiv:2606.22332v2 Announce Type: replace Abstract: Tactile sensing is critical for contact-rich dexterous manipulation, yet it remains unclear which tactile ab…
CLAP: Direct VLM-to-VLA Adaptation via Language-Action Grounding
arXiv:2607.08974v1 Announce Type: new Abstract: Vision-language-action models (VLAs) inherit semantic capabilities from pretrained VLMs, yet large-scale post-tr…
OIPP: Object-Adaptive Impact Point Predictor for Catching Diverse In-Flight Objects
arXiv:2509.15254v3 Announce Type: replace Abstract: In this study, we address the problem of in-flight object catching using a quadruped robot with a basket. Ou…
Empirical Pedestrian Safety Assessment in a Mobile Robot Using a Predictive Social Force Model
arXiv:2607.09192v1 Announce Type: new Abstract: Mobile robots are going to share the sidewalks with pedestrians. They must ensure their objective safety and res…
Act, Sense, Act: Learning Active Perception from Large-Scale Egocentric Human Data
arXiv:2602.04600v2 Announce Type: replace Abstract: Achieving generalizable manipulation in unconstrained environments requires the robot to proactively resolve…
FlowDAgger: Human-in-the-Loop Adaptation of Generative Robot Policies in Latent Space
arXiv:2607.08877v1 Announce Type: new Abstract: Pretrained generative robot policies based on flow matching and diffusion have achieved impressive results acros…
B-spline Policy: Accelerating Manipulation Policies via B-spline Action Representations
arXiv:2607.09648v1 Announce Type: new Abstract: In this work, we present B-spline Policy (BSP), an action representation designed for accelerating robot manipul…
CORAL-AUV: CFD Oriented Reinforcement Learning for Autonomous Underwater Vehicles
arXiv:2607.09557v1 Announce Type: new Abstract: Fine grain control and positioning of autonomous underwater vehicles (AUVs) is critical for sampling, maintenanc…
GenVid2Robot: From Video Generation to Robot Manipulation via Rigid-Geometric Consistency
arXiv:2607.09191v1 Announce Type: new Abstract: Generated videos provide useful visual motion priors for robot manipulation, but their visual plausibility does …
Validating Virtual Reality for Studying Multimodal Human-Robot Interaction in Socially Aware Robot Navigation
arXiv:2607.09261v1 Announce Type: new Abstract: Virtual Reality (VR) offers a flexible and controllable platform for studying human-robot interaction. Prior wor…
Residual Physics-Informed Neural Networks for High-Fidelity BLDC Motor Modeling
arXiv:2607.09136v1 Announce Type: new Abstract: Accurate dynamics modeling of Brushless DC (BLDC) motors is fundamental to high-performance robotic joint contro…
RoboStream: Weaving Spatio-Temporal Reasoning with Memory in Vision-Language Models for Robotics
arXiv:2603.12939v2 Announce Type: replace Abstract: Enabling reliable long-horizon robotic manipulation is a crucial step toward open-world embodied intelligenc…
One-Shot Multimodal Learning from Demonstration with Force-Constrained Elastic Maps
arXiv:2607.09515v1 Announce Type: new Abstract: Robotic manipulation tasks often require simultaneous reasoning over motion and contact forces, yet most Learnin…
Re$^3$Sim: Generating High-Fidelity Simulation Data via 3D-Photorealistic Real-to-Sim for Robotic Manipulation
arXiv:2502.08645v4 Announce Type: replace Abstract: Real-world data collection for robotics is costly and resource-intensive, requiring skilled operators and ex…
TactiDex: A Real-World Tactile-Guided Benchmark for Human-Like Dexterous Manipulation
arXiv:2607.09190v1 Announce Type: new Abstract: Tactile feedback is fundamental to Hand-Object Interaction (HOI), governing contact formation, force regulation,…
Robot Trajectron V3: A Probabilistic Shared Control Framework for SE(3) Manipulation
arXiv:2607.09315v1 Announce Type: new Abstract: We aim to address the challenge of teleoperating robotic arms for high-degree-of-freedom (high-DoF) manipulation…
Differential Analysis of Multispectral Images for Terrain Identification
arXiv:2607.09319v1 Announce Type: new Abstract: Reliable terrain understanding is a prerequisite for autonomous robot navigation. Yet, the widespread RGB-based …