News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesMission-Level Runtime Assurance for LLM-Assisted ISR Swarms over a Verification-Aware Fabric
arXiv:2607.23532v1 Announce Type: cross Abstract: Swarms of LLM-assisted autonomous robots are increasingly proposed for cooperative intelligence, surveillance,…
Unifying Complementarity Constraints and Control Barrier Functions for Safe Whole-Body Robot Control
arXiv:2504.17647v2 Announce Type: replace Abstract: Safety-critical whole-body robot control demands reactive methods that ensure collision avoidance in real-ti…
Learning Reusable Hybrid Motion Priors for Humanoid Locomotion from Motion Imitation
arXiv:2607.24083v1 Announce Type: cross Abstract: Reinforcement learning can produce robust humanoid controllers, but each new task is typically trained as a se…
PRISM: Polynomial Representations for Interaction-Structured Motor Control
arXiv:2607.23473v1 Announce Type: new Abstract: Robot policies are typically MLPs mapping observations to actions. Yet robot observations are physical variables…
FutureRTC: Real-Time Robot Execution with Anticipatory-Conditioned Action Chunking
arXiv:2607.24008v1 Announce Type: new Abstract: Real-time deployment of Vision-Language-Action (VLA) policies necessitates asynchronous execution, wherein subse…
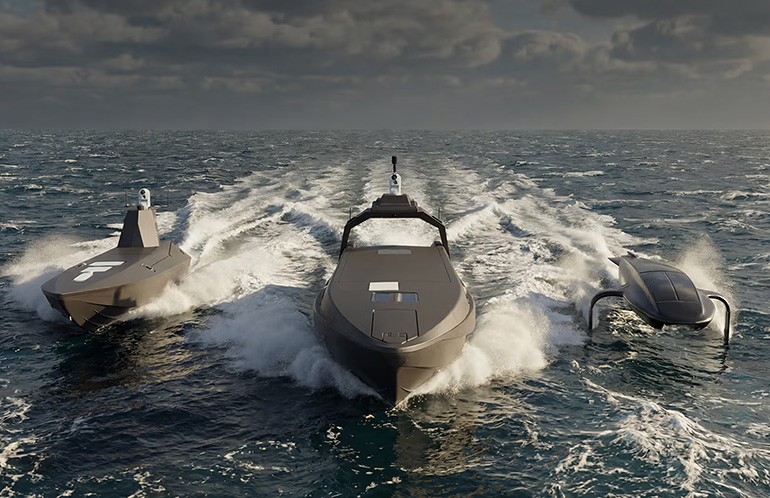
Kraken Technology raises Series B funding for autonomous vessels
Kraken Technology plans to use its funding to continue developing uncrewed surface vessels and localizing manufacturing around the world. The post Kraken Techno…

NORD expands compact NORDAC VFD family to 200 hp
NORD Drivesystems said its NORDAC PRO VFDs are adaptable to individual application requirements across industries. The post NORD expands compact NORDAC VFD fami…
DB-VIO: Dual-Branch Visual Inertial Odometry with Enhanced Visual-Inertial Representation
arXiv:2607.22123v1 Announce Type: new Abstract: Visual inertial odometry (VIO) is essential for accurate 6-DoF motion estimation in mobile robotic systems. Rece…
Ordered Action Tokens for Visuomotor Policy Learning
arXiv:2607.21670v1 Announce Type: new Abstract: Action tokenization maps continuous robot action chunks to discrete tokens and has become an important interface…
Progress Reward Modeling for Robotic Learning: A Comprehensive Survey
arXiv:2607.21655v1 Announce Type: new Abstract: Robotic learning takes place in dynamic environments with large behavior spaces. A terminal success signal only …
Robot-Factored World Models via Robot Rendering
arXiv:2607.22535v1 Announce Type: new Abstract: Action-conditioned video world models predict future observations from an initial observation and an action sign…
Conformal Constraint Tightening for Chance-Constrained Motion Planning with Unknown Dynamics
arXiv:2607.22409v1 Announce Type: new Abstract: Motion planning algorithms compute control sequences that drive autonomous robots to goal regions while avoiding…
Plug, Play, and Comply: A Modular Framework for Online Variable Impedance with Arbitrarily Oriented Compliance Axes
arXiv:2607.22483v1 Announce Type: new Abstract: The paper proposes a robot-agnostic compliant-control framework that extends the ROS control ecosystem with stan…
Flight-Ready LiDAR-Inertial Odometry for Embedded Drone Platforms
arXiv:2607.22145v1 Announce Type: new Abstract: Open-source LiDAR-inertial odometry (LIO) systems have achieved remarkable benchmark accuracy, yet current state…
Teachy Mini: Development and Preliminary Evaluation of a Knowledge-Based Generative Social Robot for Higher Education
arXiv:2607.22345v1 Announce Type: new Abstract: Generative social robots (GSRs) powered by large language models offer new possibilities for personalized tutori…
Constraint-Driven Synthesis of Hyper Petri Nets
arXiv:2607.22062v1 Announce Type: cross Abstract: This paper addresses the modeling and synthesis of constrained robotic system behaviors using Petri nets (PNs)…
One Hand Watches The Other: Dynamic Multi-Agent Cooperation for Sample-Efficient Bimanual Manipulation in Dynamic Environments
arXiv:2607.22119v1 Announce Type: new Abstract: Multi-stream robot manipulation policies achieve unparalleled sample efficiency and generalization by modeling a…
JustDepth: Real-Time Radar-Camera Depth Estimation with Single-Scan LiDAR Supervision
arXiv:2607.22172v1 Announce Type: cross Abstract: Accurate yet low-latency depth is essential for radar-camera perception in autonomous systems. Cameras provide…
Compliant Non-Prehensile Pushing Manipulation
arXiv:2605.25672v2 Announce Type: replace Abstract: In this paper, we address the challenge of performing non-prehensile pushing operations with a compliant rob…
A Monolithic Hand with Asymmetric Origami Bending and Dual-chamber Actuators
arXiv:2607.22320v1 Announce Type: new Abstract: The passive adaptability inherent in soft robotic hands affords them advantages in applications that require saf…
Learning Diverse Humanoid Tasks via Synthetic Video Scenarios without Real World Data
arXiv:2607.21648v1 Announce Type: new Abstract: The human-like morphology of humanoid robots grants them exceptional potential for agile and versatile motor cap…
Action-Conditioned World Model for Goal Plane Probe Guidance in Robotic Ultrasound
arXiv:2607.21918v1 Announce Type: new Abstract: We present an action-conditioned world model framework for goal plane probe guidance in robotic ultrasound, with…
Benchmarking the Safety of Large Language Models for Robotic Health Attendant Control
arXiv:2604.26577v2 Announce Type: replace-cross Abstract: Large language models (LLMs) are increasingly considered for deployment as the control component of ro…
GRACE: Gradient-Free Robot Action Generation via Combined Diffusion-MPPI Posterior Mean Estimation
arXiv:2607.21661v1 Announce Type: new Abstract: Diffusion policies generate multimodal robot action sequences from demonstrations, but steering them toward depl…
NVIDIA OmniDreams: Real-Time Generative World Model for Closed-Loop Autonomous Vehicle Simulation
arXiv:2606.03159v2 Announce Type: replace-cross Abstract: As autonomous vehicle capabilities advance, the safe evaluation of driving policies in long-tail scena…
ViTacWorld: Scaling Visuo-Tactile World Models for Contact-Rich Robot Manipulation
arXiv:2607.22530v1 Announce Type: new Abstract: Contact-rich robot manipulation requires physical interaction cues that are often invisible to cameras, making t…
Adaptive Learned State Estimation based on KalmanNet
arXiv:2604.02441v2 Announce Type: replace Abstract: Hybrid state estimators that combine model-based Kalman filtering with learned components have shown promise…
Safe Learning Predictive Control for Ego-World Robotic Systems
arXiv:2607.22225v1 Announce Type: new Abstract: Safe autonomous navigation in shared environments requires the ability to anticipate and react to the latent beh…
ACME: A Multi-Cultural, Multi-Embodiment Social-Navigation Dataset
arXiv:2607.21964v1 Announce Type: new Abstract: Understanding how robots and humans move in shared spaces is essential for designing effective social robot navi…
Design and Human Evaluation of Tactile Withdrawal Reflexes for a Skin-Covered Robot Arm
arXiv:2607.22249v1 Announce Type: new Abstract: Nociception is a protective biological mechanism that links harmful stimulation to a reaction. This paper invest…