News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesVision-Language-Policy Model for Dynamic Robot Task Planning
arXiv:2512.19178v2 Announce Type: replace Abstract: Bridging the gap between natural language commands and autonomous execution in unstructured environments rem…
Robostral Navigate
arXiv:2607.20785v1 Announce Type: new Abstract: Deploying navigation systems at scale requires a recipe that minimizes sensor assumptions, generalizes across ro…
TOPReward: Token Probabilities as Hidden Zero-Shot Rewards for Robotics
arXiv:2602.19313v2 Announce Type: replace Abstract: General-purpose robot learning requires dense, instruction-conditioned feedback that can distinguish meaning…
TableVerse: A Large-scale Tabletop Dataset with Real-world Grounded Layouts for Generalizable Manipulation
arXiv:2607.21017v1 Announce Type: new Abstract: The development of generalizable robotic manipulation policies is inherently bounded by the availability of larg…
PhysCoRe: Physics-Corrected Residual World Models for Material-Aware Deformable Dynamics
arXiv:2607.20653v1 Announce Type: new Abstract: Predicting how deformable objects evolve under robotic manipulation is a longstanding challenge. Existing approa…
HGeo-TopoMap: Boosting Topological Mapping with Hierarchical Geometric Priors
arXiv:2607.21281v1 Announce Type: cross Abstract: Topological maps are key outputs of autonomous driving perception systems, delivering essential road informati…
Towards Capability-Aware Traversability Navigation for Unstructured Environments
arXiv:2607.20679v1 Announce Type: new Abstract: Estimating traversability in unstructured environments requires conditioning on robot embodiment, as the same te…
Human-Inspired Framework for Robotic Craniotomy: Integrating Multimodal Fusion and Adaptive Trajectory Adjustment
arXiv:2607.21058v1 Announce Type: new Abstract: Manual craniotomy is a high-risk, skill-dependent procedure associated with surgeon fatigue and potential dural …
Compact Latent Coordination for Autonomous Vehicles at Unsignalized Intersections
arXiv:2607.21488v1 Announce Type: cross Abstract: Coordinating autonomous vehicles at unsignalized intersections remains a critical challenge for multi-agent re…
TransBiolab: A Real-World Multi-View Dataset of Cluttered Transparent Biomedical Objects
arXiv:2607.21071v1 Announce Type: cross Abstract: Autonomous biomedical laboratories increasingly rely on visual perception to recognize, localize, and manipula…
i2Nav-Robot: A Large-Scale Indoor-Outdoor Robot Dataset for Multi-Sensor Fusion Navigation
arXiv:2508.11485v3 Announce Type: replace Abstract: Accurate and reliable navigation is crucial for autonomous unmanned ground vehicles (UGVs). However, current…
Socially Consistent Multi-Robot Navigation Using Decoupled Planning and Trajectory Coordination
arXiv:2607.20772v1 Announce Type: new Abstract: The successful integration of mobile robots in human-centric environments requires navigation that is not only s…
Self-Supervised Bio-Inspired Robotic Trajectory Planning with Obstacle Avoidance
arXiv:2607.20743v1 Announce Type: new Abstract: Trajectory planning is a fundamental problem in robotics, requiring the generation of collision-free and efficie…
Deep Reinforcement-Learning-Guided Model Predictive Control for Preventing Overtakes in Autonomous Racing
arXiv:2607.20973v1 Announce Type: new Abstract: This paper addresses defensive blocking in autonomous racing, where a vehicle must prevent a faster opponent fro…

Uber co-founder raises $1.7B for new robotics startup ATOMS
Travis Kalanick, the former CEO of Uber, said with ATOMS, he hopes to create physical automation to transform industry. The post Uber co-founder raises $1.7B fo…
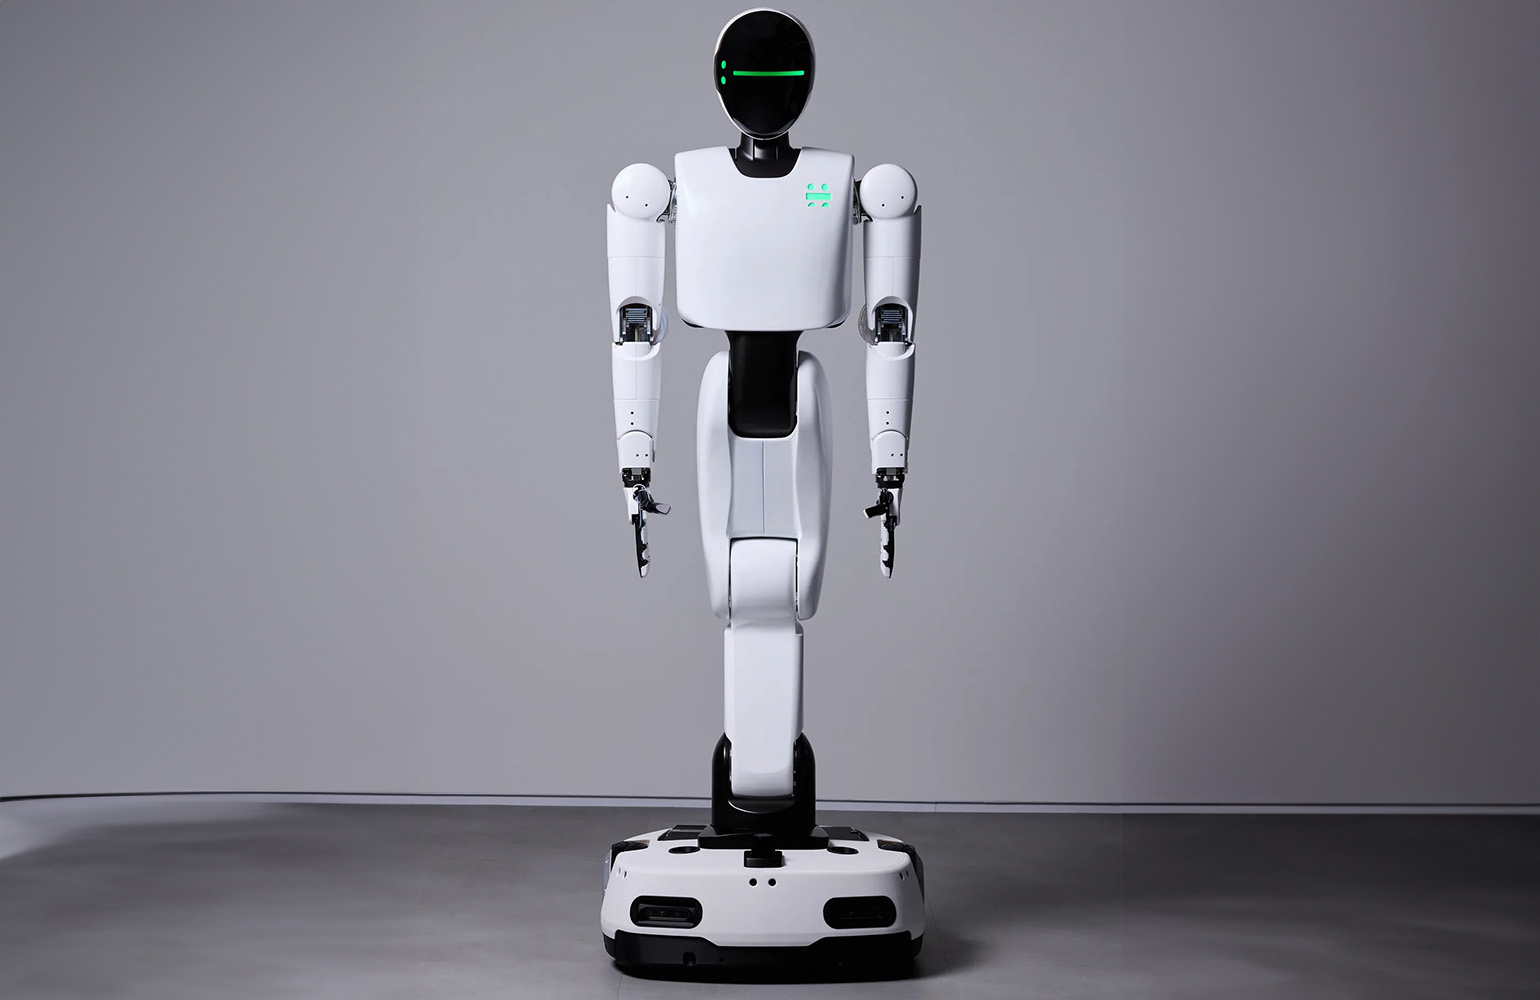
Holiday Robotics raises $105M for its FRIDAY wheeled humanoid
Holiday's robot features a wheel-based mobile base, an upper body for dexterous manipulation, and hot-swappable batteries. The post Holiday Robotics raises $105…

Ropedia raises $22M to scale data collection for training robots
Ropdeia's HOMIE is a head-mounted device, equipped with a 360º camera view, that captures first-person data for training robots. The post Ropedia raises $22M to…

AMD unveils Kria module for real-time control, unified memory for robots
AMD has launched the Ryzen AI Embedded X100 and Kria AI SoM, bringing unified memory and real-time control to challenge NVIDIA in robotics. The post AMD unveils…
Optimal Placement of Docking Stations and Resident AUVs for Subsea Pipeline Inspection
arXiv:2607.19944v1 Announce Type: cross Abstract: A two-stage mixed-integer linear programming framework is introduced for subsea pipeline incident response pla…
Extreme-RGMT: Continual Learning of Highly Dynamic Skills for Robust Generalist Humanoid Control
arXiv:2607.20110v1 Announce Type: new Abstract: Humans can progressively acquire highly dynamic motor skills while preserving reliable everyday motor abilities.…
Distributed Acoustic Localization Array Deployed Using a Soft Everting Vine Robot
arXiv:2607.20392v1 Announce Type: new Abstract: Soft robot exteroception is increasingly being explored for a variety of field applications. In this work, we pr…
SOPD-SocialNav: Selective On-Policy Distillation for Vision-Language Social Navigation
arXiv:2607.19850v1 Announce Type: new Abstract: Vision-language models have shown strong potential for social robot navigation by leveraging rich semantic under…
Towards Miniature Humanoid Tele-Loco-Manipulation Using Virtual Reality and Reinforcement Learning
arXiv:2607.20399v1 Announce Type: new Abstract: Full-sized humanoid robot capabilities have grown exponentially in recent years, aiming towards general-purpose …
Effort-Based Criticality Metrics for Evaluating 3D Perception Errors in Autonomous Driving
arXiv:2603.28029v2 Announce Type: replace-cross Abstract: Criticality metrics such as time-to-collision (TTC) quantify collision urgency but do not distinguish …
SeededGrasp: Language-Guided Grasping in Complex Scenes with Multiple Embodiments
arXiv:2607.20207v1 Announce Type: new Abstract: Practical robotic grasping in complex scenes requires both 3D spatial reasoning and alignment with task-specific…
V2F: Vision-Informed Grasp Force Prediction for Damage-Aware Robotic Handling of Date Fruits
arXiv:2607.19804v1 Announce Type: new Abstract: This paper presents a vision-informed grasp force prediction framework for robotic handling of date fruits. Addr…
Morphing MILR: Design and control of a cable-driven limbless robot with rolling joints for maneuvering in complex environments
arXiv:2607.19714v1 Announce Type: new Abstract: Limbless robots offer exceptional mobility in confined and cluttered environments due to their slender bodies an…
Defer to Plan: Adaptive Multi-Agent Fusion for End-to-End V2X Driving
arXiv:2607.19774v1 Announce Type: new Abstract: Vehicle-to-everything-aided autonomous driving (V2X-AD) significantly enhances driving performance through infor…
What Matters in Humanoid General Motion Tracking? An Empirical Study
arXiv:2607.19903v1 Announce Type: new Abstract: Humanoid general motion tracking requires policies that can follow diverse whole-body references while maintaini…
Distributed Motion Planning with Safety Guarantees for Self-Reconfiguring Robotic Boats
arXiv:2607.20352v1 Announce Type: new Abstract: Aquatic self-reconfigurable robots must assemble into desired shapes while ensuring safe interactions among mult…