News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesOffline Vision-Language Navigation with Geometric Goal Localization for Outdoor Environments
arXiv:2607.22226v1 Announce Type: new Abstract: Foundation-model-based vision-language navigation (VLN) has advanced autonomous robot navigation by enabling rob…
Geometric 2D Scene Graph Generation
arXiv:2607.22325v1 Announce Type: cross Abstract: In production processes for consumer products, assembly instructions are essential not only for planning but a…
StARS: Socially Appropriate Robot Actions via a Recommender System-Driven Approach
arXiv:2607.21802v1 Announce Type: new Abstract: Social appropriateness in human-robot interaction (HRI) is not universal: different people can judge the same ro…
Robot Learning to Communicate through Projected Visual Abstractions
arXiv:2607.22434v1 Announce Type: new Abstract: Humans routinely communicate through abstractions of their bodies, including shadows, silhouettes, and reflectio…
Embodying Multi-Hand Manipulation Policies by Searching the Assignment and Null Spaces
arXiv:2607.22020v1 Announce Type: new Abstract: Learned manipulation policies increasingly predict motions for abstract "hands" and are attractive in practice b…

Magmotor makes motors for a changing world for 150+ years
Magmotor has been providing motors for demanding use cases for decades and offers custom systems for robotics. The post Magmotor makes motors for a changing wor…

Photos: First look at J&J’s Ottava surgical robot
Johnson & Johnson MedTech unveiled its long-awaited Ottava surgical robot after winning FDA de novo authorization. It’s the world’s first table-integra…
How time series databases unlock real-time data for robotics
Discover how time series databases help robotics teams manage high-volume sensor data, power AI insights, and keep systems running at scale. The post How time s…
Generalist’s GEN-1 foundation model now supports a range of robot end effectors
By training GEN-1 to work with new hands, Generalist said a single base model can learn sensorimotor policies on different robots. The post Generalist’s G…
NEURA Robotics establishes NEURA Gym RWTH Aachen to train physical AI
NEURA Robotics has partnered with a German university for NEURA Gym RWTH Aachen, one of 10 facilities for training physical AI. The post NEURA Robotics establis…
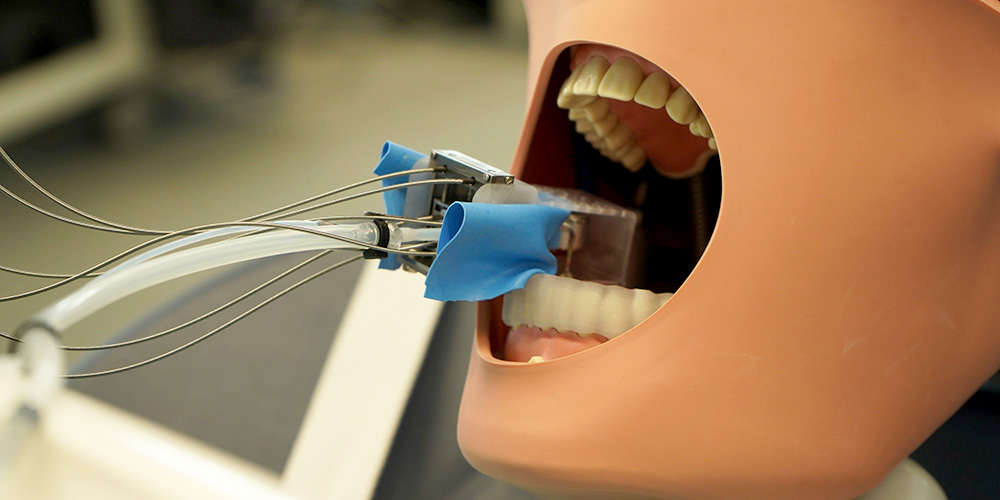
A mini robot to simplify dental treatment
A miniature robot developed at the University of Basel could help prepare teeth for a crown. Photo: University of Basel, Catherine Weyer. By Angelika Jacobs A r…
Drive As You Like: Multi-Head Diffusion with Reinforcement Learning for Personalized Driving
arXiv:2508.16947v2 Announce Type: replace Abstract: Despite significant progress, imitation learning-based autonomous driving planners remain largely restricted…
GuidedAttention: Interpretable and Correctable Visual Attention for OOD-Robust Robot Manipulation via Imitation Learning
arXiv:2607.21049v1 Announce Type: new Abstract: End-to-end visuomotor policies provide little opportunity for humans to understand or correct the policy's visua…
A Real-Time Generalized Nash Equilibrium Framework for Interaction-Aware Autonomous Driving in Mixed Traffic
arXiv:2607.21043v1 Announce Type: new Abstract: Safe and efficient navigation in mixed-traffic environments remains a critical challenge for Autonomous Vehicles…
Factorized Spatio-Temporal Convolutions for Human Pose Estimation from Planar Lidar
arXiv:2607.21309v1 Announce Type: new Abstract: Localizing nearby humans and estimating their facing direction are key capabilities for safe navigation and soci…
What Matters for Simulation to Online Reinforcement Learning on Real Robots
arXiv:2602.20220v2 Announce Type: replace Abstract: We investigate what specific design choices enable successful online reinforcement learning (RL) on physical…
Distributed Model-Based Diffusion For Scalable Multi-Robot Trajectory Optimization
arXiv:2607.20992v1 Announce Type: new Abstract: Trajectory optimization for multi-robot systems remains a critical challenge, particularly when navigating highl…
A real-time RGB-D perception pipeline for autonomous impact hammers in mining: self-filtering, rock segmentation and rock-breaking poses generation
arXiv:2607.20748v1 Announce Type: new Abstract: Impact hammers, also known as rock-breakers, are essential machines in mining operations, where they perform sec…
Is Your Safe Controller Actually Safe? A Critical Review of CBF Tautologies and Hidden Assumptions
arXiv:2603.06954v2 Announce Type: replace Abstract: This tutorial provides a critical review of the practical application of Control Barrier Functions (CBFs) in…
RL-MACRO: A Cybernetic Closed-Loop Intelligence Framework for Multimodal Adaptive Robotic Craniotomy
arXiv:2607.21113v1 Announce Type: new Abstract: Autonomous robotic craniotomy requires continuous regulation of tool-tissue interactions to mitigate mechanical …
Emergent Compositional Skills in Mixture-of-Experts VLAs
arXiv:2607.20771v1 Announce Type: new Abstract: We consider the problem of learning compositional robot policies end-to-end from expert demonstrations, without …
Scalable Low-Cost Laboratory Automation: A Digital Twin-Integrated Robotic Platform for Autonomous Liquid Handling (RAINBOTTM)
arXiv:2607.20662v1 Announce Type: new Abstract: Laboratory automation accelerates discovery, yet its adoption is constrained by the high cost, proprietary desig…
Do World Action Models Generalize Better than VLAs? A Robustness Study
arXiv:2603.22078v4 Announce Type: replace Abstract: Robot action planning in the real world is challenging as it requires not only understanding the current sta…
VPWEM: Non-Markovian Visuomotor Policy with Working and Episodic Memory
arXiv:2603.04910v2 Announce Type: replace Abstract: Imitation learning from human demonstrations has achieved significant success in robotic control, yet most v…
AXIS: A Growable Community-Driven Data Engine for Scalable Robot Manipulation
arXiv:2607.21588v1 Announce Type: new Abstract: Learning effective robot manipulation policies requires diverse, high-quality demonstrations, yet existing data …
Scale Up Strategically: Learning Compositional Generalization via Bias-Aware Evaluation and Data Collection for Robotic Manipulation
arXiv:2607.21582v1 Announce Type: new Abstract: Compositional generalization is essential for robot to follow diverse instructions. However, pretrained policies…
Enhancing Glass Surface Reconstruction via Depth Prior for Robot Navigation
arXiv:2604.18336v3 Announce Type: replace Abstract: Indoor robot navigation is often compromised by glass surfaces, which severely corrupt depth sensor measurem…
Q-SpiRL: Quantum Spiking Reinforcement Learning for Adaptive Robot Navigation
arXiv:2605.20801v2 Announce Type: replace Abstract: Adaptive robot navigation in dynamic environments requires policies that can reach the target reliably while…
URF: A Unified Robot Control-Policy Framework for Stable Contact Aware Manipulation
arXiv:2607.20912v1 Announce Type: new Abstract: Learning-based manipulation policies usually predict robot actions from sensory observations and leave their exe…
Safe and Scalable Multi-Drone Payload Transport via CBF-based Reinforcement Learning with Zero-Shot Sim-to-Real Transfer
arXiv:2607.20665v1 Announce Type: new Abstract: Multi-drone payload transportation has emerged as a promising research paradigm with potential applications in c…