News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesCycleVLA: Proactive Self-Correcting Vision-Language-Action Models via Subtask Backtracking and Minimum Bayes Risk Decoding
arXiv:2601.02295v2 Announce Type: replace Abstract: Current work on robot failure detection and correction typically operates in a post hoc manner, analyzing er…
HOME: Robust Hough-space Matching Method for Structured and Textureless Videos
arXiv:2607.25389v1 Announce Type: cross Abstract: Visual front-ends for robotic localization typically rely on point-based features such as Oriented FAST and Ro…
SONG: A Photorealistic 3D Gaussian Simulation Platform for Benchmarking Social Navigation
arXiv:2607.25219v1 Announce Type: new Abstract: Social navigation has progressed from simplified 2D environments toward a more general vision-based setting, in …
Tri-Manual Visuomotor Imitation Learning of Robot Policies
arXiv:2607.25731v1 Announce Type: new Abstract: Bimanual teleoperation provides an effective way to collect robot demonstrations, but it assumes that the operat…
Belief-Aware Influence and Trust (BAIT): Shaping Human Belief During Repeated Human-Robot Interaction
arXiv:2607.25327v1 Announce Type: new Abstract: Repeated human-robot interaction (HRI) requires proactively accounting for humans who continually adapt to evolv…
Input Shaping for Point-to-Point Motion with a Continuum Robot Arm
arXiv:2607.25071v1 Announce Type: new Abstract: A cable-driven continuum robot arm is an underactuated mechanism and may suffer residual vibration at the end of…
HiFi-UMI: Learning Deployable Manipulation Policies from High-Fidelity UMI Data Alone
arXiv:2607.25895v1 Announce Type: new Abstract: Learning deployable manipulation policies is bottlenecked by the scarcity of data that is both high-fidelity and…
Tripody: An Overconstrained 3-SPR-like Parallel Robot for High-Reach Construction Tasks
arXiv:2607.25781v1 Announce Type: new Abstract: Many ceiling construction tasks still rely on heavy serial manipulators that are difficult to deploy in cluttere…
SAM3D-Guided Object-Centric Representation Alignment for Vision-Language-Action Models
arXiv:2607.25912v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have shown strong potential for general robot manipulation, but most existin…
Nautilus: From One Prompt to Plug-and-Play Robot Learning
arXiv:2605.11665v2 Announce Type: replace Abstract: Robot learning research is fragmented across policy families, benchmark suites, and real robots; each implem…
A Causality-aware Infer-diagnose-refine Framework for Test-time Modality Adaptation in VLA Models
arXiv:2607.25516v1 Announce Type: new Abstract: Vision-language-action (VLA) models predict sequential actions to execute tasks specified by language instructio…
SGTP: Sampling-based Game-Theoretic Planning for Real-Time Multi-Vehicle Autonomous Racing
arXiv:2607.25388v1 Announce Type: new Abstract: Autonomous multi-vehicle racing requires real-time planning of diverse competitive behaviors in intense interact…
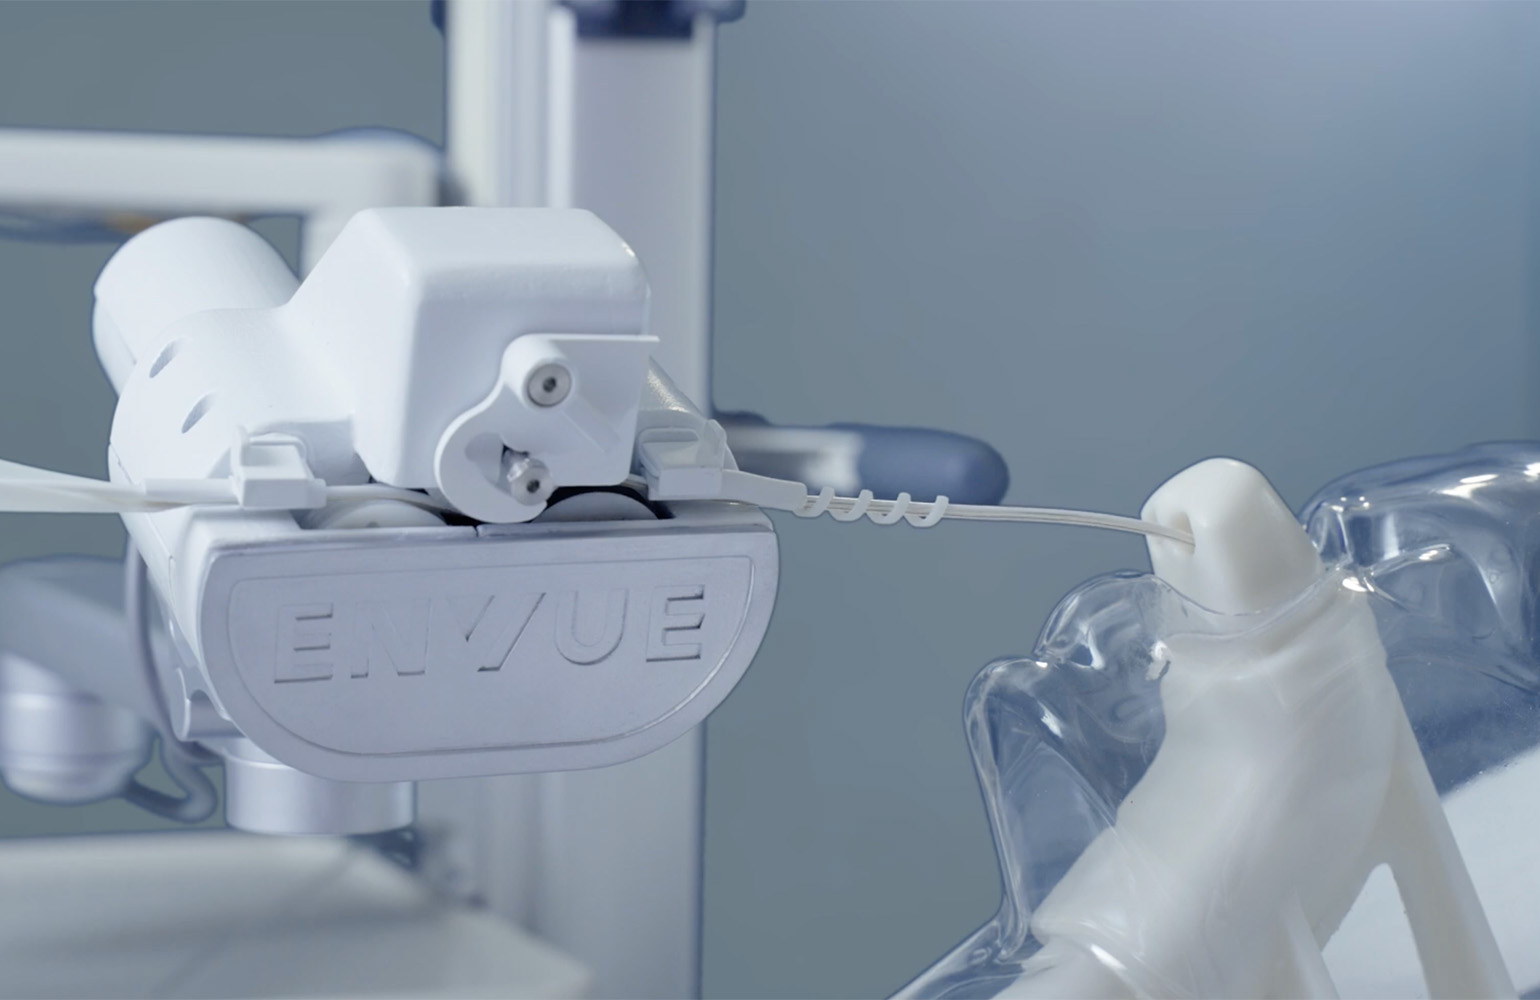
ENvue Medical develops robotic feeding tube placement system
ENvue Drive is designed to assist, not replace, the clinician, who retains full control of the procedure at all times. The post ENvue Medical develops robotic f…

Registration is open for RoboBusiness 2026
This year, join us in October in Santa Clara to celebrate 20 years of robotics excellence at RoboBusiness 2026. The post Registration is open for RoboBusiness 2…
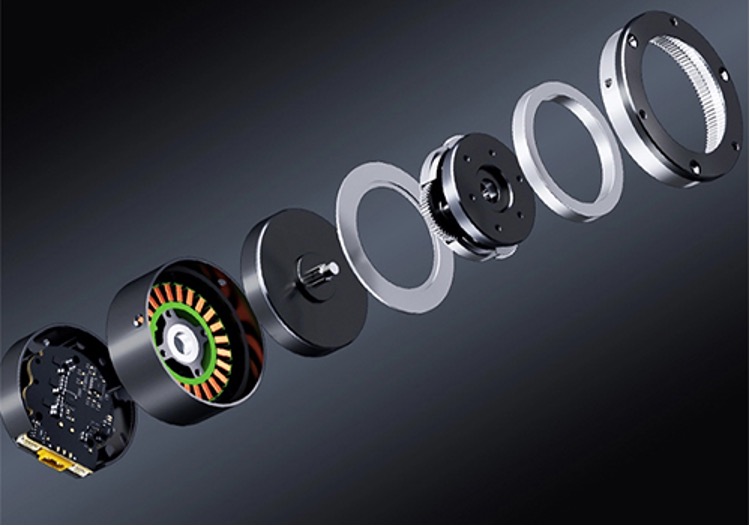
How Integrated Actuators Improve Humanoid Robot Joint Performance and System Integration
Humanoid robots have become an important area of research in robotics, attracting attention from universities, research institutions, and technology companies. …

Agency Tool Company wants to make OTA software updates easier
Two Scythe co-founders are using their experience building commercial robots to create tools for robotics developers at Agency Tool Co. The post Agency Tool Com…
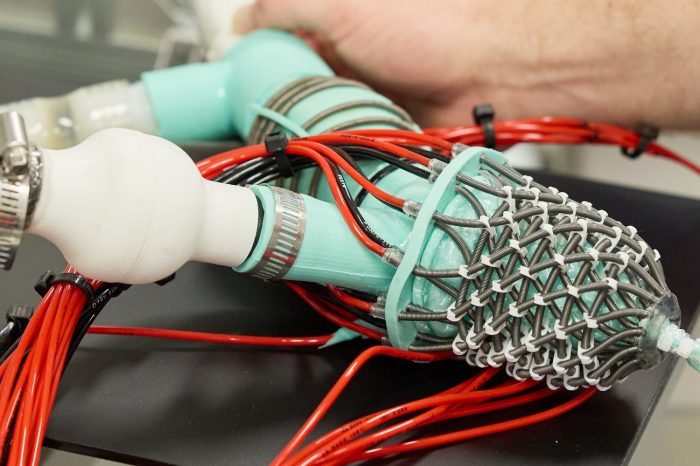
Soft robotic heart offers new way to study disease and test life-saving devices
The soft robotic model of the human heart, developed at UNSW. Credit: UNSW/Richard Freeman. UNSW researchers have developed a soft robotic model of the human he…
Continual-RL for Generalization in Autonomous Racing on the RoboRacer Platform
arXiv:2607.24320v1 Announce Type: new Abstract: A key challenge in modern robotics is to adapt to changing environments, a challenge that is exacerbated when si…
A Case Study on the Acceptance of a Humanoid Robotic Head Employed in Three Public Spaces
arXiv:2607.24113v1 Announce Type: new Abstract: Previous research has shown that a human-like robot's acceptance heavily depends on the setting in which it oper…
The Curse of Precision: A Data Scaling Law for High-Precision Robotic Manipulation
arXiv:2607.23108v1 Announce Type: new Abstract: While scaling laws for imitation learning have primarily focused on generalization in open-world settings, the r…
Accuracy potential of visual localization exploiting high-end street-level imagery
arXiv:2607.24409v1 Announce Type: cross Abstract: Accurate and reliable pose information with respect to a reference frame is increasingly demanded across appli…
Self-Supervised Consistency Enhanced Disentangled Learning for Neural Decoding Generalization in Brain-Machine Interface
arXiv:2607.24023v1 Announce Type: cross Abstract: Brain-Machine Interfaces (BMIs) provide a direct communication pathway between the brain and external devices,…
CoopReflect: Towards Natural Language Communication for Cooperative Autonomous Driving via Multi-Agent Learning
arXiv:2505.18334v2 Announce Type: replace Abstract: Past work has demonstrated that autonomous vehicles can drive more safely if they communicate with each othe…
KAI: A Kinematic-Aware Interface for Data-Efficient Articulated Object Manipulation
arXiv:2607.24493v1 Announce Type: new Abstract: Articulated object manipulation requires an understanding of kinematic structure that is difficult and costly to…
Imitation Learning for Robot Assistance in Open Surgery: A Multi-Policy Evaluation on Suture Following
arXiv:2605.28736v2 Announce Type: replace Abstract: This study presents the first evaluation of general-purpose imitation learning for surgeon-robot collaborati…
DeVA: Decoupled Video-Action Model with physical guidance for robot policy learning
arXiv:2607.24159v1 Announce Type: new Abstract: Generalizable robot manipulation requires policies that can anticipate how visual scenes evolve while executing …
VLASH: Real-Time VLAs via Future-State-Aware Asynchronous Inference
arXiv:2512.01031v2 Announce Type: replace Abstract: Vision-Language-Action models (VLAs) are becoming increasingly capable across diverse robotic tasks. However…
RRTrack: Robust and Recoverable Object 6D Pose Tracking for Dynamic Scenes
arXiv:2607.23669v1 Announce Type: cross Abstract: Robust object 6D pose tracking is critical for robotic systems operating in dynamic and occluded scenes. Per-f…
Not Forgotten: Implementation and Evaluation of a Personalized Episodic Memory for the Humanoid Robot Head Kim
arXiv:2607.24190v1 Announce Type: new Abstract: Social robots that rely on large language models for conversation are unable to retain information across sessio…
Embodied GPT-5.1: Evidence of a World Model?
arXiv:2607.23899v1 Announce Type: new Abstract: This exploratory study examines whether a large multimodal language model, GPT-5.1, can serve as the high-level …