News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesIt's Not Just More Demos: Counterfactual Action Sensitivity Coverage for Data-Efficient Robust Robot Imitation
arXiv:2607.27261v1 Announce Type: new Abstract: Visuomotor imitation learning has demonstrated success for manipulation tasks. However, the trained policies rem…
A Three-Stage Offline SDRE-Based Control Framework for Human Motion Reproduction on a Suspended Bipedal Robot
arXiv:2506.04680v3 Announce Type: replace Abstract: Evaluating lower limb exoskeletons directly with human subjects can expose users to risk when actuator fault…
TacWAM: Anchor-Guided World Action Model with Mechanics-Aware Tactile Prediction
arXiv:2607.28391v1 Announce Type: new Abstract: World Action Models (WAMs) combine future-state prediction with robot action generation, but existing approaches…
RoboBRIDGE: A Modular Framework for Bridging Policies to Robust Real-World Robotic Agents
arXiv:2607.27881v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have attracted growing interest as a scalable approach to robotic manipulati…
TEA-AgriVLN: Traversability Estimation Alarm for Agricultural Vision-and-Language Navigation
arXiv:2607.28474v1 Announce Type: new Abstract: Vision-and-Language Navigation in Continuous Environments (VLN-CE) requires an agent to follow a natural languag…
SemAnCorr: Semantic Anchored Correspondence for Zero-Shot Manipulation Skill Transfer
arXiv:2607.28382v1 Announce Type: new Abstract: Transferring manipulation skills across object instances that share functionality but differ in geometry remains…
Learning Social Robot Navigation By Sensing Human Legs
arXiv:2607.27922v1 Announce Type: new Abstract: Robots navigating among pedestrians typically sense their surroundings with a 2D LiDAR mounted close to the grou…
DoorDash gains FAA certification to operate its own drone delivery program
The FAA approval came nearly a year after DoorDash unveiled its delivery robot and reflects its increasing interest in building automation in-house. The post Do…
5 Physical AI Infrastructure Platforms Shaping Robotics in 2026
From accelerated computing and simulation to data operations, open-source tooling, validation engineering, and continuous learning, these five platforms represe…
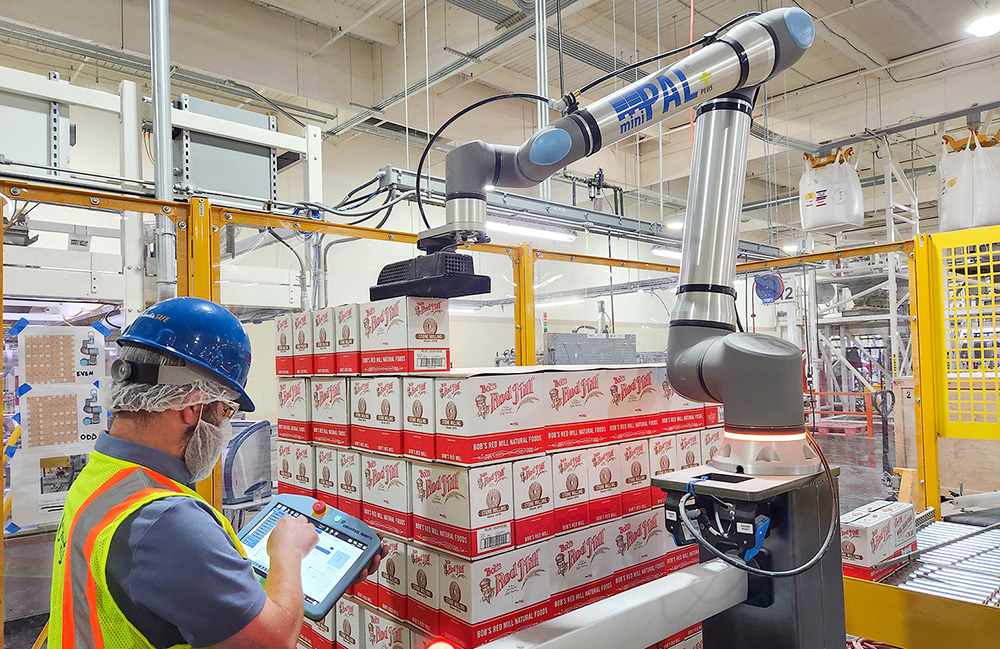
Teradyne Robotics revenue rises 33% year over year in Q2
Teradyne Robotics said growth in the U.S. and in AI were big drivers for its revenue increase in the second quarter of 2026. The post Teradyne Robotics revenue …
Practice Makes Policies: Bootstrapping and Consolidating Robotic Capabilities from Zero Human Demonstrations
arXiv:2607.26809v1 Announce Type: new Abstract: General-purpose robotic manipulation requires robots to perform diverse tasks in open-world environments while i…
Invariant Extended Kalman Filtering with Partial Orientation Measurement Integration: Theoretical Derivations and Application to Autonomous Surface Vessels
arXiv:2506.10850v2 Announce Type: replace Abstract: Autonomous surface vessels (ASVs) are increasingly vital for marine science, offering robust platforms for u…
MoMo: Dial Motion Mode in Robot Manipulation with Spatiotemporal Action Tokenization
arXiv:2607.26315v1 Announce Type: new Abstract: To operate effectively across diverse contexts, robots must not only perform manipulation tasks accurately but a…
From Passive Video to Editable Experience: Physically Grounded Experience Synthesis for Embodied Intelligence
arXiv:2607.26903v1 Announce Type: cross Abstract: The key bottleneck in embodied AI is not model architecture but data. Although billions of human manipulation …
Controlled Experiments on Lane Changing by Transitional Autonomous Vehicle: Dataset and Behavioral Insights
arXiv:2607.27085v1 Announce Type: new Abstract: This paper presents the North Carolina Transitional Autonomous Vehicle Lane-Changing (NC-tALC) dataset and uses …
TurboVLA: Real-Time Vision-Language-Action Model at 32 Hz on an RTX 4090 with <1 GB VRAM
arXiv:2607.27205v1 Announce Type: cross Abstract: Vision-language-action (VLA) models commonly adopt an LLM-centric $V \to L \to A$ pathway, where visual observ…
Task and Skill Planning: Hierarchical Robot Planning with Black-Box Skills
arXiv:2504.17901v3 Announce Type: replace Abstract: Task and motion planning (TAMP) is a well-established approach for solving long-horizon robot planning probl…
Vision-TL-Action: Neuro-Symbolic Trajectory Generation from Visual Observations and Temporal Logic
arXiv:2607.26770v1 Announce Type: new Abstract: Temporal logic (TL) provides a compositional language for the formulation of long horizon robotic tasks, but exi…
SG-CoT: An Ambiguity-Aware Robotic Planning Framework using Scene Graph Representations
arXiv:2603.18271v3 Announce Type: replace Abstract: Ambiguity poses a major challenge to large language models (LLMs) used as robotic planners. In this letter, …
ContactFlow: A video action conditioning that transfers across embodiments
arXiv:2607.26579v1 Announce Type: new Abstract: World models offer a promising route toward robot planning by enabling agents to imagine and verify the conseque…
PACE: Phase-Aware Chunk Execution for Robot Policies with Action Chunking
arXiv:2606.00537v2 Announce Type: replace Abstract: Recent vision-language-action and diffusion-based robot policies often use action chunking, where each polic…
Reeling It In: Flexible Needle Pick Up via Thread Manipulation for Autonomous Suturing
arXiv:2607.26337v1 Announce Type: new Abstract: Suture-needle pickup is necessary for autonomous suturing, as a needle can be unexpectedly dropped or strategica…
SymmGrid: Super-Scaling On-Robot Learning with Parallelized Symmetries and Egocentric-Exocentric Visual Perception
arXiv:2607.26985v1 Announce Type: new Abstract: Deep reinforcement policy learning directly in physical robots (on-robot learning) remains bottlenecked by slow …
Risk-Aware Motion Planning with Learned Trajectory Primitives and Probabilistic Safety Assessment
arXiv:2607.26802v1 Announce Type: new Abstract: This paper presents a radial basis function network (RBFN)-informed motion planning framework for safe and effic…
HeteroPROPMT: A Real-time and Privacy-Preserving Heterogeneous Collaborative Perception Framework
arXiv:2607.26283v1 Announce Type: cross Abstract: Collaborative Perception (CP) improves autonomous systems' awareness of their surroundings by sharing sensor d…
TiPToP: A Modular Open-Vocabulary Robot Manipulation System That Plans
arXiv:2603.09971v2 Announce Type: replace Abstract: We present TiPToP, a modular manipulation system that integrates pretrained foundation models with a GPU-acc…
Speech2Grasp: Data-Efficient Transfer of Text-Conditioned Grasp Detection to Speech in Humanoid Robots
arXiv:2607.26567v1 Announce Type: new Abstract: Humanoid robots increasingly require multi-modal understanding for natural interaction with humans. Despite the …
Embodied Agents Take Control: Minimal-Interface Zero-Shot Agents Rival Industrial-Scale Policies in Vision-and-Language Navigation
arXiv:2607.26148v1 Announce Type: new Abstract: Autonomous embodied agents must sustain a long decision-making loop that involves perceiving, acting, verifying,…
GBPP: Grasp-Aware Base Placement Prediction for Robots via Two-Stage Learning
arXiv:2509.11594v3 Announce Type: replace Abstract: GBPP is a fast learning based scorer that selects a robot base pose for grasping from a single RGB-D snapsho…
PolygMap: A Perceptive Locomotion Framework for Humanoid Robot Stair Climbing
arXiv:2510.12346v2 Announce Type: replace Abstract: Recently, biped robot walking technology has been significantly developed, mainly in the context of a bland …