News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 stories
FCC robot ruling shines a spotlight on U.S. policy; how next-gen AI can help warehousing
Osaro’s Derek Pridmore says warehouse robots are advancing, but real-world safety and reliability still depend on specialized, layered AI systems. The post FCC …
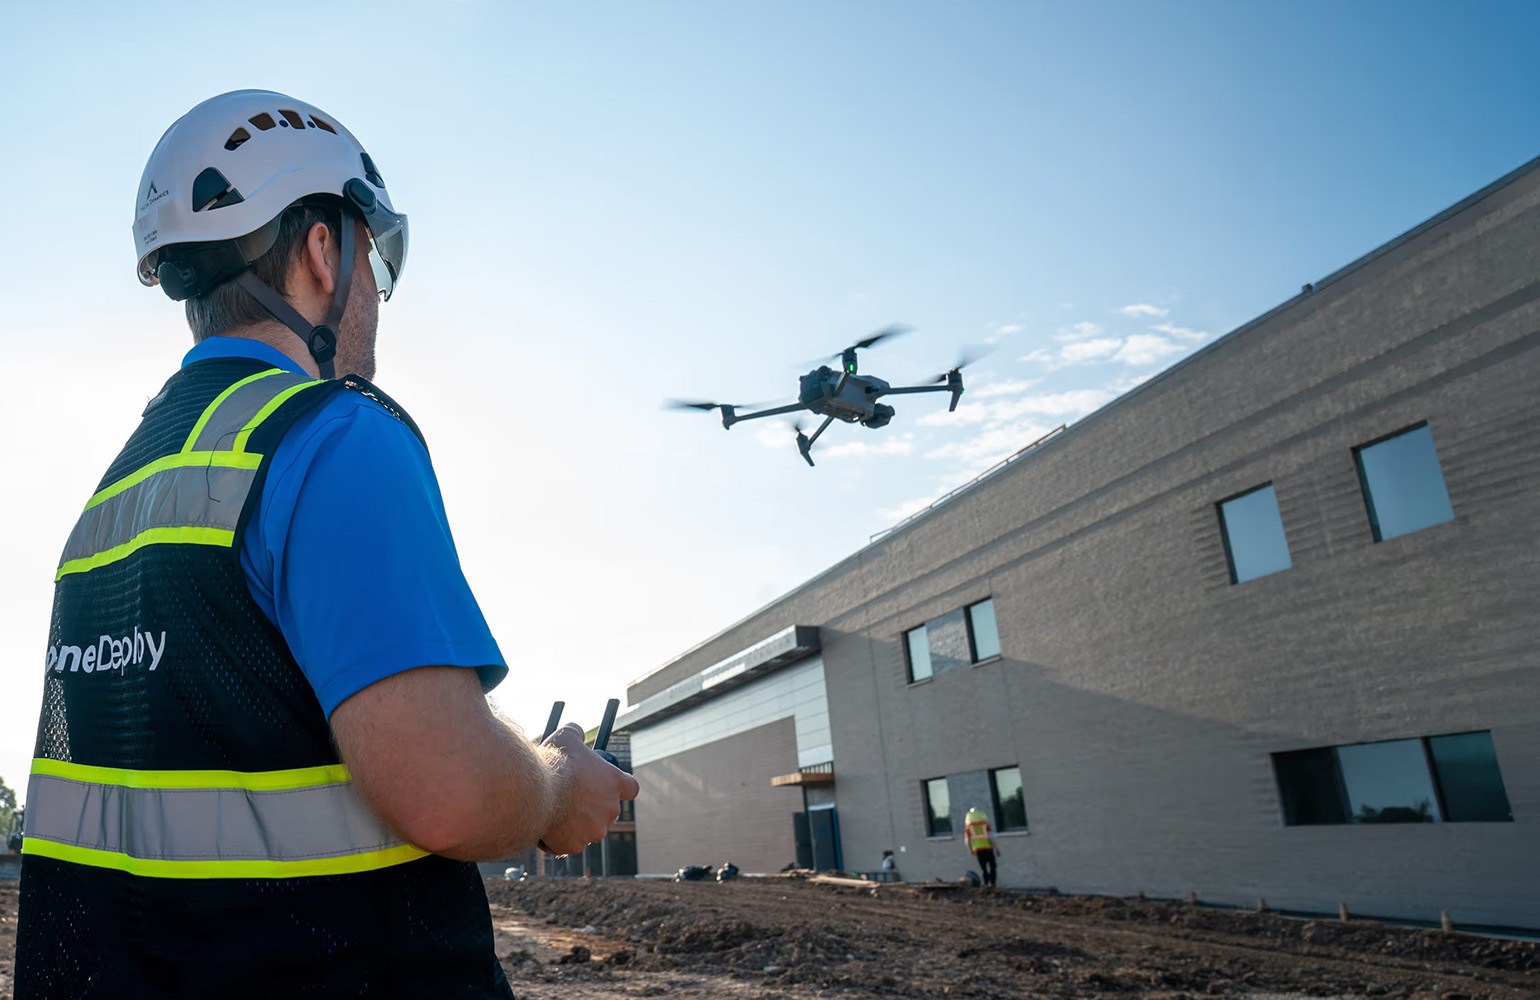
Procore Technologies acquires DroneDeploy for $845M
Procore will integrate DroneDeploy's visual intelligence technology to link the digital world with physical construction sites. The post Procore Technologies ac…
RMBench: Memory-Dependent Robotic Manipulation Benchmark with Insights into Policy Design
arXiv:2603.01229v3 Announce Type: replace Abstract: Robotic manipulation policies have made rapid progress in recent years, yet most existing approaches give li…
SeedPolicy: Horizon Scaling via Self-Evolving Diffusion Policy for Robot Manipulation
arXiv:2603.05117v4 Announce Type: replace Abstract: Imitation Learning (IL) enables robots to acquire manipulation skills from expert demonstrations. Diffusion …
PAC-MAN: Perception-Aware CBF-RL for Whole-Body Safety in Humanoid Dodgeball
arXiv:2607.28623v1 Announce Type: new Abstract: We present PAC-MAN, a perception-aware CBF-RL framework that couples control-barrier safety with deployment-real…
Simulation of Surgical Suturing Using Position-Based Dynamics and the Material Point Method for Robot Reinforcement Learning
arXiv:2607.27494v1 Announce Type: new Abstract: Recent advances in robotics research have created a strong demand for high-performance simulators. Surgical robo…
When Robots Exchange Meaning: A Demo of Goal-Oriented Semantic Communications for Collaborative Robotics
arXiv:2607.28256v1 Announce Type: new Abstract: Collaborative robotics is a representative task-oriented 6G use-case, where communication quality should be refl…
Machines that know they are aging: a framework for hardware-aware autonomous intelligence
arXiv:2607.28451v1 Announce Type: new Abstract: Autonomous systems inevitably age, yet their artificial intelligence typically assumes hardware remains in its o…
Corrigible Assistance in One Round: Pragmatic-Pedagogic Best Response
arXiv:2607.27508v1 Announce Type: new Abstract: Assistance games formalize human-robot collaboration under asymmetric information: the human knows the goal, whi…
DexDirect: Direct Kinesthetic Arm Guidance for Efficient Dexterous Demonstration Collection
arXiv:2607.27784v1 Announce Type: new Abstract: Scalable collection of dexterous manipulation demonstrations remains a major bottleneck for robot learning. High…
ARCSnake V2: Mechanical Adaptations For An Amphibious Multi-Domain Screw-Propelled Snake-Like Robot
arXiv:2511.11970v2 Announce Type: replace Abstract: Robotic exploration in extreme environments, such as caves, oceans, and extraplanetary surfaces, poses signi…
Goal-Oriented Semantic Communication for ISAC-Enabled Robotic Obstacle Avoidance
arXiv:2603.02291v2 Announce Type: replace Abstract: We investigate an integrated sensing and communication (ISAC)-enabled BS for the unmanned aerial vehicle (UA…
LabEvolver: Training-Free Experience Evolution for Safe and Grounded Wet-Lab Agents
arXiv:2607.27690v1 Announce Type: new Abstract: We introduce LabEvolver, a training-free framework that equips safe and grounded wet-lab agents with episodic me…
X-NavDP: Generalizing Navigation Diffusion Policy to Novel Behavior and Embodiments with Group Q-score Reweighted Matching
arXiv:2607.28560v1 Announce Type: new Abstract: Pretraining navigation diffusion policies rely on large-scale expert demonstrations. These data are typically ge…
HALO: Heterogeneous Admission through Localized Obligations for Safe Agentic Execution
arXiv:2607.27636v1 Announce Type: cross Abstract: Recent agentic AI systems may return a heterogeneous response containing notices, requests, handoffs, and acti…
Cross-Embodiment Transfer via Behavior-Aligned Representations
arXiv:2607.27549v1 Announce Type: new Abstract: Recent progress in large-scale imitation learning for robot manipulation has been driven by leveraging datasets …
CLAM: Continuous Latent Action Models for Robot Learning from Unlabeled Demonstrations
arXiv:2505.04999v2 Announce Type: replace Abstract: Learning robot control policies from demonstrations typically requires action-labeled expert data, which is …
SharedAssembly: A Data Collection Approach via Shared Tele-Assembly
arXiv:2503.12287v2 Announce Type: replace Abstract: High-precision, tight-clearance assembly demonstrations are indispensable for training tactile-aware robotic…
RedFlow: Redirect Failure into Action-Level Corrections for Flow-matching VLA Policy
arXiv:2607.27782v1 Announce Type: new Abstract: Flow-matching Vision-Language-Action (VLA) policies have shown strong potential for robotic manipulation but oft…
Failure Detection for Surgical Robot Imitation Policies via Flow-Matching World Modeling
arXiv:2607.27511v1 Announce Type: new Abstract: Imitation learning has shown increasing promise for autonomous robotic surgery, yet safe deployment remains chal…
One Future, Every Robot: Label-Efficient Collective-State Prediction with Decentralized JEPA
arXiv:2607.28443v1 Announce Type: new Abstract: Can every robot in a swarm predict the same future collective state from only local observations and bandwidth-l…
Arm2Air: Cross-Embodiment Skeleton Transfer for 3D Relay Formation
arXiv:2607.27627v1 Announce Type: new Abstract: Unmanned aerial vehicle (UAV) relay networks can restore connectivity after communication infrastructure is dama…
A Robust Placeability Metric for Model-Free Unified Pick-and-Place Reasoning
arXiv:2510.14584v3 Announce Type: replace Abstract: Reliable manipulation of previously unseen objects remains a fundamental challenge for autonomous robotic sy…
World Action Planner: Generalizable Decision-Making with Action-Conditioned World Models
arXiv:2607.27599v1 Announce Type: cross Abstract: Building generalizable agents for diverse applications remains a fundamental challenge. While imitation learni…
Ultrafast Sampling-based Kinodynamic Planning via Differential Flatness
arXiv:2603.16059v3 Announce Type: replace Abstract: Motion planning under dynamics constraints, i.e, kinodynamic planning, enables safe robot operation by gener…
Compact Task-Aligned Imitation Learning for Laboratory Automation
arXiv:2603.01110v2 Announce Type: replace Abstract: Robotic laboratory automation has traditionally relied on carefully engineered motion pipelines and task-spe…
REFINE-DP: Diffusion Policy Fine-tuning for Humanoid Loco-manipulation via Reinforcement Learning
arXiv:2603.13707v3 Announce Type: replace Abstract: Humanoid loco-manipulation requires coordinated task-space motion planning with stable loco-manipulation com…
Metrics vs Surveys: An Analysis for Human-Aligned Benchmarking in Social Robot Navigation
arXiv:2510.02941v2 Announce Type: replace Abstract: Social, also called human-aware, navigation is a key challenge for integrating mobile robots into human envi…
SUNSET - A Sensor-fUsioN based semantic SegmEnTation exemplar for ROS-based self-adaptation
arXiv:2601.13732v2 Announce Type: replace Abstract: The fact that robots are getting deployed more often in dynamic environments, together with the increasing c…
Relational Scene Graphs for Object Grounding of Natural Language Commands
arXiv:2602.04635v2 Announce Type: replace Abstract: Robots are finding wider adoption in human environments, increasing the need for natural human-robot interac…