News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesCombining Large Language Models and Symbolic Reasoning for Multi-Robot Temporal Planning through Explainable Knowledge Bases
arXiv:2502.19135v2 Announce Type: replace-cross Abstract: We present PLANTOR, a framework for generating and executing multi-robot task plans from natural-langu…
GPA-RAM: Grasp-Pretraining Augmented Robotic Attention Mamba for Spatial Task Learning
arXiv:2504.19683v4 Announce Type: replace Abstract: Fine-grained robotic manipulation often fails when inaccurate initial grasps propagate errors and necessitat…
FibVLA: An Efficient Temporal Vision-Language-Action Model with Fibonacci Sampling
arXiv:2607.29596v1 Announce Type: new Abstract: Vision-language-action models (VLAs), which leverage the cognition of multimodal information to infer physical-w…
Diagnosing Compositional Generalization in Sequential Robot Tasks
arXiv:2607.29687v1 Announce Type: new Abstract: Sequential robot manipulation requires policies to execute novel combinations of familiar instruction components…
Vision-Based Agile Landing on Turbulent Waters
arXiv:2605.23717v2 Announce Type: replace Abstract: Autonomous landing of Unmanned Aerial Vehicles on maritime vessels is challenging due to the coupled motion …
Outcome-Guided Distillation: A Teacher-Student Framework to Advance VLM Reasoning in Autonomous Driving
arXiv:2607.29052v1 Announce Type: new Abstract: End-to-end (E2E) autonomous driving aims to learn a direct mapping from visual observations to control actions. …
Receding-Horizon Next-Best-View Planner for Autonomous Leaf Surface Reconstruction
arXiv:2607.28995v1 Announce Type: new Abstract: Accurate plant leaf modeling is fundamental to downstream tasks such as plant growth monitoring, and phenotyping…
TransGraspNet: Physically and Geometrically Consistent Manipulation of Transparent Labware
arXiv:2607.29567v1 Announce Type: new Abstract: Manipulating transparent laboratory glassware that contains liquid is inherently safety-critical: even small geo…
STAGE: STyle-controllable Action GEneration for personalized autonomous driving
arXiv:2607.29517v1 Announce Type: new Abstract: Driving style refers to the behavioral preferences that drivers maintain during driving, shaped by their diverse…
Automated Straight-line Sewing of Stretchable Fabrics with Different Lengths
arXiv:2607.29464v1 Announce Type: new Abstract: Different Length Alignment Sewing (DLAS), which involves stretching the shorter fabric to match the longer one a…
Advances, challenges, and opportunities for legged robots
arXiv:2607.28952v1 Announce Type: new Abstract: Humanoid and quadrupedal robots have the potential to revolutionize the way we work, interact, and coexist with …
ASVSim (AirSim for Surface Vehicles): A High-Fidelity Simulation Framework for Autonomous Surface Vehicle Research
arXiv:2506.22174v3 Announce Type: replace Abstract: The transport industry has recently shown significant interest in unmanned surface vehicles (USVs), specific…
Homotopy-Aware Corridor Generation without Predefined Reference Paths
arXiv:2607.29513v1 Announce Type: new Abstract: Generating safe corridors is essential for collision-free robotic motion planning, yet most existing methods rel…
Balancing of Humanoid with Object Mass: Trade-off Analyses and Lifting Control
arXiv:2607.29625v1 Announce Type: new Abstract: The demand for humanoid loco-manipulation tasks with an object has recently increased, and most existing control…
TacPrint: A Wearable Fingertip Tactile Sensor for Human-to-Robot Contact Reproduction
arXiv:2607.29231v1 Announce Type: new Abstract: Human-centric data collection is emerging as a significant paradigm for robot skill acquisition, but seamlessly …
TRACT: Temporally Routed Action Chunks with Chronological Phase Authority for Contact-Rich Manipulation
arXiv:2607.29285v1 Announce Type: new Abstract: Action chunking shortens the effective decision horizon of robot imitation learning by predicting multiple futur…
ActFovea: Runtime Safeguarding for VLA Policies via Spatiotemporal Visual-Action Consistency
arXiv:2607.29169v1 Announce Type: new Abstract: Vision-language-action (VLA) policies achieve strong performance in robotic manipulation but remain vulnerable t…
Auto-JEPA: A Latent World Model of Continuous Intent for End-to-End Autonomous Driving
arXiv:2607.29031v1 Announce Type: new Abstract: Existing autonomous-driving world models typically perform dense prediction of future videos, occupancy states, …
ST-WAM: Semantic-Temporal World Action Model for Robust Manipulation under Visual Distribution Shifts
arXiv:2607.28993v1 Announce Type: new Abstract: World Action Models (WAMs) have emerged as a promising paradigm by jointly modeling robot actions and future vis…
FBFM: A Training-Free Asynchronous Feedback Mechanism for Flow-Matching in World-Action Models Execution
arXiv:2607.29235v1 Announce Type: new Abstract: Although world-action models (WAMs) enhance long-horizon robot control by predicting visual evolution before act…
CLIFT: Turning Gemini Robotics On-Device into Humanoid Specialists via Non-Invasive Closed-Loop Iterative Fine-Tuning
arXiv:2607.29172v1 Announce Type: new Abstract: While robot foundation models are growing increasingly capable, the strongest models are typically trained on pr…
HAM-VLN: Harnessing Hierarchical Agentic Memory for Zero-Shot Vision-and-Language Navigation
arXiv:2607.29600v1 Announce Type: new Abstract: Vision-and-language navigation (VLN) enables robots to follow instructions in previously unseen environments. Re…
Event-Based Upper-Body Humanoid Teleoperation Under Challenging Illumination
arXiv:2607.29227v1 Announce Type: new Abstract: We present a real-time upper-body human-to-humanoid motion imitation framework driven by neuromorphic event-base…
Temporal Policy: History-Initialized Action Generation for Robotic Learning from Demonstration
arXiv:2607.29482v1 Announce Type: new Abstract: By relying on independent couplings from uninformative Gaussian priors, standard diffusion and flow matching mod…
Shepherding UAV Swarm with Action Prediction Based on Movement Constraints
arXiv:2604.17189v3 Announce Type: replace Abstract: In this study, we propose a new sheepdog-inspired control method for a swarm of small unmanned aerial vehicl…
Bootstrapping Self-Supervised Learning of Binary Classification Using Error Bounds: A Case Study on a Robotic Insertion Task
arXiv:2607.29640v1 Announce Type: new Abstract: Flexible manufacturing requires rapid deployment of solutions and minimal setup time to remain competitive. An e…
RAPiD: Reward-Guided Consistency Distillation of Diffusion Planners for Real-Time Autonomous Driving
arXiv:2602.07339v2 Announce Type: replace-cross Abstract: Diffusion-based trajectory planners can model multi-modal driving behavior, but their iterative denois…
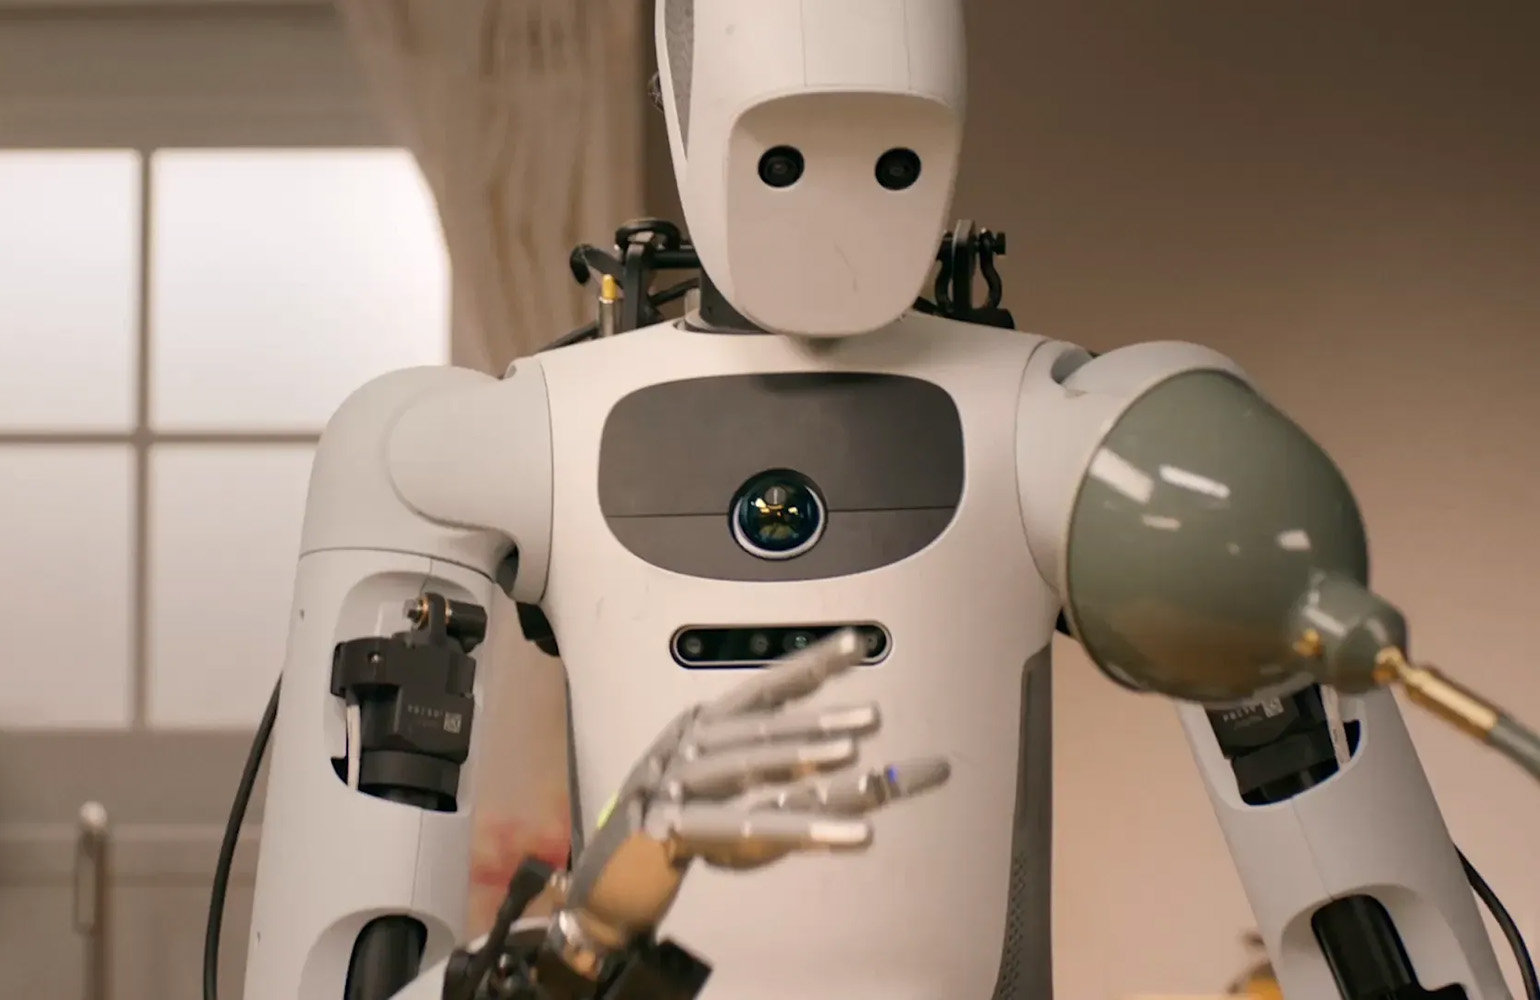
Google DeepMind says Gemini Robotics 2 enables full body control
Gemini Robotics 2 enables robots to reason through every movement, unlocking a broad range of tasks, DeepMind said. The post Google DeepMind says Gemini Robotic…
Top 10 robotics stories of July 2026
In July, large funding rounds, new approaches to robot training, and new robot models drew our readers attention. The post Top 10 robotics stories of July 2026 …
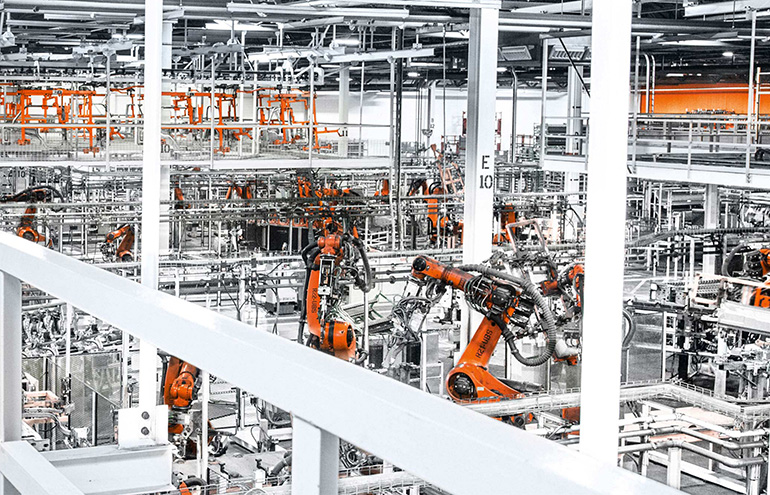
KUKA deploys Automation Management Platform for North American automakers
KUKA has deployed its Automation Management Platform at KTPO, a major manufacturing facility in Ohio. The post KUKA deploys Automation Management Platform for N…