News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesWhy did My Robot Just Change Personality? Prompting Guidelines for a Grounded Robot Persona in LLM-Based HRI
arXiv:2608.26182v1 Announce Type: cross Abstract: Large language models (LLMs) are increasingly used for verbal interaction in social robots, yet prompt design …
Planning a Shared Modular Fixture Layout Across Robotic Disassembly Stages
arXiv:2608.27151v1 Announce Type: new Abstract: Stable support remains challenging in robotic disassembly of irregularly shaped products. As components are prog…
Riemann-1.0: An Embodied World Action Model for Physical AI
arXiv:2608.27033v1 Announce Type: new Abstract: We introduce Riemann-1.0, a fully causal autoregressive World Action Model for embodied intelligence. Riemann-1.…
Active Surface-Driven Reconfigurable Gripper: Robust Grasping and Sequential Manipulation of Thin Objects
arXiv:2608.26883v1 Announce Type: new Abstract: Robotic grippers face substantial challenges in grasping and manipulating thin objects. Most existing grippers r…
PredVLA: A Sub-Million-Parameter Predictive-Coding Policy for Robot Manipulation
arXiv:2608.26673v1 Announce Type: new Abstract: Large pretrained vision-language-action models dominate modern robot-manipulation benchmarks, but it remains unc…
FLARE: A Failure-Aware Framework for Autonomous Correction and Recovery in Visual-Language Robotic Manipulation
arXiv:2608.26645v1 Announce Type: new Abstract: Vision-Language-Action Models~(VLAs) have demonstrated significant promise in generalizing to complex, long-hori…
Cross-Platform Benchmark of Neural 3D Reconstruction for Autonomous Laboratory Robots
arXiv:2608.26383v1 Announce Type: new Abstract: Autonomous robots performing laboratory tasks depend on 3D reconstruction pipelines that can turn raw camera str…
Closing the Loop on the Poppy Humanoid: Bipedal Locomotion with Linear-Quadratic Control and Learned Cost Functions
arXiv:2608.26505v1 Announce Type: new Abstract: The Poppy Humanoid is an open-source, low-cost robot suitable for research and education in artificial intellige…
Memory Anchors for Continual Robot Learning
arXiv:2608.26545v1 Announce Type: new Abstract: Robot policies deployed in the wild should have the capability to continually learn new tasks without forgetting…
SOLO: Stable Omni-terrain Long-Horizon Perceptive Humanoid Locomotion
arXiv:2608.26583v1 Announce Type: new Abstract: Humans traverse complex terrain over long distances without losing balance, whereas perceptive humanoid policies…
Residual Deep Reinforcement Learning-Based Computed Torque Control for a Cable-Driven Lower-Limb Rehabilitation Robot under Disturbances and Parametric Uncertainties
arXiv:2608.26739v1 Announce Type: new Abstract: Accurate trajectory tracking in cable-driven lower-limb rehabilitation robots is challenging because model uncer…
Residual Reward Models: Leveraging Prior Knowledge for Efficient Preference-based Reinforcement Learning in Robotics
arXiv:2507.00611v2 Announce Type: replace-cross Abstract: Preference-based Reinforcement Learning (PbRL) provides a promising alternative to heuristic reward de…
Marine Autonomous Vehicle Fleet Scheduling to Maximise Scientific Impact
arXiv:2608.27271v1 Announce Type: cross Abstract: The marine science community increasingly relies on Marine Autonomous Vehicles (MAVs) to collect the critical …
CLAP: Cross-Embodiment Video World Models are Zero-Shot Physical Simulators
arXiv:2608.27406v1 Announce Type: new Abstract: State-of-the-art action-conditioned video models are typically restricted to a single robot embodiment, preventi…
Embodied Scene Rearrangement Planning
arXiv:2608.27371v1 Announce Type: new Abstract: This paper introduces Embodied Scene Rearrangement Planning (ESRP), a novel task requiring embodied agents to re…
Active sensing to characterize the heterogeneity of plant stress
arXiv:2608.27088v1 Announce Type: new Abstract: While most phenotyping platforms rely primarily on image-based measurements, advanced plant characterization req…
TemporalFlow-VLA: Learning Physically Grounded Execution History for Long-Horizon Robot Manipulation
arXiv:2608.26821v1 Announce Type: new Abstract: Vision-language-action (VLA) models leverage pretrained vision-language representations for robot control, yet s…
Rapid On-Robot Learning for Dynamic Manipulation Skills: Robot Juggling
arXiv:2608.26800v1 Announce Type: new Abstract: We present an online learning framework that enables a bimanual robot to acquire diverse juggling patterns direc…
Relaxation-Aware Multimodal Sensing of Soft Gripper Driven by Structure-Perception-Learning
arXiv:2608.26622v1 Announce Type: new Abstract: Achieving stable, sustained grasping with soft robotic hands remains a fundamental challenge. Compliance enables…
TrapVLA: Trapping Vision-Language-Action Models in Configured Failure Modes
arXiv:2608.26578v1 Announce Type: new Abstract: This work introduces Configured Failure Trapping, a novel backdoor attack task against Vision-Language-Action (V…
WALL-SS: Scaling Long-horizon World Models via Next-Scale Autoregression
arXiv:2608.26239v1 Announce Type: new Abstract: Generative world models provide robots with predictive models of how the world evolves under interaction, with g…
NSF to invest $90M into three new technology centers, including one focused on robotics
One of the new NSF funded centers will be the Center for Human and Robot Co-Adaptation, led by The University of Texas at Austin. The post NSF to invest $90M in…
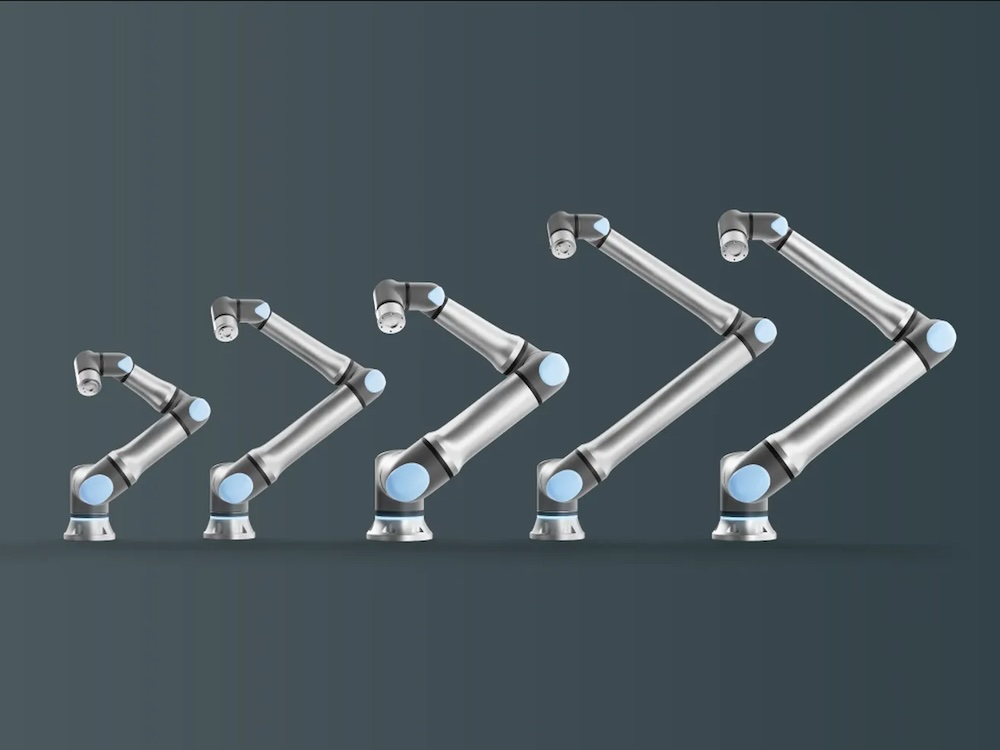
Teradyne Robotics ramps up fight against cobot copycats
Teradyne Robotics sued cobot maker JAKA over alleged patent infringement, marking its second battle with a Chinese cobot company in 2026. The post Teradyne Robo…
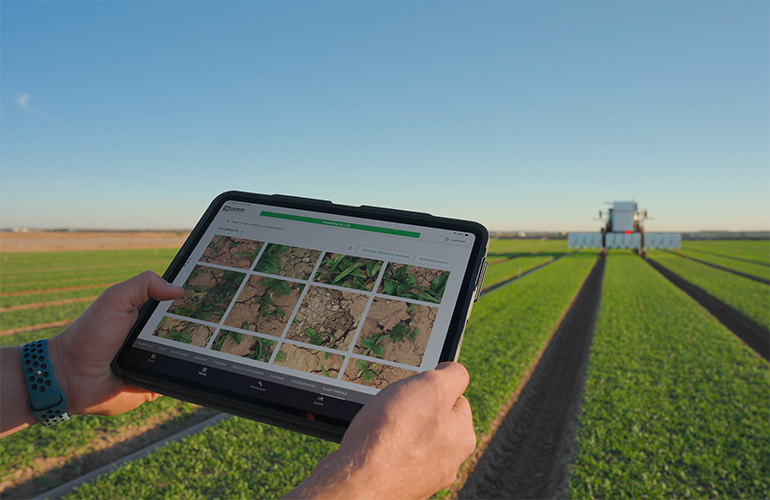
Carbon Robotics partners with iMerit to power instant in-field AI customization
Carbon Robotics introduced a plant foundation AI model and tractor kit, enabling farmers to customize laser weeding. The post Carbon Robotics partners with iMer…
Generative Action-Chunk Sampling for Adaptive Stiffness Control in Physical Human-Robot Collaboration
arXiv:2608.25284v1 Announce Type: new Abstract: Physical human-robot collaboration requires a robot to provide assistance when human intention is clear while re…
A Tendon-Driven Five-Fingered Hand with Distributed Tactile Perception for Dexterous Manipulation
arXiv:2608.25547v1 Announce Type: new Abstract: To apply the techniques of embodied artificial intelligence to human-oid robots for complex manipulations, dexte…
EgoNav: Bridging Learned Waypoints and Geometry-Aware Local Control for Robust Indoor Navigation
arXiv:2608.25642v1 Announce Type: new Abstract: Image-goal navigation using lightweight topological maps is a practical paradigm for indoor robot deployment: th…
Low-Resolution Perception for Robotic Packing
arXiv:2608.25874v1 Announce Type: new Abstract: This work tackles the problem of scalable perception for robotic packing with low-cost, low-resolution depth sen…
DESCENT: Directed Edge Scene Encoding for Airport Surface Movement Prediction
arXiv:2608.26002v1 Announce Type: new Abstract: Advanced automation is a key technology for enhancing the safety of ground operations amidst the increasing dens…
$R^3$: Training Robots to Reason in Natural Language via Reinforcement Learning
arXiv:2608.26053v1 Announce Type: new Abstract: Reasoning in language allows foundation models to spend more test-time compute on hard problems, such as those r…