News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesGaussianDream++: Efficient 3D Gaussian World Modeling for Robotic Manipulation
arXiv:2608.25659v1 Announce Type: new Abstract: Vision-Language-Action (VLA) policies have advanced language-conditioned robotic manipulation, yet action-imitat…
RA-VLA: Retrieval-Augmented VLA for Test-Time Adaptation
arXiv:2608.25585v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models provide a versatile foundation for general robotic manipulation, yet they ex…
A Taxonomy of Construction Task Activities for Robot Workers
arXiv:2608.25395v1 Announce Type: new Abstract: Recent vision-language-action models offer a path toward robots with broader repertoires than conventional task-…
RAEM: Robust Autonomous Exploration for Multi-Floor Environments with a Quadruped Robot
arXiv:2608.25366v1 Announce Type: new Abstract: In this paper, we propose RAEM, a robust autonomous exploration framework for quadruped robots operating in mult…
ROS2 Connect: A new ROS2 over WAN Solution
arXiv:2608.25102v1 Announce Type: new Abstract: The Robot Operating System 2 (ROS2) has become a widely adopted framework for the development of distributed rob…
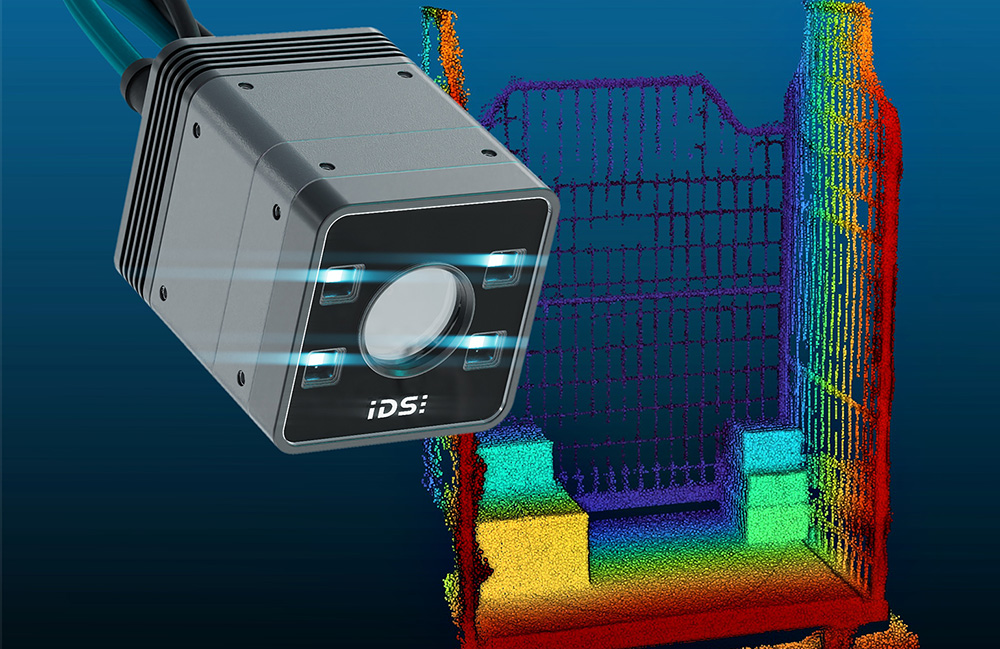
IDS Imaging adds Nion ToF sensor to its portfolio of 3D cameras
IDS said Nion is suitable for applications where precise 3D data is required at real-world process speeds, such as logistics and robotics. The post IDS Imaging …
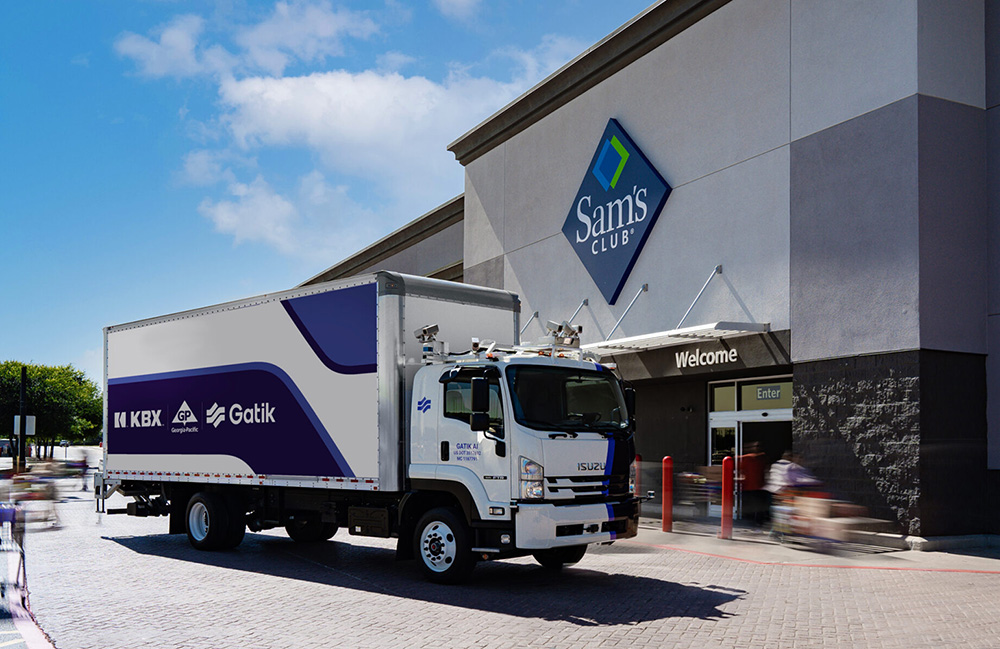
Gatik brings in $200M to continue expanding autonomous trucking operations
Gatik said the funding will help it expand its model built around high-frequency regional routes connecting distribution centers and stores. The post Gatik brin…
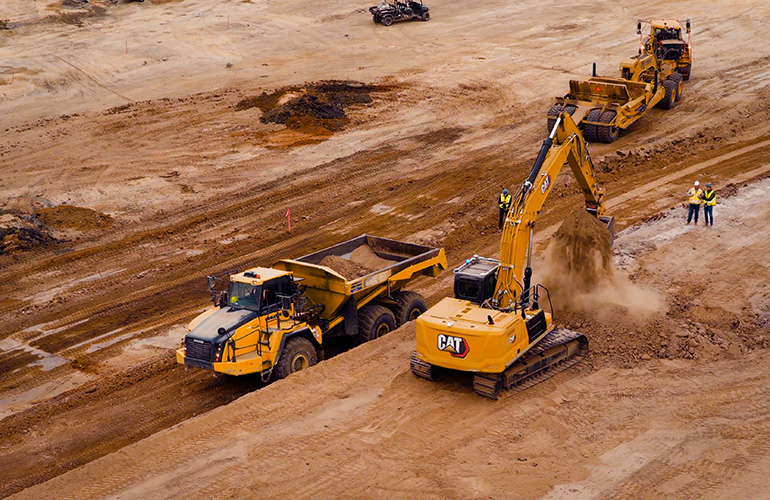
Bedrock Robotics’ first operator-free excavator deployments take off
Bedrock Robotics deploys autonomous excavators to active job sites, tackling construction labor shortages with AI-powered heavy machinery. The post Bedrock Robo…
How green is your robot? And other awkward questions
Deborah Lupton / Servers in a Landscape / Licenced by CC-BY 4.0 By Emmet Cole Robots clean rivers and sort waste, monitor ecosystems, and inspect renewable-ener…
CARE: Camera-Residual Reserves for First Sightings in Adaptive LiDAR Sensing
arXiv:2608.24282v1 Announce Type: cross Abstract: Adaptive LiDAR scanning concentrates a limited sensing budget on regions of interest predicted from past objec…
VGGT-DP: Generalizable Robot Control via Vision Foundation Models
arXiv:2509.18778v2 Announce Type: replace Abstract: Visual imitation learning frameworks allow robots to learn manipulation skills from expert demonstrations. W…
A Robust Task-Level Control Architecture for Learned Dynamical Systems
arXiv:2511.09790v2 Announce Type: replace Abstract: Dynamical system (DS)-based learning from demonstration (LfD) is a powerful tool for generating motion plans…
From Dialogue to Execution: Mixture-of-Agents Assisted Interactive Planning for Behavior Tree-Based Long-Horizon Robot Execution
arXiv:2603.01113v2 Announce Type: replace Abstract: Interactive task planning with large language models (LLMs) lets robots generate high-level action plans fro…
AURASeg: Attention-Guided Upsampling with Residual-Assisted Boundary Refinement for Drivable-Area Segmentation
arXiv:2510.21536v5 Announce Type: replace Abstract: Free-space segmentation is essential for autonomous robots to identify drivable regions and navigate safely …
Do Robotic World Models Really Follow Actions? Diagnosing and Aligning Action-Conditioned Generation for Policy Learning
arXiv:2608.24885v1 Announce Type: new Abstract: Action-conditioned world models are increasingly used as learned simulators for policy evaluation and improvemen…
Latent Action as Intention Enables Efficient Future Imagination for World Action Models
arXiv:2608.24882v1 Announce Type: new Abstract: World action models (WAMs) improve robot control by modeling how observations evolve, but generating future obse…
One-Shot Learning from Demonstration of Contact-Rich Robotic Manipulation by Identifying Physical Interactions
arXiv:2608.24741v1 Announce Type: new Abstract: Learning from Demonstration (LfD) allows robots to learn manipulation tasks directly from humans, thereby suppor…
NVIDIA Cosmos-H-Dreams: Real-Time Generative Physics Simulation for Surgical Robotics
arXiv:2608.24199v1 Announce Type: new Abstract: Generative simulation for surgical robotics still lacks real-time interaction. Physical-robot experiments, often…
Coverage Planning for Robotic Tooth Preparation in Densely Constrained Environments
arXiv:2608.24155v1 Announce Type: new Abstract: Tooth preparation refers to the controlled removal of tooth structure to create an optimal substrate for fixed r…
PonderPounce: A Pretrained MLLM as an Episode Context Engine for Robot Control
arXiv:2608.24115v1 Announce Type: new Abstract: Multimodal large language models (MLLMs) can integrate long visual histories, reason under partial observability…
Hierarchical Skill Retrieval for Data-Efficient Adaptation of Vision-Language-Action Models
arXiv:2608.24042v1 Announce Type: new Abstract: While Vision-Language-Action (VLA) models pretrained on large-scale robot datasets provide a strong foundation f…
NeurRAFT: Robot Motion Planning via Anchor-Level Flow Matching with Clearance-Aware Preference Tuning
arXiv:2608.24026v1 Announce Type: new Abstract: Recent end-to-end neural motion planners generate trajectories from raw sensor observations, avoiding the privil…
Learning to Act While Waiting: RL Finetuning of Generalist Robot Policies Under Inference Latency
arXiv:2608.23831v1 Announce Type: new Abstract: While reinforcement learning (RL) allows generalist robot policies to continually improve during deployment, the…
Concept-Guided Exploration: Building Persistent, Actionable Scene Graphs
arXiv:2608.23650v1 Announce Type: new Abstract: The perception of 3D space by mobile robots is rapidly moving from flat metric grid representations to hybrid me…
DreamLedger: Execution-Settled Credit Files for World-Model Imagination in Robot Decision Loops
arXiv:2608.23863v1 Announce Type: new Abstract: Robots are beginning to act on world-model predictions, yet reliability is still expressed through instantaneous…
Sensorless damage-safe grasping
arXiv:2608.23983v1 Announce Type: new Abstract: Robotic fruit harvesting must hold produce securely without bruising it, yet compression stiffness varies severa…
Bridging Teacher Expectations and Robot Learning via Coupling Dynamics
arXiv:2608.23994v1 Announce Type: new Abstract: Human-robot teaching focuses on enabling nontechnical experts to customize robots according to their needs after…
Trajectory-Level Continuous Action Representation for Robotic Manipulation
arXiv:2608.24111v1 Announce Type: new Abstract: We propose CAT, a trajectory-level continuous action representation framework for robotic manipulation. Existing…
Adaptive Multi-Mode Out-of-Distribution Detection for Trajectory Prediction in Autonomous Vehicles
arXiv:2509.13577v3 Announce Type: replace-cross Abstract: Trustworthy trajectory prediction grounds autonomous vehicle (AV) safety, yet deployed models inevitab…
Topology-Aware Decision Making for Multi-Session Localization and Mapping
arXiv:2602.17226v2 Announce Type: replace Abstract: Operating in previously visited environments is becoming increasingly crucial for autonomous systems, with d…