News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesBrain-Language-Action (BLA) Models: Language-Conditioned EEG for Robotics Control
arXiv:2608.28967v1 Announce Type: new Abstract: Electroencephalography (EEG)-based robotic control is commonly formulated as a direct classification problem, in…
GHOST in the Robots: Real-Time Exocentric Dual-Robot VR Teleoperation from Onboard Cameras
arXiv:2608.29080v1 Announce Type: new Abstract: Teleoperating multiple robots simultaneously enables additional views and coordinated control. Yet, it poses fun…
Systematic Lightweight Method for Robotics Based on Strain Energy Distribution Optimization
arXiv:2608.29146v1 Announce Type: new Abstract: Service robots work with people and are highly expected to be lightweight for safety, agility and energy conserv…
Toward Trustworthy Robot-Assisted Sliding Palpation for Shallow Vessel Localisation with a Calibrated Digital Twin
arXiv:2608.29396v1 Announce Type: new Abstract: Reliable localisation of shallow subsurface vessels is important for safe robot-assisted venous access and vesse…
HybridWorldSim: A Scalable and Controllable High-fidelity Simulator for Autonomous Driving
arXiv:2511.22187v4 Announce Type: replace-cross Abstract: Realistic and controllable simulation is critical for advancing end-to-end autonomous driving, yet exi…
RoboTrustBench: Benchmarking the Trustworthiness of Video World Models for Robotic Manipulation
arXiv:2606.01600v2 Announce Type: replace-cross Abstract: Video world models are increasingly used in robotic manipulation, yet existing benchmarks mostly evalu…
A Kinematic Framework for Screening Candidate Pinch Configurations in Robotic Hand Design without Object or Contact Models
arXiv:2604.20692v2 Announce Type: replace Abstract: Evaluating the pinch capability of a robotic hand is important for understanding its functional dexterity. H…
Learning Agile Perceptive Traversal of Sparse 3D Structures for Humanoids
arXiv:2608.29769v1 Announce Type: new Abstract: Traversing sparse 3D structures requires humanoid robots to perceive thin, overhanging geometry while executing …
MiBOT: A head-worn robot that modulates cardiovascular responses through human-like soft massage
arXiv:2608.30055v1 Announce Type: new Abstract: Massage therapy is helpful for the rehabilitation of various diseases, such as headaches caused by migraines and…
Optimized Modular Design and Development of a Tilt-Rotor Bicopter Drone
arXiv:2608.30222v1 Announce Type: new Abstract: Hybrid systems like tilt-rotor bicopter drones combine the beneficial characteristics of both fixed-wing and rot…
CometVLA: Co-Training on an Embodied Data Pyramid towards Physical Understanding
arXiv:2608.30289v1 Announce Type: new Abstract: Vision-language-action (VLA) models remain brittle in manipulation tasks that require physical commonsense. Curr…
AGRICAM: A Track-Mounted Crop Pollination Monitoring Robot
arXiv:2608.29237v1 Announce Type: cross Abstract: Insect pollination is critical for global food production, yet monitoring pollinators at commercial farm scale…
Fully Distributed GNE Algorithms for Multi-Robot Placement without Consensus on Multipliers
arXiv:2608.29388v1 Announce Type: cross Abstract: Recent machine learning research has increasingly focused on equilibrium analysis in non-cooperative games rat…
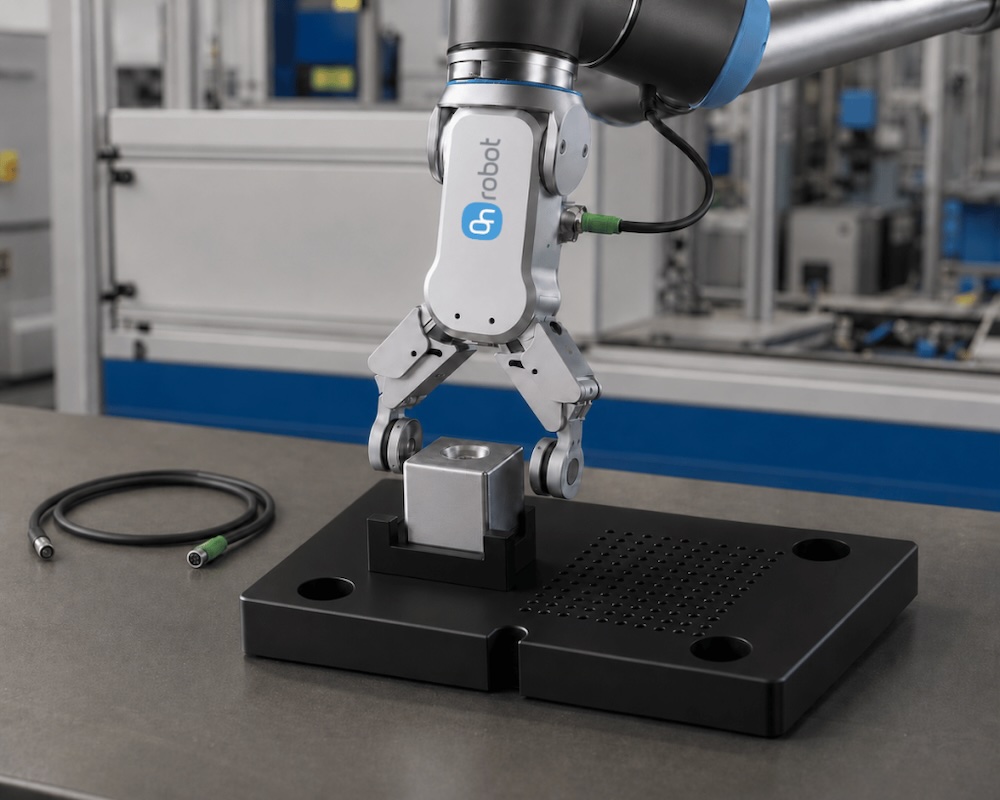
How better grippers can unlock physical AI
Physical AI depends on smarter grippers to give robots the dexterity, sensing and adaptability needed to handle real-world tasks. The post How better grippers c…
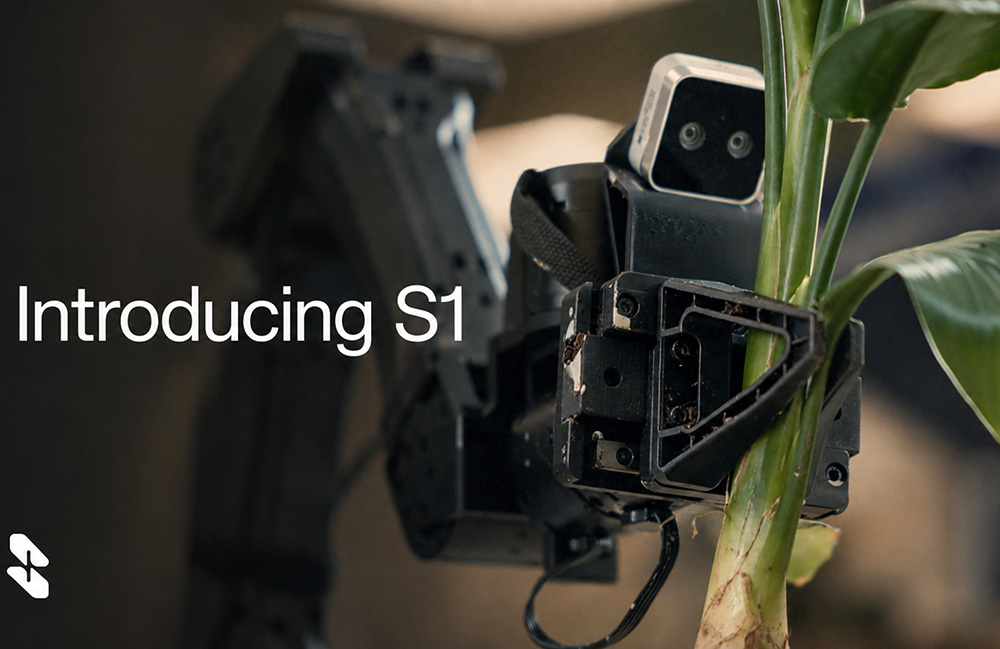
Skild AI unveils S1 flagship robot foundation model
Skild AI says its S1 robot foundation model enables robots to learn new tasks just by seeing a video of it being performed. The post Skild AI unveils S1 flagshi…
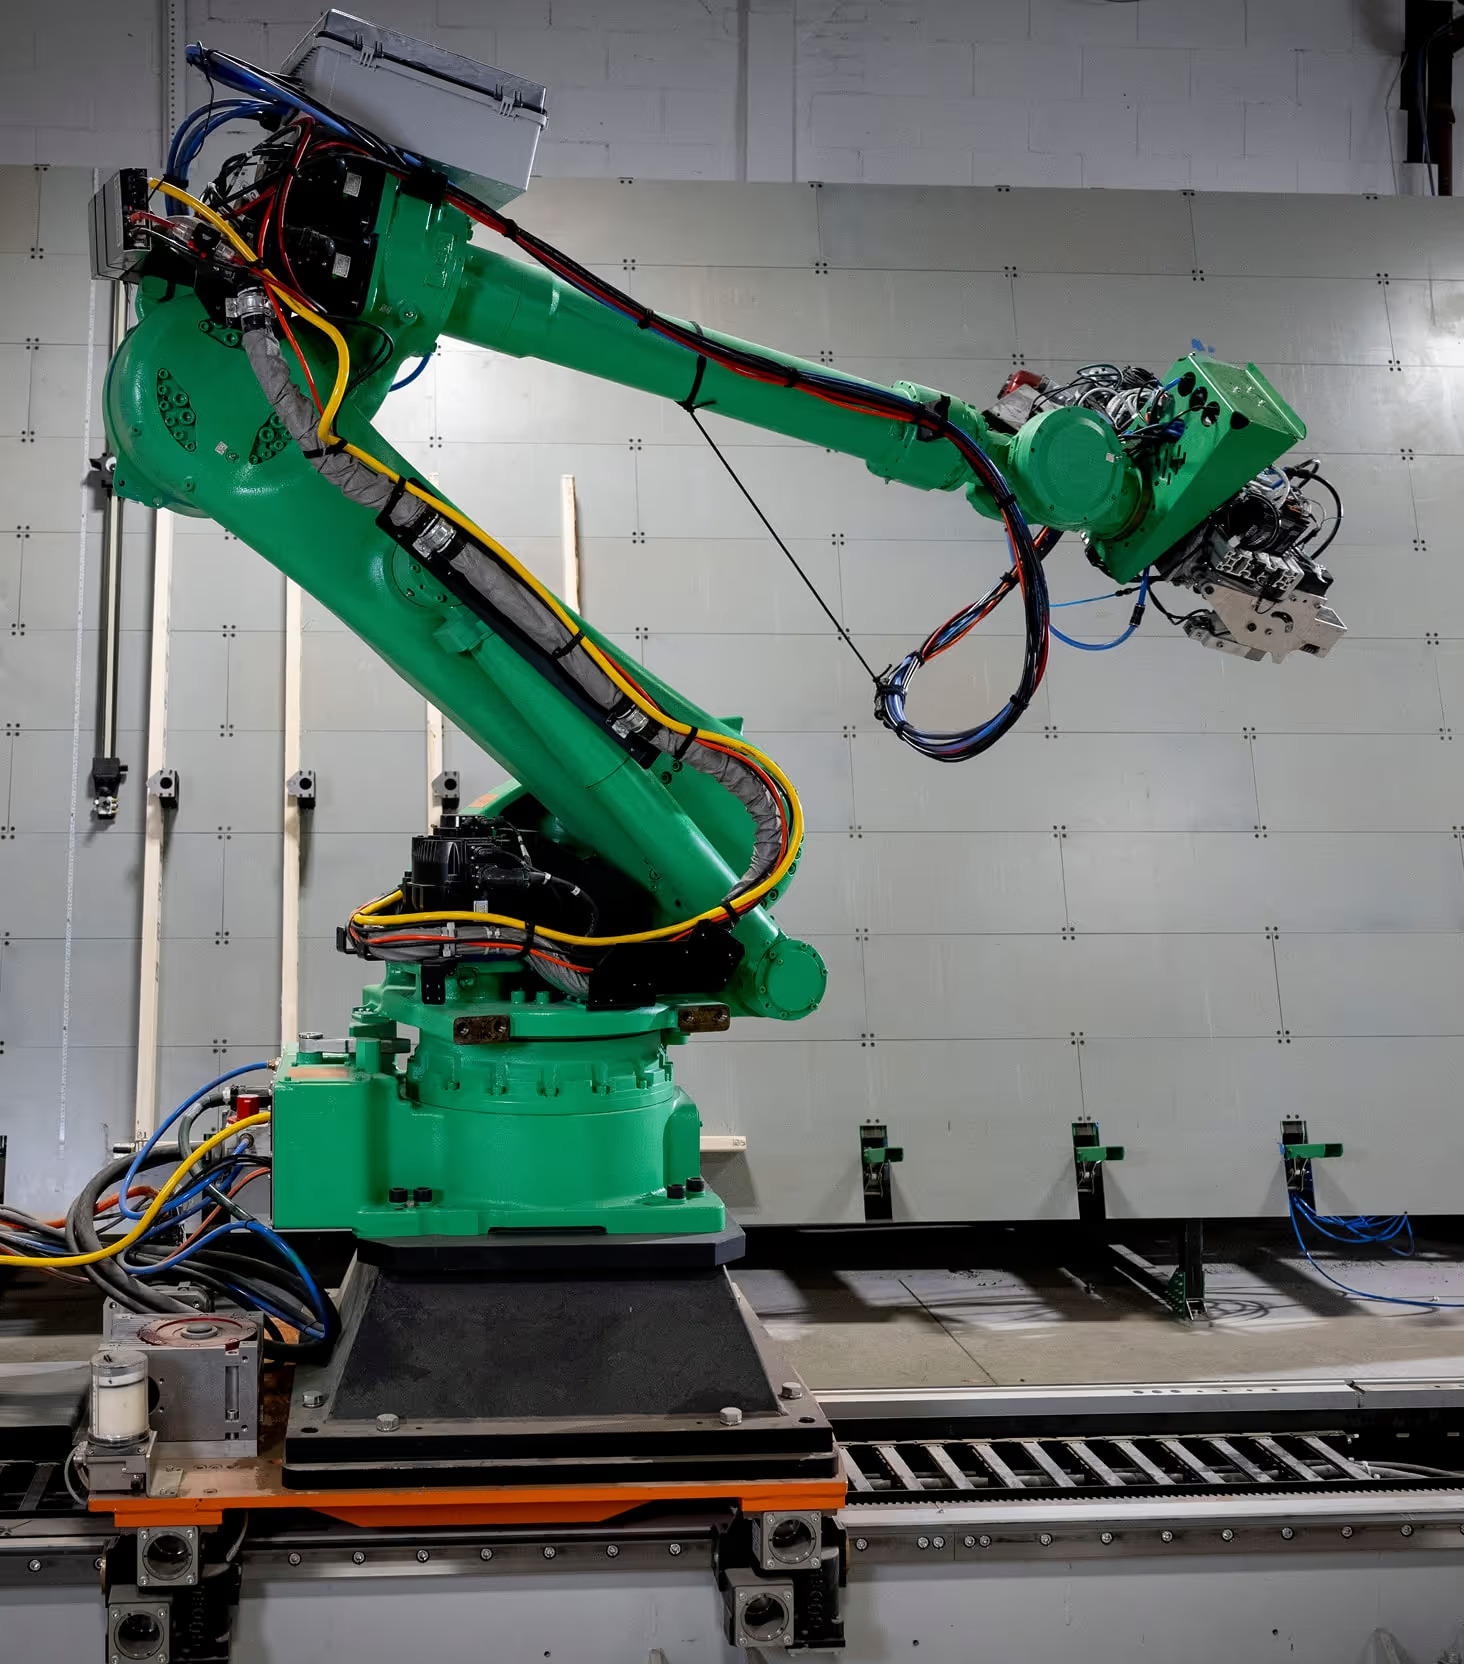
Reframe Systems raises $40M to scale its robotic microfactories for home building
Reframe Systems aims to build a network of automated microfactories near communities where homes are needed. The post Reframe Systems raises $40M to scale its r…
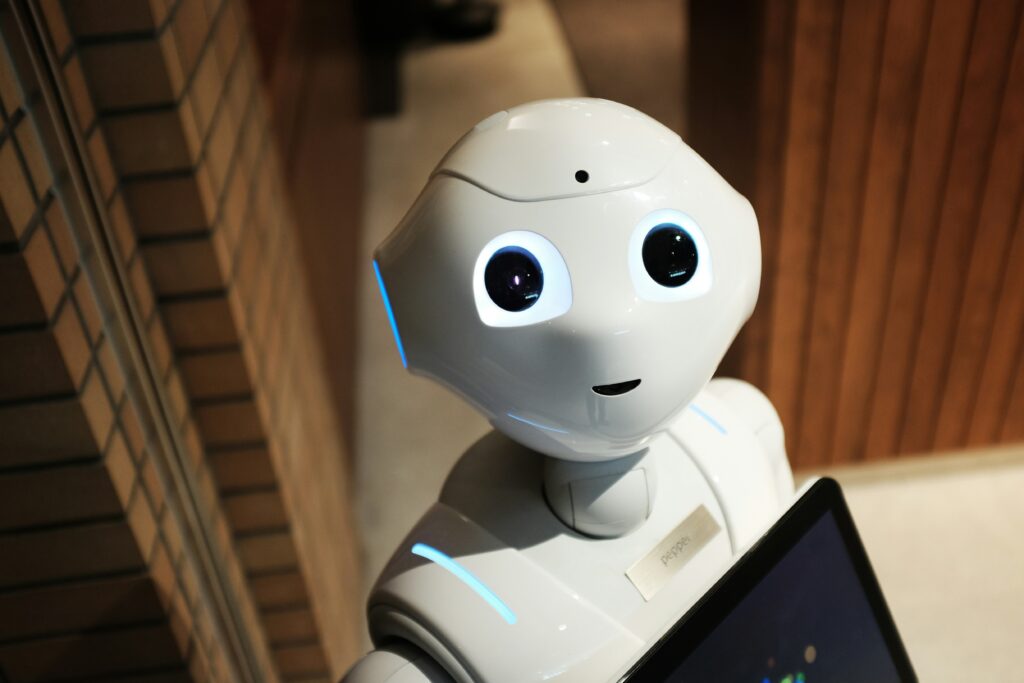
When expressive humanoid robots are awkward, people become wary – new brain study
Photo by Alex Knight on Unsplash. By Hasan Ayaz, Drexel University; Ewart J. de Visser, United States Air Force Academy; Frank Krueger, George Mason University,…
Beyond Relative Geometry: Metric-Aware Geometry Perception for Robotics
arXiv:2608.27497v1 Announce Type: new Abstract: Recent embodied models increasingly leverage geometric representations to improve spatial reasoning and robotic …
Remote Human and Robot Interaction for Greenhouse Gardening Using Virtual Reality
arXiv:2608.27545v1 Announce Type: new Abstract: This study evaluates the effectiveness of remote human-robot interaction using virtual reality for leaf inspecti…
Beyond Data Scaling: Representation-Centric Continued Pre-training for Vision-Language-Action Models
arXiv:2608.27550v1 Announce Type: new Abstract: Scaling robot data is crucial for building generalist Vision-Language-Action (VLA) models, yet robot trajectorie…
Stay Seated: Learning Omnidirectional Humanoid Locomotion on a Passive Mobile Chair with Casters
arXiv:2608.28090v1 Announce Type: new Abstract: Humanoid robots with quasi-direct-drive actuators continuously generate joint torque while standing, whereas sea…
Probabilistic Multi-Robot Gas Source Localization with Uncalibrated Sensors: A Distributed Estimation Approach
arXiv:2608.28214v1 Announce Type: new Abstract: Estimating environmental states with multi-robot systems becomes particularly challenging when robots are equipp…
Training-free Suction Grasp Detection for Deformed Aseptic Cartons Using Vision-Language Models and Geometric Surface Scoring
arXiv:2608.28246v1 Announce Type: new Abstract: Robotic sorting of recyclable waste is challenging due to the deformable and geometrically inconsistent nature o…
MaCoPlanner: LLM-Assisted Manual-Compiled Task Planning with Proactive Safety Verification for Robotic Industrial Panel Operation
arXiv:2608.28300v1 Announce Type: new Abstract: Robotic industrial panel operation requires not only accurate control localization but also compliance with oper…
ChainSplat: A Physics-Inspired Screw-Theoretic Model for Learning Deformable Linear Object Dynamics from Multi-View RGB Videos
arXiv:2608.28570v1 Announce Type: new Abstract: Identifying the underlying dynamics and 3D geometry of deformable linear objects (DLOs), such as cables, ropes, …
LUCID: An Agentic AI Framework on Digital-Twin in the Loop for QoS-Guaranteeing Robotic Control
arXiv:2608.28437v1 Announce Type: cross Abstract: Cloud robotics relies on the timely uplink of high-volume sensing streams, yet dynamic environments continuall…
AcrossVAM1.0: Particle World Modeling for Text-Assisted Robot Video Prediction
arXiv:2608.28491v1 Announce Type: cross Abstract: Predicting robot videos requires both precise motion reasoning and preservation of high-frequency appearance, …
When Robots Mishear Us: Mapping the Safety Risks of Voice-Controlled Embodied AI
arXiv:2608.28518v1 Announce Type: cross Abstract: We investigate whether automatic speech recognition (ASR) errors in user input can lead to unsafe outputs from…
SIMPNet: Spatial-Informed Motion Planning Network
arXiv:2408.12831v2 Announce Type: replace Abstract: Current robotic manipulators require fast and efficient motion-planning algorithms to operate in cluttered e…
Differentiable Dynamics and Fast Simulation of Continuous Elastic Robotic Fish
arXiv:2509.16145v3 Announce Type: replace Abstract: Body flexibility plays a critical role in fish-like swimming, as the spatial distribution of stiffness gover…