News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesFlowCorrect: Efficient Interactive Correction of Generative Flow Policies for Robotic Manipulation
arXiv:2602.22056v3 Announce Type: replace Abstract: Generative manipulation policies can fail catastrophically under deployment-time distribution shift, yet man…
Benefits of Low-Cost Bio-Inspiration in the Age of Overparametrization
arXiv:2604.20365v2 Announce Type: replace Abstract: While Central Pattern Generators (CPGs) and Multi-Layer Perceptrons (MLP) are widely used paradigms in robot…
Ethical Asymmetry in Human-Robot Interaction - An Empirical Test of Sparrow's Hypothesis
arXiv:2602.02745v2 Announce Type: replace-cross Abstract: The ethics of human-robot interaction (HRI) have been discussed extensively based on three traditional…
Linear Temporal Logic Translation via Human-Inspired Self-Constrained Reasoning for Robot Task Specification
arXiv:2608.28435v1 Announce Type: new Abstract: Many robotic tasks are temporally extended and demand precise specifications of subgoals, constraints, and their…
Cooperative Risk-Aware Exploration in Heterogeneous Multi-Robot Systems Using Algorithmic Altruism
arXiv:2608.28409v1 Announce Type: new Abstract: Multi-robot systems are well-positioned for exploration in hazardous environments, but effective deployment requ…
CAVE-NAV: VLM-Based Autonomous 3D Navigation in Underwater Cave Environments
arXiv:2608.27793v1 Announce Type: new Abstract: Autonomous navigation in underwater cave environments is essential for search-and-rescue operations, scientific …
One year in a forest: Analyzing the challenges of autonomous navigation in subarctic environments
arXiv:2608.27628v1 Announce Type: new Abstract: Subarctic regions have the potential to see increased deployment of autonomous robots in applications including …
OceanGym: A Benchmark Environment for Underwater Embodied Agents
arXiv:2509.26536v3 Announce Type: replace-cross Abstract: We introduce OceanGym, the first comprehensive benchmark for ocean underwater embodied agents, designe…
Reasoning models do not yet follow their reasoning in autonomous driving: The KITScenes LongTail Dataset
arXiv:2603.23607v3 Announce Type: replace-cross Abstract: Handling rare events is the central open challenge in autonomous driving. Reasoning models, which gene…
Object Reconstruction under Occlusion with Generative Priors and Contact-induced Constraints
arXiv:2512.05079v2 Announce Type: replace-cross Abstract: Object geometry is key information for robot manipulation. Yet, object reconstruction is a challenging…
Transformer-Based Autonomous Driving Models and Deployment-Oriented Compression: A Survey
arXiv:2304.10891v4 Announce Type: replace-cross Abstract: Transformer-based models are becoming a central paradigm in autonomous driving because they can captur…
Receding Fixed-Horizon Optimization for Near-Time-Optimal Trajectory Planning and Control
arXiv:2503.11072v4 Announce Type: replace Abstract: Time-optimal trajectory planning and control is central for autonomous vehicles, yet its application and rea…
PanelShield: Verifiable Closed-Loop Safe Planning for Robotic Industrial Panel Operation
arXiv:2608.28305v1 Announce Type: new Abstract: Industrial panel operation is knowledge-intensive and safety-critical. Beyond control recognition and action gen…
PAMoR: Parameterized Affective Motion Generation in Real Time for Humanoid Robots
arXiv:2608.28213v1 Announce Type: new Abstract: People read a humanoid robot's motion in social settings not only for the action performed but for the affect co…
From Small Talk to Rapport: Exploring Robot Self-Disclosure in Collaborative Tasks
arXiv:2608.28154v1 Announce Type: new Abstract: People naturally chat while collaborating and share personal information (i.e., self-disclose) to build rapport …
PHR-VLA: Planning Horizon Reasoning for Vision-Language-Action Models
arXiv:2608.27609v1 Announce Type: new Abstract: Vision-language-action models (VLAs) have shown strong promise for general-purpose robotic manipulation by mappi…
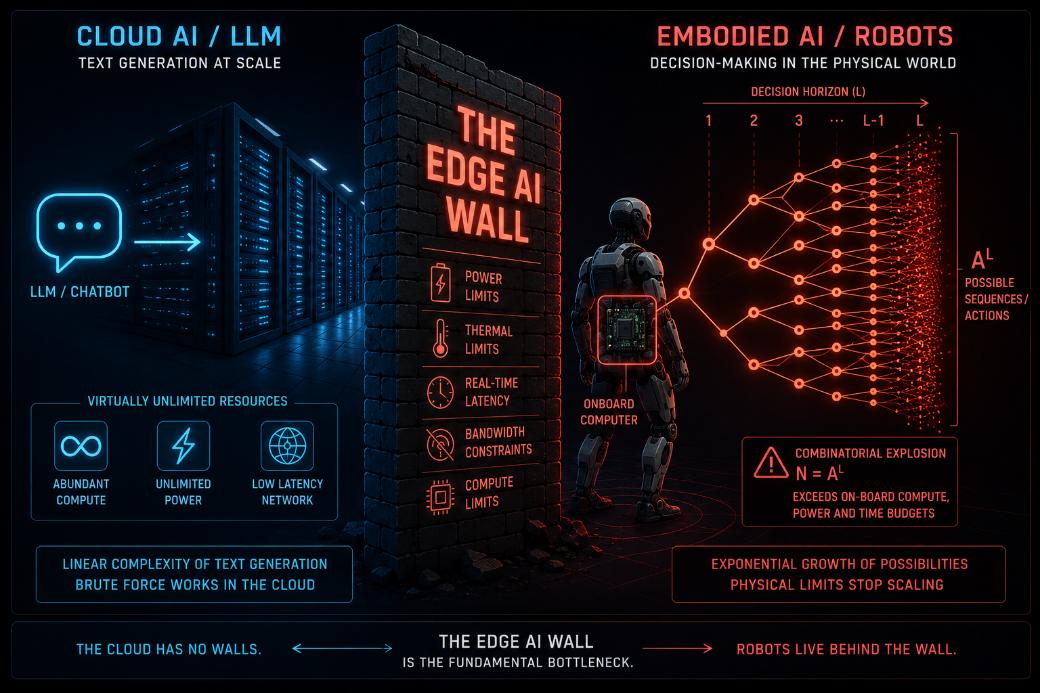
The edge AI wall: Why embodied AI requires new mathematics
Computational overload is not a bug of a specific planner, but an edge AI wall limiting physical and embodied AI. The post The edge AI wall: Why embodied AI req…
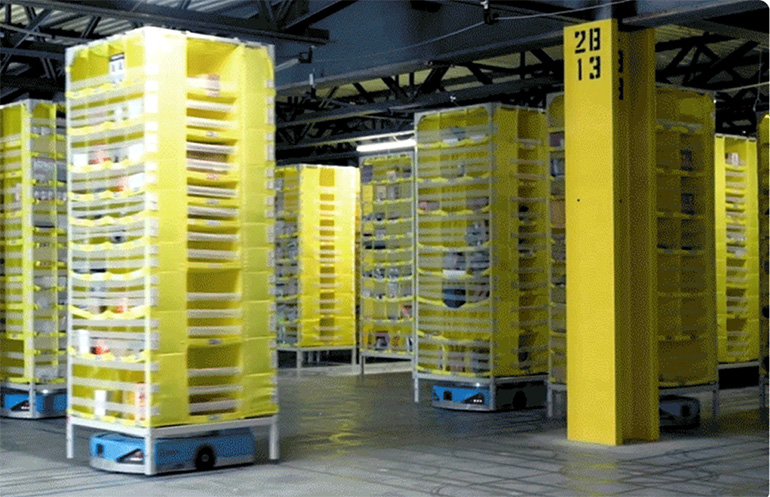
The differences between decentralized and centralized power in swarm robotics
A robotic swarm typically relies on centralized or decentralized power management, but a hybrid approach could offer the best of both. The post The differences …
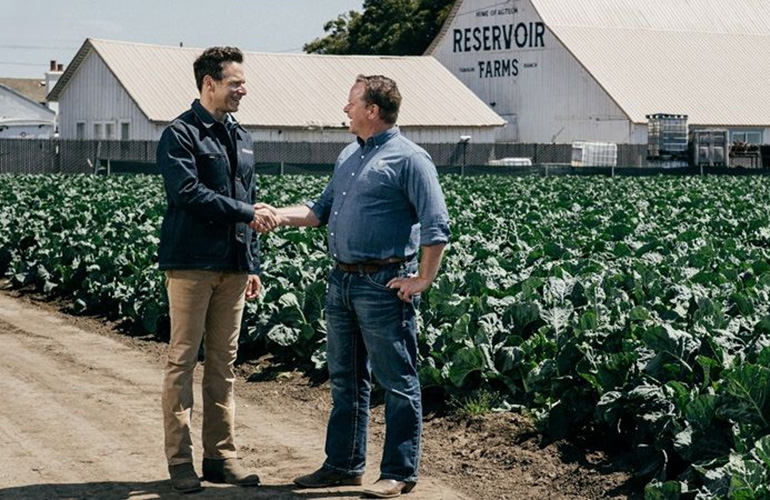
Deere faces headwinds in Q3 update and announces Reservoir R&D partnership
Deere beats Q3 expectations, raises guidance, and partners with Reservoir on a $10 million agtech AI initiative. The post Deere faces headwinds in Q3 update and…
From teach and repeat to SelfPath AI: The next robotics leap
John Black, chief technology officer at Brian Corp, shares insights on how to build trust for robotics fleets and AI. The post From teach and repeat to SelfPath…
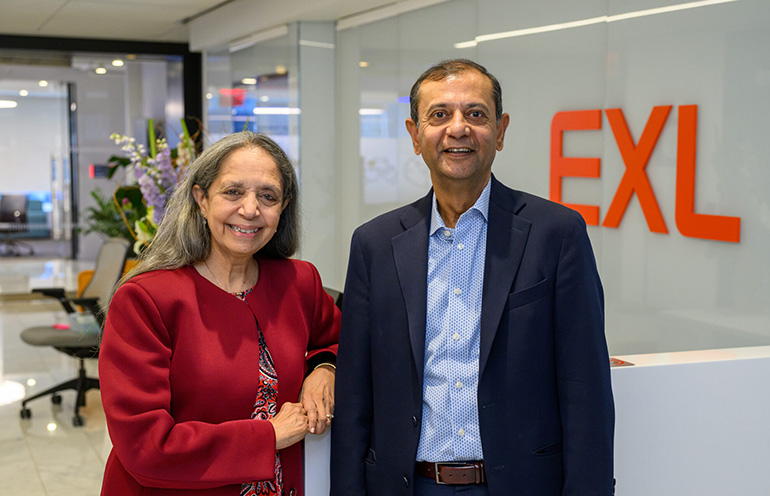
EXL acquires physical AI model developer iMerit
The EXL and iMerit executives explain how their companies' combined expertise and platforms will help developers with reliable physical AI. The post EXL acquire…
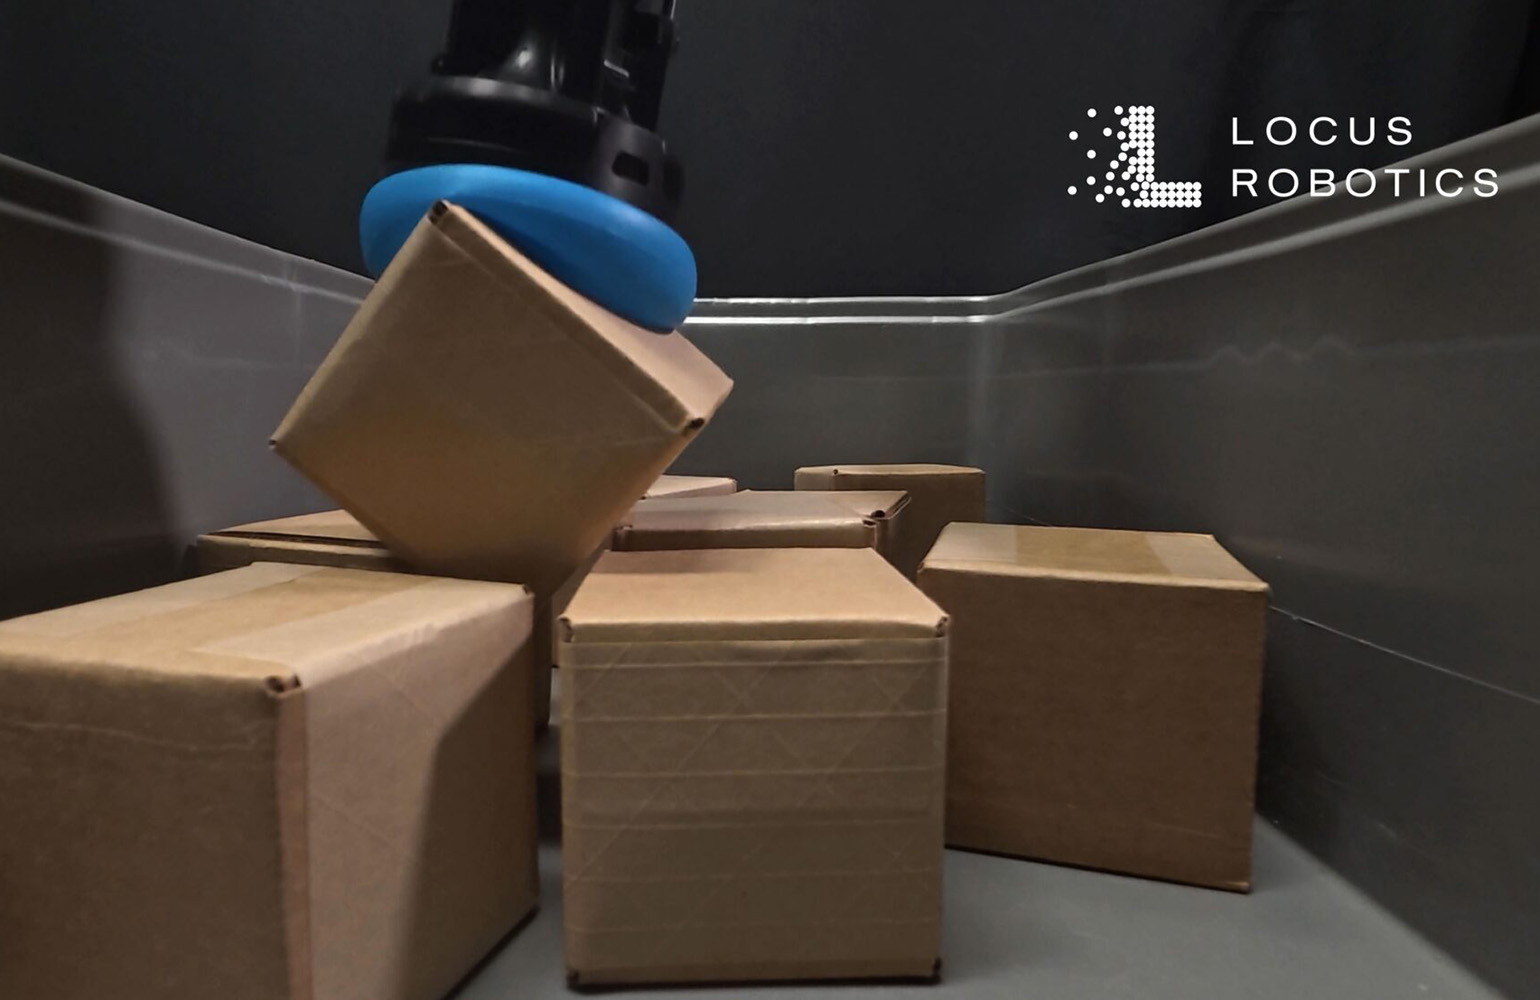
How Locus is getting a grasp on one of robotics biggest challenges: manipulation
Locus Robotics recently acquired Nexera Robotics, which create unique soft picking technology, bolstering its manipulation capabilities. The post How Locus is g…
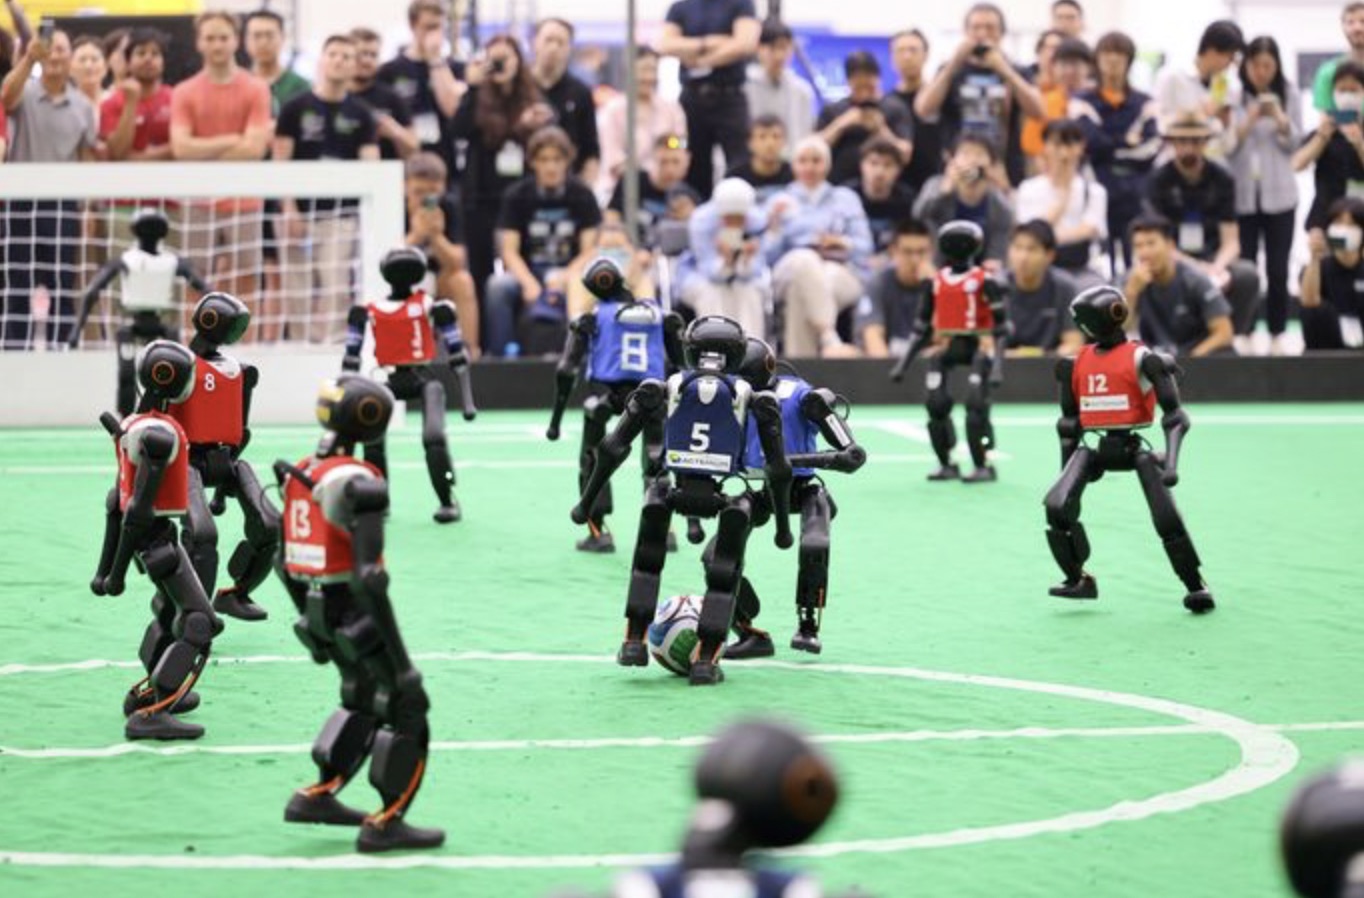
First 11 vs 11 humanoid soccer game played at RoboCup 2026
Action from the 11 vs 11 humanoid match at RoboCup 2026. Photo credit: RoboCup Federation. RoboCup 2026 saw history made, as two teams of 11 humanoids took to t…
Contact-Aided Factor-Graph Localization for Underwater Sampling
arXiv:2608.26932v1 Announce Type: new Abstract: Accurate state estimation for autonomous underwater vehicles performing close-range seafloor sampling remains ch…
GRAFT: Grounded and Efficient Online Reinforcement Adaptation for Fine-Grained Robot Manipulation
arXiv:2608.27079v1 Announce Type: new Abstract: Pretrained vision-language-action (VLA) policies provide strong priors for robot manipulation, yet adapting them…
STEP: State-Aware Task Estimation and Planning with Multi-Modal LLMs for Human-Robot Collaboration
arXiv:2608.27225v1 Announce Type: new Abstract: Effective human-robot collaboration in industrial settings requires robots to understand human intentions and as…
FlashVLA: Streaming Action Decoding for Fast and Asynchronous VLA Inference
arXiv:2608.27384v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models are increasingly promising for robotic manipulation, yet their real-world de…
No Plan, Yet Human: A Reactive Robotics Model Predicts Human Planning Failures on a Clinical Task
arXiv:2605.16514v2 Announce Type: replace Abstract: Understanding why some sequential planning problems are harder than others requires models that go beyond av…
MOMO: A framework for seamless physical, verbal, and graphical robot skill learning and adaptation
arXiv:2604.20468v3 Announce Type: replace Abstract: Industrial robot applications require increasingly flexible systems that non-expert users can easily adapt f…
Barrier Function Conformal Safety Clearance Certification with CVaR for Driving Trajectory Selection
arXiv:2608.26533v1 Announce Type: cross Abstract: Autonomous driving motion planners generate and select candidate trajectories while accounting for interaction…