News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesSSI-Policy: Learning Structured Scene Interfaces for Vision-Language Robotic Manipulation
arXiv:2606.26800v1 Announce Type: new Abstract: Real-world robotic manipulation demands spatial grounding, task-aware reasoning, and precise control. Learning s…
Rethinking Training & Inference for Forecasting: Linking Winner-Take-All back to GMMs
arXiv:2606.26424v1 Announce Type: cross Abstract: Trajectory forecasting for autonomous driving has advanced rapidly, yet representative models often produce un…
RMTL: Reinforced Micro-task Learning for Long-Horizon Manipulation with VLM Rewards
arXiv:2606.26175v1 Announce Type: new Abstract: Reinforcement learning (RL) for robotic manipulation often requires manually designing a dense reward function, …
RouterVLA: Turning Smoke Tests into Supervision for Heterogeneous VLA Selection
arXiv:2606.27355v1 Announce Type: new Abstract: We study whether pre-deployment evaluation rollouts can be reused to supervise policy selection. Robot teams rou…
Bridging Handheld and Teleoperated Supervision for Contact-Rich Manipulation via State-Gated Experts
arXiv:2606.26603v1 Announce Type: new Abstract: Handheld data collection systems, such as the Universal Manipulation Interface (UMI), enable scalable data colle…
RobOralScan: Learning Active Intraoral Scanning for Robotic Dental Reconstruction
arXiv:2606.26955v1 Announce Type: new Abstract: Intraoral scanning is widely used for digital optical impressions in prosthodontic, implant, and orthodontic tre…
PhysReflect-VLA: Physical Feasibility and Self-Reflective Regulation for Reliable Vision-Language-Action Policies
arXiv:2606.27146v1 Announce Type: new Abstract: Long-horizon robotic manipulation is highly sensitive to physically infeasible transitions, contact-induced dist…
World Action Models Enable Continual Imitation Learning with Recurrent Generative Replays
arXiv:2606.27374v1 Announce Type: new Abstract: Going beyond predicting robot actions, World Action Models (WAMs) can also generate future visual observations. …
Humanoid-DART: Humanoid Loco-Manipulation using Diffusion-guided Augmentation through Relabeling and Tracking
arXiv:2606.26855v1 Announce Type: new Abstract: Imitating human demonstrations has emerged as a dominant paradigm for learning humanoid loco-manipulation polici…
RelAfford6D: Relational 6D Affordance Graphs for Constraint-Driven Robotic Manipulation
arXiv:2606.27036v1 Announce Type: new Abstract: Bridging abstract semantics and precise physical control remains a fundamental challenge in open-world robotic m…
PlanRL: A Trajectory Planning Architecture for Reinforcement Learning-based Driving Experts
arXiv:2606.26858v1 Announce Type: new Abstract: Reinforcement learning (RL) has become a prominent framework for developing driving experts in autonomous vehicl…
WatchAct: A Benchmark for Behavior-Grounded Robot Manipulation
arXiv:2606.26443v1 Announce Type: new Abstract: A robot working alongside people must reason about what they have done, in what order, and with what intent. Vid…
CogAD: Cognitive-Hierarchy Guided End-to-End Autonomous Driving
arXiv:2505.21581v4 Announce Type: replace Abstract: While end-to-end autonomous driving has advanced significantly, prevailing methods remain fundamentally misa…
ForesightSafety-VLA: A Unified Diagnostic Safety Benchmark for Vision-Language-Action Models
arXiv:2606.27079v1 Announce Type: new Abstract: In embodied intelligence, safety is a prerequisite for reliable robot deployment in the physical world. Current …
Hardware Design for Table Tennis Robot Capable of Beating Professional Players
arXiv:2606.26643v1 Announce Type: new Abstract: This paper focuses on the hardware specifications required for a table tennis robot to beat professional players…
E-TTS: A New Embodied Test-Time Scaling Framework for Robotic Manipulation
arXiv:2606.27268v1 Announce Type: new Abstract: Recently, a few works have made early attempts to study test-time scaling for embodied tasks. However, two major…
Bridging Performance and Generalization in Reinforcement Learning for Agile Flight
arXiv:2606.27348v1 Announce Type: new Abstract: Autonomous drone racing is a fundamentally challenging regime for autonomous aerial robots, requiring time-optim…
OmniRobotHome: A Multi-Camera Home Platform for Real-Time Human-Robot Interaction
arXiv:2604.28197v2 Announce Type: replace Abstract: Robots in homes must continuously sense the people around them, yet most prior work relies on limited or off…
Real-Time Safety Evaluation of Human Arm Operations Using a Wrist-Mounted IMU with PSM System
arXiv:2502.09241v2 Announce Type: replace Abstract: This paper presents a novel approach to real-time safety monitoring in human-robot collaborative manufacturi…
LAMP: Lane-Aligned Motion Primitives for Feasible Trajectory Prediction
arXiv:2606.26661v1 Announce Type: new Abstract: Motion forecasting is essential for autonomous driving systems to enable safe decision-making and planning in co…
Reinforcement Learning Enables Autonomous Microrobot Navigation and Intervention in Simulated Blood Capillaries
arXiv:2606.26154v1 Announce Type: new Abstract: Autonomous microrobots navigating biological vasculature could enable targeted drug delivery and thrombolysis, y…
History-Conditioned Spatio-Temporal Visual Token Pruning for Efficient Vision-Language Navigation
arXiv:2603.06480v2 Announce Type: replace Abstract: Vision-Language Navigation (VLN) enables robots to follow natural-language instructions in visually grounded…
Unsupervised Memory-Enhanced Video Transformers: Obstacle Detection for Autonomous Agricultural Rover
arXiv:2606.26151v1 Announce Type: new Abstract: While autonomous rovers have become indispensable to precision farming, achieving consistent operational safety …
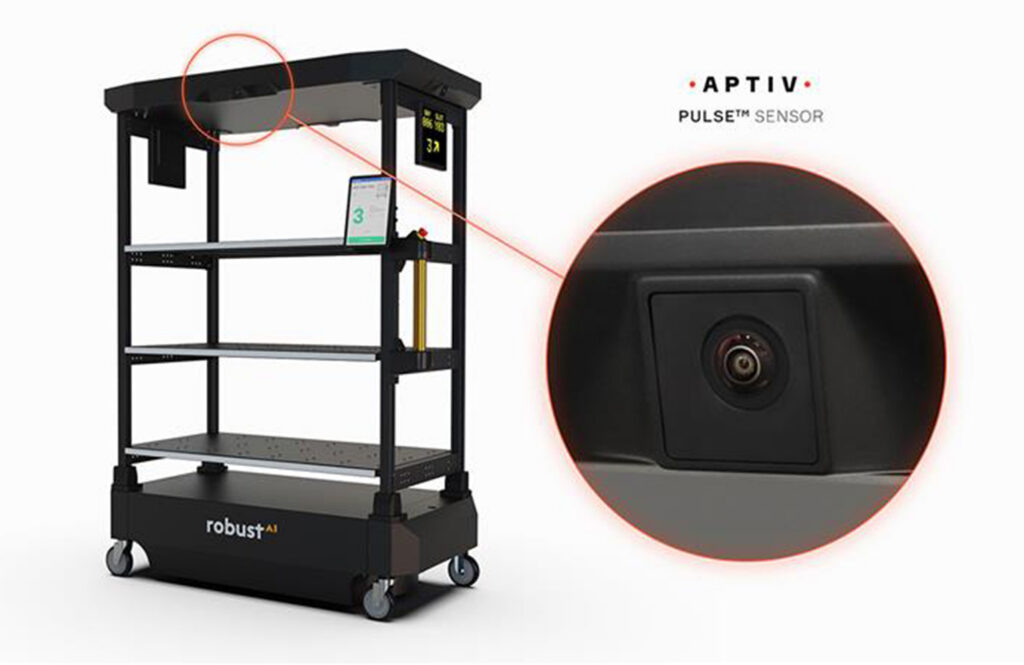
Robust.AI chooses Aptiv PULSE sensor for Gen 3 Carter mobile robot
Aptiv provides sensor fusion from radar and vision using AI to enable Robust.AI's Carter robot to move safely around people. The post Robust.AI chooses Aptiv PU…
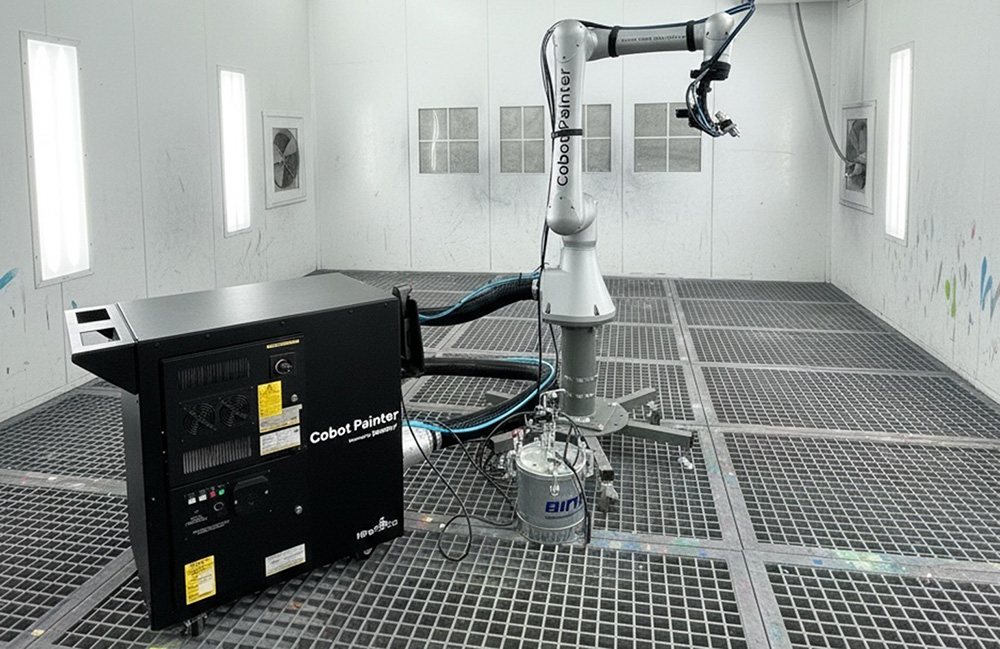
Hirebotics offers no-code, explosion-proof cobot for painting
Hirebotics' Cobot Painter supports stationary painting, with parts placed in a paint booth where robots perform all spraying operations. The post Hirebotics off…
ARM Institute expands RoboticsCareer.org into physical AI
RoboticsCareer.org now lists the growing job opportunities in physical AI and enables employers to connect to qualified talent. The post ARM Institute expands R…
ForceBand: Learning Forceful Manipulation with sEMG
arXiv:2606.26093v1 Announce Type: new Abstract: Human demonstrations are a scalable data source for learning robot manipulation policies. However, common source…
RARM: Confidence-Gated Progress Reward Modeling for RL in Manipulation
arXiv:2606.22027v2 Announce Type: replace Abstract: Reinforcement learning for robot manipulation is often bottlenecked by reward design, especially in long-hor…
Learning Robot Visual Navigation in Crowds via Intention-Aware Scene Representations
arXiv:2606.26047v1 Announce Type: new Abstract: Robot crowd navigation requires the ability to infer human intentions while accounting for the structural constr…
RoboRouter: Training-Free Policy Routing for Robotic Manipulation
arXiv:2603.07892v4 Announce Type: replace Abstract: Research on robotic manipulation has developed a diverse set of policy paradigms, including vision-language-…