News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesMobileManiBench: Simplifying Model Verification for Mobile Manipulation
arXiv:2602.05233v2 Announce Type: replace Abstract: Vision-language-action models have advanced robotic manipulation but remain constrained by reliance on the l…
Drop-Then-Recovery: How Redundant Are Vision-Language-Action Models?
arXiv:2606.27755v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models enable instruction-driven robotic manipulation, but they inherit oversized l…
S$^2$-VLA: State-Space Guided Vision-Language-Action Models for Long-Horizon Manipulation
arXiv:2606.27872v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have demonstrated strong capabilities in robotic manipulation, but their per…
DIM-WAM: World-Action Modeling with Diverse Historical Event Memory
arXiv:2606.27677v1 Announce Type: new Abstract: World-action models have shown promising robot-manipulation performance by jointly predicting future visual stat…
PhysisForcing: Physics Reinforced World Simulator for Robotic Manipulation
arXiv:2606.28128v1 Announce Type: cross Abstract: Video generation models have emerged as a promising paradigm for embodied world simulation. However, both gene…
Spacecraft Fiducial Marker for Autonomous Rendezvous, Proximity Operations, and Docking
arXiv:2606.27566v1 Announce Type: new Abstract: Robotic operations in space are challenging due to the harsh environment and the high cost of failure. Fiducial …
VLM-Guided Visual Place Recognition for Planet-Scale Geo-Localization
arXiv:2507.17455v2 Announce Type: replace-cross Abstract: Geo-localization from a single image at planet scale (essentially an advanced or extreme version of th…
DIVER: Reinforced Diffusion Breaks Imitation Bottlenecks in End-to-End Autonomous Driving
arXiv:2507.04049v5 Announce Type: replace-cross Abstract: Most end-to-end autonomous driving methods rely on imitation learning from single expert demonstration…
Image-based Geo-localization for Robotics: Are Black-box Vision-Language Models there yet?
arXiv:2501.16947v2 Announce Type: replace-cross Abstract: The advances in Vision-Language models (VLMs) offer exciting opportunities for robotic applications in…
Learn Structure, Adapt on the Fly: Multi-Scale Residual Learning and Online Adaptation for Aerial Manipulators
arXiv:2603.11638v2 Announce Type: replace Abstract: Autonomous Aerial Manipulators (AAMs) are inherently coupled, nonlinear systems that exhibit nonstationary a…
PA-BiCoop: A Primary-Auxiliary Cooperative Framework for General Bimanual Manipulation
arXiv:2606.28192v1 Announce Type: new Abstract: Bimanual manipulation is essential for advanced robotic systems because it offers higher efficiency and flexibil…
Physics-Guided Robotic Radiation Source Localization along Arbitrary Measurement Paths in Unstructured Environments
arXiv:2606.27624v1 Announce Type: new Abstract: Using robots to estimate the location of the radiation source is an effective way to improve efficiency and safe…
LXD-SLAM: LiDAR+X Dense SLAM with $\sum_{i=0}^{5}C_5^i$ Configurable Sensor Combinations
arXiv:2606.27811v1 Announce Type: new Abstract: Simultaneous Localization and Mapping (SLAM) is essential for autonomous systems, yet achieving reliable, global…
When Multi-Robot Systems Meet Agentic AI:Towards Embodied Collective Intelligence
arXiv:2606.27929v1 Announce Type: new Abstract: Embodied AI is increasingly becoming agentic, shifting robots from perception--control pipelines towards closed-…
SceneBot: Contact-Prompted General Humanoid Whole Body Tracking with Scene-Interaction
arXiv:2606.27581v1 Announce Type: new Abstract: Current humanoid reinforcement-learning policies excel at free-space motions but struggle with contact-rich task…
Point of View: How Perspective Affects Perceived Robot Sociability
arXiv:2603.28272v2 Announce Type: replace Abstract: Ensuring that robot navigation is safe and socially acceptable is crucial for comfortable human-robot intera…
Booster Lab: A Data-Centric Pipeline for Learning Deployable Humanoid Locomotion Policies
arXiv:2606.27813v1 Announce Type: new Abstract: Humanoid robot motion learning requires not only task-oriented control policies but also physically feasible and…
A Primer on SO(3) Action Representations in Deep Reinforcement Learning
arXiv:2510.11103v3 Announce Type: replace Abstract: Many robotic control tasks require policies to act on orientations, yet the geometry of SO(3) makes this non…
P-ARC: Exploiting Subproblem Independence for Parallel Multi-Robot Motion Planning
arXiv:2606.27625v1 Announce Type: new Abstract: This paper presents Parallel ARC (P-ARC), a parallel variant of the Adaptive Robot Coordination (ARC) approach t…
Characterizing Driver Interactions with Autonomous Vehicles via Response Maps
arXiv:2606.27656v1 Announce Type: cross Abstract: Understanding human responses to autonomous vehicle (AV) behaviors is essential for socially aware interaction…
LocalNav: Distilling Frontier VLMs and Embodied RL for On-Device Object Goal Navigation
arXiv:2606.27871v1 Announce Type: new Abstract: Vision Language Models (VLMs) have emerged in the robotic domain as a powerful tool that enables environmental p…
AO-ARC: Almost-Surely Asymptotically Optimal Multi-Robot Motion Planning with ARC
arXiv:2606.27495v1 Announce Type: new Abstract: We present AO-ARC, an anytime multi-robot motion planning (MRMP) method that achieves initial solution times on …
Direct Action-Head Injection of A Grounded 3D Point Unlocks Spatial and Task Generalization
arXiv:2606.27663v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models leverage large-scale vision-language pretraining for flexible robot manipula…
Web2Grasp: Learning Functional Grasps from Web Images of Hand-Object Interactions
arXiv:2505.05517v3 Announce Type: replace-cross Abstract: Functional grasping is essential for enabling dexterous multi-finger robot hands to manipulate objects…
Swarm sign language: motion-based communication between drones
arXiv:2606.27883v1 Announce Type: new Abstract: In stealth-constrained swarm robotics, visual communication provides a critical alternative to active radio tran…
SimFoundry: Modular and Automated Scene Generation for Policy Learning and Evaluation
arXiv:2606.28276v1 Announce Type: new Abstract: Training and evaluating robot policies in the real world is costly and difficult to scale. We introduce SimFound…
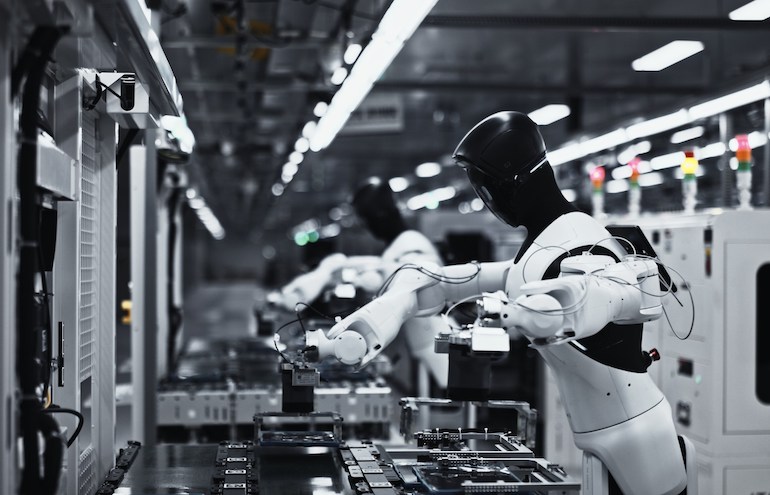
AGIBOT produces 15,000th robot, marking a milestone in embodied AI deployment
AGIBOT has rolled out 15,000 wheeled semi-humanoid robots as it moves from embodied AI from development and production to deployment. The post AGIBOT produces 1…
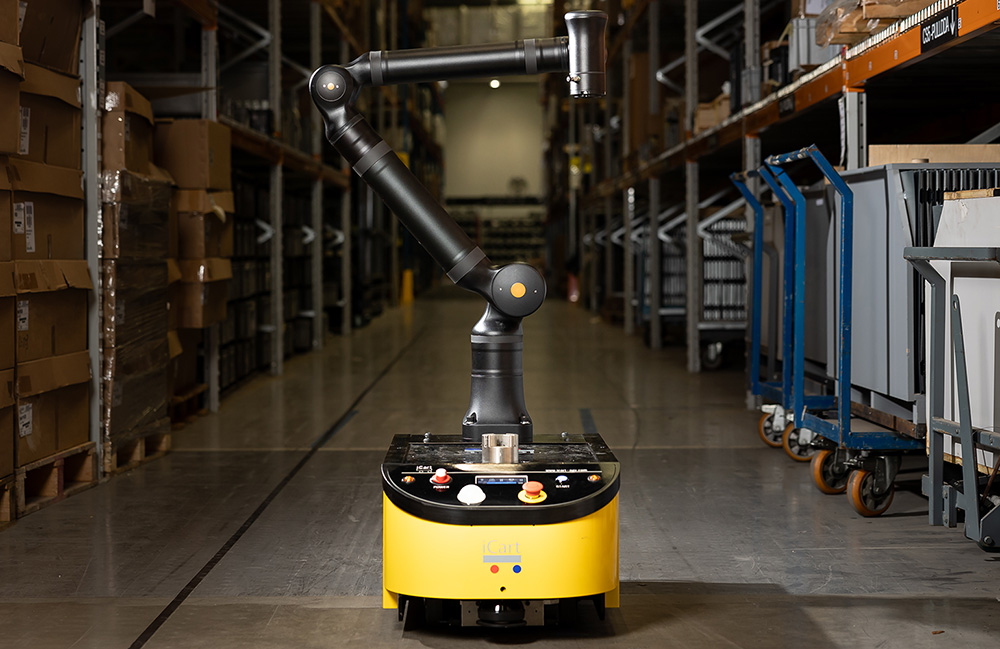
How compact cobot integration enhances autonomous mobile robot applications
Cobots are quickly shaping the future of warehousing, with their use rising 10-fold from 2018 to 2025, Kassow said. The post How compact cobot integration enhan…
We know how to build smarter robots. Now, we need to learn smarter ways to test them
Atharv Kolhar, a staff test automation engineer at Figure AI, says the robotics industry needs a testing philosophy that scales alongside autonomy. The post We …
General Intuition raises $320M to use video game data to train robots
General Intuition is using video game clips with embedded action labels to speed up AI training for robotics. The post General Intuition raises $320M to use vid…