News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 stories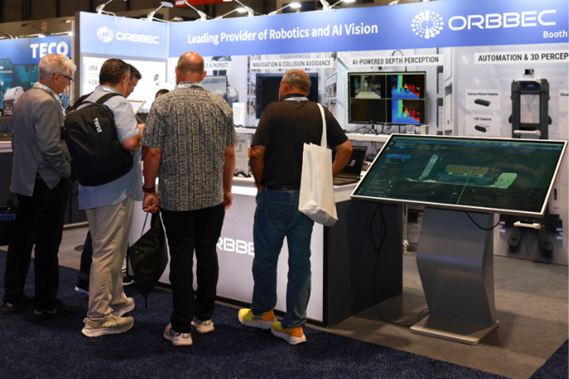
Orbbec shows AI-powered vision systems at Automate 2026
Orbbec presented industrial-grade 3D cameras for challenging automation scenarios, as well as AI integration for enhanced robotic perception. The post Orbbec sh…
Robot Talk Episode 162 – The robot doctor will see you now
Since the first robot-assisted surgery was performed, over 40 years ago, major advances in robotics, computer vision and artificial intelligence have fundamenta…
Monte Carlo Tree Search with Tensor Factorization for Optimization Problems in Robotics
arXiv:2507.04949v3 Announce Type: replace Abstract: Many robotic tasks, such as inverse kinematics, motion planning, and contact-rich manipulation, can be formu…
A System for Fast, Resilient, and Adaptable Loco-Manipulation Behaviors on Humanoid Robots
arXiv:2606.26425v1 Announce Type: new Abstract: Humanoid robots could take on physically demanding, hazardous, and repetitive work in spaces built for humans. H…
FC-Vision: Real-Time Visibility-Aware Replanning for Occlusion-Free Aerial Target Structure Scanning in Unknown Environments
arXiv:2602.13720v2 Announce Type: replace Abstract: Autonomous aerial scanning of target structures is crucial for practical applications, requiring online adap…
CycleRL: Sim-to-Real Deep Reinforcement Learning for Robust Autonomous Bicycle Control
arXiv:2603.15013v3 Announce Type: replace Abstract: Autonomous bicycles offer a promising agile solution for urban mobility and last-mile logistics. However, co…
Tactile-WAM: Touch-Aware World Action Model with Tactile Asymmetric Attention
arXiv:2606.26663v1 Announce Type: new Abstract: World Action Models (WAMs) generate actions together with predicted futures, offering a powerful interface for r…
PressMimic: Pressure-Guided Motion Capture and Control for Humanoid Robot Imitation
arXiv:2606.26741v1 Announce Type: new Abstract: Humanoid motion imitation requires not only accurate perception of human kinematics but also faithful reproducti…
VibeAct: Vibration to Actions for Contact-Rich Reactive Robot Dexterity
arXiv:2606.27344v1 Announce Type: new Abstract: Dexterous manipulation depends on contact events that are fast, local, and often visually occluded. Piezoelectri…
BAT-Nav: Budget-Aware Arbitration and Termination for Long-Horizon Semantic Navigation
arXiv:2605.16932v2 Announce Type: replace Abstract: Long-horizon semantic navigation asks a robot to localize multiple open-vocabulary targets under a finite ac…
NavIsaacLab: Generating Realistic Crowd via Parallel Robot Learning for Benchmarking Human-aware Navigation
arXiv:2606.26265v1 Announce Type: new Abstract: Robot autonomous navigation that accounts for surrounding human activities is crucial for ensuring both safety a…
How Should a Simulation-to-Reality Transfer Budget Be Spent?
arXiv:2606.22062v2 Announce Type: replace Abstract: Simulation-to-reality transfer, often called sim-to-real transfer, is a central challenge in robot learning.…
OmniContact: Chaining Meta-Skills via Contact Flow for Generalizable Humanoid Loco-Manipulation
arXiv:2606.26201v1 Announce Type: new Abstract: Learning long-horizon humanoid loco-manipulation poses a dual challenge: it requires not only the robust executi…
Racing a Wheeled Quadruped: Active Load Transfer Mitigation via Model Predictive Control
arXiv:2606.26313v1 Announce Type: new Abstract: This paper presents a hierarchical control framework using model predictive control (MPC) and reinforcement lear…
TaskNPoint: How to Teach Your Humanoid to Hit a Backhand in Minutes
arXiv:2606.26215v1 Announce Type: new Abstract: How do we learn to hit a tennis backhand? Not from a thousand hours of tennis tournaments on TV - we work with a…
Inference-Time Robot Behavior Steering through Physically-Aware Reconfiguration of Task-Structure
arXiv:2606.26588v1 Announce Type: new Abstract: A central challenge in deploying learned robot policies is inference-time behavior steering: redirecting a polic…
Improving Vision-Language-Action Model Fine-Tuning with Structured Stage and Keyframe Supervision
arXiv:2606.26801v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have shown strong potential for generalizable robotic manipulation. During f…
LiMoDE: Rethinking Lifelong Robot Manipulation from a Mixture-of-Dynamic-Experts Perspective
arXiv:2606.26183v1 Announce Type: new Abstract: Building a generalist robot that can leverage prior knowledge for continuous task adaptation remains a significa…
RoboTales: ROBOTic Anthropomorphic LEarning Systems
arXiv:2606.26213v1 Announce Type: new Abstract: RoboTales is a low-cost robotic storytelling system that animates narratives using expressive sock puppetry. Imp…
LA4VLA: Learning to Act without Seeing via Language-Action Pretraining
arXiv:2606.27295v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models are commonly pretrained on robot demonstrations by jointly mapping visual ob…
Visual-Language-Guided Task Planning for Horticultural Robots
arXiv:2601.11906v2 Announce Type: replace Abstract: Crop monitoring is essential for precision agriculture, but current systems lack high-level reasoning. We in…
Ordinal Neural Collapse as a Representation Prior for Visual Navigation
arXiv:2606.26839v1 Announce Type: new Abstract: Learning robust navigation policies directly from visual observations remains a fundamental challenge in vision-…
HumanoidUMI: Bridging Robot-Free Demonstrations and Humanoid Whole-Body Manipulation
arXiv:2606.27239v1 Announce Type: new Abstract: High-quality demonstration data are essential for humanoid robot skill learning, especially for whole-body behav…
Continual Robot Policy Learning via Variational Neural Dynamics
arXiv:2606.27353v1 Announce Type: new Abstract: Robots deployed in the real world rarely operate under a single fixed dynamics model: wind changes, payloads var…
PAMAE: Phase-Aware-MoE Action Experts Towards Reliable Flow-Matching Vision-Language-Action Policies
arXiv:2606.27144v1 Announce Type: new Abstract: Reliable action generation for multi-stage robotic manipulation remains challenging for Vision-Language-Action (…
Proposal-Conditioned Latent Diffusion for Closed-Loop Traffic Scenario Generation
arXiv:2606.27123v1 Announce Type: new Abstract: Closed-loop traffic simulation remains challenging because it must generate interactive multi-agent behaviors th…
Advancing Omnimodal Embodied Agents from Isolated Skills to Everyday Physical Autonomy
arXiv:2606.27251v1 Announce Type: new Abstract: Building persistent embodied agents in unstructured environments demands unified orchestration of heterogeneous …
Charting the Growth of Social-Physical HRI (spHRI): A Systematic Review Pipeline Augmented by Small Language Models
arXiv:2606.26382v1 Announce Type: cross Abstract: Social-physical human-robot interaction (spHRI) has grown rapidly across robotics, human-computer interaction,…
A Closed-Form 4-DoF Inter-Robot Pose Estimator using Bearing-only Measurements
arXiv:2606.26616v1 Announce Type: new Abstract: Bearing-odometry-based cooperative localization has attracted increasing research interest due to its minimal in…
OctoSense: Self-Supervised Learning for Multimodal Robot Perception
arXiv:2606.27317v1 Announce Type: cross Abstract: We present OctoSense, an open-source sensor platform with stereo RGB and event cameras, LiDAR, a thermal camer…