News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesASSCG: Just-Right Gating over Chattering for Fast-Slow LLM Planning in Autonomous Driving
arXiv:2606.25509v1 Announce Type: new Abstract: Large language models (LLMs) can improve autonomous driving planning but are costly to query online, and existin…
ARTOO-DARTU: Studying AR-HRC With AR Obstruction Mitigation During a Warehouse Task
arXiv:2606.25202v1 Announce Type: cross Abstract: Human-robot collaboration (HRC) often requires robot intentions and internal states to be conveyed to users fo…
AI Coaching for Accelerating Human Skill Development with Reinforcement Learning
arXiv:2606.25337v1 Announce Type: new Abstract: AI copilots can substantially boost human performance through shared control, but excessive assistance can induc…
One Body, Two Minds: Variable Autonomy Approach for a Co-embodied Robotic Hand
arXiv:2606.25575v1 Announce Type: new Abstract: Assistive robotic systems face a fundamental trade-off: fully autonomous systems lack user agency, while fully u…
Learning Action Priors for Cross-embodiment Robot Manipulation
arXiv:2606.26095v1 Announce Type: new Abstract: Most Vision-Language-Action (VLA) models build on a Vision-Language Model (VLM) backbone by attaching an action …
MANGO: Automated Multi-Agent Test Oracle Generation for Vision-Language-Action Models
arXiv:2606.24815v1 Announce Type: cross Abstract: Vision-Language-Action (VLA) models are emerging robotic control systems that integrate perception, language u…
GROVE: Grounded Pedestrian Simulation via Natural Language for Interactive Social Robot Navigation
arXiv:2606.25504v1 Announce Type: new Abstract: Pedestrian simulation is a critical component for training and deploying social robot navigation approaches, yet…
WOLF-VLA: Whole-Body Humanoid Optimal Locomotion Framework for Vision-Language-Action Learning
arXiv:2606.25591v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have recently demonstrated strong generalization in robotic manipulation, ye…
RGB: RL Guided Whole-Body MPPI for Humanoid Control
arXiv:2606.25123v1 Announce Type: new Abstract: Humanoid robots require whole-body controllers that are both robust and precise in contact-rich environments. Wh…
Deep Reinforcement Learning-Enhanced Event-Triggered Data-Driven Predictive Control for a 3D Cable-Driven Soft Robotic Arm
arXiv:2606.26048v1 Announce Type: new Abstract: Soft robots are challenging to control due to their nonlinear and time-varying dynamics. Data-enabled predictive…
Beyond Topology: A Morphological Symmetry Graph Representation for Locomotion Policy Learning
arXiv:2512.00727v2 Announce Type: replace Abstract: Reinforcement learning has enabled impressive locomotion skills on articulated robots, but common policy rep…
Reflective VLA: In-Context Action Consequences Make VLAs Generalize
arXiv:2606.25215v1 Announce Type: cross Abstract: Most vision-language-action (VLA) models are reactive: they predict the next action from the current instructi…
SurveilNav: Collaborative Object Goal Navigation with Robot and Surveillance System
arXiv:2606.25119v1 Announce Type: new Abstract: With the growing deployment of surveillance systems in factories, offices, and homes, integrating them with robo…
Self Capacitive Tactile Sensor System designed for Companion Robots
arXiv:2606.25348v1 Announce Type: new Abstract: Tactile sensing is essential for humanoid robots to achieve safe physical interaction, dexterous manipulation, a…
Event-Adaptive Motion Planning with Distilled Vision-Language Model in Safety-Critical Situations
arXiv:2606.25629v1 Announce Type: new Abstract: Robot navigation in safety-critical scenarios faces significant challenges from unforeseen semantic events, wher…
From Rubble Simulation to Active Magnetic Mapping: Quantum Sensing for Disaster Response
arXiv:2606.25957v1 Announce Type: new Abstract: Locating survivors of building collapses within the first 72 hours is a critical challenge in disaster response,…
Action ControlNet: A Lightweight Delay-Aware Adapter for Smooth Asynchronous Control in Vision-Language-Action Models
arXiv:2606.25985v1 Announce Type: new Abstract: Vision-language-action (VLA) models have shown strong potential for general-purpose robot manipulation, but thei…
Sampling Strategies for Robust Universal Quadrupedal Locomotion Policies
arXiv:2510.07094v2 Announce Type: replace Abstract: This work focuses on sampling strategies of configuration variations for generating robust universal locomot…
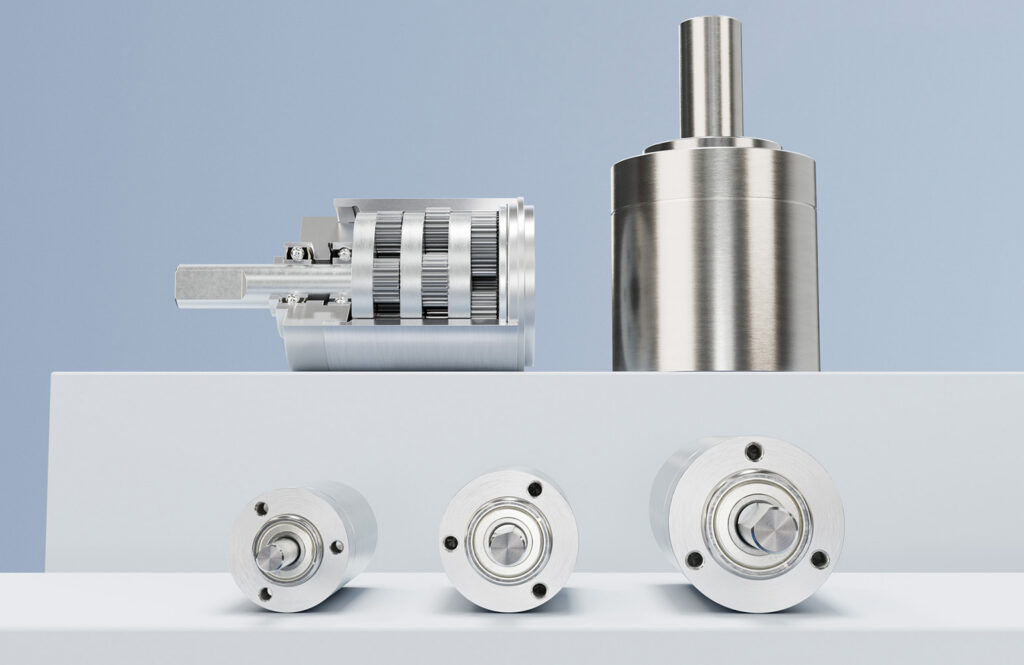
FAULHABER focuses on torque, noise, and power with new GPT gearheads
FAULHABER says its new GPT gearheads work with motors in its standard range and provide more performance with a compact design. The post FAULHABER focuses on to…
Reservoir acquires Contain to scale agtech startups
Reservoir has acquired agriculture finance platform Contain,, naming founder Nicola Kerslake general partner to help scale AI startups. The post Reservoir acqui…
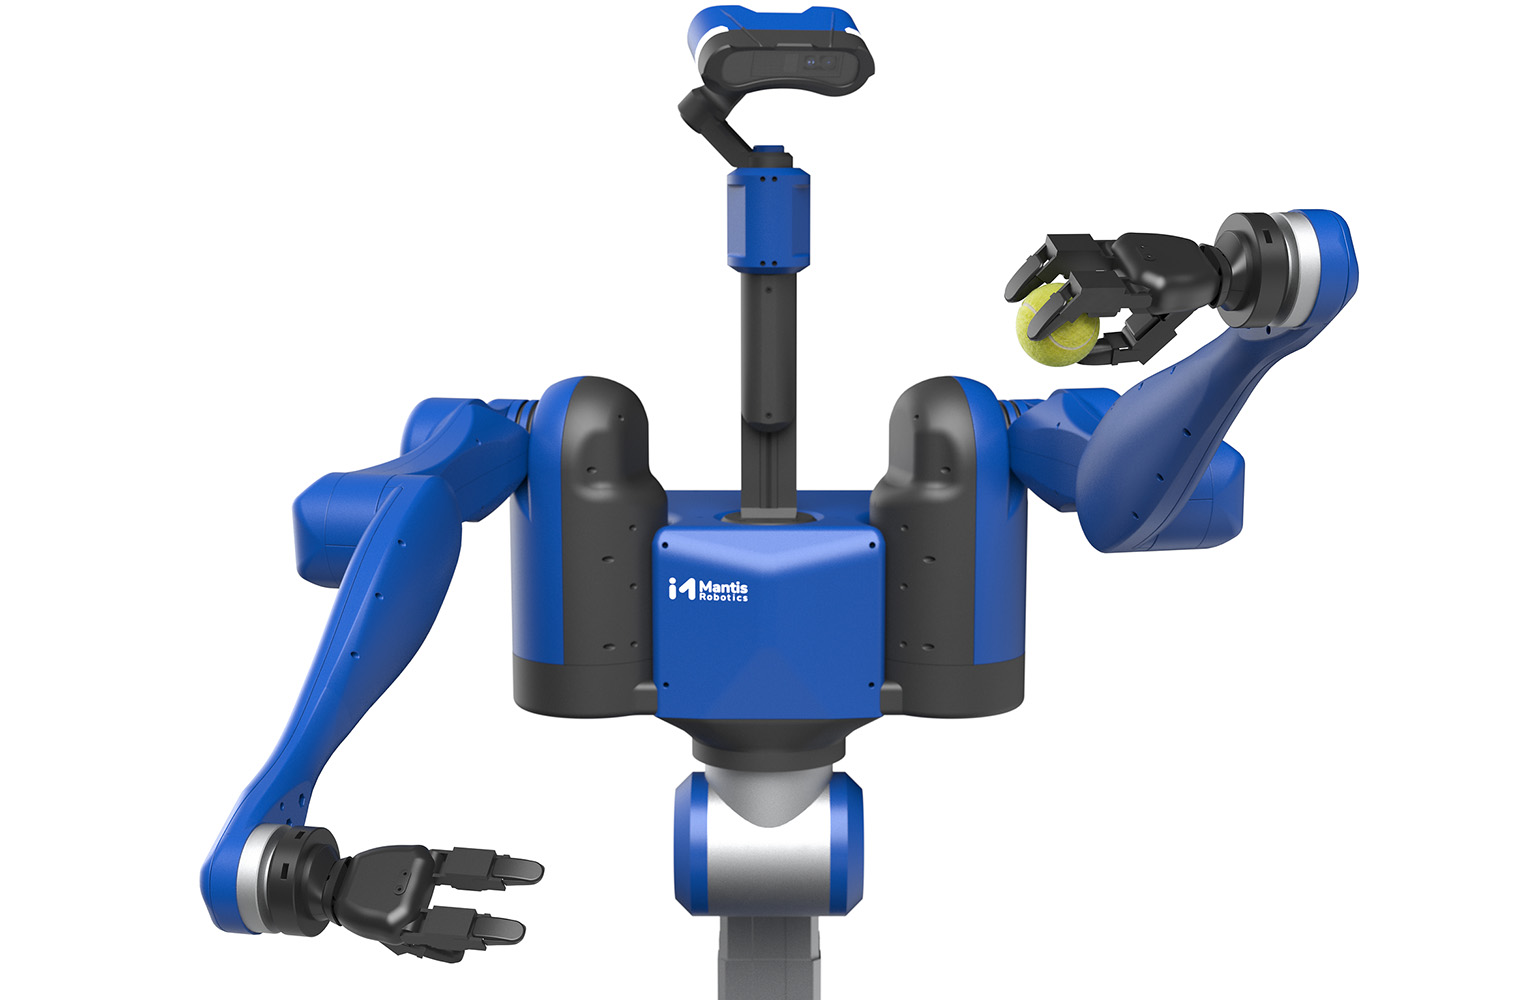
Mantis Robotics launches dual-arm, fenceless robot
Mantis said the robot allows for new flexibility in how to configure automation in complex, real-world environments. The post Mantis Robotics launches dual-arm,…
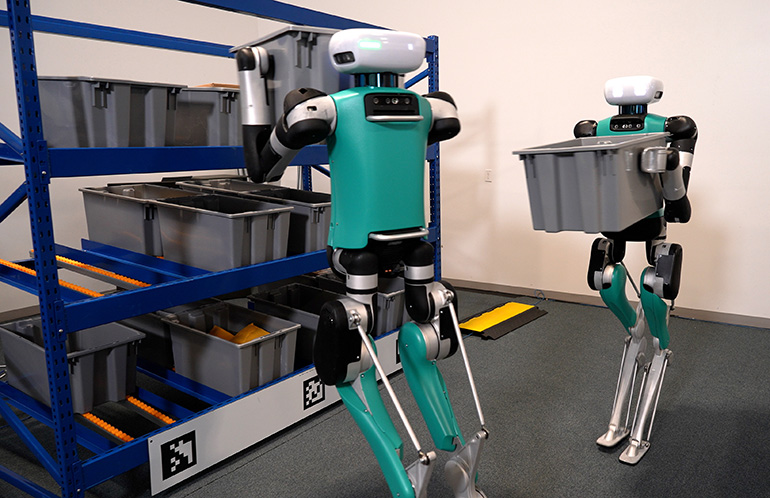
Humanoid maker Agility Robotics to go public through SPAC merger
Agility Robotics will merge with Churchill Capital Corp XI, raising $620 million to advance Digit v5 and fulfill growing customer orders. The post Humanoid make…
Grounding Generative Policies in Physics: Optimization-Guided Diffusion for Robot Control
arXiv:2606.24208v1 Announce Type: new Abstract: Diffusion models sample effectively from high-dimensional, multimodal distributions, but their outputs may viola…
Varying Bundle Size Reactive Multi-Task Assignment using Selective Cost Estimation for Multi-Agent Systems
arXiv:2606.24462v1 Announce Type: new Abstract: This paper presents a scalable framework for multi-robot task allocation in complex environments where estimatin…
Supervise What Survives: Geometry-Guided VLA Adaptation from Synthetic Robot Videos
arXiv:2606.24448v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models require large-scale video-action pairs, yet real teleoperation remains scarc…
G$^3$VLA: Geometric inductive bias for Vision-Language-Action Models
arXiv:2606.24472v1 Announce Type: new Abstract: Vision-language-action (VLA) models have made rapid progress in generalist robot manipulation by harnessing sema…
Explaining Failures of Cyber-Physical Systems with Actual Causality
arXiv:2606.24546v1 Announce Type: new Abstract: Modern autonomous Cyber-Physical Systems (CPSs), such as self-driving cars, face increasingly complex demands, a…
Flow as Flow: Modeling Robot Velocity Fields as Probability Velocity Fields for Flow-Based Object Manipulation
arXiv:2606.23090v2 Announce Type: replace Abstract: Cross-embodiment data have become central to training robotic foundation models. To leverage such heterogene…
PanoVine: Whole-Body Visuomotor Control for Soft Growing Vine Robot
arXiv:2606.22923v2 Announce Type: replace Abstract: Vine robots, a class of soft, growing robots, are suitable for navigating complex and confined environments …
Wh0: Generative World Models as Scalable Sources of Egocentric Human Hand Manipulation Data
arXiv:2606.22136v2 Announce Type: replace Abstract: Scaling dexterous manipulation requires generalization across objects, scenes, and tasks, yet existing data …